Related Experiment Video
Updated: Sep 9, 2025


WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Approximation-free finite-time control for uncertain active suspensions with unknown time-varying input delays
Wenbo Wang1, Shuang Liu1, Dingxuan Zhao2
1Key Laboratory of Industrial Computer Control Engineering of Hebei Province, Yanshan University, 066004, Qinghuangdao, China.

Abstract:
This article investigates a new approximation-free finite-time control method for active suspension systems (ASSs) to address uncertain nonlinearities and unknown time-varying input delays (UTIDs), while enhancing suspension performance. First, to improve the transient performance of ASSs, a unique finite-time prescribed performance function (FPPF) is designed to ensure that the suspension motion converges to a predetermined range within a finite time. Then, a novel compensator is developed to resolve the impact of unknown input delays in the closed-loop system. Finally, an approximation-free finite-time control method is presented for uncertain ASSs using the FPPF and the compensator. In this method, neural networks and fuzzy logic systems are not required to handle system uncertainties, and finite-time prescribed performance convergence of suspension motion can be achieved even in the presence of UTIDs. To exhibit the usefulness of the proposed method, a combined dynamic simulator is built using MATLAB and Simpack, a professional vehicle simulation software. Simulation results are presented to validate the effectiveness of the proposed method and show improved suspension performance.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 08:35
Interactive and Visualized Online Experimentation System for Engineering Education and Research
Published on: November 24, 2021
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:18
Second Order systems II
 01:21
First Order Systems
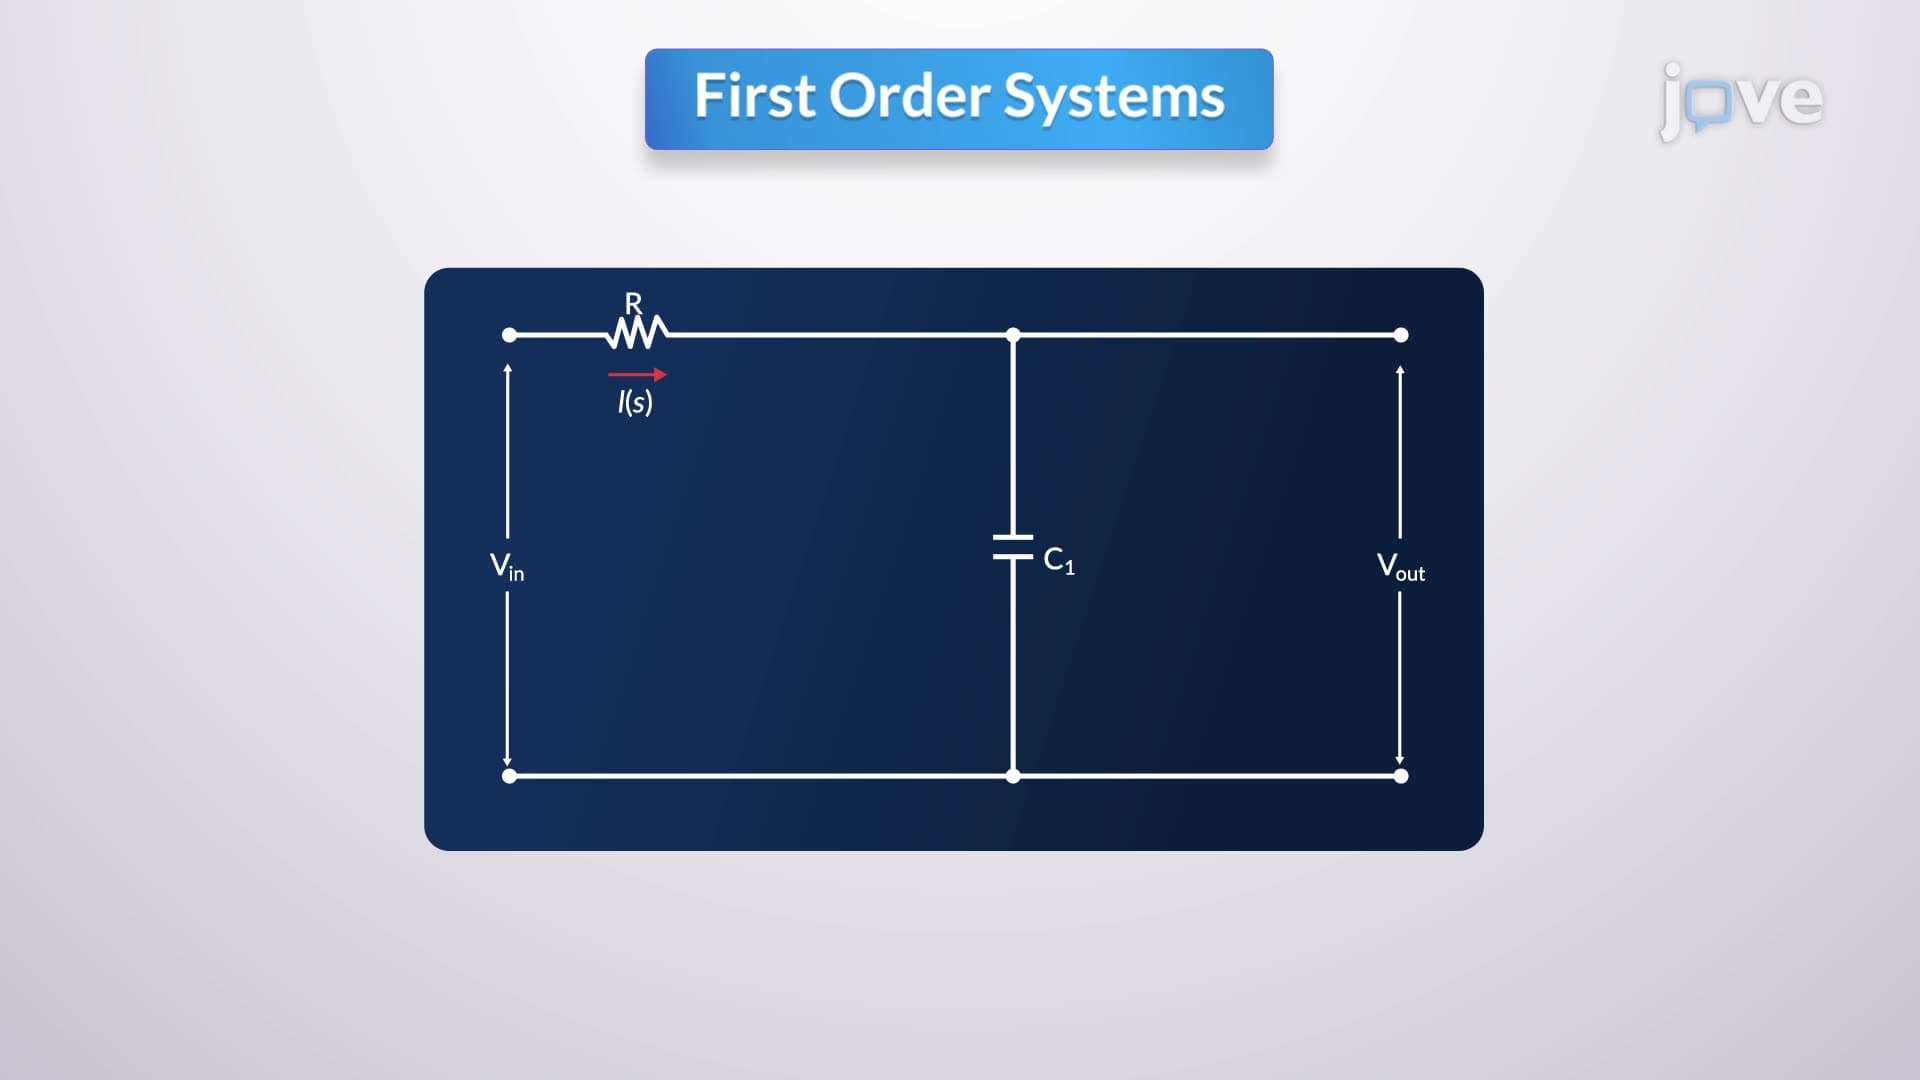
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...