Related Experiment Video
Updated: Sep 9, 2025
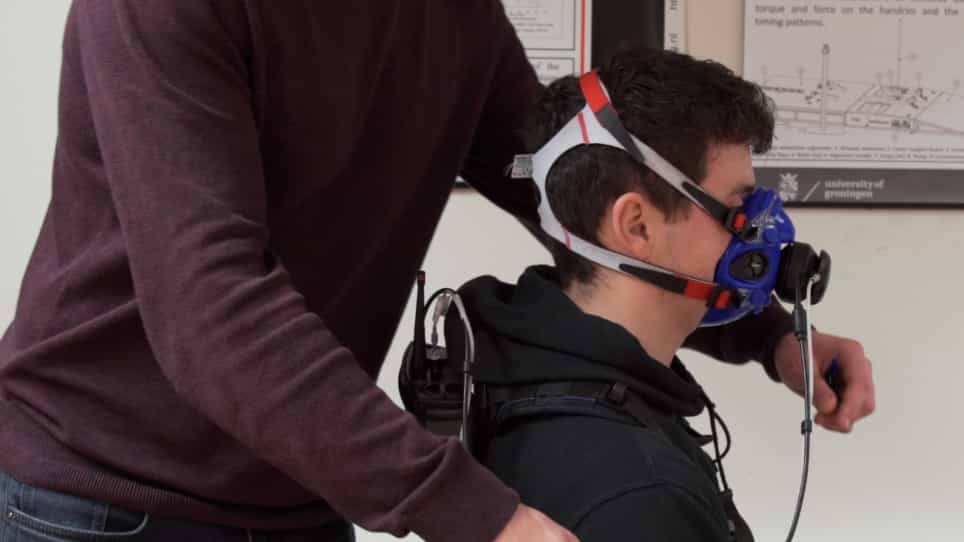

Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
Estimating braking and propulsion forces during overground running in and out of the lab
Lauren M Baker1, Fabian C Weigend1, Krithika Swaminathan1
1John A. Paulson School of Engineering and Applied Sciences, Harvard University, Boston, Massachusetts, United States of America.

Abstract:
Accurately estimating kinetic metrics, such as braking and propulsion forces, in real-world running environments enhances our understanding of performance, fatigue, and injury. Wearable inertial measurement units (IMUs) offer a potential solution to estimate kinetic metrics outside the lab when combined with machine learning. However, current IMU-based kinetic estimation models are trained and evaluated within a single environment, often on lab treadmills. The transferability of these treadmill-trained models during overground running in and out of the lab is underexplored, and the individualization and validation of such models remain a challenge. Toward bridging this gap, we trained a generalized model on treadmill data of 15 recreational runners and evaluated braking and propulsion force estimates during overground running in and out of the lab. We explored fine-tuning with individual data from lab-based overground running to quantify model performance improvements with individualization. The generalized and fine-tuned models were extrapolated to outdoor running for a subset of five participants, and estimates were compared to lab-based overground measurements. Evaluating the generalized model with a leave-one-out cross validation yielded overground braking and propulsion force root mean squared error of 4.3 ± 1.1 % bodyweight (%BW). Fine-tuning this model with eight strides reduced error to 2.6 ± 0.5 %BW. Outdoor force predictions from the fine-tuned model better aligned with expected linear trends between braking/propulsion impulses and speed than the generalized model. These results provide insights into the accuracy and applicability of IMU data-driven models for braking and propulsion estimation during overground running, facilitating the development of practical, individualized biomechanical analysis tools for real-world use.
More Related Videos
 10:28
Kinematics and Ground Reaction Force Determination: A Demonstration Quantifying Locomotor Abilities of Young Adult, Middle-aged, and Geriatric Rats
Published on: February 22, 2011
 10:52
Simulation of Human-induced Vibrations Based on the Characterized In-field Pedestrian Behavior
Published on: April 13, 2016
Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:05
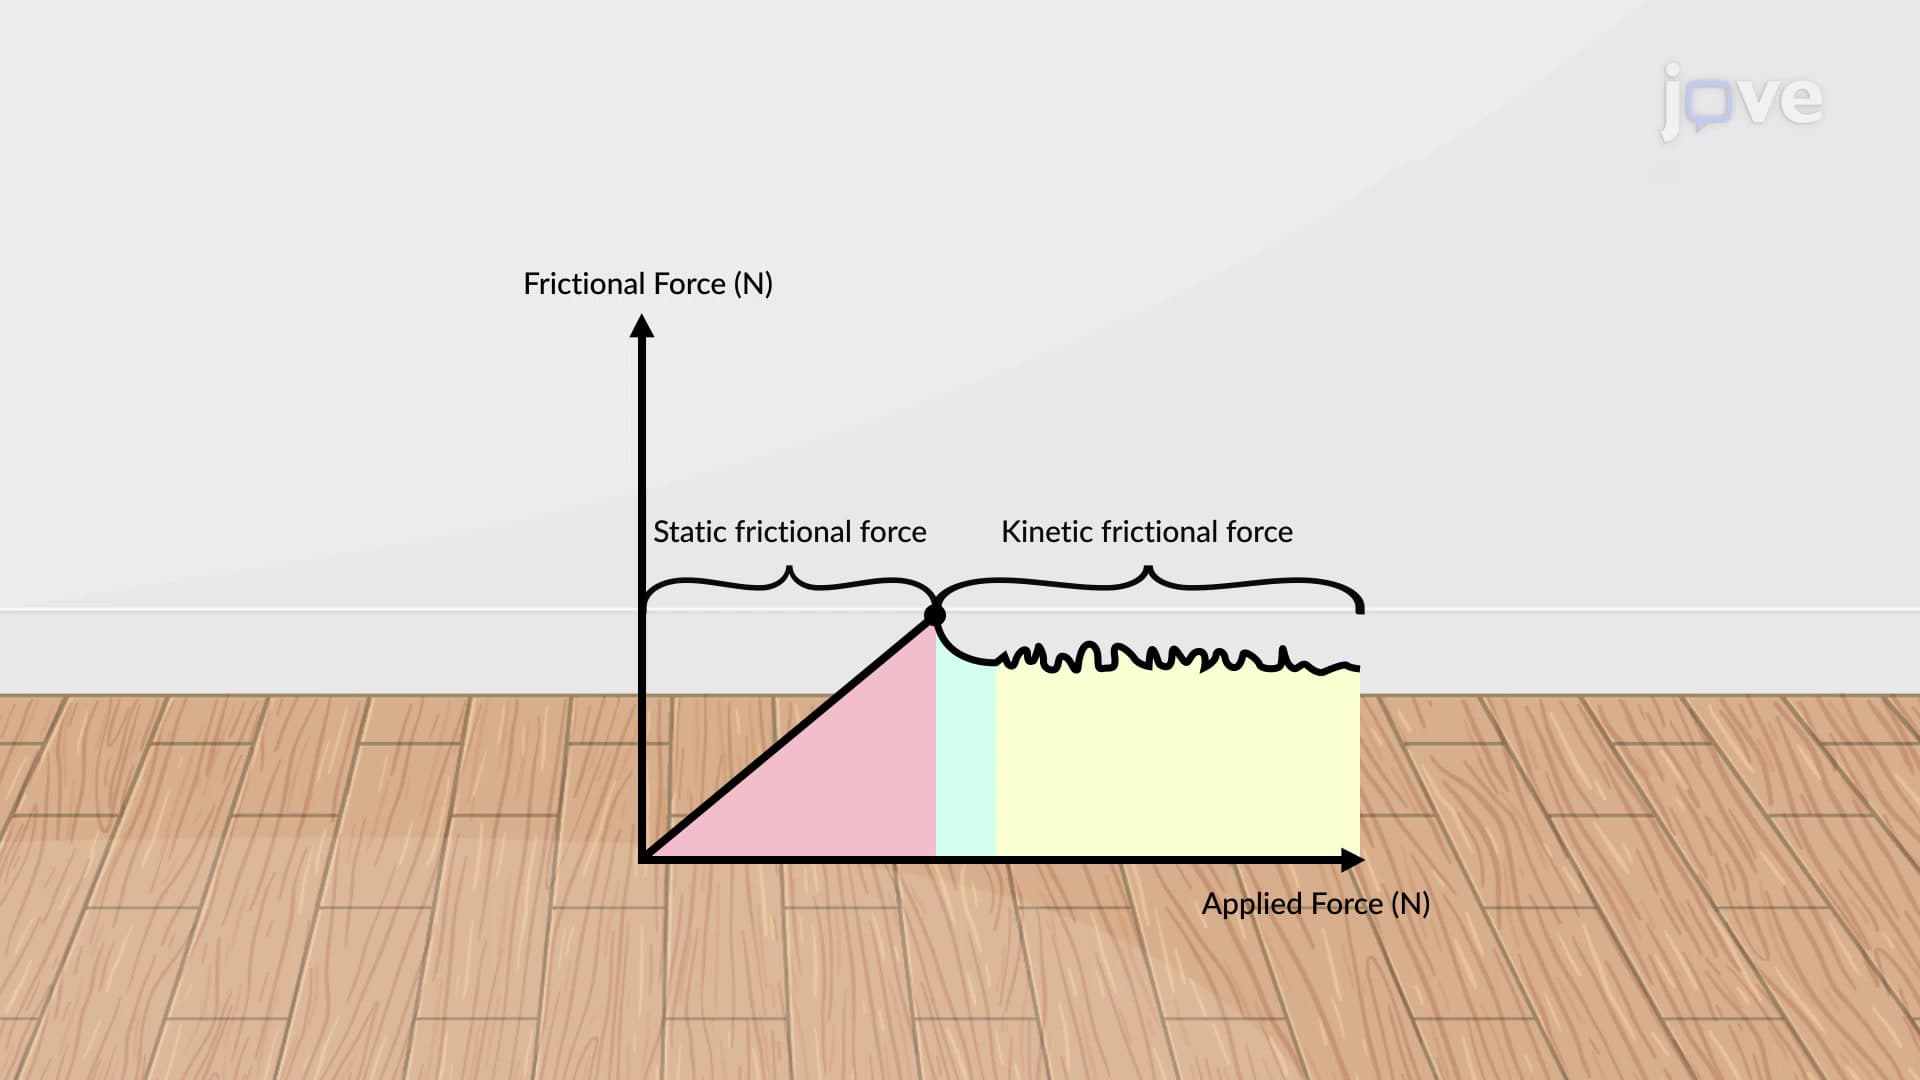
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 00:57
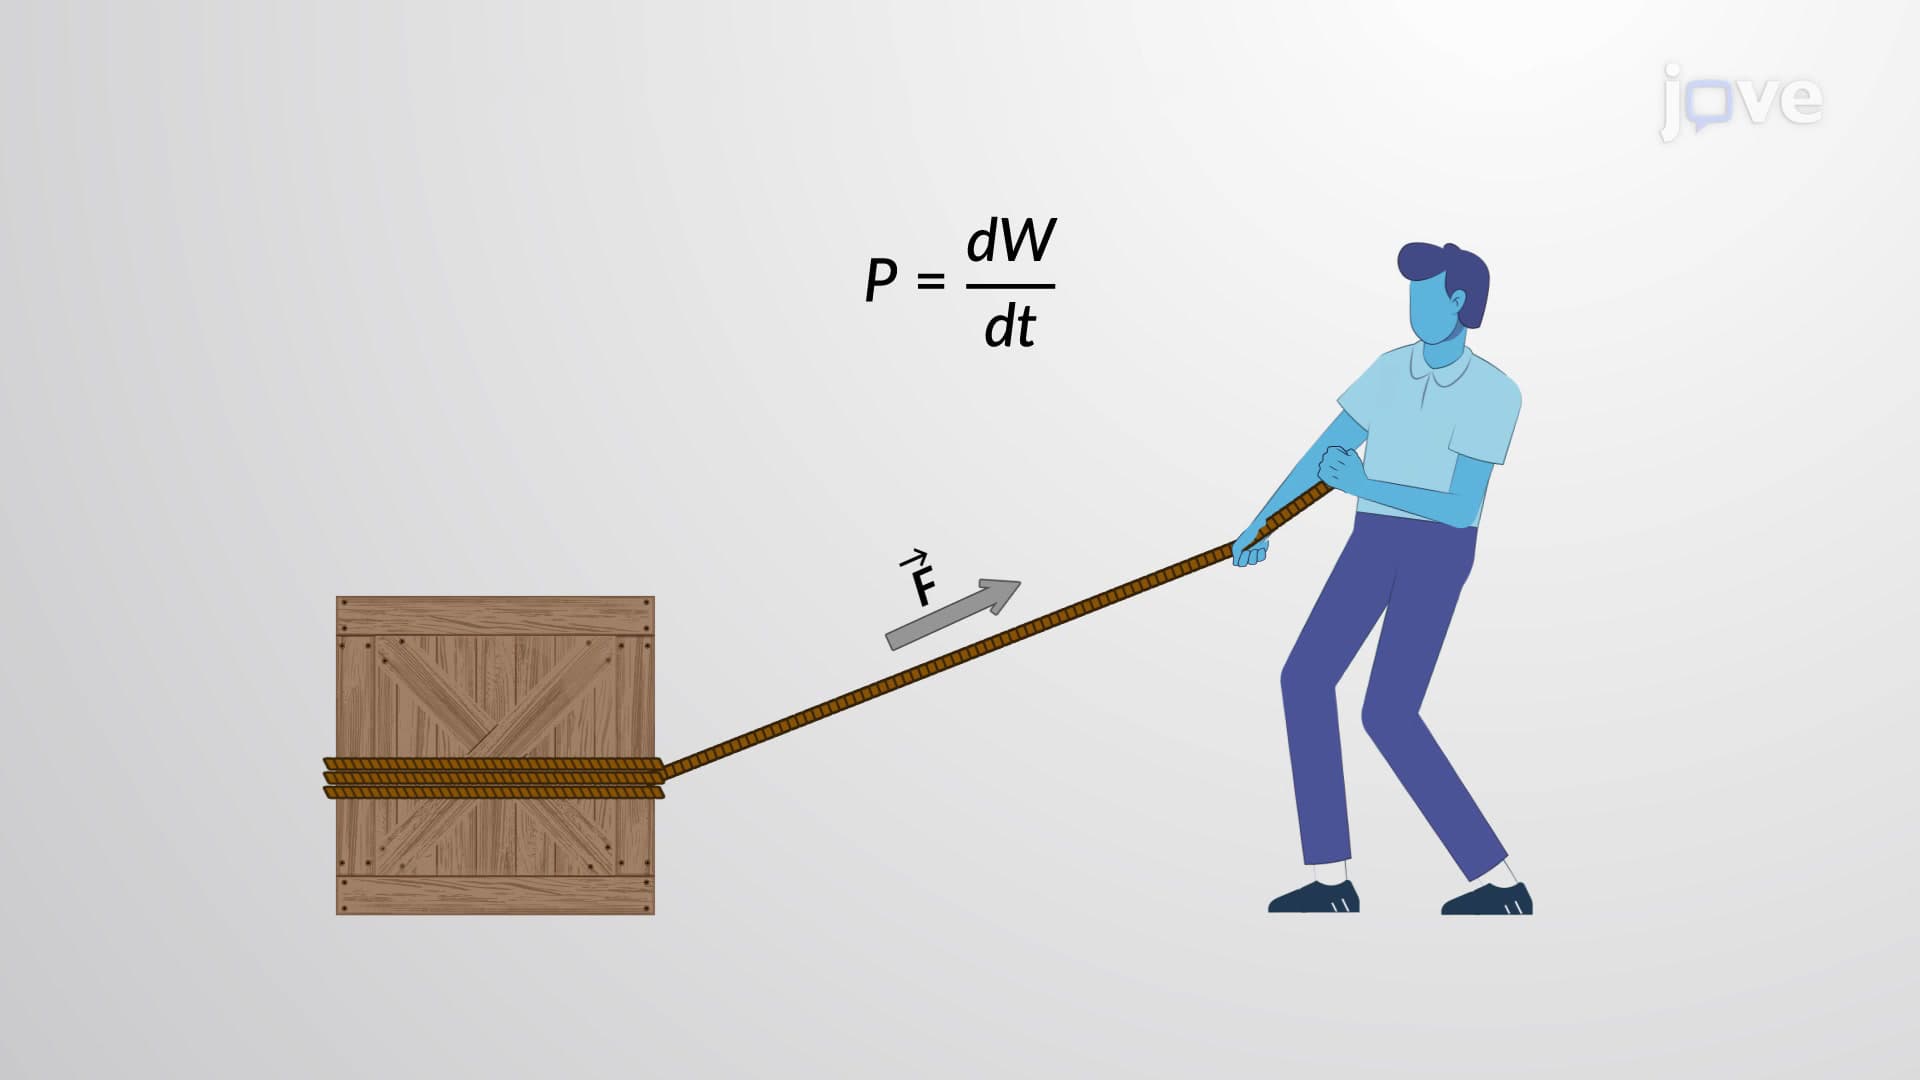
Power Expended by a Constant Force
 01:21
Rolling Resistance
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down...
 01:10
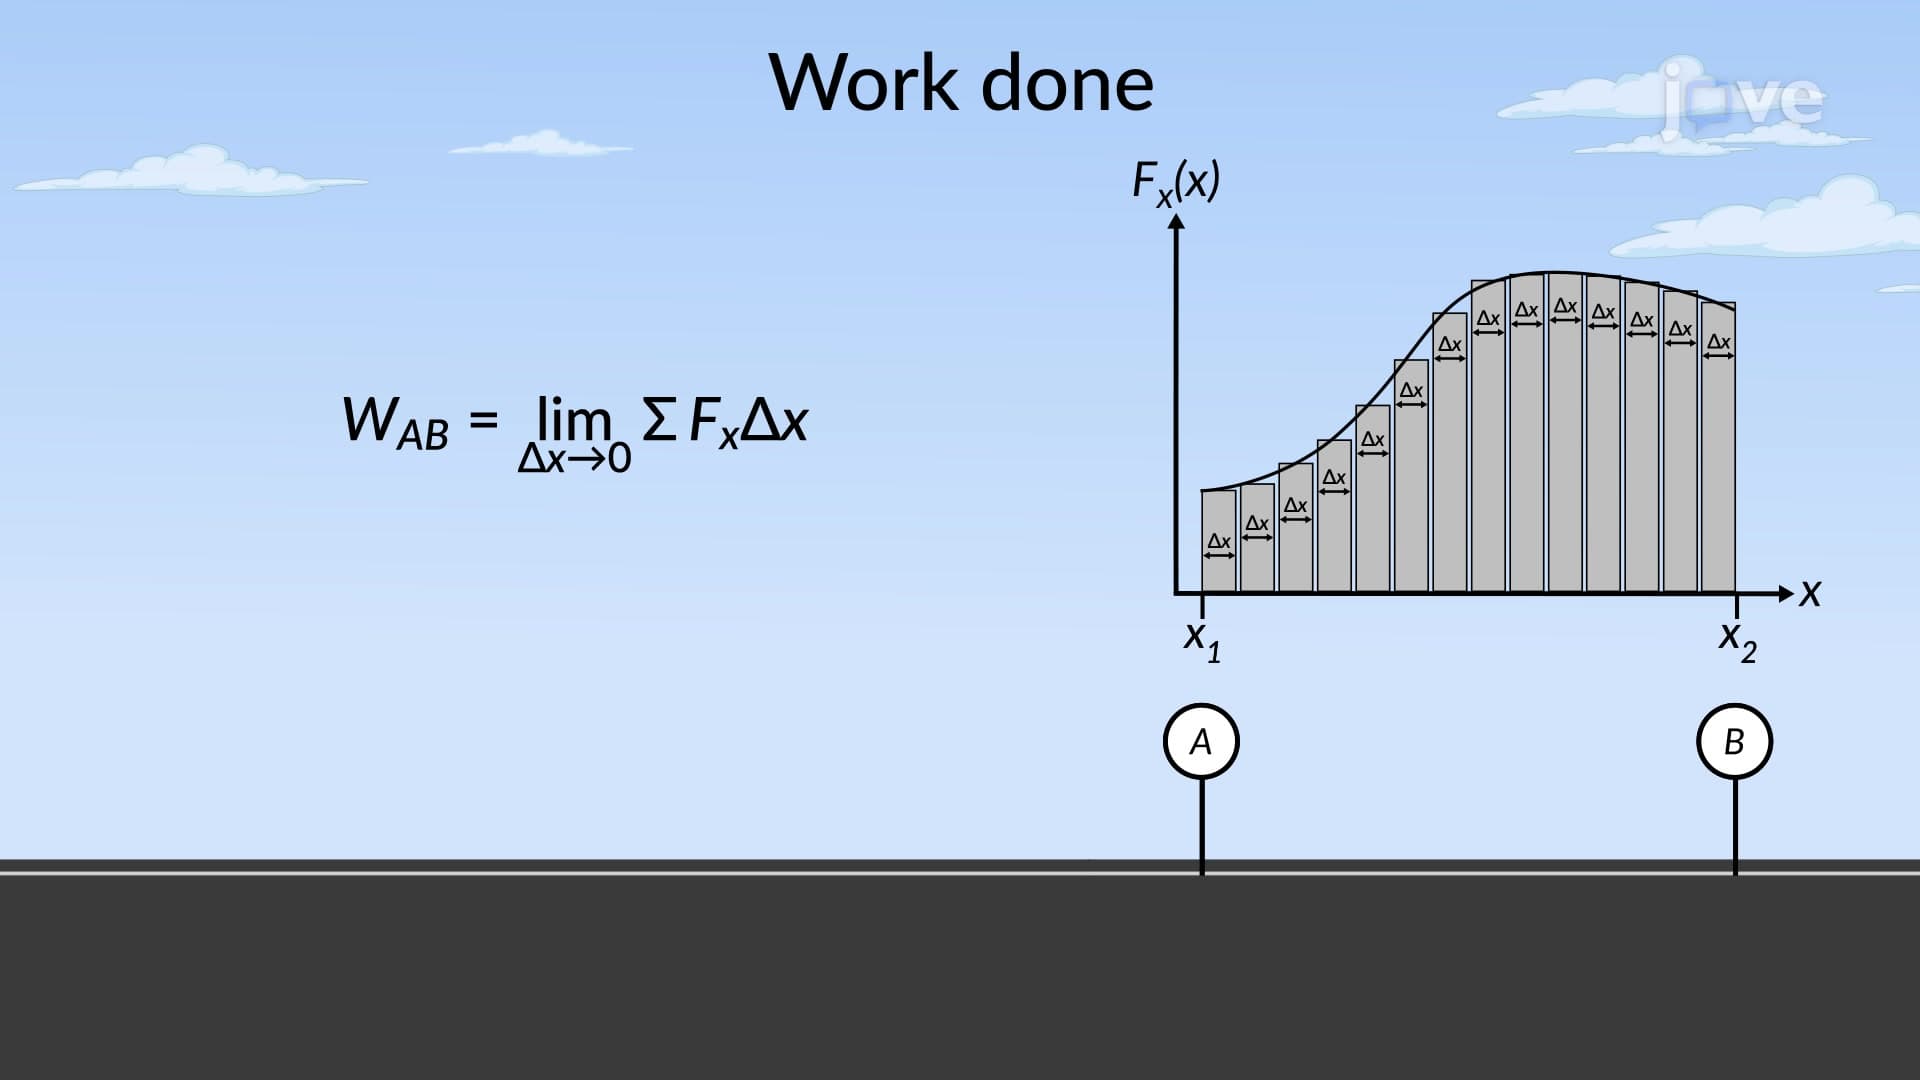
Work and Energy for Variable Forces
 01:28
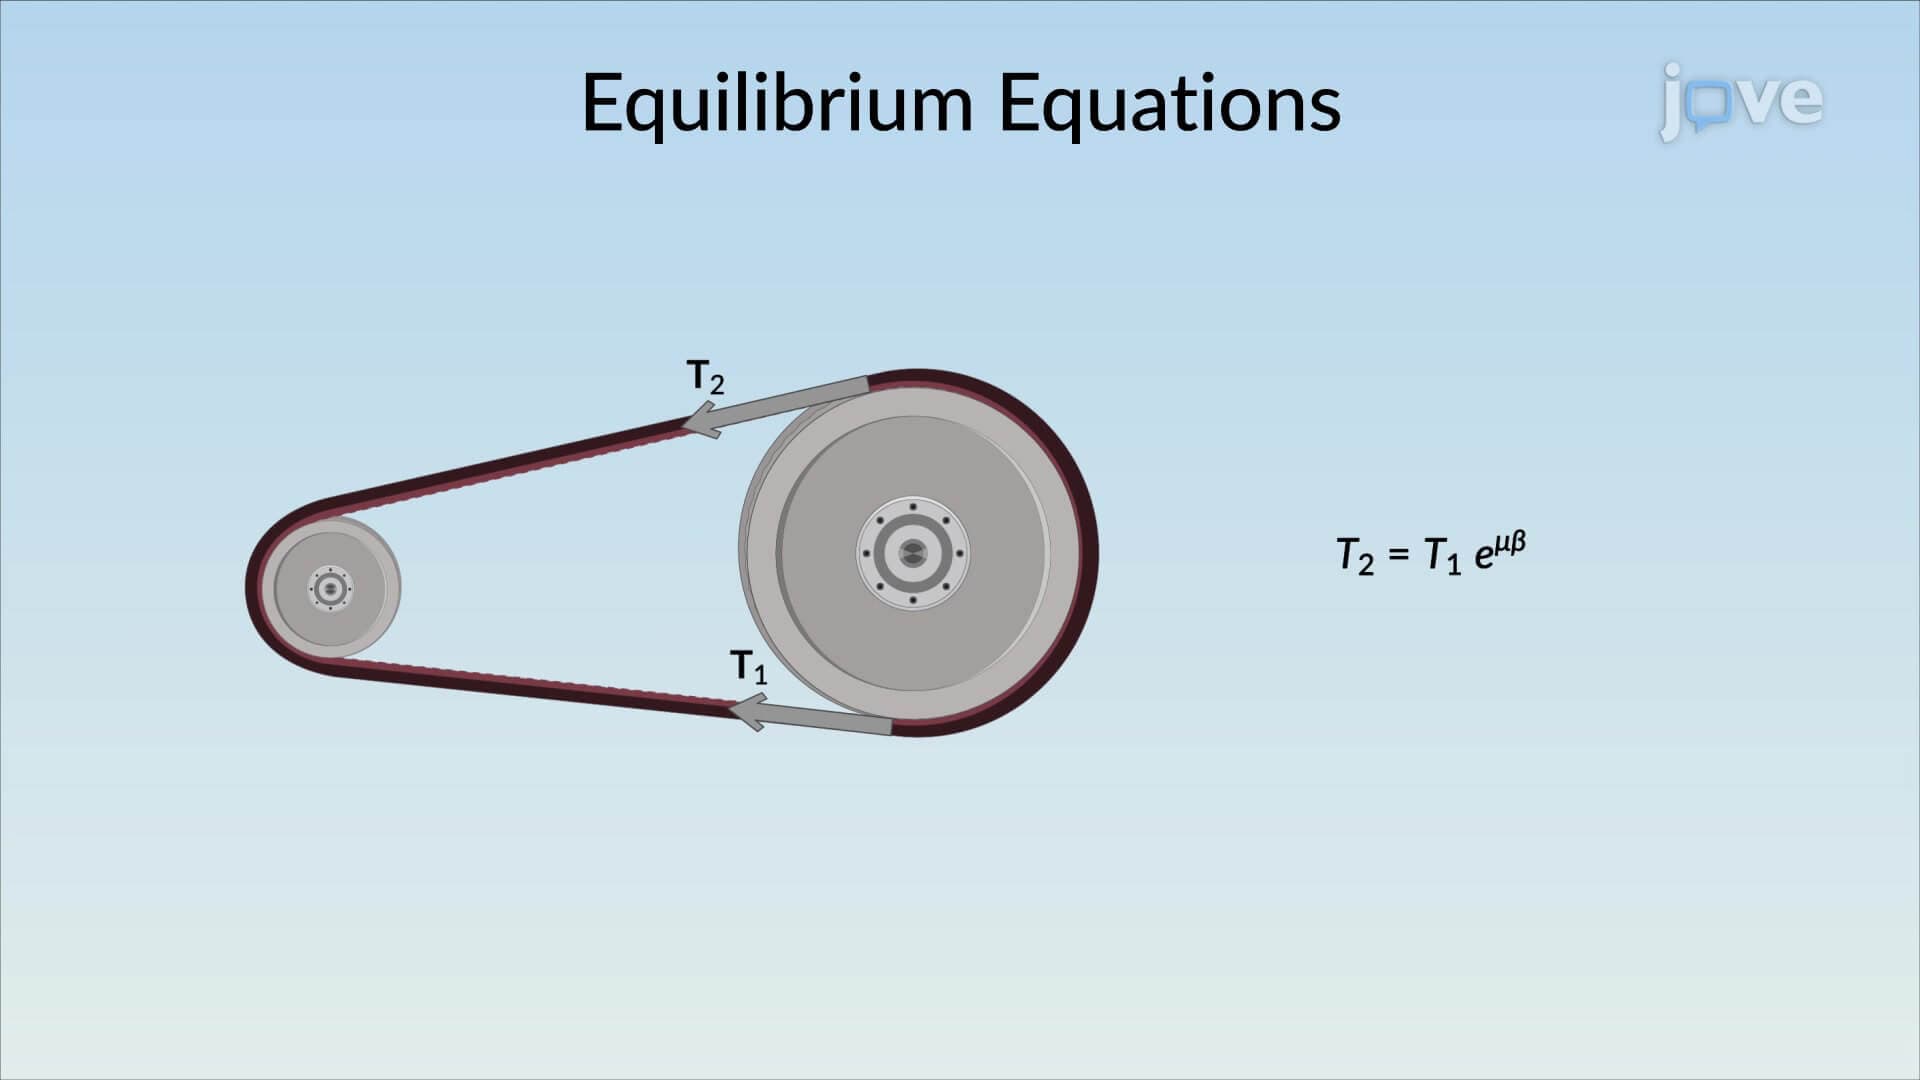
Frictional Forces on Flat Belts