Related Experiment Video
Updated: Sep 8, 2025


Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
Optimum Push-Off for Uneven Walking Based on the Just-In-Time Strategy: Walking With Interrupted Push-Off Is
Seyed-Saleh Hosseini-Yazdi1, John E A Bertram2,3
1Department of Biomedical Engineering, Schulich School of Engineering, University of Calgary, Calgary, AB T2N 1N4, Canada; Human Performance Laboratory, Faculty of Kinesiology, University of Calgary, Calgary, AB T2N 1N4, Canada.

Abstract:
We examine the limits of push-off, and we explore when alternate joint actuation might replace it. Using a powered simple walking model (point mass with rigid massless legs), the optimal analytical push-off was derived based on walking speed and step elevation changes. It was observed that higher speeds increased the available push-off to attain greater step-up, e.g., a walker at 1.4 m/s could manage a step-up amplitude of Δh = 0.106 m with a push-off only. Step-up amplitude also required a minimum walking speed for the required push-off. When poststep transition energy compensation was necessary, delayed push-off exerted along the trailing leg led to some wasted work. Walking over smooth surfaces, the delayed push-off cost was up to 7.5 times higher than the optimal push-off, whereas hip-driven compensation was lower at 3.2 times the optimal work. A similar pattern was also observed for step-ups. Our simulation results match young adult walking when terrain view was unrestricted. We utilized available empirical data to quantify the incremental energetic cost of disrupted push-off. It showed that the frequency and poststep transition compensation costs were comparable. As step length further decreased, the cost of poststep transition compensation rose more rapidly, possibly defining a lower limit for step length. The poststep transition compensation rose by 0.18 W/kg/%ΔHz in young adults and 0.2 W/kg/%ΔHz in older adults. Additionally, visual constraints amplified the cost by 0.05 W/kg/%ΔHz.
Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:16
Eccentric Loading
 01:21
Distributed Loads: Problem Solving
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 00:48
Optimal Foraging
 01:19
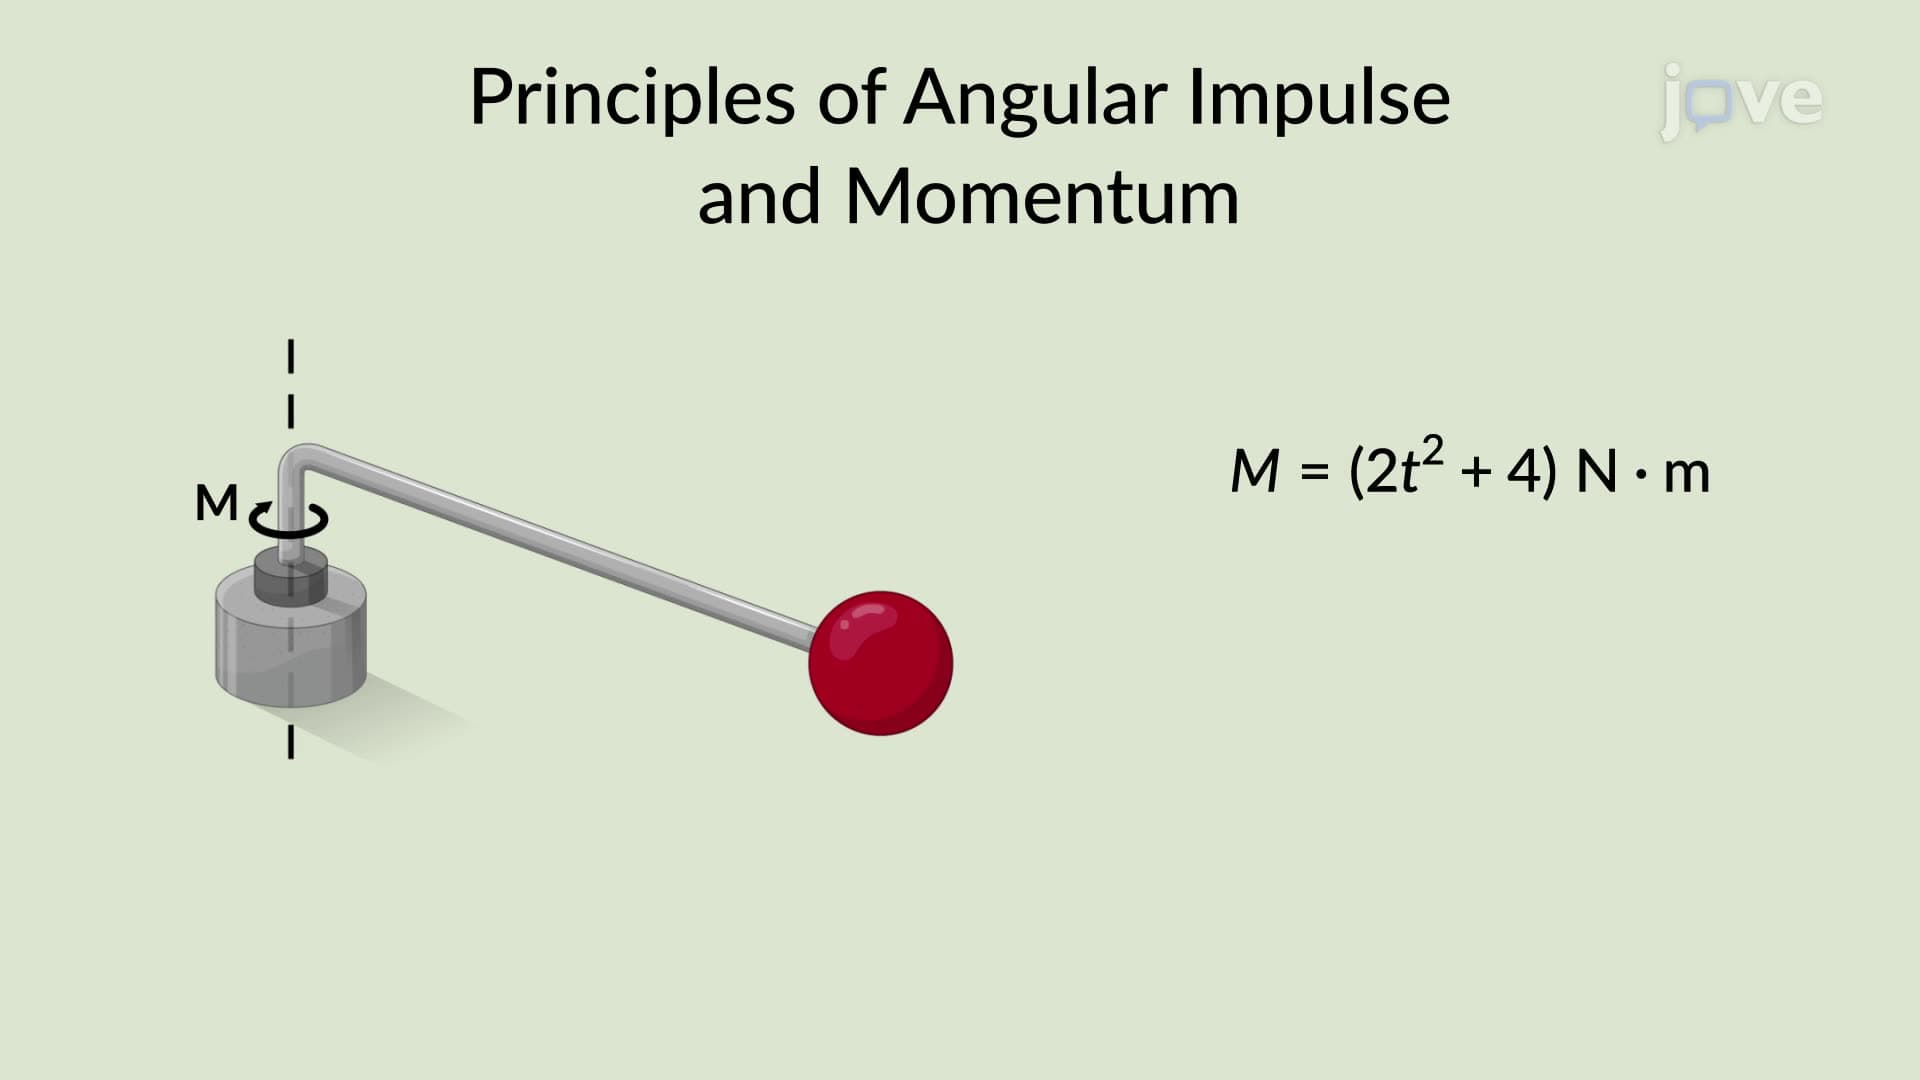
Principle of Angular Impulse and Momentum: Problem Solving
Initially, a free-body diagram of the system is drawn to illustrate all the forces acting upon the system, providing a crucial understanding of the dynamics at play. Then, the principle of angular impulse and momentum is...