Related Experiment Video
Updated: Jan 6, 2026

Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
A Three-Phase Electrostatic Clutch with Variable Mechanical Impedance Control for Soft Robotic Systems
Dongyoung Lee1, Heejin Yu2, Joonbum Bae3
1Electronics and Telecommunications Research Institute (ETRI), Daejeon, 34129, South Korea.

Abstract:
Various studies have explored mechanical impedance control strategies in soft actuators to enhance stability and precision, as the nonlinear characteristics of soft materials frequently lead to unwanted oscillations. Among these approaches, electrostatic (ES) clutches have shown promise for achieving friction-based mechanical impedance control; however, conventional ES clutches are limited by issues such as residual charge accumulation and stick-slip behavior, which compromise force stability and reliability over time. To address these limitations, this study introduces a three-phase ES clutch with variable mechanical impedance control, designed to enable continuous friction modulation and thereby reduce force degradation and oscillatory motion. Experimental validation was conducted through tensile tests and mechanical impedance applications in a vibration system. These findings suggest that the proposed three-phase ES clutch offers a robust and adaptable solution for friction modulation and mechanical impedance in soft robotic and wearable systems, effectively addressing the key limitations of conventional ES clutch technology.

Related Concept Videos
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:22
Mechanical Systems
 01:22
Phase-lead and Phase-lag Controllers
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:05
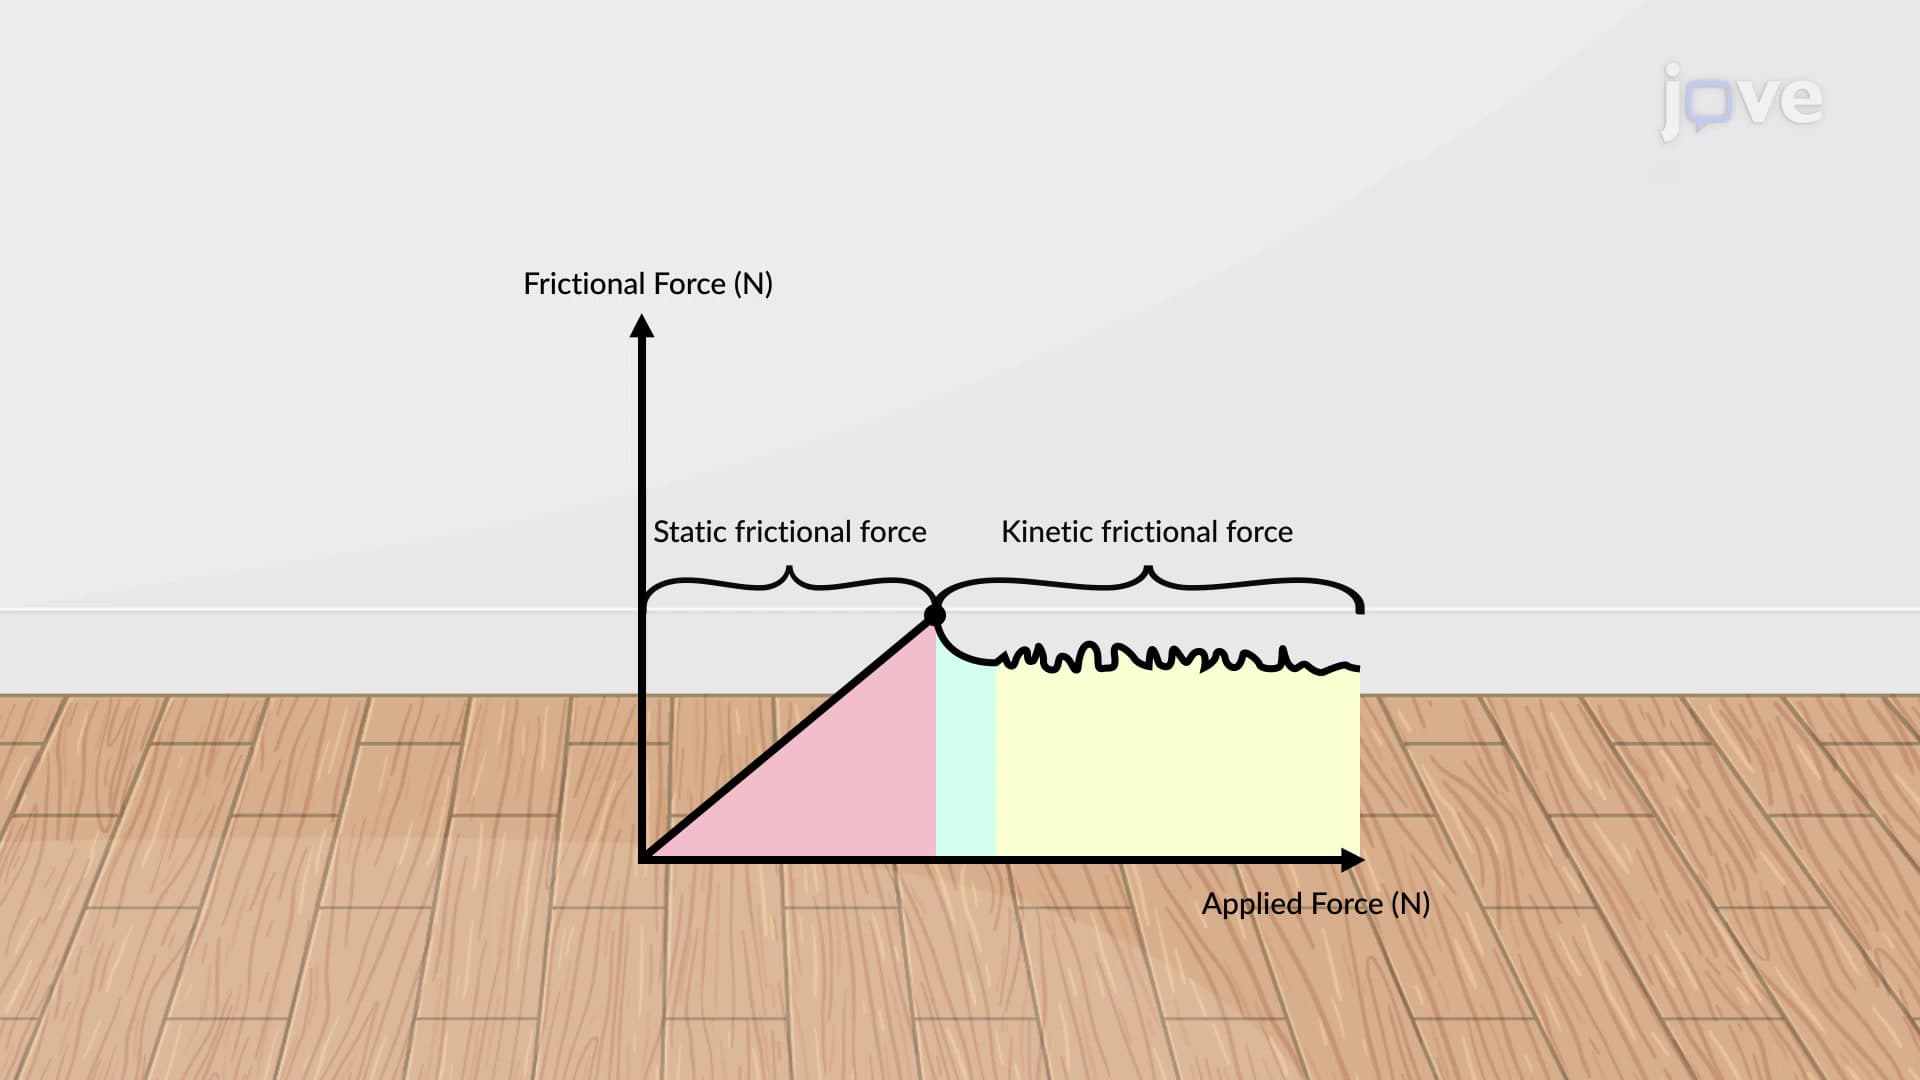
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...