Related Experiment Video
Updated: Jan 17, 2026


Operation of the Collaborative Composite Manufacturing CCM System
Published on: October 1, 2019
Research on robot positioning error compensation algorithm based on the Dog Leg and PSONN algorithm
1School of Instrument Science and Opto-electronic Engineering, Hefei University of Technology, Hefei, China.

Abstract:
The absolute positioning accuracy of industrial robots is much lower than that of repetitive. In this paper, an error compensation algorithm for industrial robots is proposed, which included the kinematic parameter calibration based on the enhanced Dog Leg algorithm, the odd point error prediction based on the Particle Swarm Optimization Neural Network (PSONN) algorithm, and the positioning error calculation based on the Spatial Grid Multipoint Interpolation (SGMI) algorithm. The proposed algorithm reduce the robot localization error in three progressive steps, which combines the interpretability of traditional algorithms and the nonlinear effect of neural networks, avoiding the low accuracy of traditional algorithms and the local optimal phenomenon of neural networks. The robot end positioning error model developed in this paper, mainly includes kinematic parameters, return angle, deceleration ratio relative error coefficients, joint angle coupling coefficients, and base coordinate system error. The experimental results demonstrate that, after calibrating kinematic parameter, the positioning error is reduced from 3.158 mm to 0.406 mm, the uncertainty is reduced from 1.726 mm to 0.160 mm. After compensating by the SGMI algorithm, the positioning error is reduced from 0.406 mm to 0.0685 mm. The results also demonstrate that the proposed SGMI algorithm calibrate the kinematic parameter effectively and reduced the positioning error of the industrial robot significantly.


Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:03
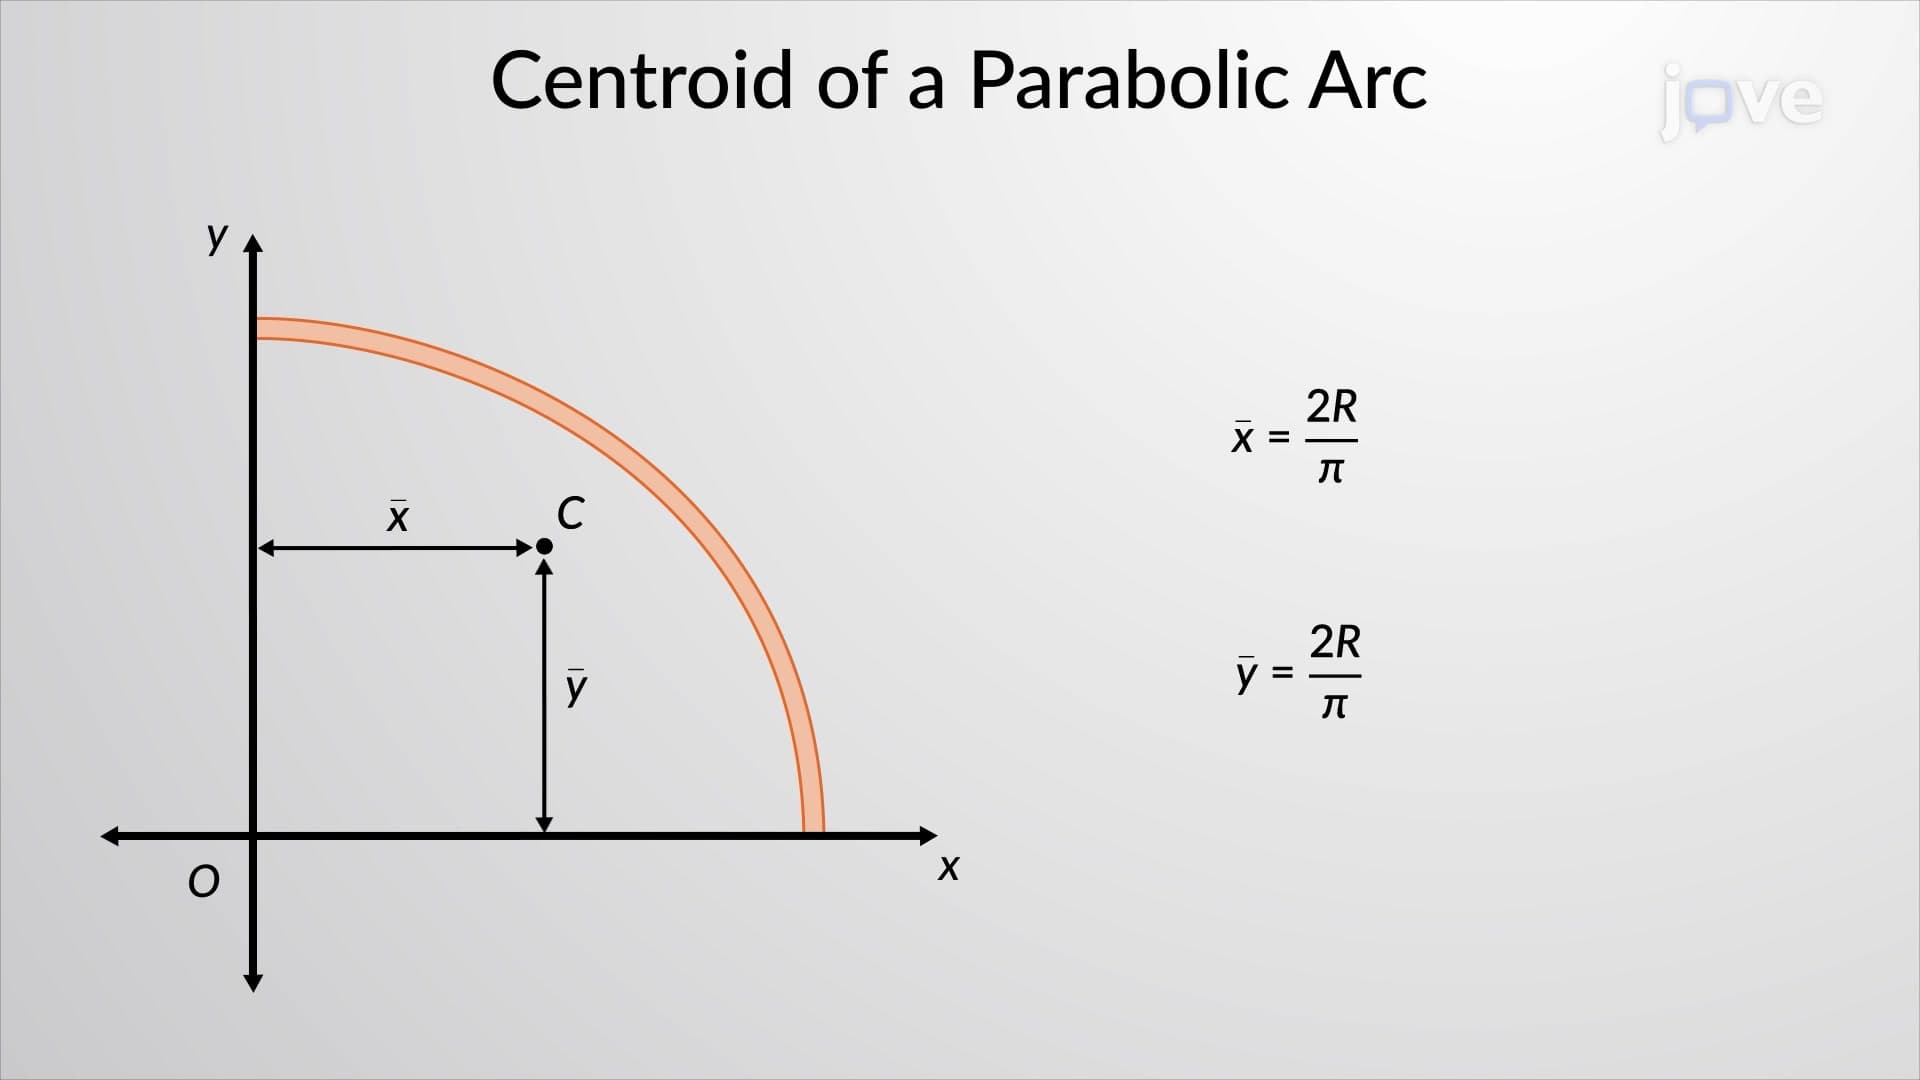
Centroid of a Body: Problem Solving
The x-coordinates and y-coordinates of each element's...
 01:15
Kinematic Equations: Problem Solving
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...