Related Experiment Video
Updated: Jan 17, 2026
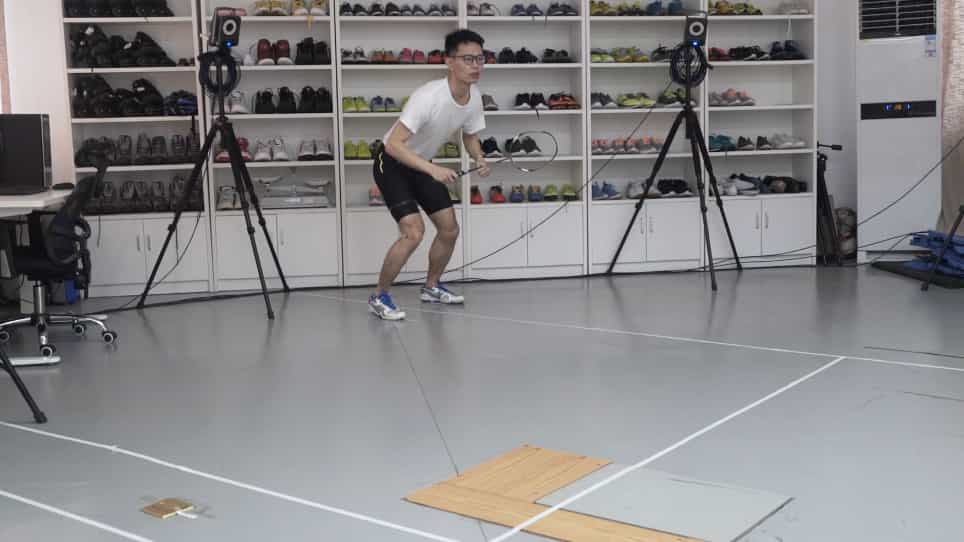
Biomechanical Analysis Methods to Assess Professional Badminton Players' Lunge Performance
Published on: June 11, 2019
Imitation-relaxation reinforcement learning for sparse badminton strikes via dynamic trajectory generation
Yanyan Yuan1,2,3,4, Yucheng Tao1,2,3,4, Shaowen Cheng1,2,3,4
1Center for X-Mechanics, Zhejiang University, Hangzhou, China.

Abstract:
Robotic racket sports provide exceptional benchmarks for evaluating dynamic motion control capabilities in robots. Due to the highly non-linear dynamics of the shuttlecock, the stringent demands on robots' dynamic responses, and the convergence difficulties caused by sparse rewards in reinforcement learning, badminton strikes remain a formidable challenge for robot systems. To address these issues, this study proposes DTG-IRRL, a novel learning framework for badminton strikes that integrates imitation-relaxation reinforcement learning with dynamic trajectory generation. The framework demonstrates significantly improved training efficiency and performance, achieving faster convergence and twice the landing accuracy. Analysis of the reward function within a specific parameter space hyperplane intuitively reveals the convergence difficulties arising from the inherent sparsity of rewards in racket sports and demonstrates the framework's effectiveness in mitigating local and slow convergence. Implemented on hardware with zero-shot transfer, the framework achieves a 90% hitting rate and a 70% landing accuracy, enabling sustained humanrobot rallies. Cross-platform validation using the UR5 robot demonstrates the framework's generalizability while highlighting the requirement for high dynamic performance of robotic arms in racket sports.

Related Concept Videos
 01:29
Relaxation of Skeletal Muscles
When an action potential reaches the axon terminal, it depolarizes the membrane and opens voltage-gated sodium channels. Sodium ions enter the cell, further depolarizing the presynaptic membrane. This depolarization causes voltage-gated calcium channels to open....
 01:26
Orthogonal Trajectories
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:15
Kinematic Equations: Problem Solving
 01:23
Principle of Linear Impulse and Momentum for a Single Particle: Problem Solving
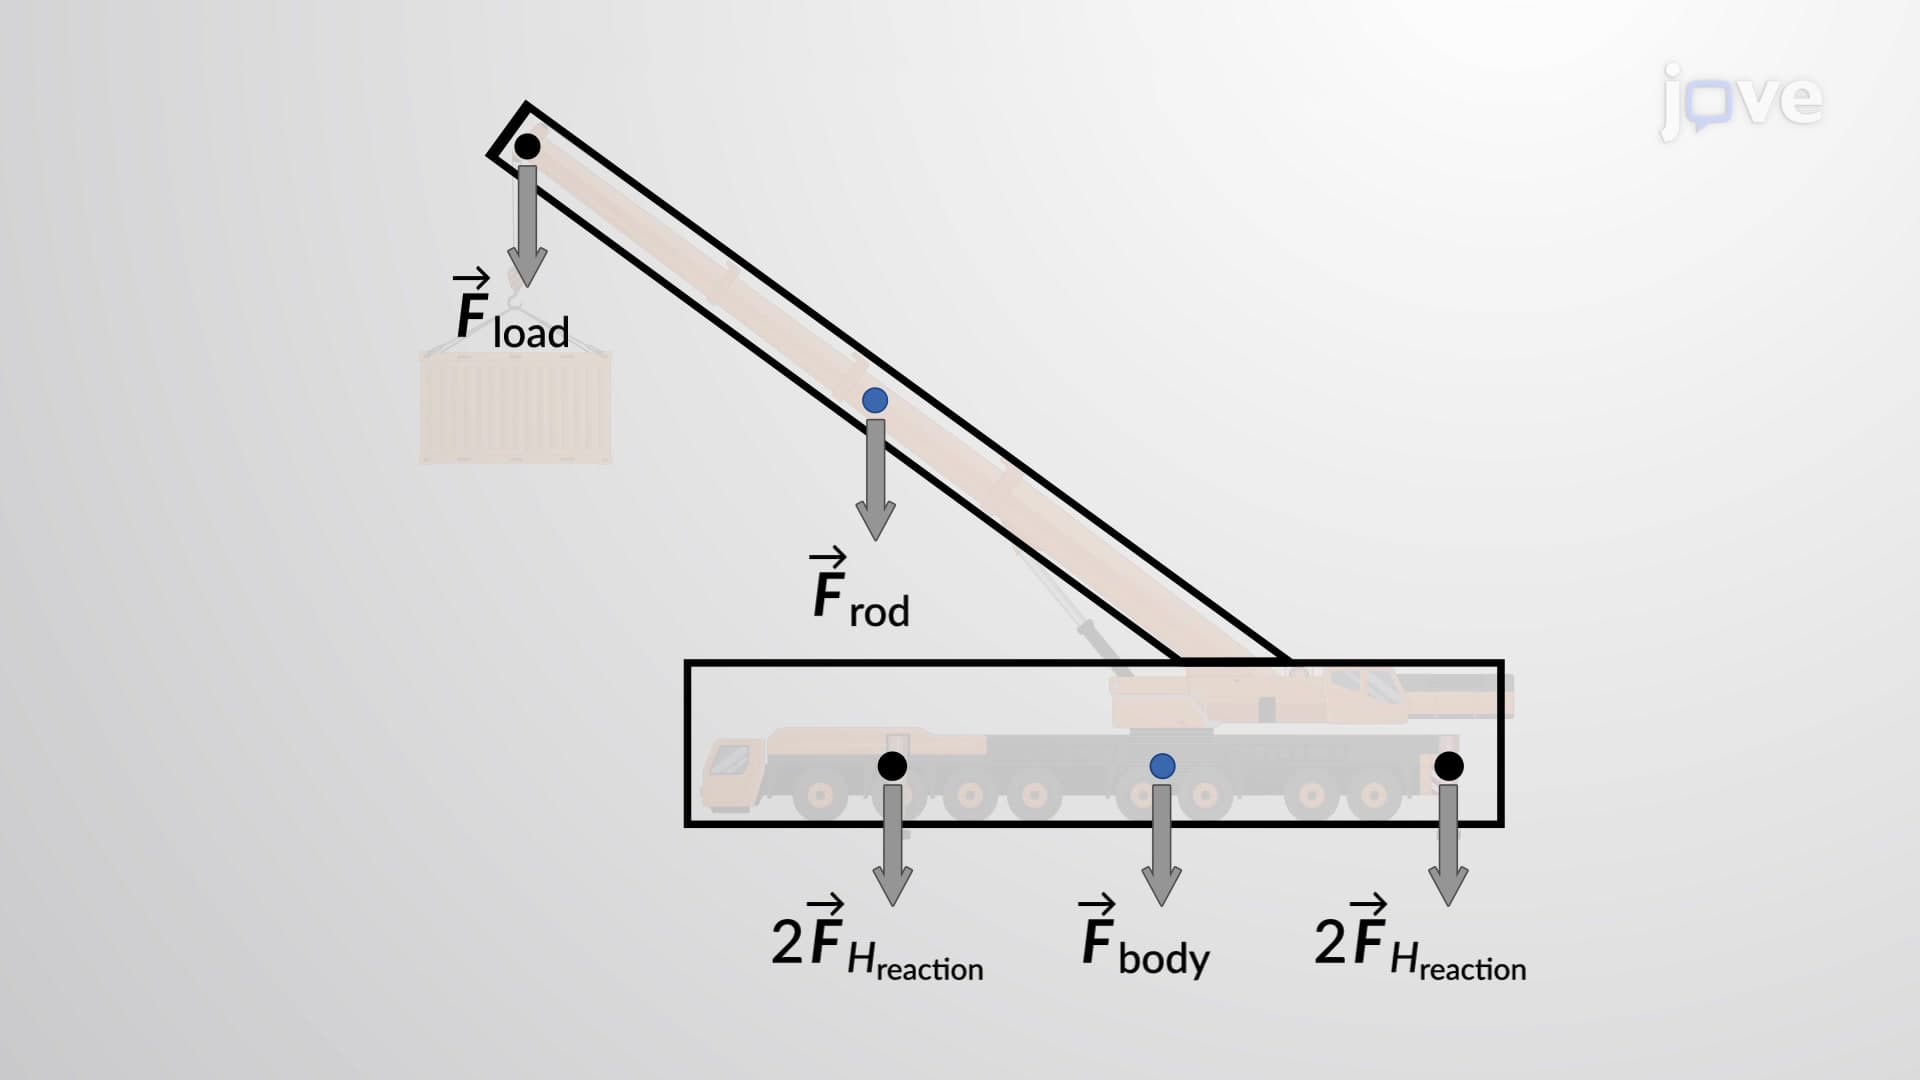 00:49
Rigid Body Equilibrium Problems - I