Related Experiment Video
Updated: Aug 4, 2026


Combining Eye-tracking Data with an Analysis of Video Content from Free-viewing a Video of a Walk in an Urban Park Environment
Published on: May 7, 2019
End-to-End Autonomous Driving Without Costly Modularization and 3D Manual Annotation

Abstract:
We propose UAD, an end-to-end framework with Unsupervised pretext task for vision-based Autonomous Driving, achieving the best open-loop evaluation performance in nuScenes, meanwhile showing robust closed-loop driving quality in CARLA. Our motivation stems from the observation that current end-to-end autonomous driving (E2EAD) models still mimic the modular architecture in typical driving stacks, with carefully designed supervised perception and prediction subtasks to provide environment information for oriented planning. Although achieving groundbreaking progress, such design has certain drawbacks: 1) preceding subtasks require massive high-quality 3D annotations as supervision, posing a significant impediment to scaling the training data; and 2) each submodule entails substantial computation overhead in both training and inference. To this end, we propose UAD, an E2EAD framework with an unsupervised1 proxy to address all these issues. Firstly, we design a novel Angular Perception Pretext to eliminate the annotation requirement. The pretext perceives the driving scene by predicting the angular-wise spatial objectness and temporal dynamics, without manual annotation. Secondly, a self-supervised training strategy, which learns the consistency of the predicted trajectories under different augment views, is proposed to enhance the planning robustness in steering scenarios. Our UAD achieves 38.7% relative improvements over UniAD on the average collision rate of nuScenes open-loop evaluation and obtains the route completion score of 98.5% in closed-loop evaluation of CARLA's Town05 Long benchmark, which outperforms the recent work VADv2. Moreover, the proposed method consumes only 44.3% training resources of UniAD and runs $3.4\times$3.4× faster in inference when employing the same backbone network. Our innovative design not only for the first time demonstrates unarguable performance advantages over supervised counterparts, but also enjoys unprecedented efficiency in data, training, and inference.
More Related Videos
 07:46
Author Spotlight: Revolutionizing Remote Surgery with Augmented Reality and Robotics for Enhanced Precision and Accessibility
Published on: August 9, 2024
 05:47
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Related Concept Videos
 01:20
Internal Combustion Engine
 01:14
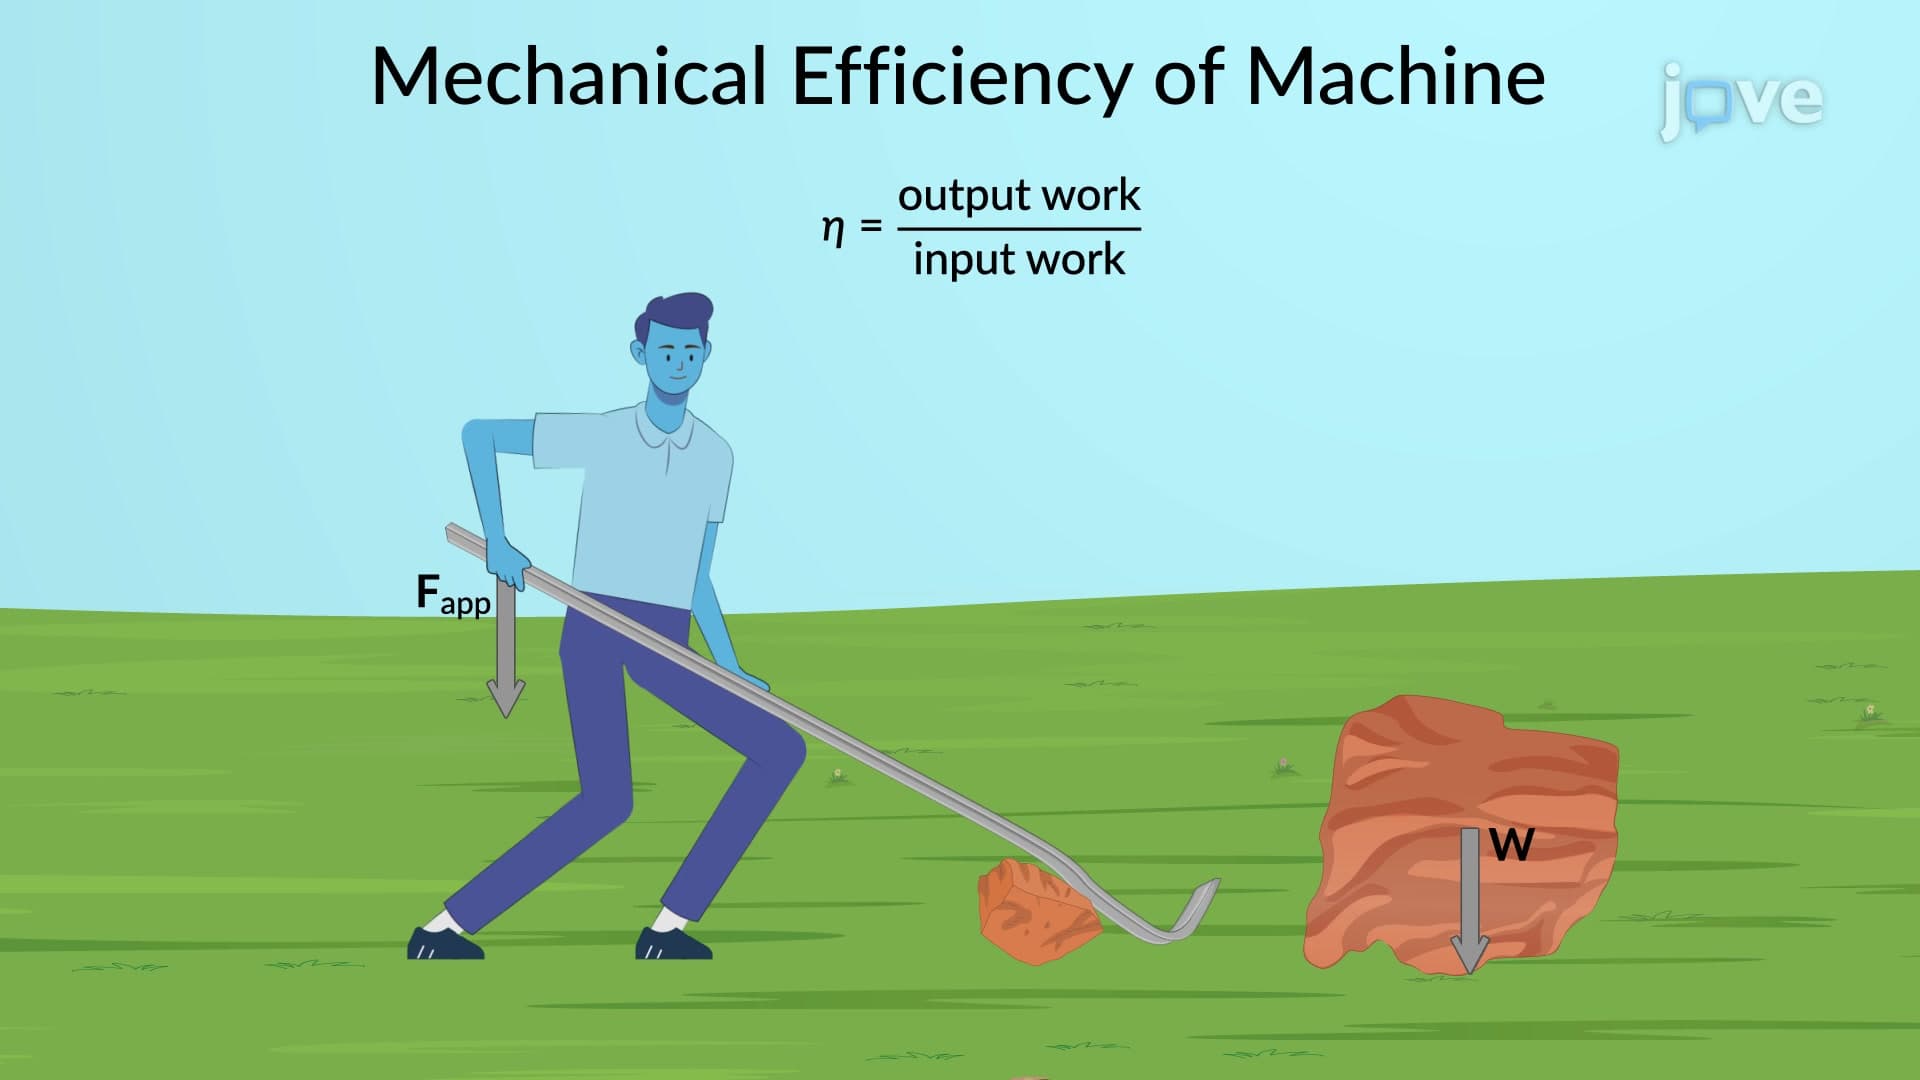
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:14
Design Example: Automobile Ignition System
One can generate a large voltage using a car battery of 12 volts with the help of inductors. Inductors are known for opposing rapid...
 01:22
Mechanical Systems
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...