Related Experiment Video
Updated: Jan 16, 2026
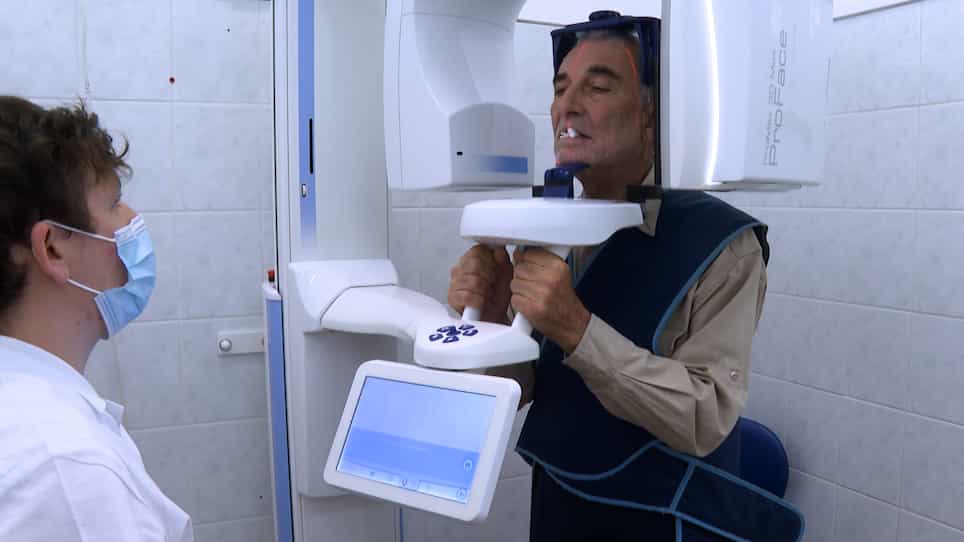

Dynamic Navigation for Dental Implant Placement
Published on: September 13, 2022
Real-Time Motion Compensation for Dynamic Dental Implant Surgery
Daria Pisla1, Vasile Bulbucan2, Mihaela Hedeșiu1
1Department of Maxillofacial Surgery and Radiology, Oral Radiology, "Iuliu Hatieganu" University of Medicine and Pharmacy, 400006 Cluj-Napoca, Romania.

Abstract:
Background: Accurate and stable instrument positioning is critical in dental implant procedures, particularly in anatomically constrained regions. Conventional navigation systems assume a static patient head, limiting adaptability in dynamic surgical conditions. This study proposes and validates a real-time motion compensation framework that integrates optical motion tracking with a collaborative robot to maintain tool alignment despite patient head movement. Methods: A six-camera OptiTrack Prime 13 system tracked rigid markers affixed to a 3D-printed human head model. Real-time head pose data were streamed to a Kuka LBR iiwa robot, which guided the implant handpiece to maintain alignment with a predefined target. Motion compensation was achieved through inverse trajectory computation and second-order Butterworth filtering to approximate realistic robotic response. Controlled experiments were performed using the MAiRA Pro M robot to impose precise motion patterns, including pure rotations (±30° at 10-40°/s), pure translations (±50 mm at 5-30 mm/s), and combined sinusoidal motions. Each motion profile was repeated ten times to evaluate intra-trial repeatability and dynamic response. Results: The system achieved consistent pose tracking errors below 0.2 mm, tool center point (TCP) deviations under 1.5 mm across all motion domains, and an average latency of ~25 ms. Overshoot remained minimal, with effective damping during motion reversal phases. The robot demonstrated stable and repeatable compensation behavior across all experimental conditions. Conclusions: The proposed framework provides reliable real-time motion compensation for dental implant procedures, maintaining high positional accuracy and stability in the presence of head movement. These results support its potential for enhancing surgical safety and precision in dynamic clinical environments.
More Related Videos
 05:54
Real-Time Dynamic Navigation System for the Precise Quad-Zygomatic Implant Placement in a Patient with a Severely Atrophic Maxilla
Published on: October 18, 2021
 09:10
Digital Hybrid Model Preparation for Virtual Planning of Reconstructive Dentoalveolar Surgical Procedures
Published on: August 5, 2021