A projection-based inverse kinematic model for extensible continuum robots and hyper-redundant robots with an elbow joint
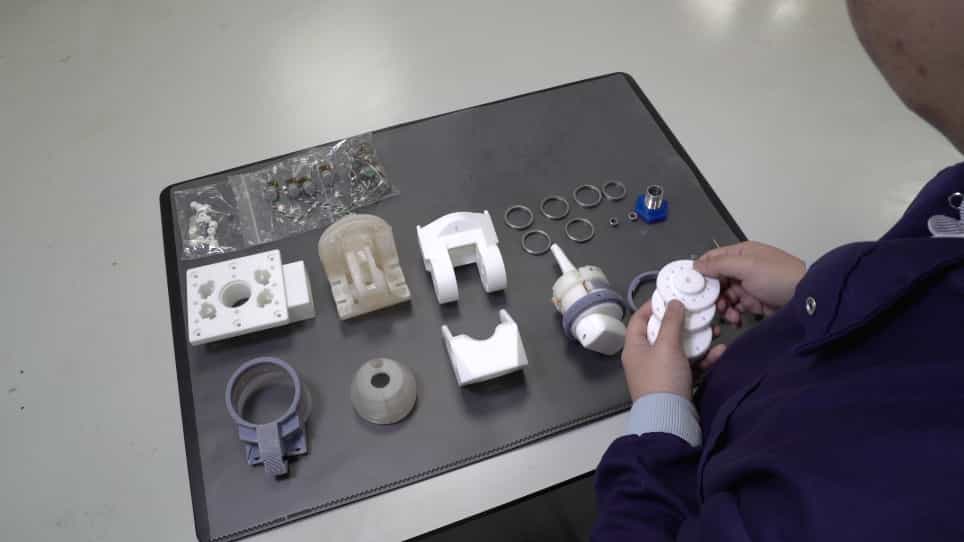
Related Experiment Video
Updated: Jan 16, 2026

Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Sven Fritsch1, Dirk Oberschmidt1
1Department of Mechanical Engineering and Transport Systems, Technical University, Berlin, Germany.

Abstract:
Inverse kinematics is a core problem in robotics, involving the use of kinematic equations to calculate the joint configurations required to achieve a target pose. This study introduces a novel inverse kinematic model (IKM) for extensible (i.e., length-adjustable) continuum robots (CRs) and hyper-redundant robots (HRRs) featuring an elbow joint. This IKM numerically solves a set of equations representing geometric constraints (abbreviated as NSGC). NSGC can handle target poses in 3D space, which are projected onto a 2D plane and solved numerically. NSGC is capable of real-time operation and accounts for elbow joint limits. Extensive simulations and empirical tests confirm the reliability, performance, and practical applicability of NSGC.

Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
 01:18
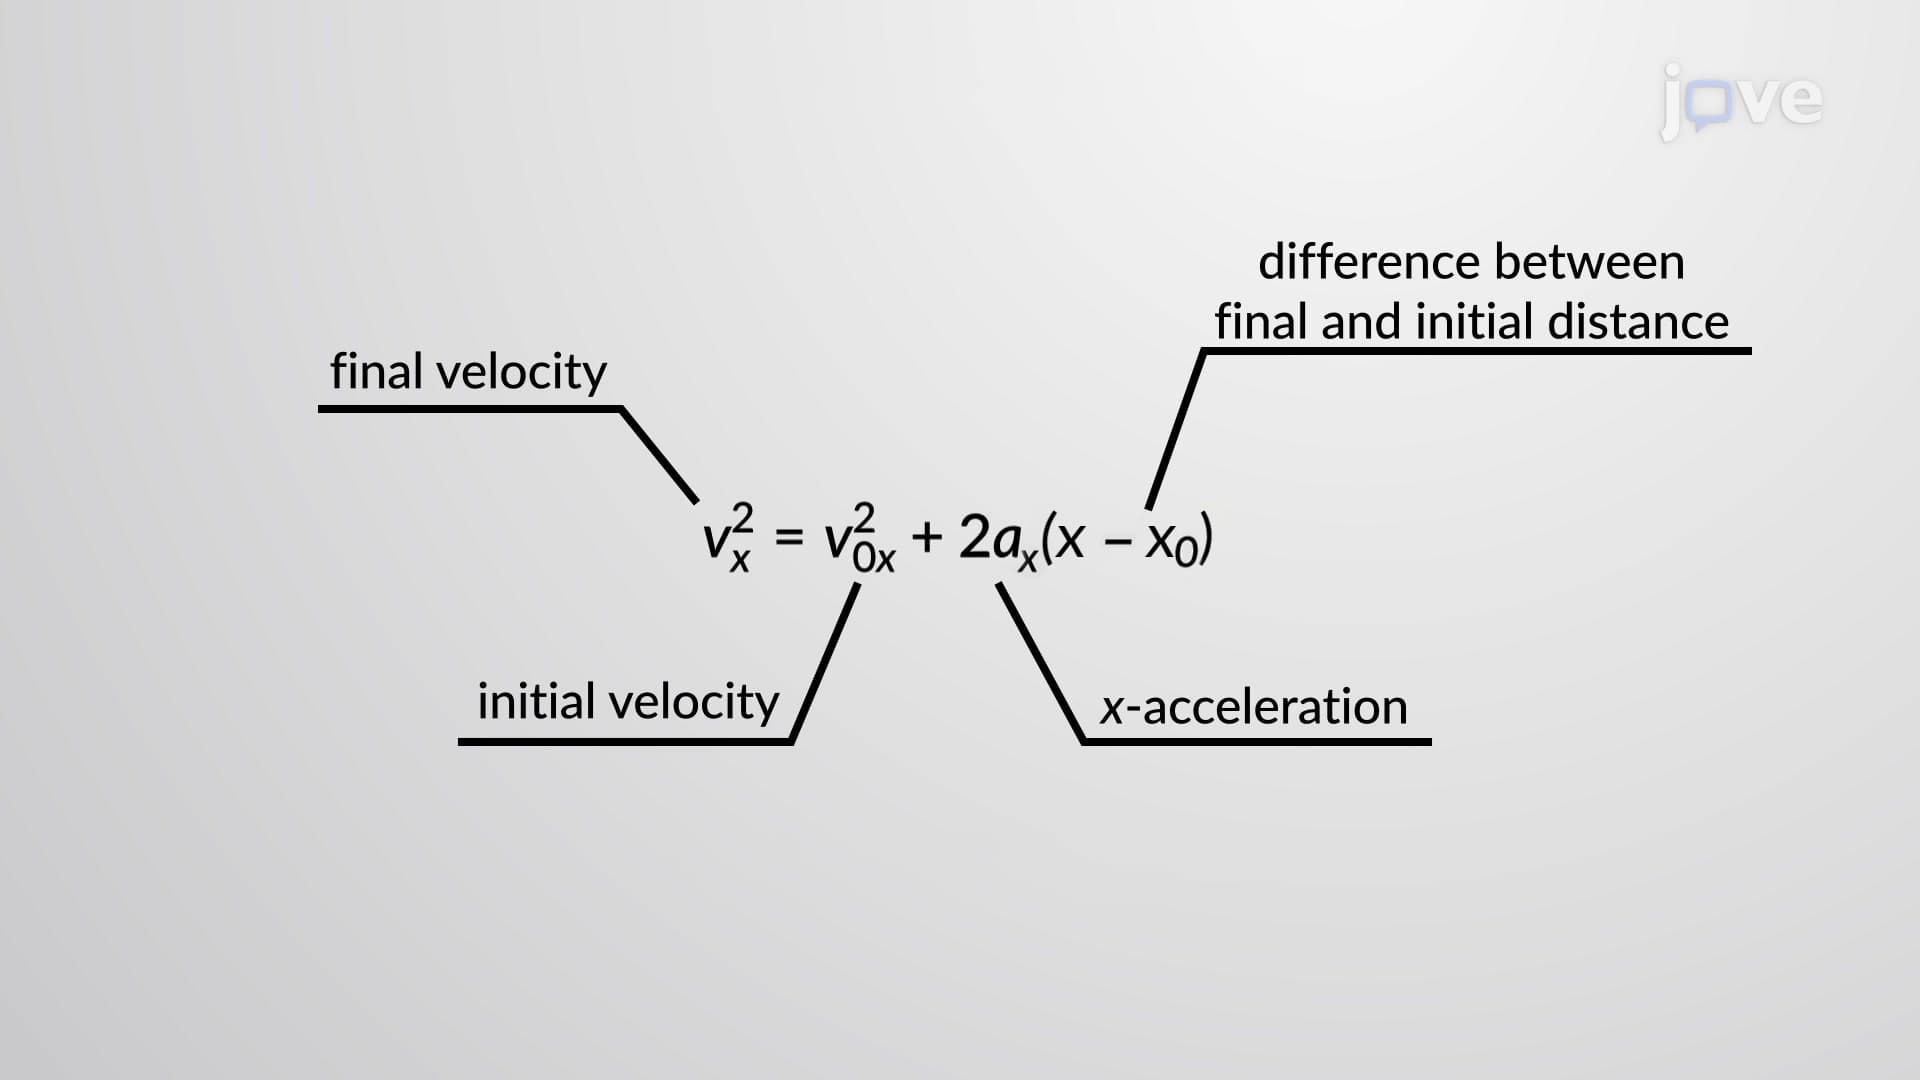
Kinematic Equations - III
Using the kinematic equations,...
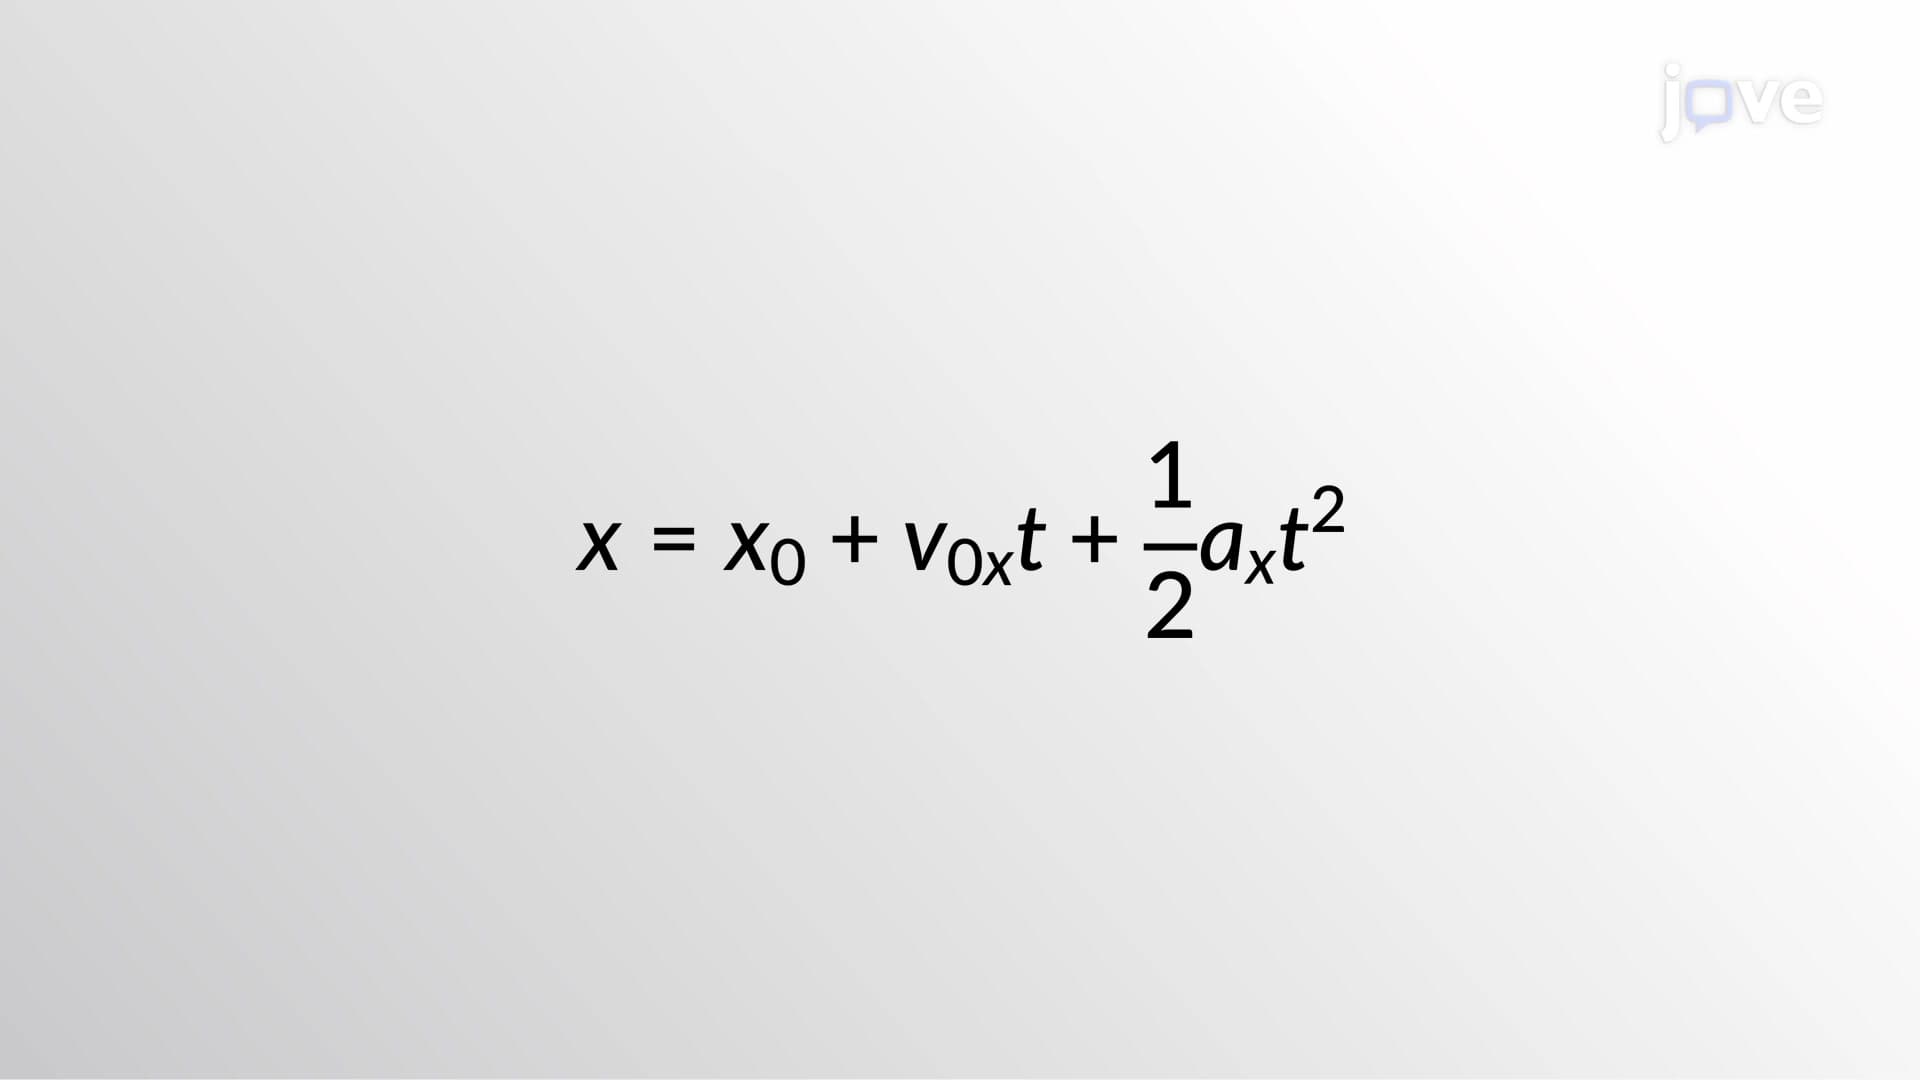 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
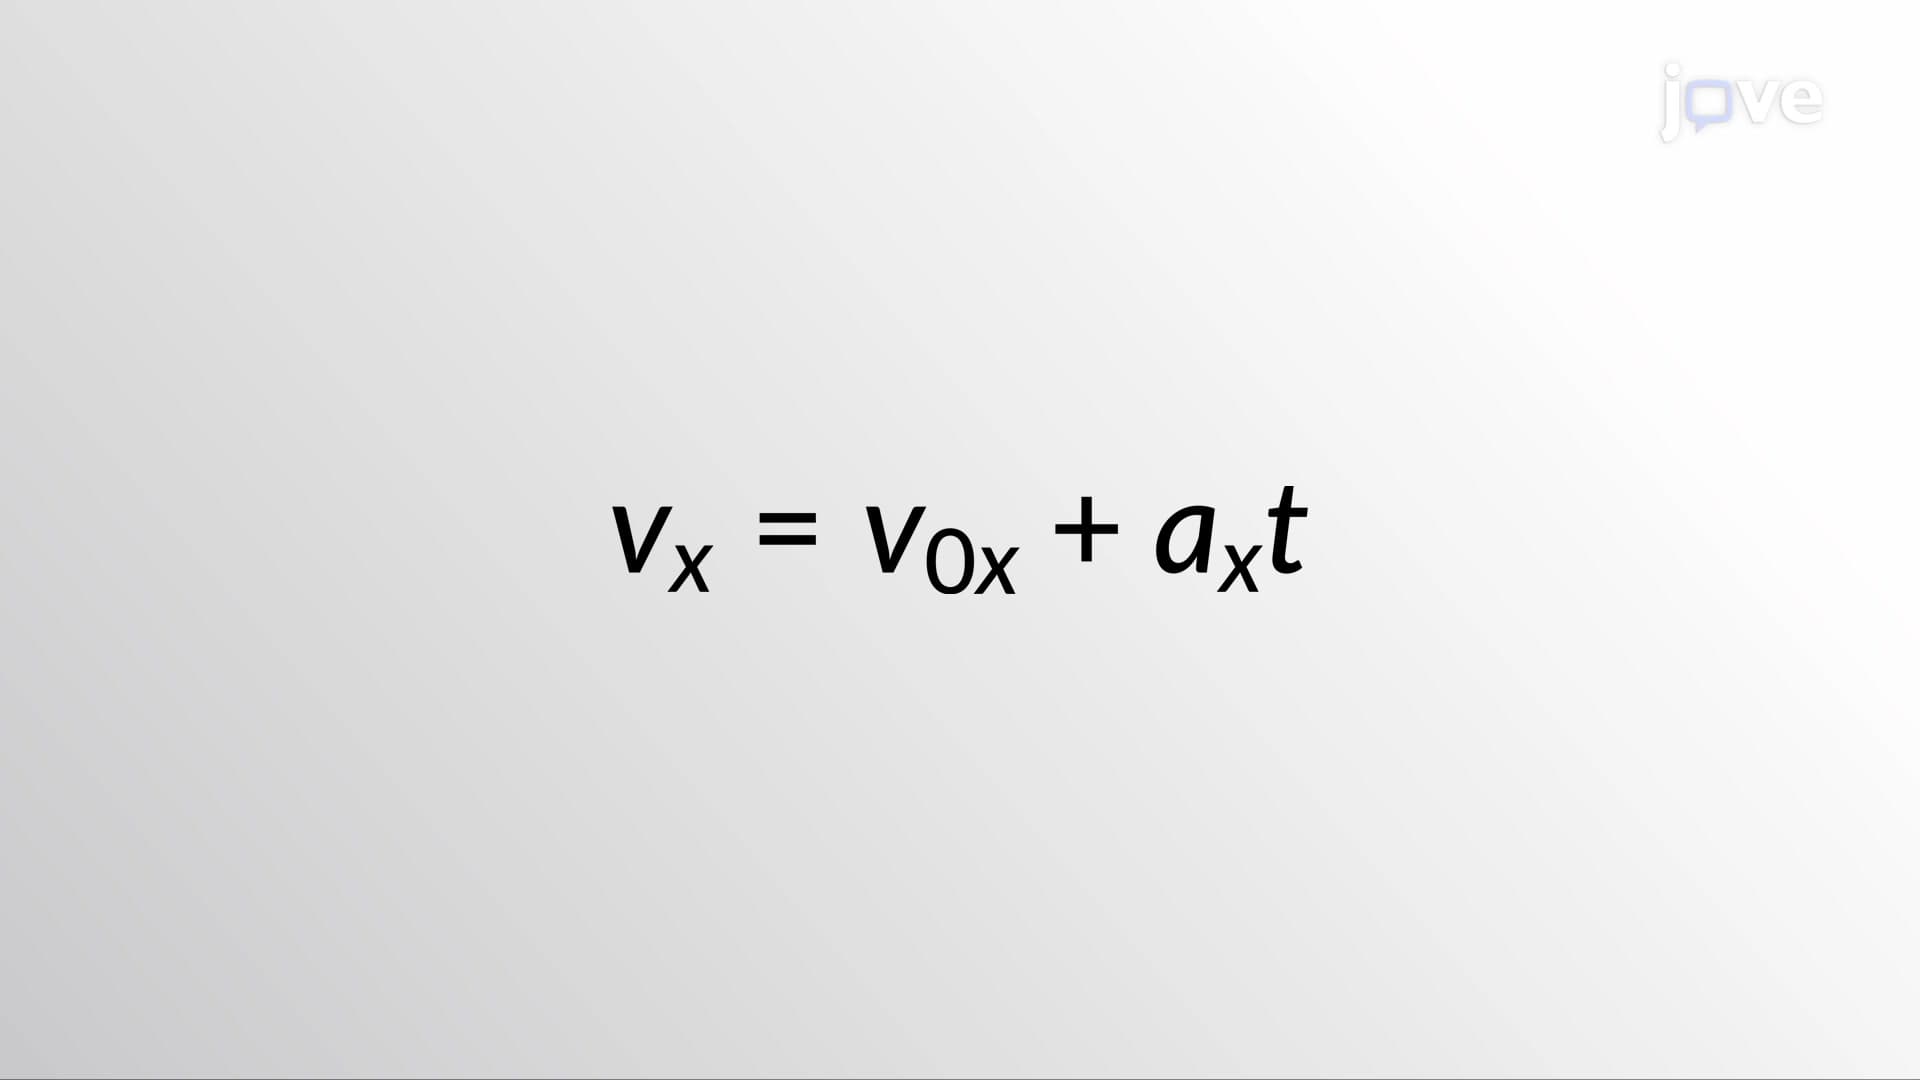 01:26
Kinematic Equations - I