Related Experiment Video
Updated: Jan 16, 2026

Methods for Measuring the Orientation and Rotation Rate of 3D-printed Particles in Turbulence
Published on: June 24, 2016
DePoint: Improving rotation robustness of 3D point cloud analysis via decreasing entropy
Lu Shi1, Gaoyun An2, Yigang Cen1
1State Key Laboratory of Advanced Rail Autonomous Operation, Beijing Jiaotong University, Beijing, 100044, China; School of Computer Science and Technology, Beijing Jiaotong University, Beijing, 100044, China; Visual Intellgence X International Cooperation Joint Laboratory of MOE, Beijing, 100044, China.

Abstract:
In real-world scenarios, achieving rotation robustness in point cloud analysis is crucial due to the unpredictable orientations of 3D objects. While recent advancements in rotation robustness typically rely on auxiliary modules to align rotated objects, precisely aligning object orientations remains challenging given the vast space of possible rotations. In this work, we investigate the impact of rotation on point clouds, revealing that random rotations significantly increase the joint entropy of point clouds and semantic labels-a key factor leading to degraded model performance on rotated datasets. To address this issue, we introduce DePoint, a simple yet effective rotation enhancement method that decreases entropy by aligning the spatial distribution of rotated point cloud representations with semantic information. Specifically, a Siamese point cloud encoder processes differently oriented views of an object with a shared task head, ensuring semantic consistency in the learned representations. A minimal auxiliary classifier enforces linear separability into these representations. Notably, DePoint can be seamlessly integrated into existing point cloud models without introducing additional parameters during inference. Experimental results demonstrate that DePoint significantly enhances the rotation robustness of various point cloud models in 3D object classification and segmentation.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:10
Entropy Change in Reversible Processes
The statement can be further generalized to prove that entropy is a state function. Take a cyclic process between any two points on a p-V diagram.
 01:16
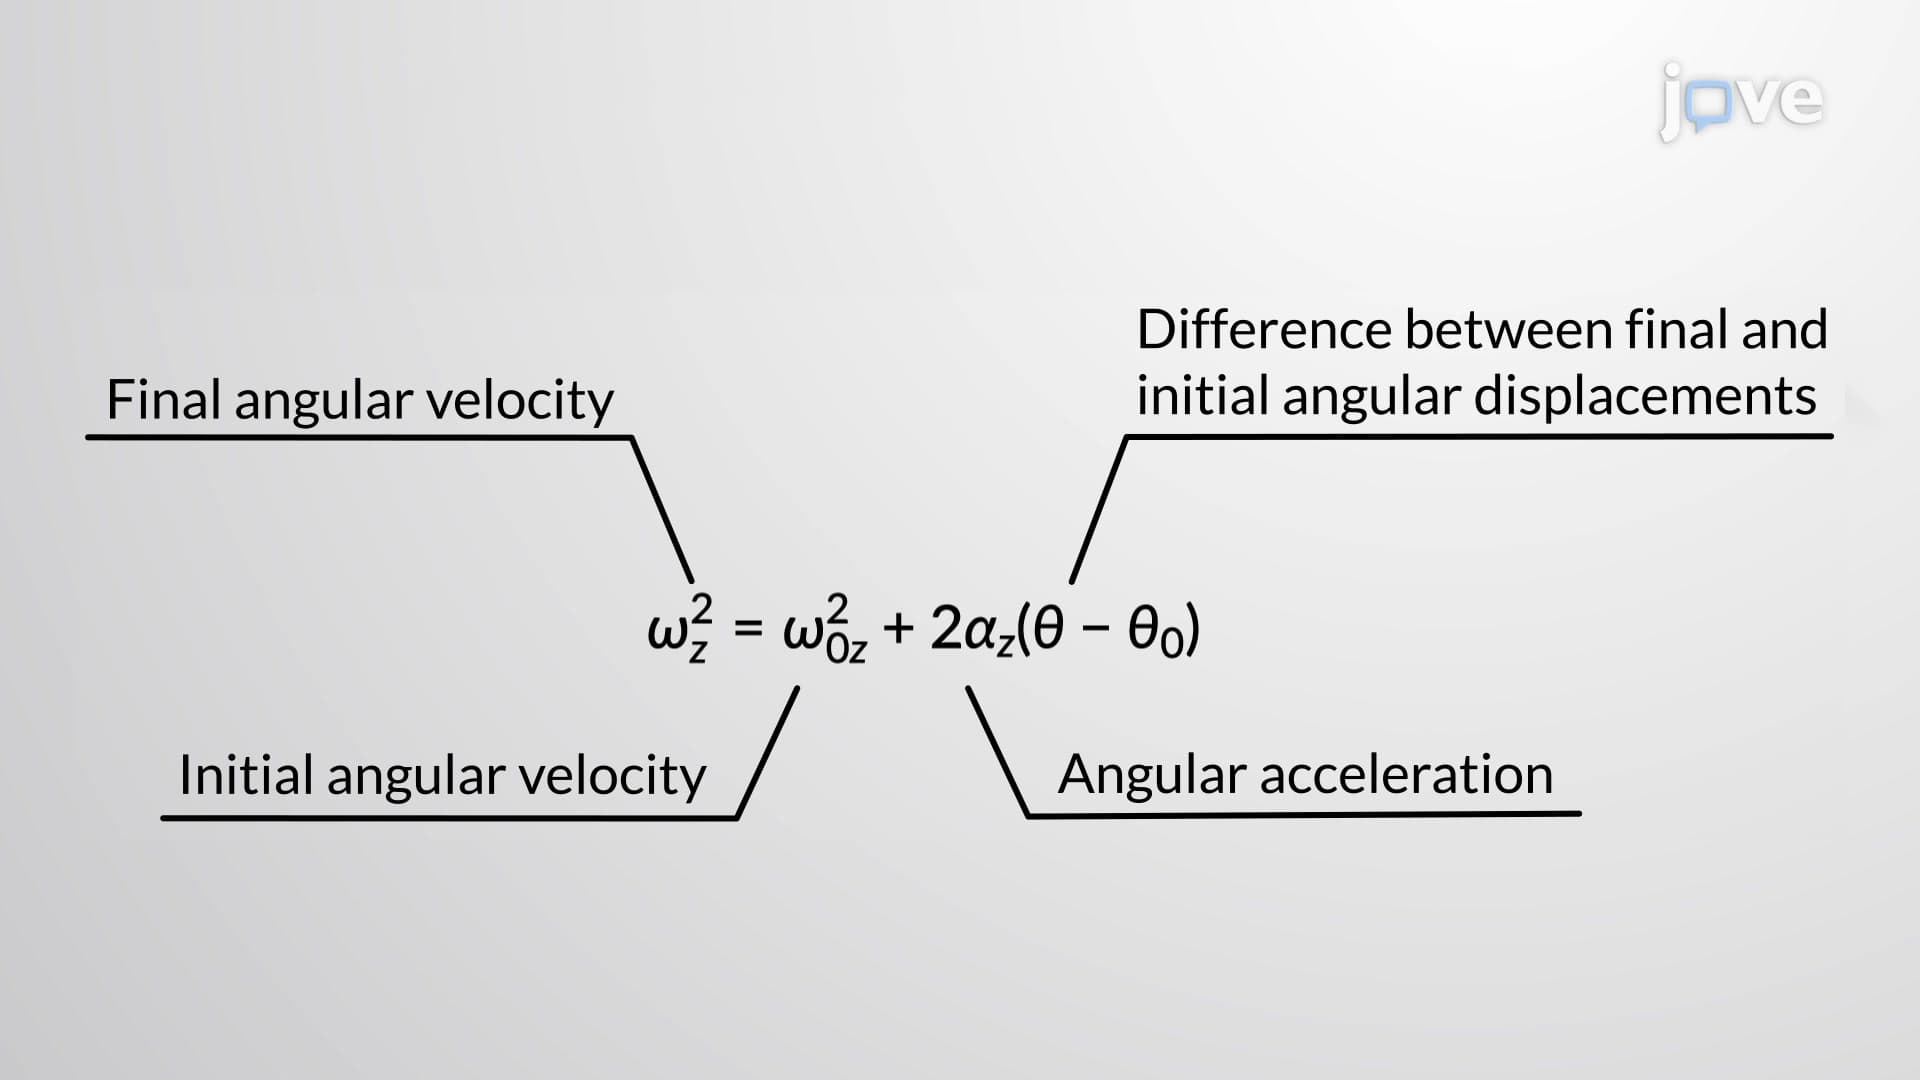
Rotation with Constant Angular Acceleration - II
The first...