Related Experiment Video
Updated: Jan 15, 2026

A System for Tracking the Dynamics of Social Preference Behavior in Small Rodents
Published on: November 21, 2019
Incomplete-Information Dynamic Stackelberg Equilibrium Seeking by A Distributed Distributionally Robust Feedback

Abstract:
This article investigates a multileader Stackelberg game where leaders lack critical information about the follower's objective function and face random disturbances with unknown distributions. Unlike conventional approaches requiring complete follower information, we consider leaders who manipulate physical plant states while observing the follower's strategy through private tracking responders. To address distributional uncertainty in the follower's best response, we reformulate the game as a distributionally robust equilibrium-seeking problem and develop a fully distributed feedback learning algorithm. The proposed data-driven approach operates without prior knowledge of system models or disturbance distributions, enabling leaders to estimate states through neighbor communication and local gradient updates. We characterize equilibrium existence in nonconvex settings. The relationship between communication and gradient errors and the energy function of the dynamic system is established. The upper bound of the regret based on the proposed algorithm is rigorously analyzed. A case study demonstrates the framework's effectiveness in achieving distributionally robust solutions against uncertain stochastic perturbations.

Related Concept Videos
 02:20
Dynamic Equilibrium
 01:13
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:59
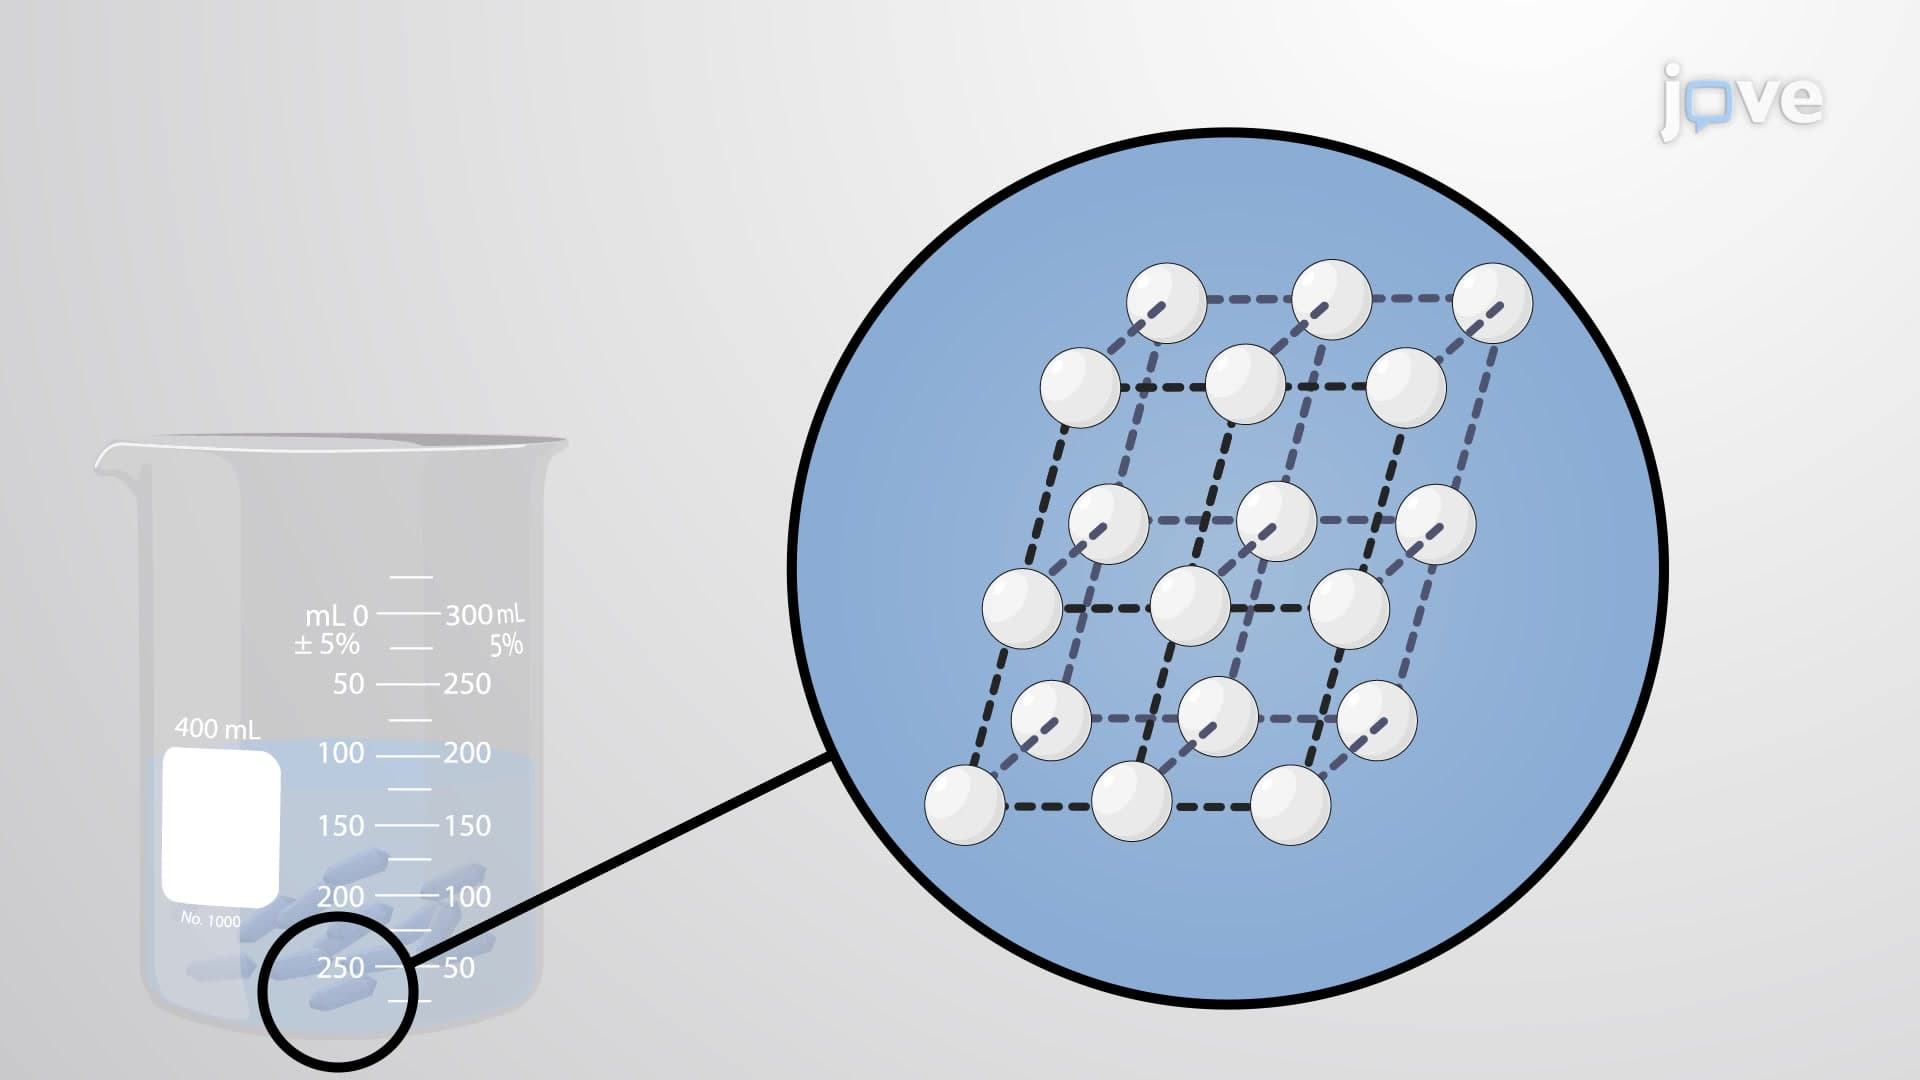
Solution Equilibrium and Saturation
 01:26
Equity Theory
 01:31
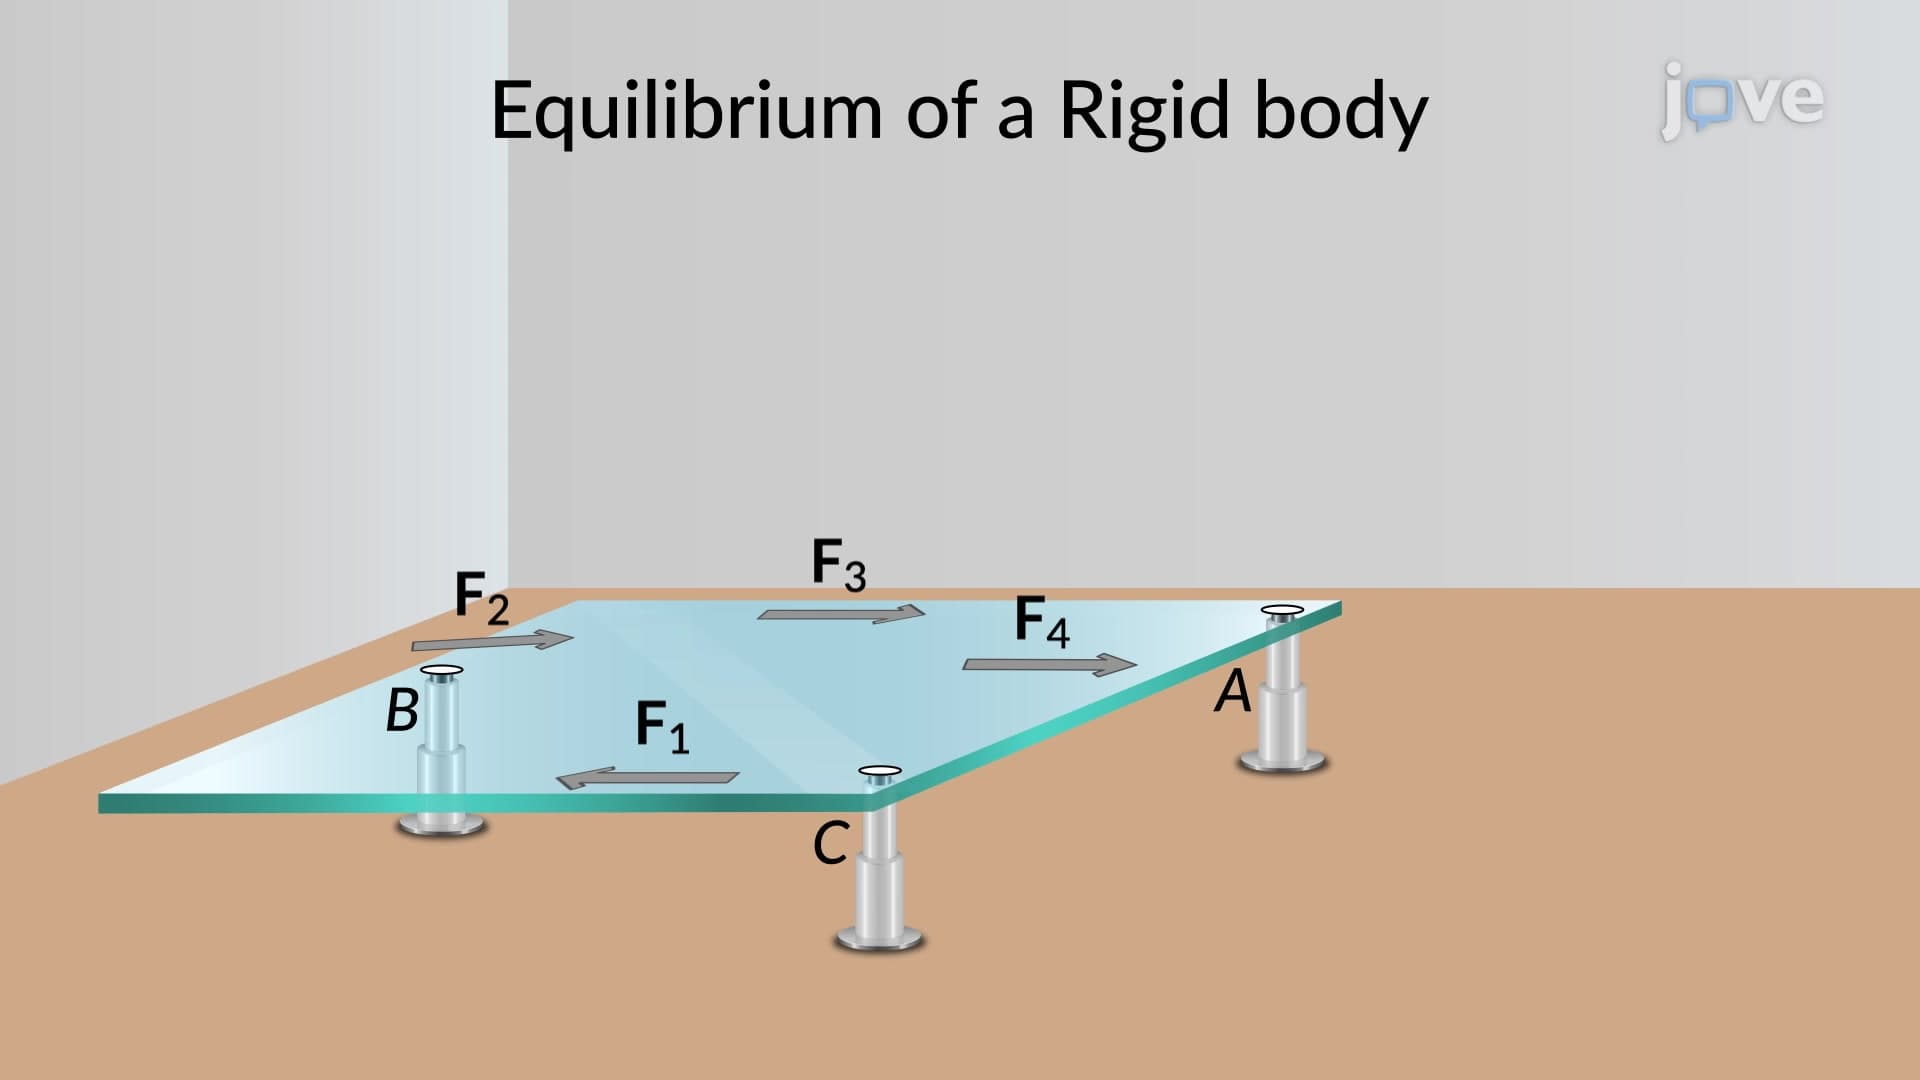
Alternative Sets of Equilibrium Equations
One example of such a situation can be observed in a...