Related Experiment Video
Updated: Jan 15, 2026


Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
T-S fuzzy approach for real-time vehicle state estimation and road safety enhancement
Mohamed Saber1, Mohamed Ouahi2, Saad Motahhir3
1Laboratory of Applied Sciences and Emerging Technologies, National School of Applied Sciences, BP 72, My Abdallah Avenue Km. 5 Imouzzer Road, Fez, Morocco. mohamed.saber1@usmba.ac.ma.

Abstract:
Safe driving requires a comprehension of critical instances and dangers, achievable only through accurate estimation of dynamic vehicle behavior and road characteristics. This study proposes a Takagi-Sugeno (T-S) fuzzy functional observer capable of real-time estimation of unmeasured states (side-slip angle, yaw rate, angular displacement) and unknown inputs such as road curvature, using Lyapunov-Krasovskii stability theory and Linear Matrix Inequalities (LMIs) for parameter design. The objective is to provide a computationally efficient and robust solution that overcomes the restrictive assumptions of Proportional-Multiple Integral Observers (PMIO) and the complexity of Fuzzy Unknown Input Observers (FUIO) while ensuring real-time feasibility for embedded automotive systems. Comparative simulations and Processor-in-the-Loop (PIL) validation demonstrated that the proposed observer achieved superior accuracy, faster convergence, and lower computational cost than Full-Order Observer (FO), PMIO, and FUIO, confirming its novelty and practical potential for integration into advanced driver assistance systems to enhance safety and reduce accident risks.


Related Concept Videos
 01:27
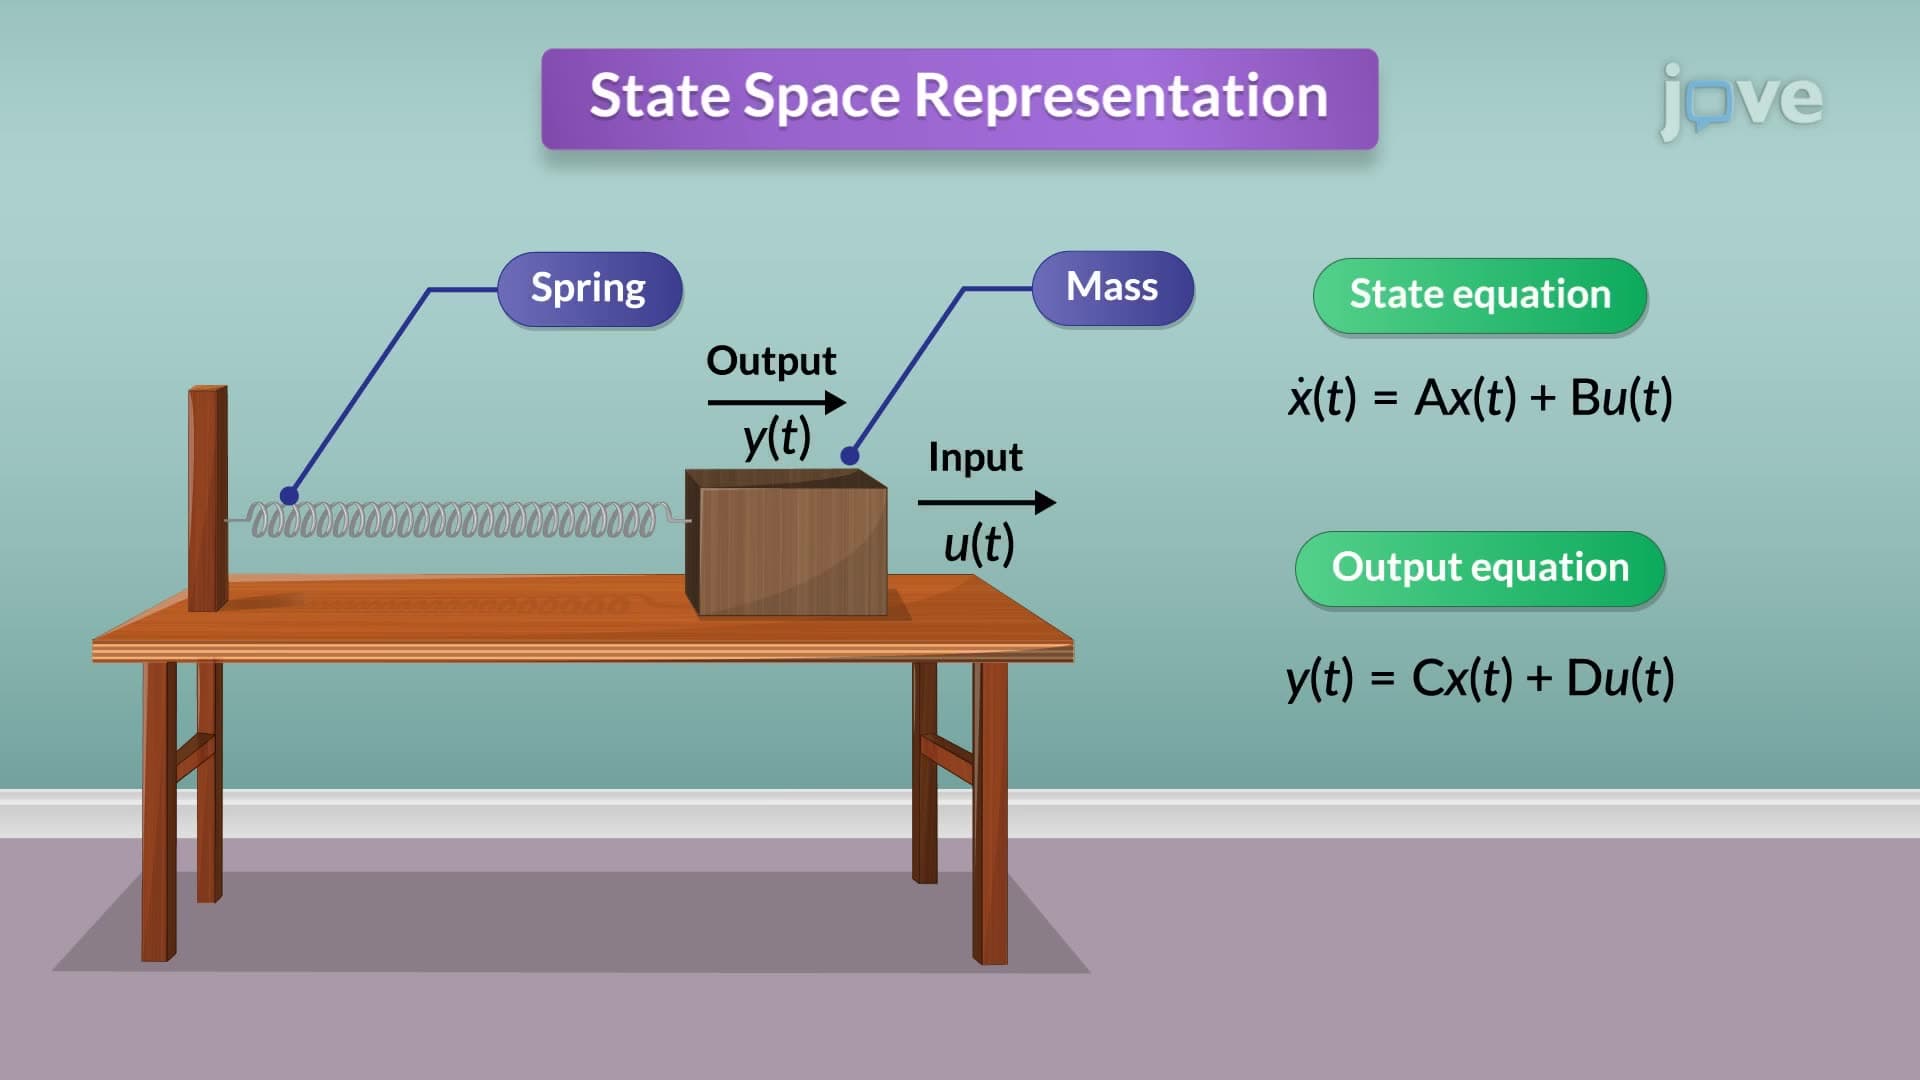
State Space Representation
Consider an RLC circuit, a...
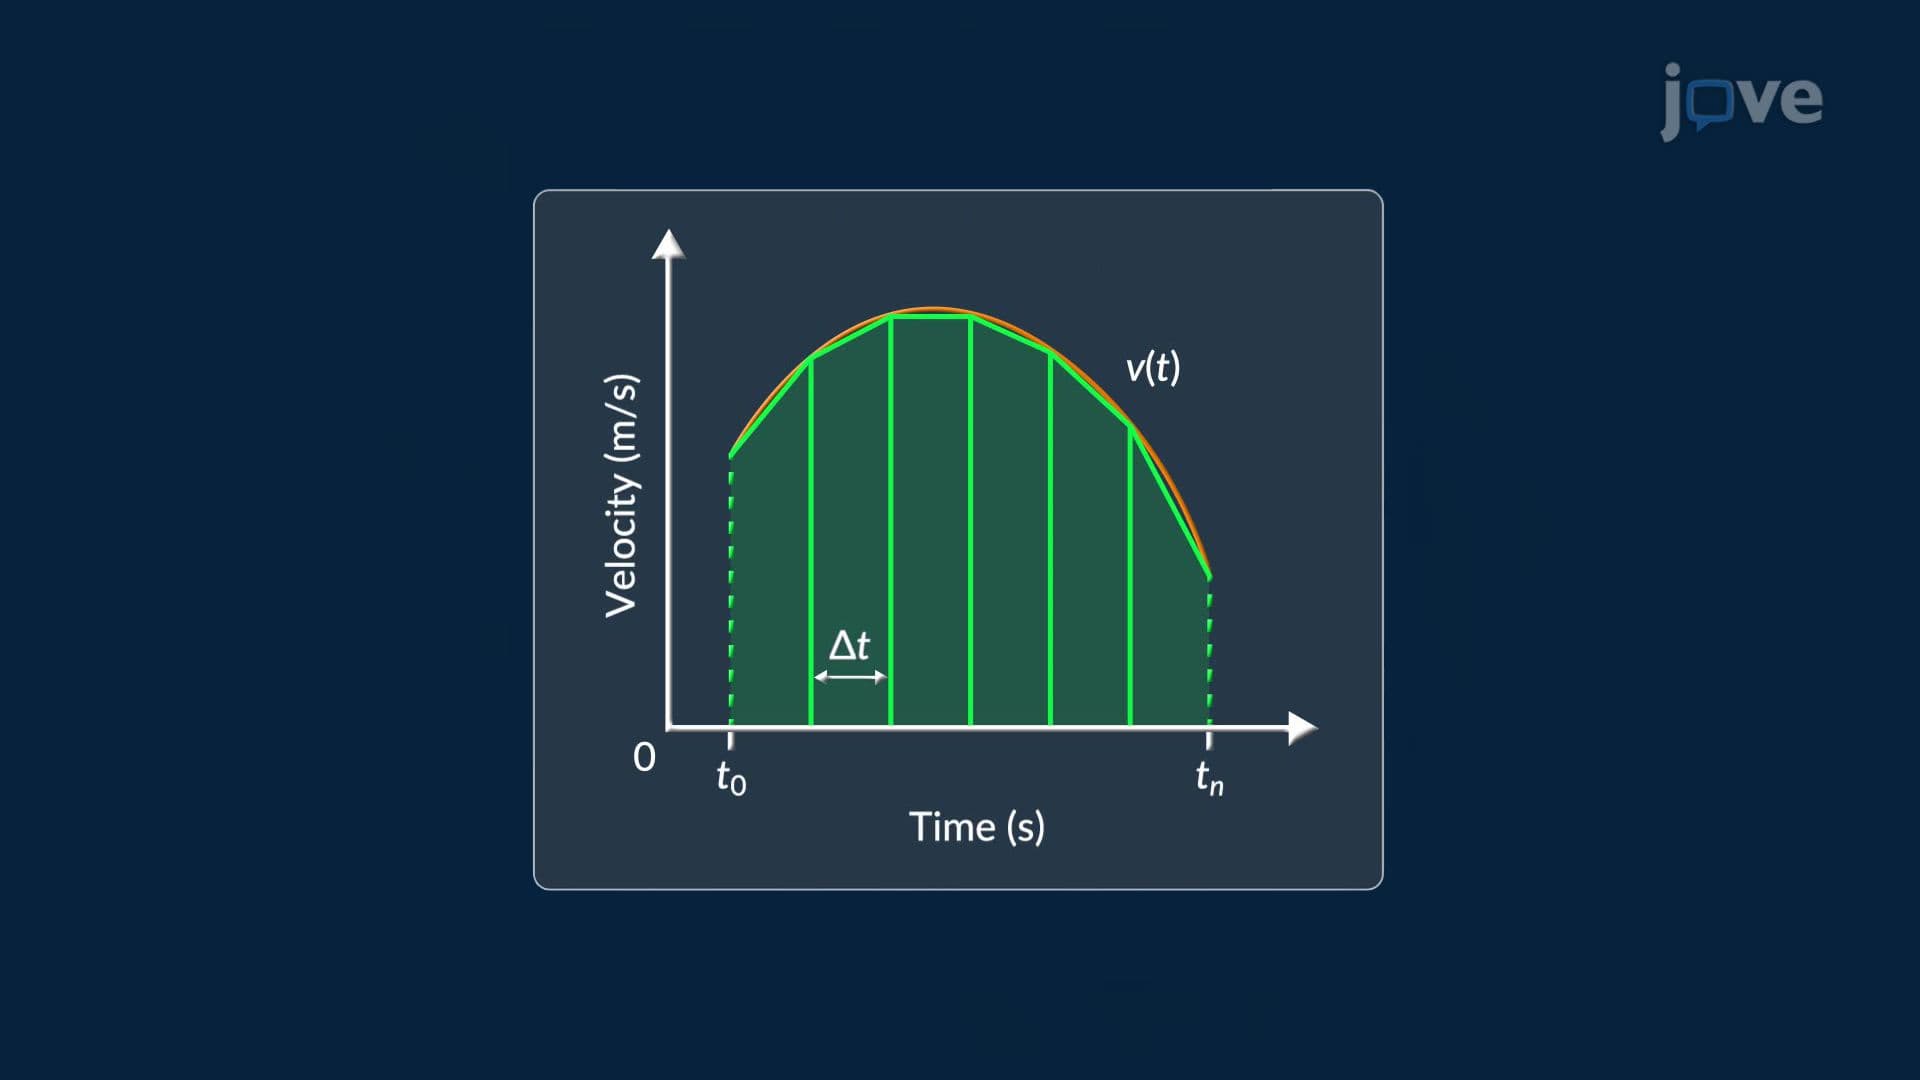 01:26
Trapezoidal Rule
 01:29
Sight Distance in a Vertical Curve
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:17
Design Example: Alignment of a Road Line Using GIS
 01:21
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: