Related Experiment Video
Updated: Jan 15, 2026


Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Adaptive neural network based leader-following consensus control for a class of second-order nonlinear multi-agent
Fathia Moh Al Samman1, Wajiha Abdul Khaliq2, Shreefa O Hilali3
1Department of Mathematics, College of Sciences, Northern Border University, Arar, Saudi Arabia.

Abstract:
The leader-following consensus problem for a type of second-order nonlinear multi-agent systems (MASs) with input saturation, actuator faults, and sensor faults is examined in this study. An adaptive control strategy based on neural networks (NNs) is suggested to overcome the difficulties brought on by unknown nonlinear dynamics and real-world limitations. To handle the unknown nonlinear factors more precisely and flexibly than traditional approaches that depend on global Lipschitz requirements, we use the differential mean value theorem. This improvement enhances the system's capacity to deal with nonlinear behaviors that change quickly. Additionally, sensor faults that affect location and velocity readings and actuator faults that may decrease or deform the input signal are taken into consideration in the control design. The suggested design also clearly addresses input saturation, which may restrict the control authority. Complete state measurements are not required because a distributed adaptive NN-based controller is created only on relative location and velocity data. Using stability theory and appropriate Lyapunov function construction, we rigorously demonstrate that the suggested approach leads to leader-following consensus. The efficiency and resilience of the suggested control strategy against nonlinear uncertainty, actuator and sensor failures, and saturation effects in complicated multi-agent networks are confirmed by simulation results.

Related Concept Videos
 01:18
Second Order systems II
 01:22
Multi-input and Multi-variable systems
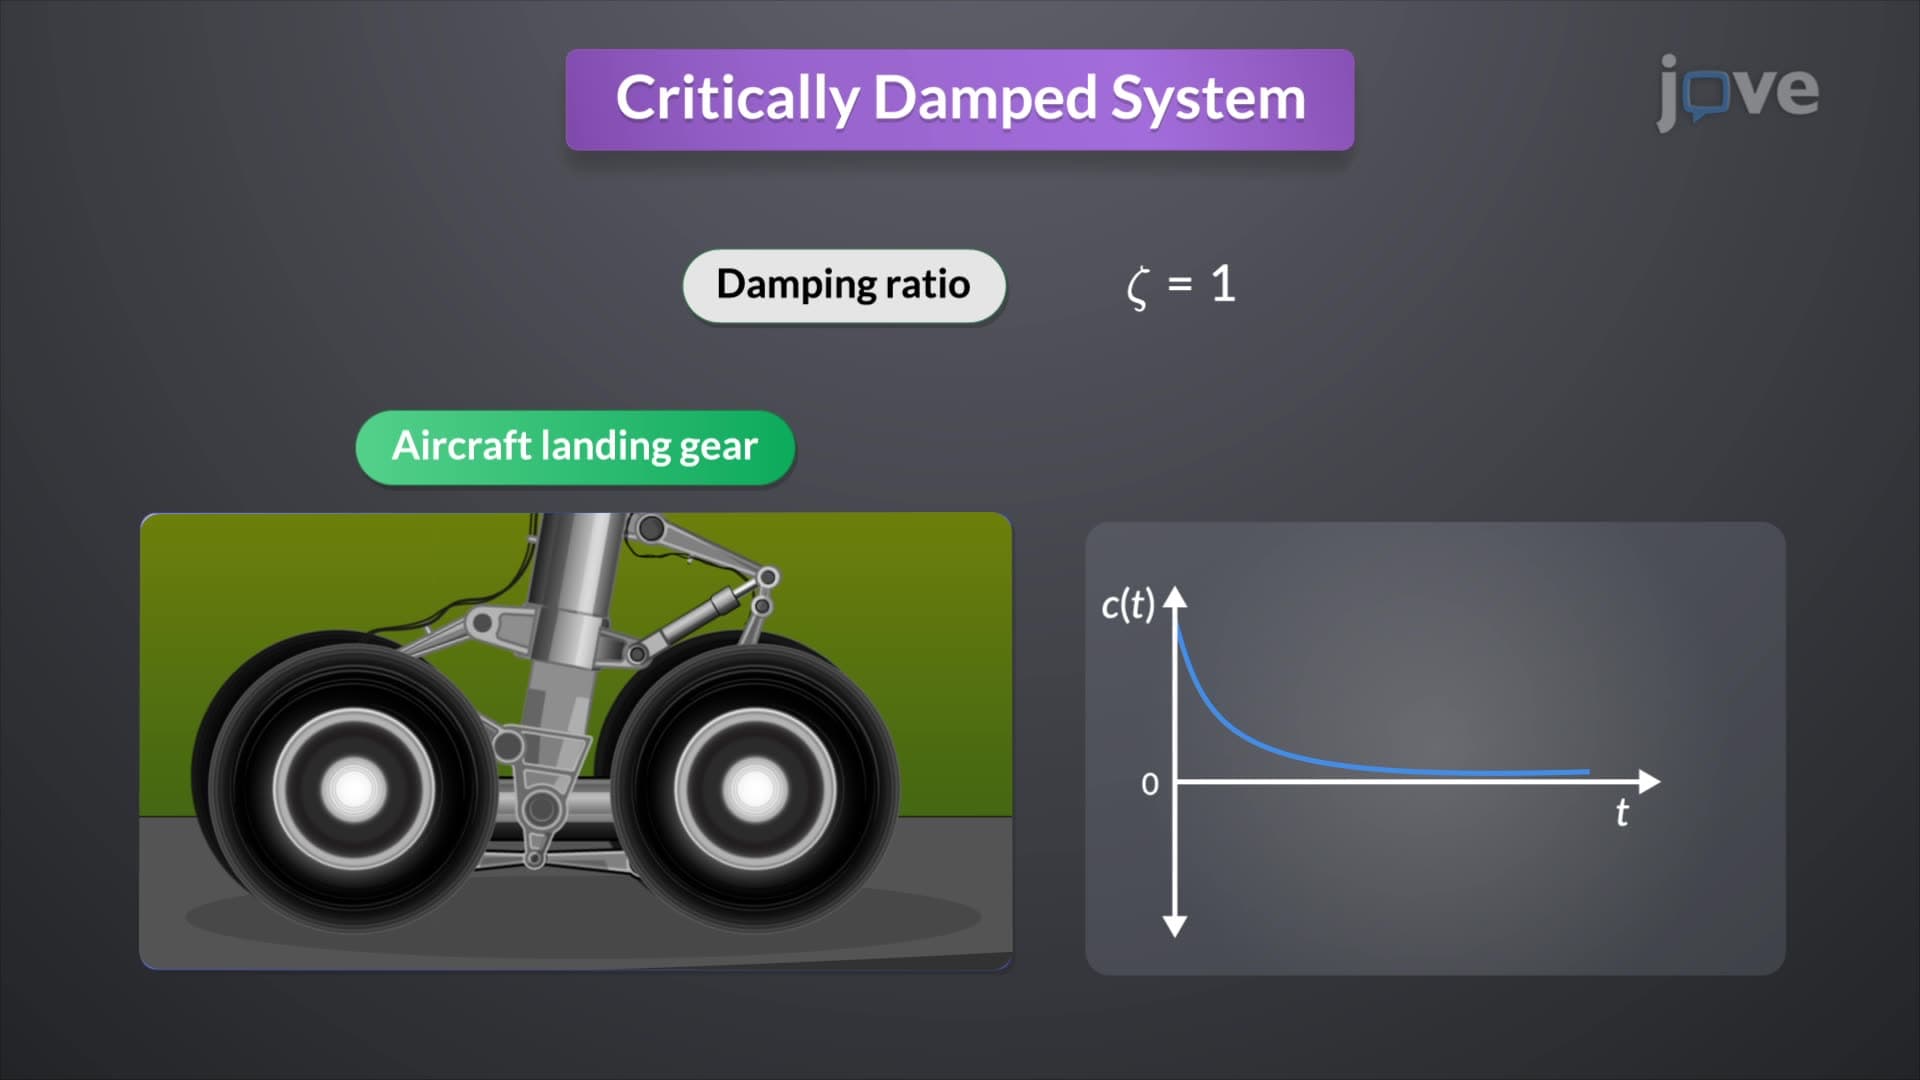
In the absence of...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:13
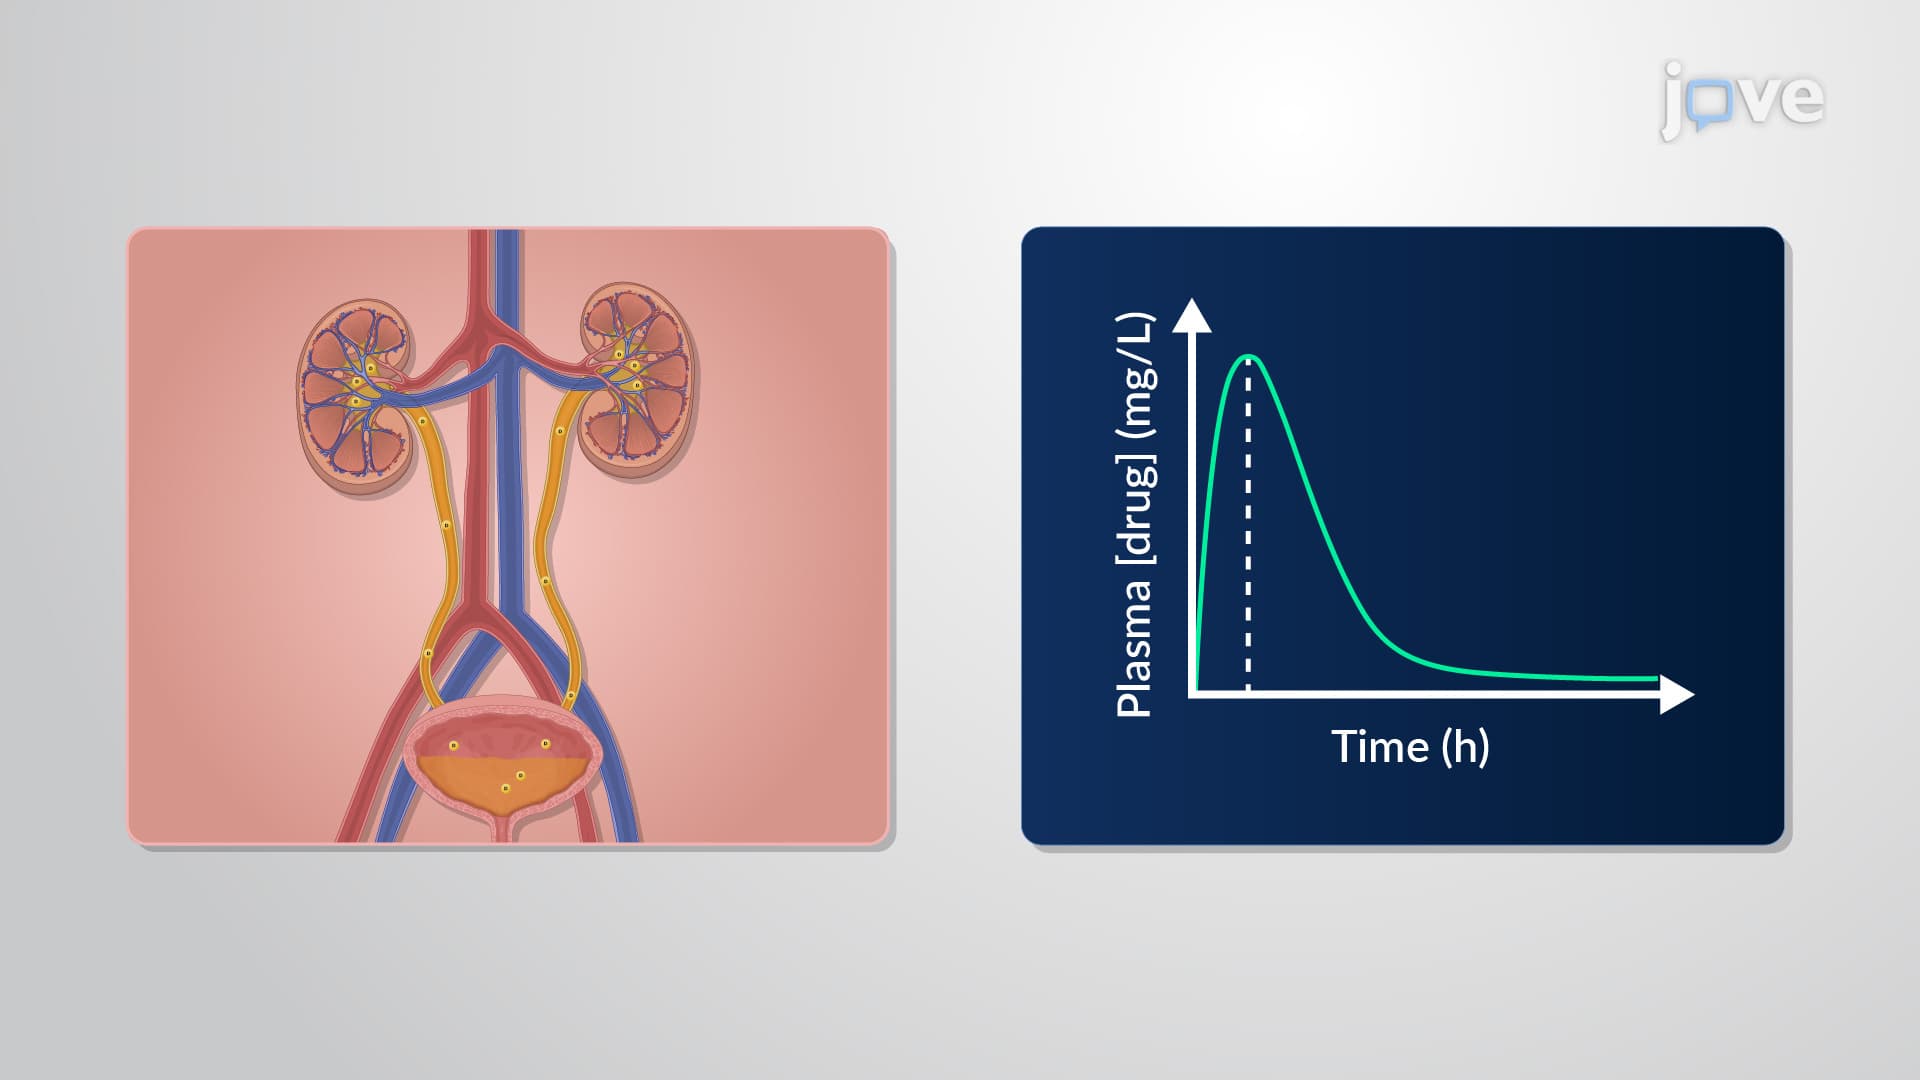
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...