Related Experiment Video
Updated: Jan 15, 2026

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Autonomous Concrete Crack Monitoring Using a Mobile Robot with a 2-DoF Manipulator and Stereo Vision Sensors
Seola Yang1, Daeik Jang2, Jonghyeok Kim3
1Department of Civil and Environmental Engineering, Hanbat National University, Daejeon 34158, Republic of Korea.

Abstract:
Crack monitoring in concrete structures is essential to maintaining structural integrity. Therefore, this paper proposes a mobile ground robot equipped with a 2-DoF manipulator and stereo vision sensors for autonomous crack monitoring and mapping. To facilitate crack detection over large areas, a 2-DoF motorized manipulator providing linear and rotational motions, with a stereo vision sensor mounted on the end effector, was deployed. In combination with a manual rotation plate, this configuration enhances accessibility and expands the field of view for crack monitoring. Another stereo vision sensor, mounted at the front of the robot, was used to acquire point cloud data of the surrounding environment, enabling tasks such as SLAM (simultaneous localization and mapping), path planning and following, and obstacle avoidance. Cracks are detected and segmented using the deep learning algorithms YOLO (You Only Look Once) v6-s and SFNet (Semantic Flow Network), respectively. To enhance the performance of crack segmentation, synthetic image generation and preprocessing techniques, including cropping and scaling, were applied. The dimensions of cracks are calculated using point clouds filtered with the median absolute deviation method. To validate the performance of the proposed crack-monitoring and mapping method with the robot system, indoor experimental tests were performed. The experimental results confirmed that, in cases of divided imaging, the crack propagation direction was predicted, enabling robotic manipulation and division-point calculation. Subsequently, total crack length and width were calculated by combining reconstructed 3D point clouds from multiple frames, with a maximum relative error of 1%.

Related Concept Videos
 01:20
Microcracking in Concrete
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:28
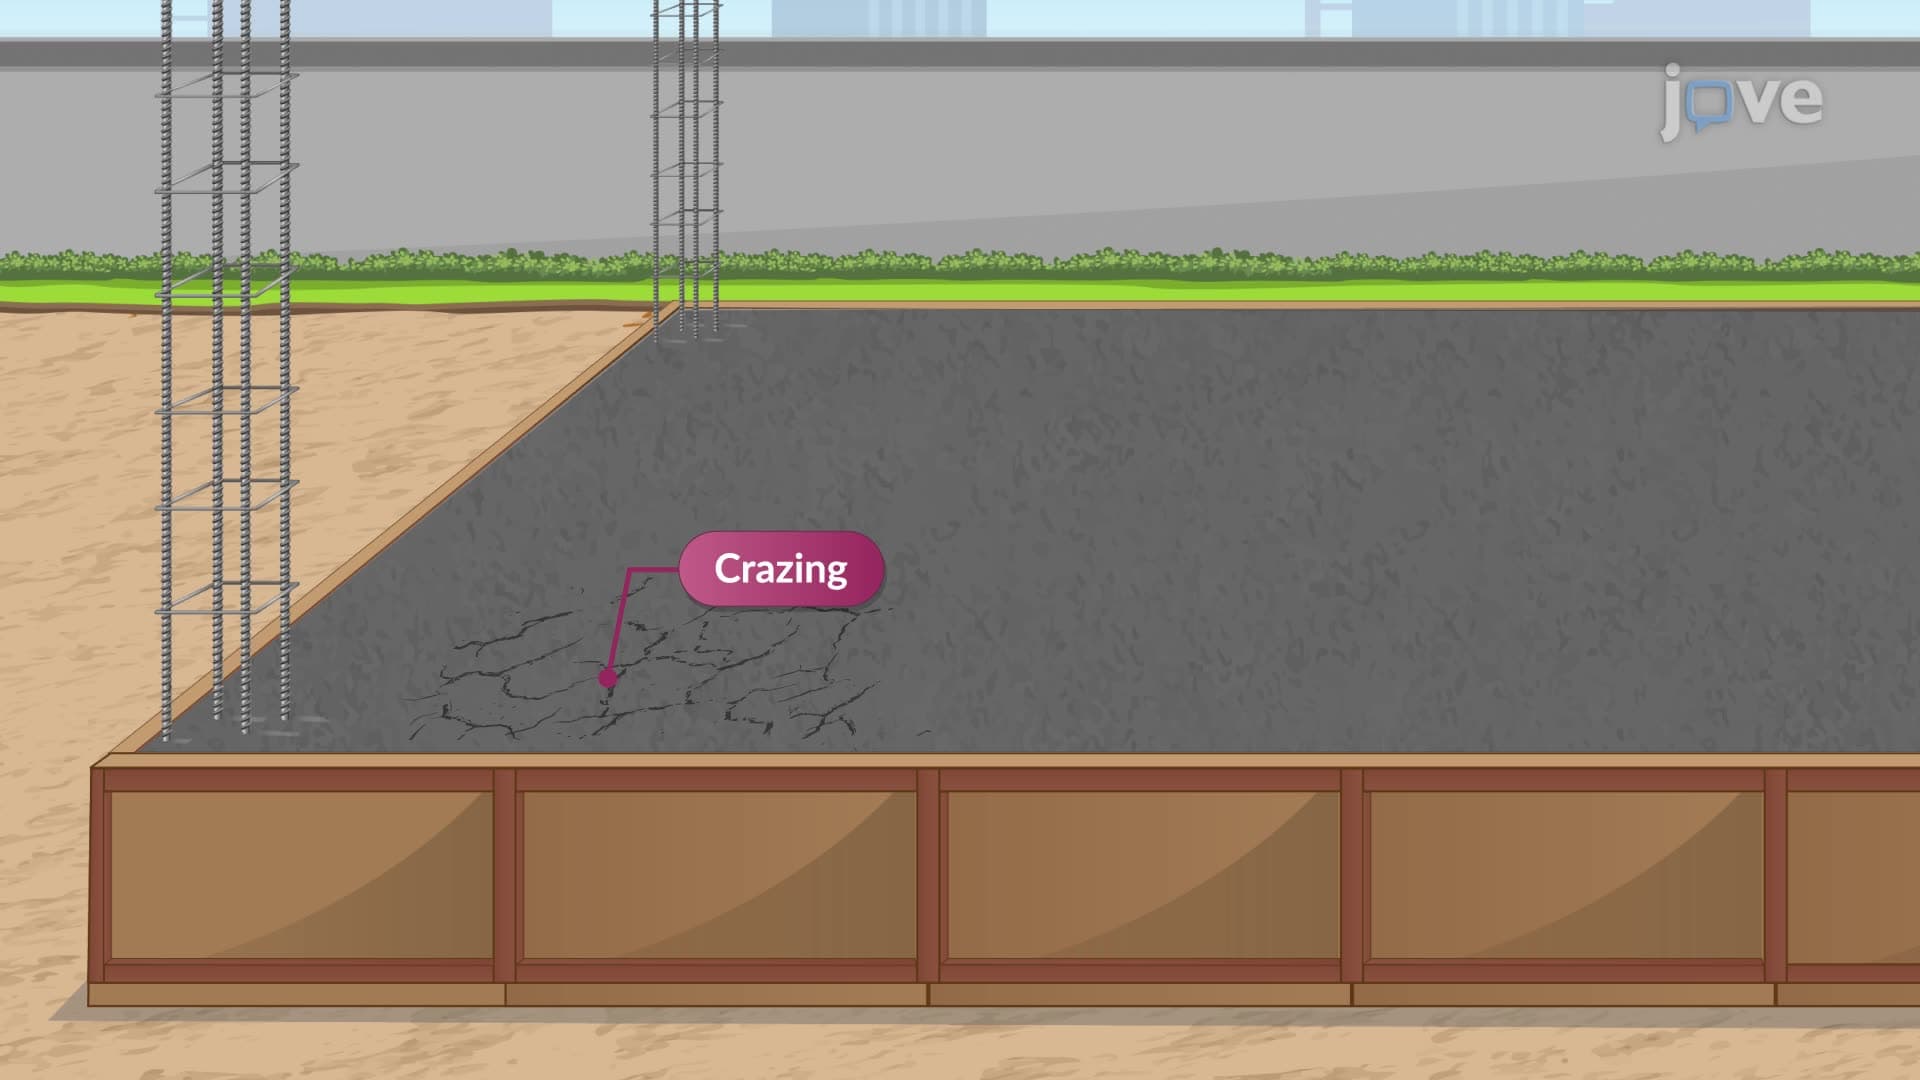
Types of Non-structural Cracks in Concrete
Plastic shrinkage cracks typically form within hours after the concrete is poured. The concrete's surface dries faster than the bottom, creating tensile stress that the still-plastic concrete cannot withstand, leading to diagonal or randomly patterned cracks on the concrete surface.
 01:19
Vibrating Concrete