Related Experiment Video
Updated: Aug 13, 2026
Evaluation of Patients' Posture and Gait Profile After Lumbar Fusion Surgery by Video Rasterstereography and Treadmill Gait Analysis
Published on: March 23, 2019
Kinematic and mechanical assessment of seated lumbar rotation manipulation: force, velocity and orientation in three
Changxiao Han1, Jiali Chen2, Jinghua Gao1
1Wangjing Hospital, China Academy of Chinese Medical Sciences, Beijing, China.

Background:
Seated lumbar rotation manipulation is widely used for low back pain, but lacks detailed biomechanical analysis. Understanding its biomechanical characteristics is crucial for therapists to improve comprehension and support education and research. The purpose of this study was to analyze the kinematic and mechanical parameters of Seated lumbar rotation manipulation.
Methods:
Sixty healthy volunteers underwent manipulation by experienced therapists. Three-dimensional movements, thrust velocity, and acceleration were measured using motion capture technology. Force parameters were recorded using pressure sensing gloves mounted on the therapist's hands. Subgroup comparisons were conducted based on body mass index, and linear regression was used to analyse the relationship between force parameters and BMI (Body Mass Index). Finally, Pearson's correlation test was employed to examine the correlation between the forces exerted by both hands during each procedure.
Results:
Kinematic analysis indicated that the angles in three directions were greatest for rotation, followed by lateral bending and flexion. Similarly, rotation was the dominant angular velocities, greater than lateral flexion and anteflexion. Furthermore, Preload duration (2.72 ± 0.10 s) and thrust duration (0.48 ± 0.04 s) were recorded. In terms of force, four key force metrics were calculated: preload force (58.99 ± 9.76 N), valley force (23.25 ± 6.24 N), thrust force (50.54 ± 9.63 N), and peak force (73.77 ± 11.06 N). While the preload rate (21.73 ± 4.66 N/s), thrust rate (106.30 ± 11.72 N/s), and the maximum torque (51.86 ± 7.52 N m) were determined. Subgroup analysis showed significant differences in force parameters by body types (P < 0.01). Linear regression revealed a positive correlation between BMI and force parameters (P < 0.05), and Pearson analysis indicated a significant correlation between forces exerted by both hands (P < 0.05).
Conclusion:
Seated lumbar rotation manipulation is characterized by long-lever, three-dimensional coupled movements with high-velocity, low-amplitude thrusts. Additionally, the force parameters are positively influenced by somatotype, and bilateral hand force exerts a synergistic effect. This valuable biomechanical quantification help comprehending the technique and supporting its educational and experimental settings.
More Related Videos
Related Concept Videos
 01:30
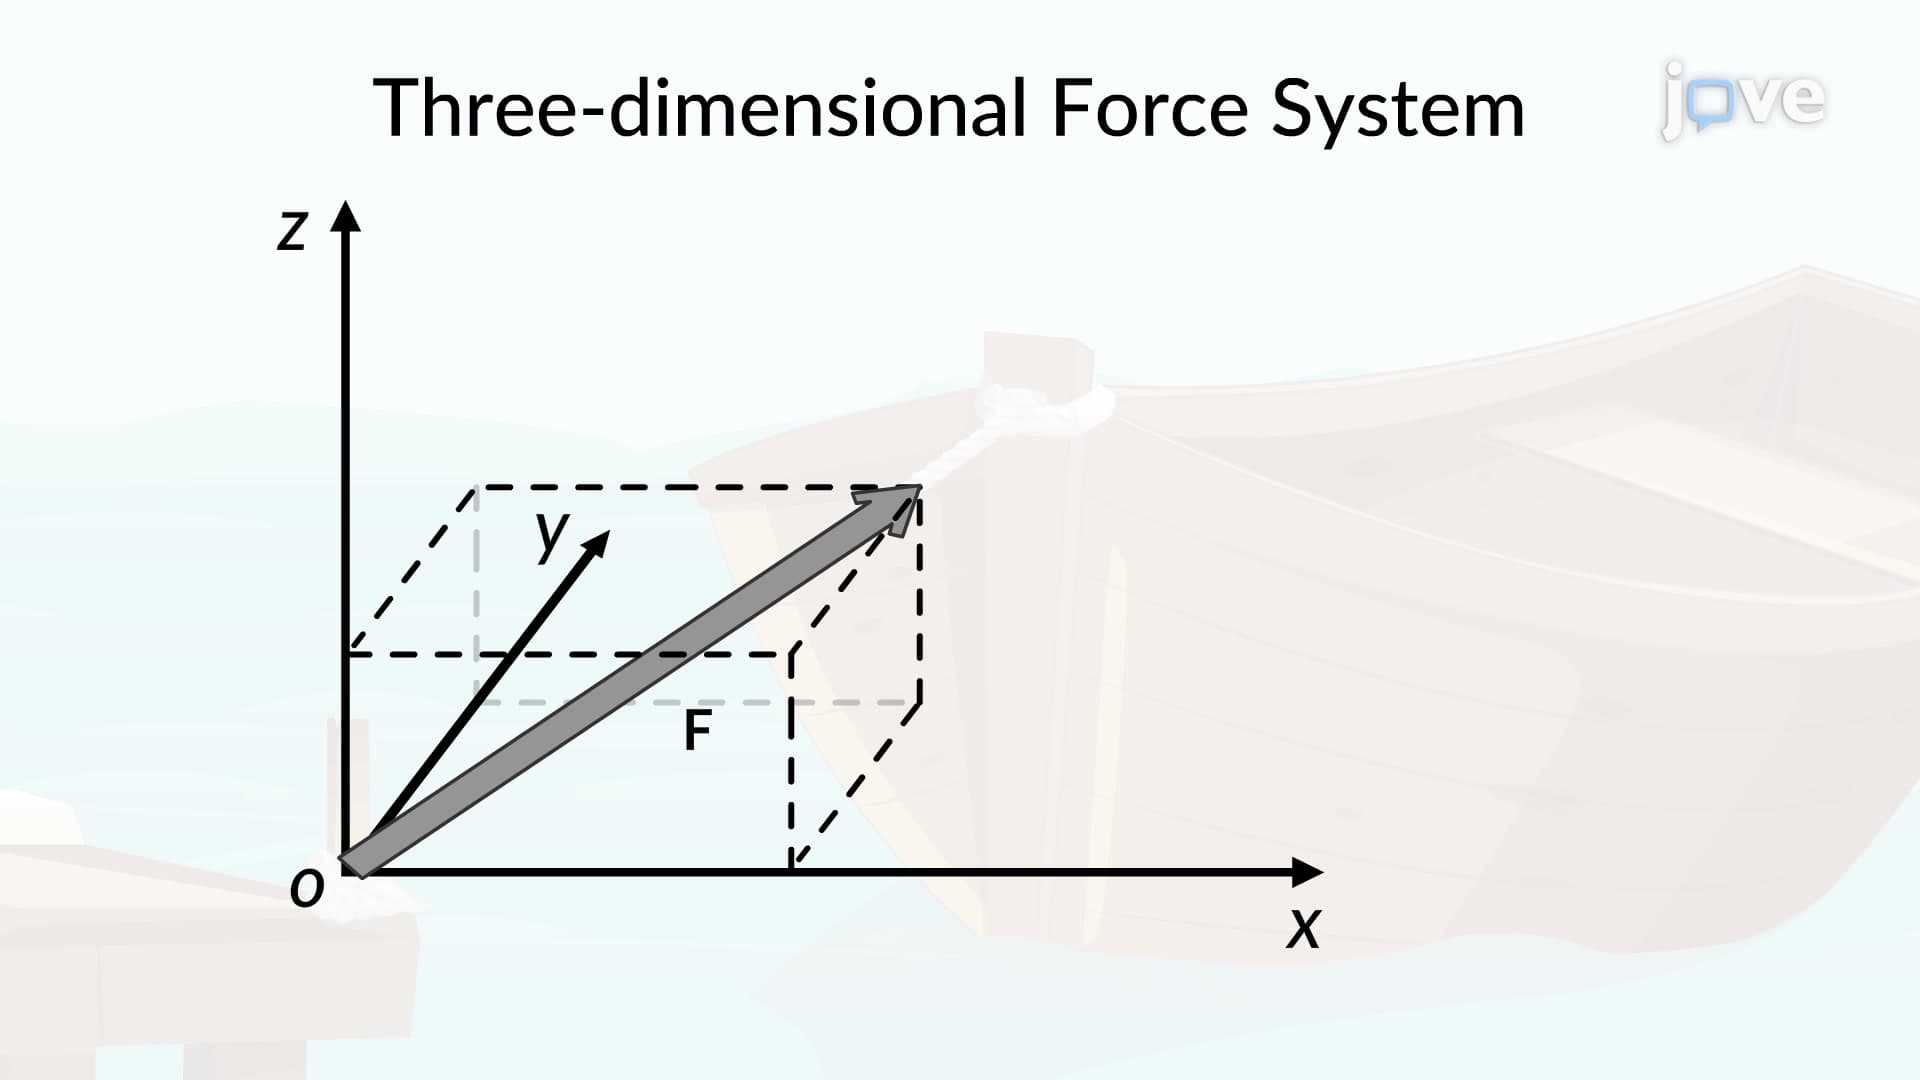
Three-Dimensional Force System
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:10
Relative Motion Analysis - Acceleration