

Coordinated control of acceleration slip regulation and active front steering for in-wheel motor driven electric
Zhigang Zhou1, Wei Shen1, Fang Xu2
1College of Vehicle and Traffic Engineering, Henan University of Science and Technology, Luoyang, China.

Abstract:
In-wheel motor driven electric vehicles are prone to issues such as wheel spin, vehicle sideslip, fishtailing, and steering instability when traveling on compacted snow surfaces. While traditional optimal slip ratio tracking aims to maximize longitudinal force, it significantly compromises lateral force reserves. Moreover, most existing longitudinal-lateral coordination strategies fail to actively constrain the slip ratio, unable to prevent the deterioration of road adhesion conditions. To address these challenges, this study proposes a coordinated control strategy integrating acceleration slip regulation (ASR) and active front steering (AFS) under dynamic slip ratio constraints. To maximize the preservation of tire lateral force margin for enhanced anti-sideslip capability, a dynamic slip ratio constraint control method is proposed. With the objectives of dynamically minimizing wheel slip ratio and maintaining driving stability, the non-dominated sorting genetic algorithm-II (NSGA-II) is employed to optimally distribute the total driving torque. Furthermore, to counteract undesired yaw moments caused by uneven road friction coefficients or torque distribution, an active front steering (AFS) compensation control strategy based on sliding mode control (SMC) is designed to track the ideal yaw rate and sideslip angle, thereby achieving efficient coordination between acceleration slip regulation and yaw stability control. Co-simulations under various conditions are conducted using the Matlab/Simulink-CarSim platform. The results demonstrate that the proposed strategy effectively suppresses wheel spin, reduces lateral path tracking errors, and improves both longitudinal and lateral stability of the vehicle. This study provides an effective solution for enhancing the active safety control of in-wheel motor driven electric vehicles operating in icy and snowy environments.


Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:14
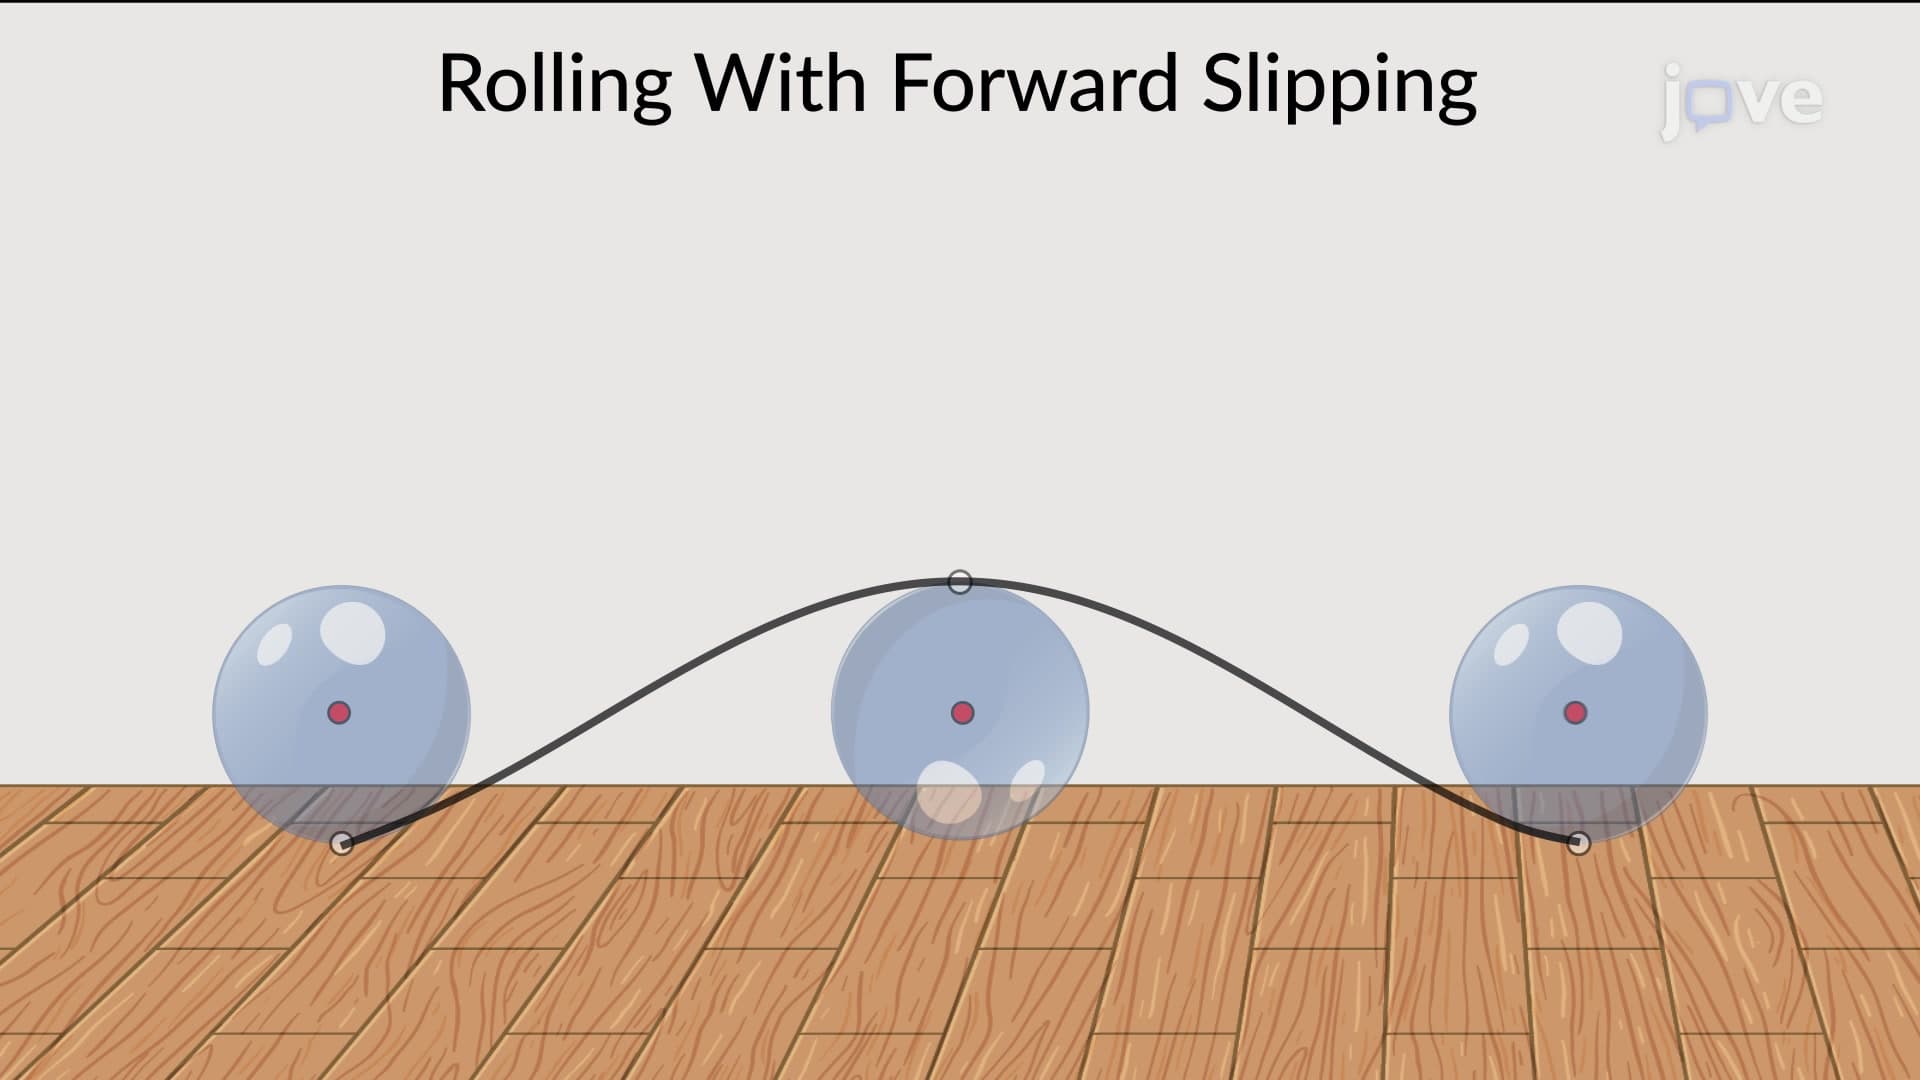
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:09
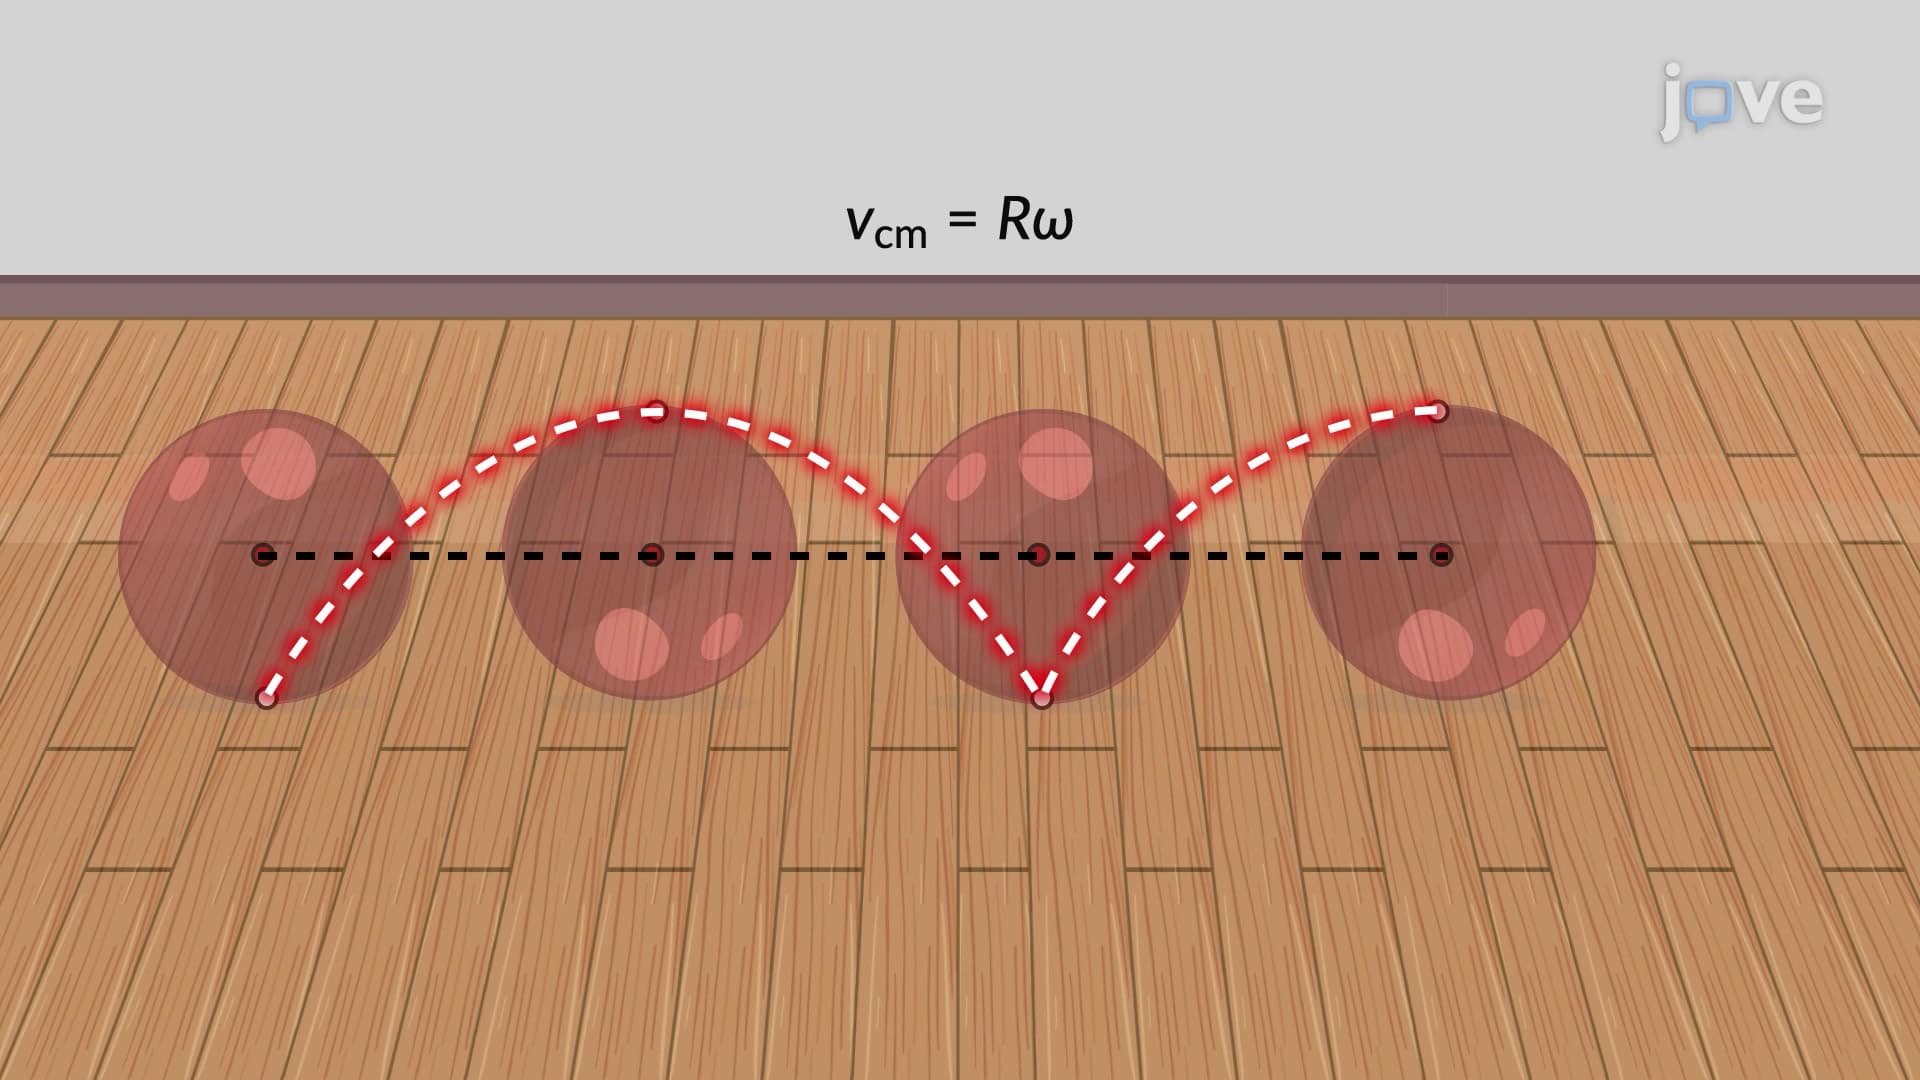
Rolling Without Slipping
 01:21
Rolling Resistance
For instance, imagine a hard cylinder rolling on a comparatively soft surface. The cylinder's weight compresses the surface beneath it. As the cylinder moves, the material in front of it slows down due to...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...