Related Experiment Video
Updated: Jan 6, 2026
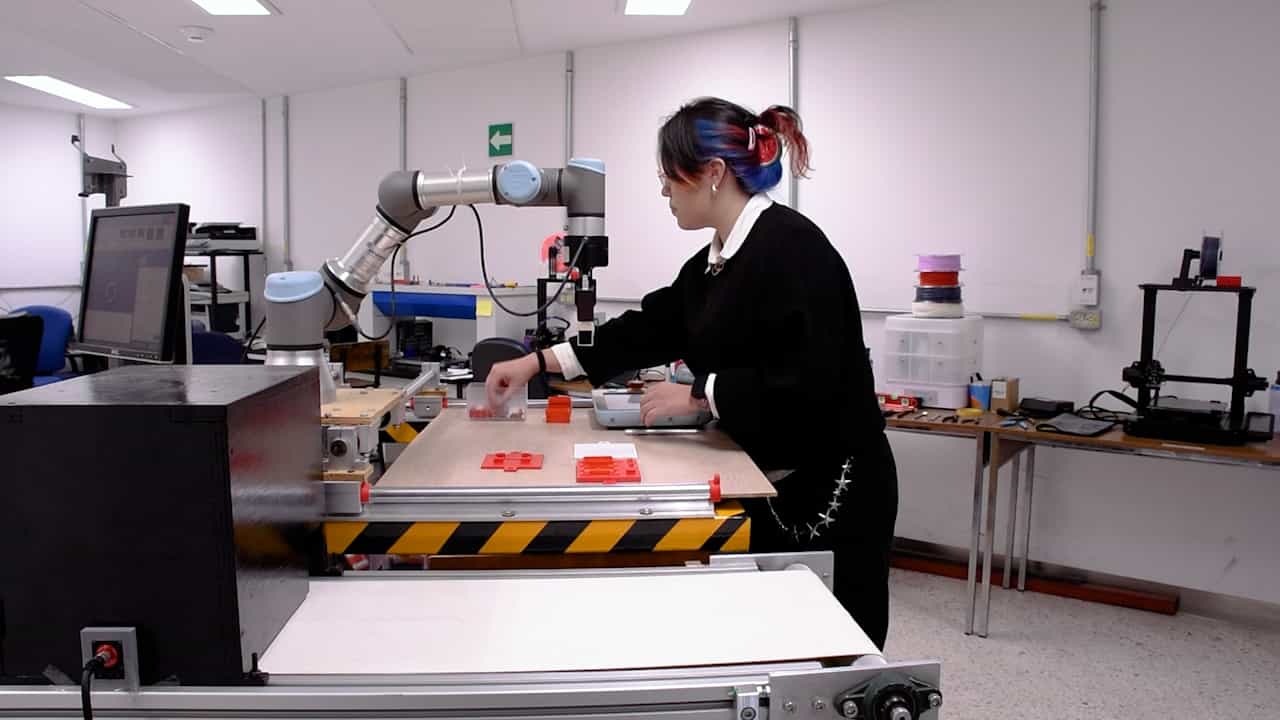

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
A review of the development of instrument and meter inspection robot
Linkang Yang1, Wan Ma1, Wenlong Dai1
1School of Mechatronic Engineering, Jiangsu Normal University, Xuzhou 221116, China.

Abstract:
The shortcomings of conventional human instrument inspection, such as its low efficiency, high risk, and data latency, have been made clear by the rapidly growing trend of industrial automation and intelligentization. An essential instrument for unmanned operation and maintenance is the instrument and meter inspection robot, which combines multimodal sensors, autonomous navigation, and intelligent identification technologies. The technical foundation and current state of application for instrument and meter inspection robots are systematically reviewed in this study. We critically examine the advancements in instrument recognition research and present the sensors, autonomous navigation algorithms, and identification technologies utilized in instrument and meter inspection robots. We tested a prototype of a standard wheeled inspection robot in the instrument inspection of a cement plant and reported the test findings to further examine the viability of inspection robots. Furthermore, we evaluate the challenges in the development of instrument and meter inspection robots and propose potential avenues for future research.


