Related Experiment Video
Updated: Jan 12, 2026
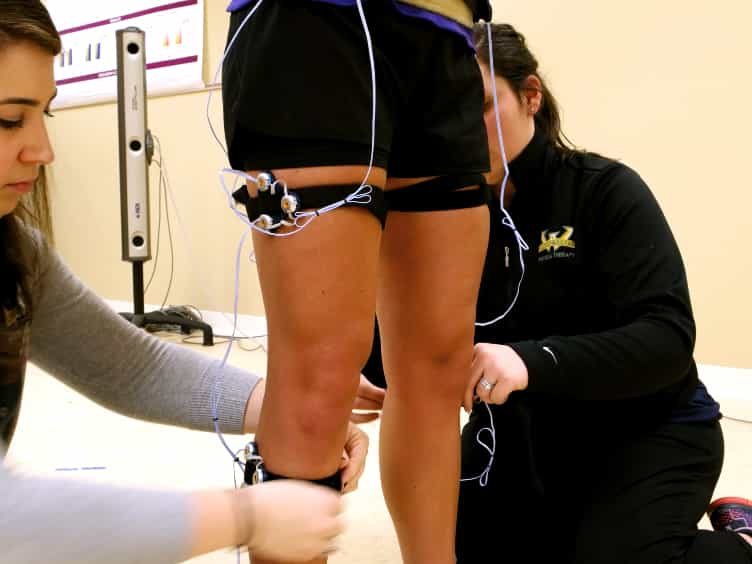
Video Movement Analysis Using Smartphones ViMAS: A Pilot Study
Published on: March 14, 2017
Knowledge transfer-driven estimation of knee moments and ground reaction forces from smartphone videos via
Md Sanzid Bin Hossain1,2, Hwan Choi3, Zhishan Guo4
1Department of Clinical Science, University of Central Florida, College of Medicine, Orlando, Florida, United States of America.

Abstract:
The knee adduction and flexion moment provides critical information about knee joint health, while 3D ground reaction forces (GRFs) help identify force and energy characteristics for maneuvering the entire human body. Existing methods of acquiring joint moments and GRFs require expensive equipment, time-consuming pre-processing, and limited accessibility. This study proposes to tackle these limitations by utilizing only smartphone videos to estimate joint moments and 3D GRFs accurately. We also propose the augmentation of joint kinematics by generating additional modalities of 2D joint center velocity and acceleration from 2D joint center position acquired from the videos. This augmented joint kinematics helps to apply a multi-modal fusion module to learn the importance of inter-modal interactions. Additionally, we utilize recurrent neural networks and graph convolutional networks to perform temporal-spatial modeling of joint center dynamics for enhanced accuracy. To overcome another challenge of video-based estimation, particularly the lack of inertial information related to body segments, we propose multi-modal knowledge transfer to train the video-only student model from a teacher model that integrates both video and inertial measurement unit (IMU) data. The student model significantly reduces the normalized root mean square error (NRMSE) from 5.71 to 4.68 and increases the Pearson correlation coefficient (PCC) from 0.929 to 0.951. These results demonstrate that knowledge transfer, augmentation of joint kinematics for multi-modal fusion, and temporal-spatial modeling significantly enhance smartphone video-based estimation, offering a potential cost-effective alternative to traditional motion capture for clinical assessments, rehabilitation, and sports applications.
Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
 01:23
Knee Joint
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...