Related Experiment Video
Updated: Jan 11, 2026

Collecting and Processing Drone-based Remotely Sensed Data for Use in Forest Recovery Monitoring
Published on: October 24, 2025
Collecting and Processing Drone-based Remotely Sensed Data for Use in Forest Recovery Monitoring
Dmytro Movchan1, Charumitha Selvaraj1, Zhouxin Xi1
1Natural Resources Canada, Canadian Forest Service, Northern Forestry Centre.

Abstract:
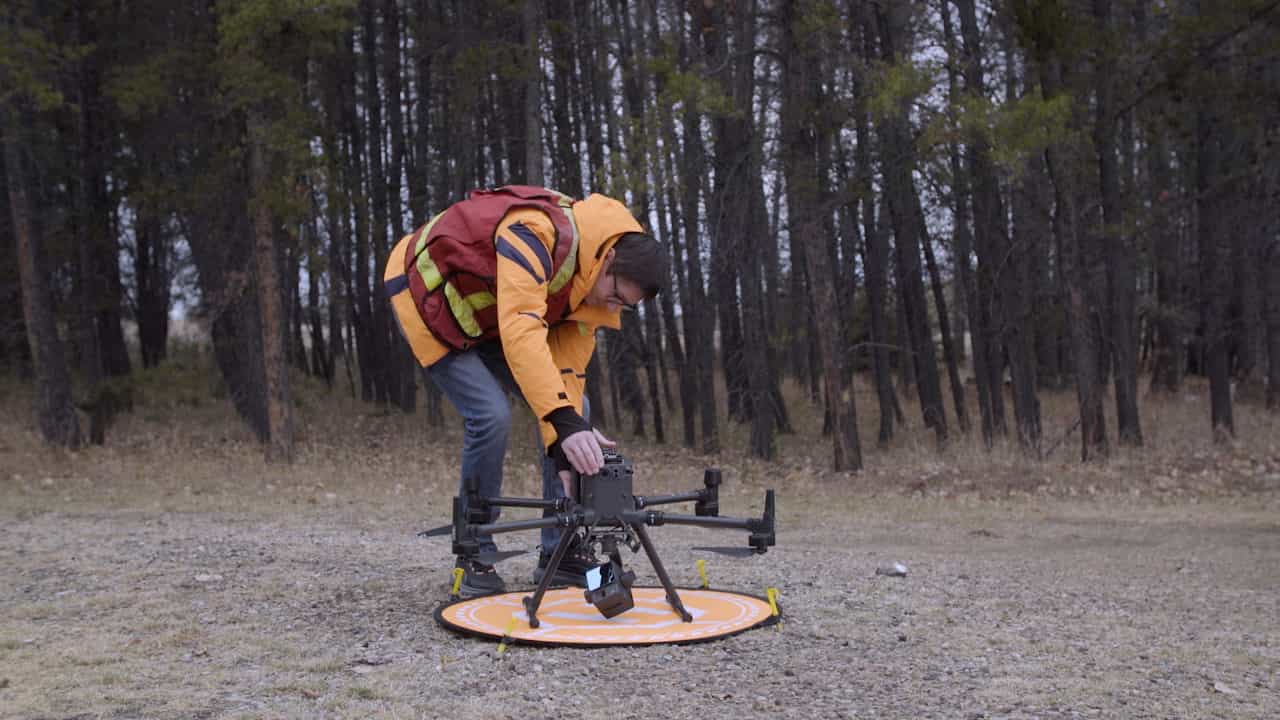
Remote sensing (RS) technologies, particularly light detection and ranging (LiDAR) and multispectral (MS) imagery, provide broad-scale vegetation monitoring capabilities at varying spatial resolutions. Remotely piloted aircraft systems (RPAS) equipped with LiDAR and MS sensors can enhance vegetation assessments by offering flexible flight schedules and capturing fine-resolution data. Further integration of deep learning (DL) models holds promise for automating the post-processing workflow, which is particularly important for vegetation monitoring applications. This protocol outlines a suite of practical methods for collecting, processing, aligning, and merging RPAS-based LiDAR and MS data for individual 3D tree delineation using an interactive DL plugin. The proprietary DL model effectively detects and segments tree boundaries across various sensors, study sites, and data resolutions within forest ecosystems. Our specific application and motivation for developing this protocol and tool is for monitoring forest recovery on reclaimed oil and gas wellsites. Currently field-based assessment methods are time-consuming, labor-intensive, and spatially limited. As reclamation efforts expand, there is a growing need for more efficient, and scalable approaches to monitor reclamation success and ecosystem recovery. By advancing RPAS-based DL applications, this research supports the monitoring of ecological recovery on reclaimed wellsites and is also applicable to other forested landscapes.

Related Concept Videos
 01:29
Applications of GIS: Disaster Management and Emergency Response
 01:23
GIS Software, Hardware, and Sources of GIS Data