

Hybrid deep learning framework for real-time fault detection in squirrel-cage induction motors
J M Jakaria1, Jahin Sabir1, Md Zillur Rahman1
1Department of Electrical and Electronic Engineering, Faridpur Engineering College, Faculty of Engineering and Technology, University of Dhaka, Faridpur, Bangladesh.

Abstract:
The Fourth Industrial Revolution has heightened the demand for intelligent and reliable predictive maintenance systems in industrial environments. This study proposes a hybrid deep learning-based framework for real-time fault detection in Squirrel-Cage Induction Motors (SCIMs). Utilizing eight deep learning architectures-CNN-GRU, CNN-LSTM, LSTM, BiLSTM, Stacked LSTM, GRU, CNN, and ANN-the framework was trained and tested on a comprehensive dataset comprising one million samples, evenly divided between healthy and faulty motor conditions. Hybrid models, particularly CNN-GRU and CNN-LSTM, achieved classification accuracies of 92.57% and 92.27%, respectively, outperforming the other baseline models across precision, recall, and F1-score by effectively capturing both temporal and spatial features. Beyond classification accuracy, the hybrids further demonstrated computational efficiency in terms of inference time, latency, and throughput, validating their suitability for real-time deployment. The system analyzes real-time sensor data, including torque, speed, power, and stator/rotor currents, to identify various fault types such as short circuits, overloads, mechanical failures, and open circuits. Developed in MATLAB Simulink, the framework demonstrates high accuracy and scalability for real-time deployment. While results are promising, the claims are positioned within the scope of the evaluated models, as direct benchmarking with state-of-the-art methods was not within the present scope. The framework demands substantial computing power and annotated datasets, yet it represents a step toward intelligent, self-aware industrial systems. Future work will focus on model optimization, deployment in resource-constrained environments, and validation with real-world noisy industrial data, explicitly considering sensor drift, varying load conditions, and fault severity levels across diverse motor types and operational scenarios. In addition, since bearing faults account for a significant share of induction motor failures in practice, it will be a key priority to ensure comprehensive industrial applicability.

Related Concept Videos
 01:21
Three-Phase Short Circuit—Unloaded Synchronous Machine
This behavior occurs due to the magnetic flux produced by the short-circuit armature currents. Initially, these currents follow high-reluctance paths but eventually shift to...
 01:22
Indirect Motor Pathways
The vestibulospinal tract originates in the vestibular nuclei of the brainstem. The vestibular system detects changes in...
 01:13
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
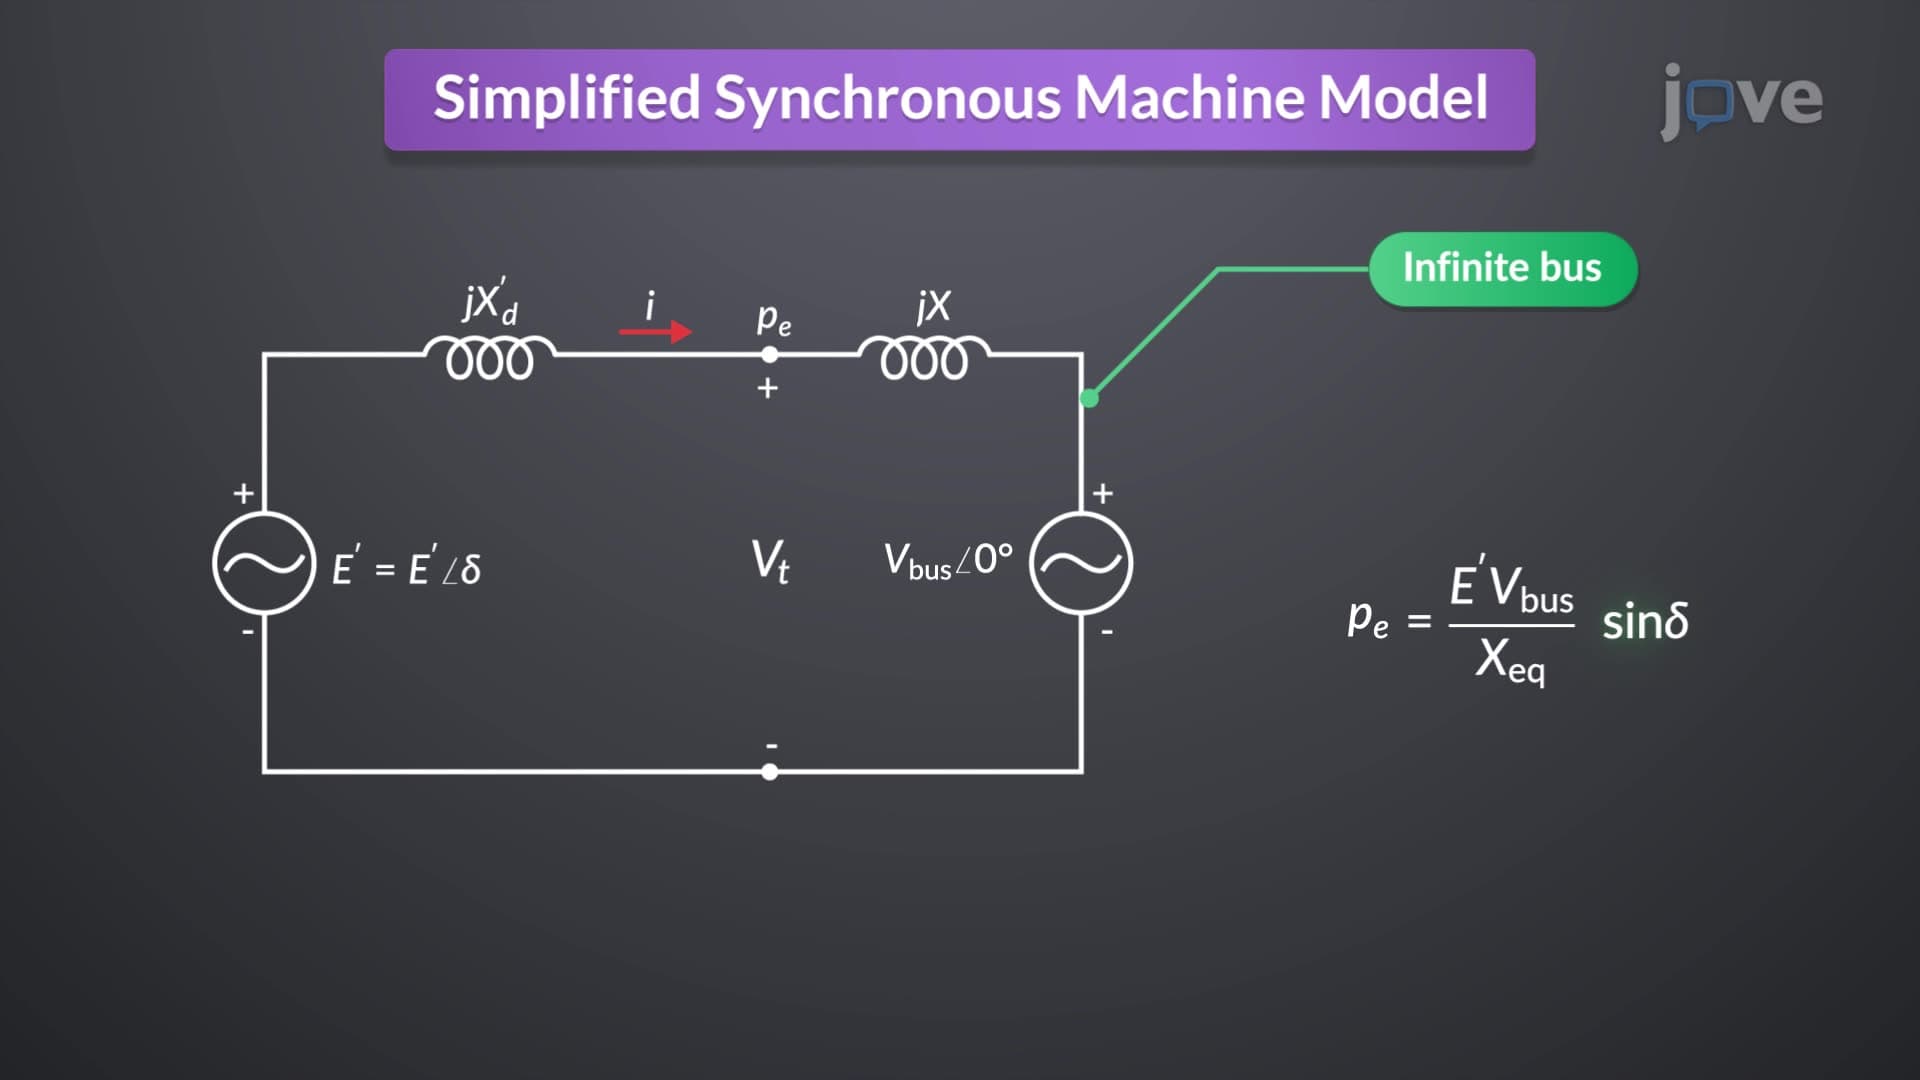 01:30
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 00:46
Motor Units
 01:13
Motor Units
Motor units come in different sizes, with smaller units...