Related Experiment Video
Updated: Jan 11, 2026
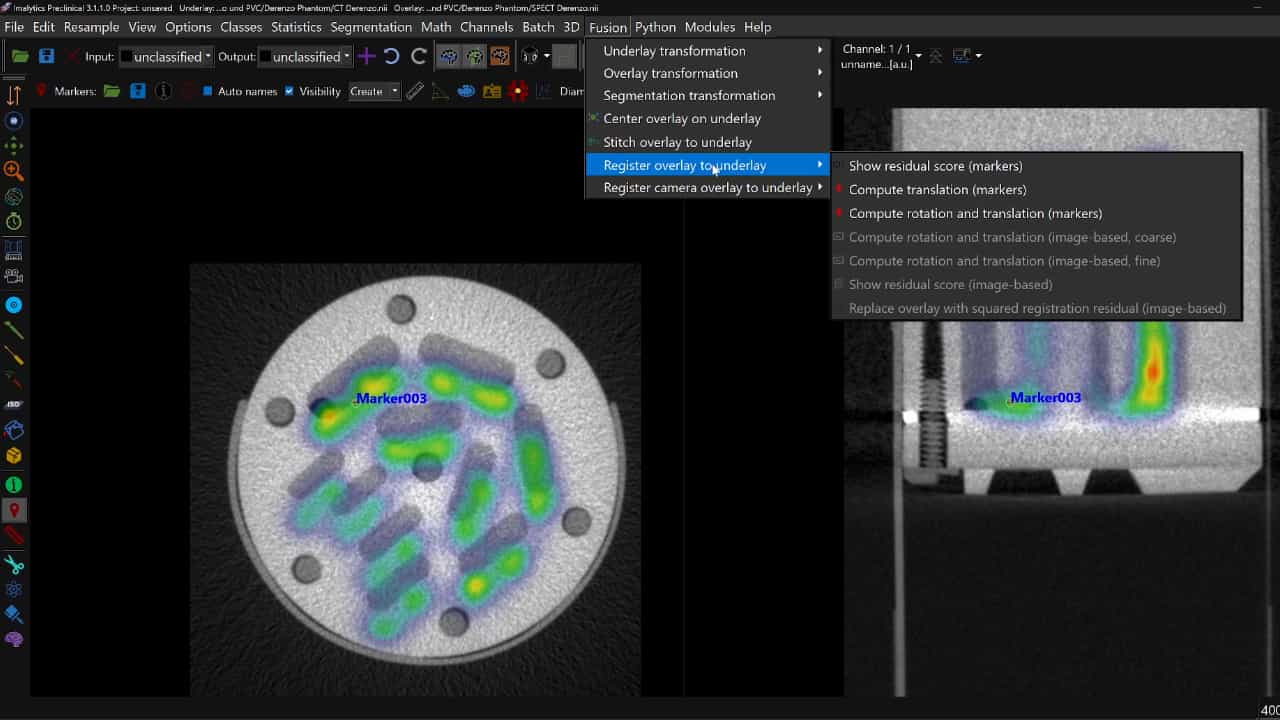

Author Spotlight: An Efficient and Robust Software for Automated Fusion of Multiple Preclinical Imaging Modalities
Published on: October 27, 2023
Toward a Unified Representation of Multi-Modal Pre-Training for 3-D Processing

Abstract:
With the growing demand for real-world 3-D understanding, learning effective representations of 3-D data has become increasingly important for tasks such as shape classification, model retrieval, scene reconstruction, and point cloud completion. Although previous work has explored self-supervised learning within individual modalities (e.g., point clouds or images), the potential of multi-modal supervision remains largely underexplored due to the lack of aligned and scalable training signals. In this work, we present DR-Point, a tri-modal pre-training framework that jointly learns from RGB images, depth maps, and 3-D point clouds to build a unified embedding space across modalities. By enforcing cross-modal consistency among RGB-depth-point triplets, DR-Point achieves effective 2-D-3-D feature alignment without manual annotations. A differentiable rendering module further enhances geometric fidelity by synthesizing depth cues and refining structural details in reconstructed point clouds. Extensive experiments on benchmarks demonstrate that DR-Point consistently outperforms state-of-the-art self-supervised methods on 3-D classification, segmentation, and completion. These results highlight the advantages of multi-modal pre-training for unified 3-D understanding and its potential to benefit a wide range of vision and graphics applications.
Related Concept Videos
 01:20
Parallel Processing
 01:15
Depth Perception and Spatial Vision
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...
 02:18
Fischer Projections
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...