Related Experiment Video
Updated: Jan 11, 2026


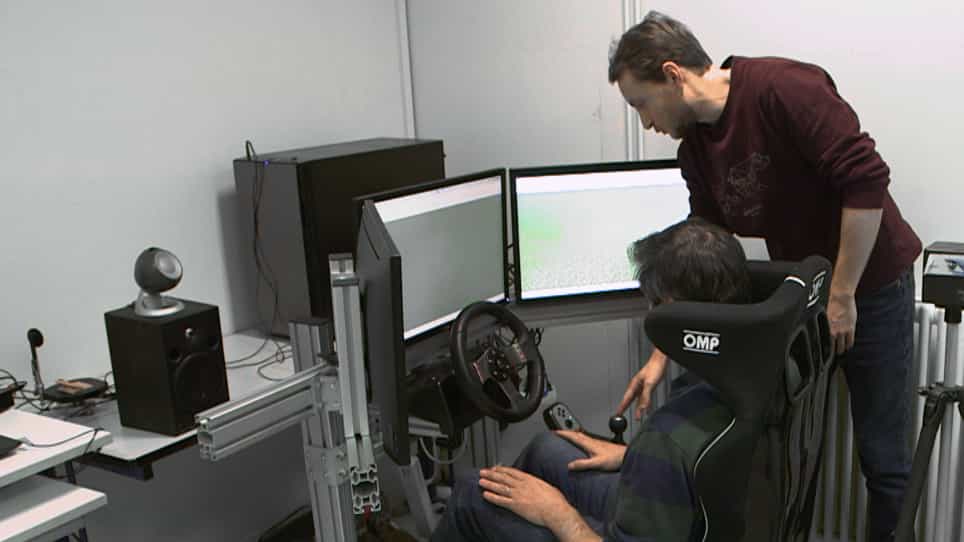
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
How does the driver respond to rear-end risk under time-varying driving styles: A temporal instability test using the
Guilong Xu1, Zhen Yang1, Jinfeng Ying1
1The Key Laboratory of Road and Traffic Engineering, Ministry of Education, Tongji University, Shanghai 201804, China; College of Transportation, Tongji University, 4800 Cao'an Highway, Shanghai 201804, China.

Abstract:
Drivers' risk-response mechanism is the internal driver of performing car-following behaviors, which is affected by internal driving styles and external traffic context. Investigating this mechanism is crucial for developing real-time safety countermeasures and designing human-like autonomous driving strategies. However, previous studies labeled the driver into one certain style, ignoring their time-varying preference tradeoffs. In addition, contextual traffic factors contributing to drivers' risk-response choice under time-varying styles also remain unclear. As such, this study aims to investigate how drivers adjust their responses to rear-end collision risks as their driving styles evolve over time in car-following scenarios. The dataset was collected by an advanced multi-driver simulation platform allowing four drivers to simultaneously drive in the same scenario. Based on this data, we first segmented driving behavior into candidate time windows and applied a spectral clustering algorithm guided by a novel driving behavior entropy metric to identify five distinct, stable styles over optimal 15-second intervals. The rear-end collision risk is depicted by a potential safety hazard index considering the leading vehicle (PSHI-1). Then we classified risk-response patterns by measuring the Spearman correlation between rear-end risk and acceleration, and addressed class imbalance by Synthetic Minority Over-sampling Technique for Nominal and Continuous features (SMOTE-NC) data augmentation. To analyze the relationship between drivers' risk-response choices and corresponding contributing factors across different driving styles, the random parameter multinomial logit model with heterogeneity in means and variances was estimated, revealing several significantly factors including driver characteristics, variables of leading vehicle (LV), variables of following vehicle (FV), interaction variables between LV and FV. Finally, we assessed temporal instability using global and pairwise likelihood-ratio tests, confirming that parameter estimates were statistically significant temporal shifts across driving styles. These findings highlight the dynamic nature of risk-response mechanisms and underscore the importance of accounting for time-varying driving styles in both real-time safety systems (e.g. Advanced Driver Assistance Systems (ADAS)) and human-like autonomous vehicles (HAV).

Related Concept Videos
 01:16
Response Surface Methodology
The process of RSM involves several key steps:
 01:21
Friedman Two-way Analysis of Variance by Ranks
 01:14
Parametric Survival Analysis: Weibull and Exponential Methods
Weibull Distribution
The Weibull distribution is a flexible model used in parametric survival analysis. It can handle both increasing and decreasing hazard rates, depending on its shape parameter...
 01:18
One-Way ANOVA
 01:08
Determination of Expected Frequency
 01:06
Model Approaches for Pharmacokinetic Data: Distributed Parameter Models
The distributed parameter models are specifically designed to account for variations and differences in some drug classes. This model is particularly useful for assessing regional concentrations of anticancer or...