Minimally invasive coronary artery bypass grafting with robotic and laparoscopic-assisted artery harvesting: a case report
Related Experiment Video
Updated: Jan 11, 2026
Author Spotlight: Enhancing Coronary Artery Revascularization
Published on: September 15, 2023
Lu-Yao Ma1, Xiao-Zhi Wang2, Huan Liu1
1Department of Cardiovascular Surgery, The First Affiliated Hospital of Nanjing Medical University, Nanjing 210029, China.

Background:
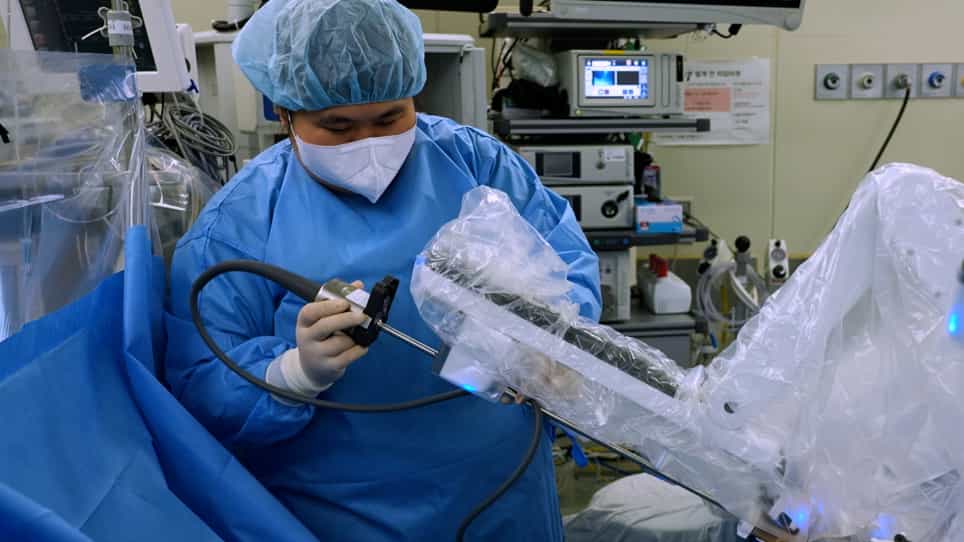
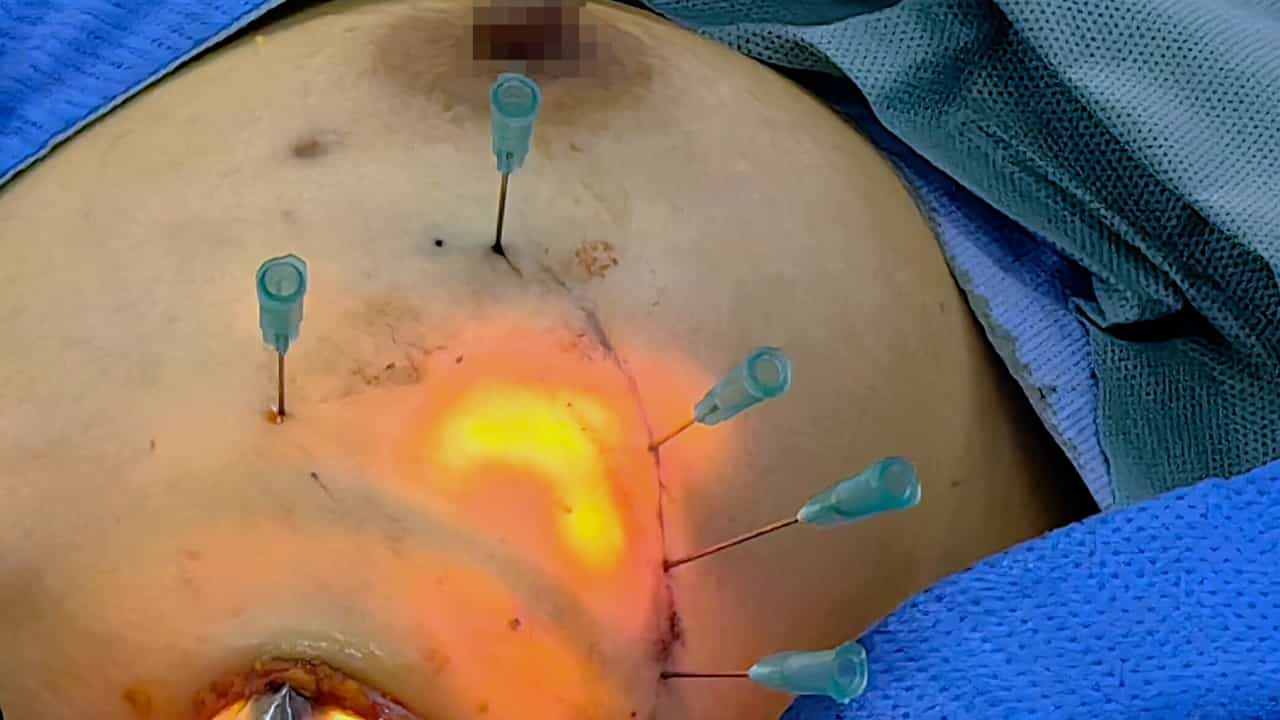
Minimally invasive techniques for harvesting arterial grafts have emerged to meet the demands for less invasive procedures. With the development of various harvesting methods, ensuring the safety and efficacy of these minimally invasive approaches remains critical. This case report describes minimally invasive direct coronary artery bypass (MIDCAB) surgery involving robotic harvesting of the left internal thoracic artery (LIMA) and laparoscopic-assisted harvesting of the right gastroepiploic artery (GEA).
Case Summary:
A 55-year-old male patient underwent minimally invasive coronary artery bypass grafting, with robotic-assisted harvesting of the left LIMA and laparoscopic-assisted harvesting of the right GEA. The procedural workflow and our experience are described herein.
Discussion:
This case report emphasizes the importance of multimodality imaging in planning for minimally invasive coronary artery bypass grafting. Robotic harvesting of the IMA and laparoscopic harvesting of the right GEA are safe procedures and can be performed in selected patients.