Related Experiment Video
Updated: Jan 10, 2026
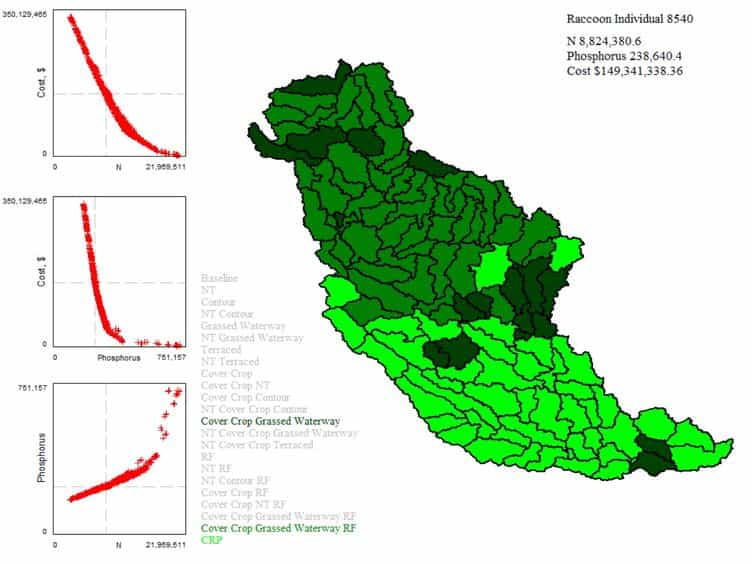
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Multi-Strategy Improved POA for Global Optimization Problems and 3D UAV Path Planning
Rui Zhang1,2, Jingbo Zhan3, Jianfeng Wang4
1School of Engineering Science, Shandong Xiehe University, Jinan 250107, China.

Abstract:
With the rapid development of smart manufacturing and the low-altitude economy, drone technology-as a vital component of next-generation intelligent equipment-has garnered significant attention from researchers. Path planning, one of the core challenges in drone technology advancement, directly impacts the efficiency and safety of drone mission execution. However, most existing drone path planning algorithms suffer from issues such as requiring extensive interactive information or being prone to getting stuck in local optima. This study introduces a multi-strategy enhanced Pelican Optimization Algorithm (MIPOA) tailored for UAV path planning. To improve the quality of the initial population, a hybrid initialization approach combining low-discrepancy sequences with heuristic refinement is developed. The low-discrepancy component promotes a more uniform distribution across the search space, while the heuristic mechanism enhances the fitness of selected individuals and reduces redundant exploration. Furthermore, a subgroup mean-guided updating strategy is designed to accelerate convergence toward the global optimum. To maintain exploration ability, a random reinitialization boundary mechanism is incorporated, effectively preventing premature convergence. To validate the algorithm's performance, MIPOA is compared with eleven benchmark metaheuristics on the CEC2017 test suite, and statistical analyses confirm its superior optimization capability. Finally, MIPOA is applied to 3D UAV path planning under four threat scenarios in a realistic environment, demonstrating robust adaptability and achieving successful mission completion.

Related Concept Videos
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:30
Types of Global Positioning System Surveys