Related Experiment Video
Updated: May 3, 2026


MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Robotic manipulation of human bipedalism reveals overlapping internal representations of space and time
Paul Belzner1, Patrick A Forbes2, Calvin Kuo3
1School of Kinesiology, University of British Columbia, Vancouver, BC, Canada.

Abstract:
Effective control of bipedal postures relies on sensory inputs from the past, which encode dynamic changes in the spatial properties of our movement over time. To uncover how the spatial and temporal properties of an upright posture interact in the perception and control of standing balance, we implemented a robotic virtualization of human body dynamics to systematically alter inertia and viscosity as well as sensorimotor delays in 20 healthy participants. Inertia gains below one or negative viscosity gains led to larger postural oscillations and caused participants to exceed virtual balance limits, mimicking the disruptive effects of an additional 200-millisecond sensorimotor delay. When balancing without delays, participants adjusted their inertia gains to below one and viscosity gains to negative values to match the perception of balancing with an imposed delay. When delays were present, participants increased inertia gains above one and used positive viscosity gains to align their perception with baseline balance. Building on these findings, 10 naïve participants exhibited improved balance stability and reduced the number of instances they exceeded the limits when balancing with a 200-millisecond delay compensated by inertia gains above one and positive viscosity gains. These results underscore the importance of innovative robotic virtualizations of standing balance to reveal the interconnected representations of space and time that underlie the stable perception and control of bipedal balance. Robotic manipulation of body physics offers a transformative approach to understanding how the nervous system processes spatial information over time and could address clinical sensorimotor deficits associated with delays.
More Related Videos


Related Concept Videos
 01:14
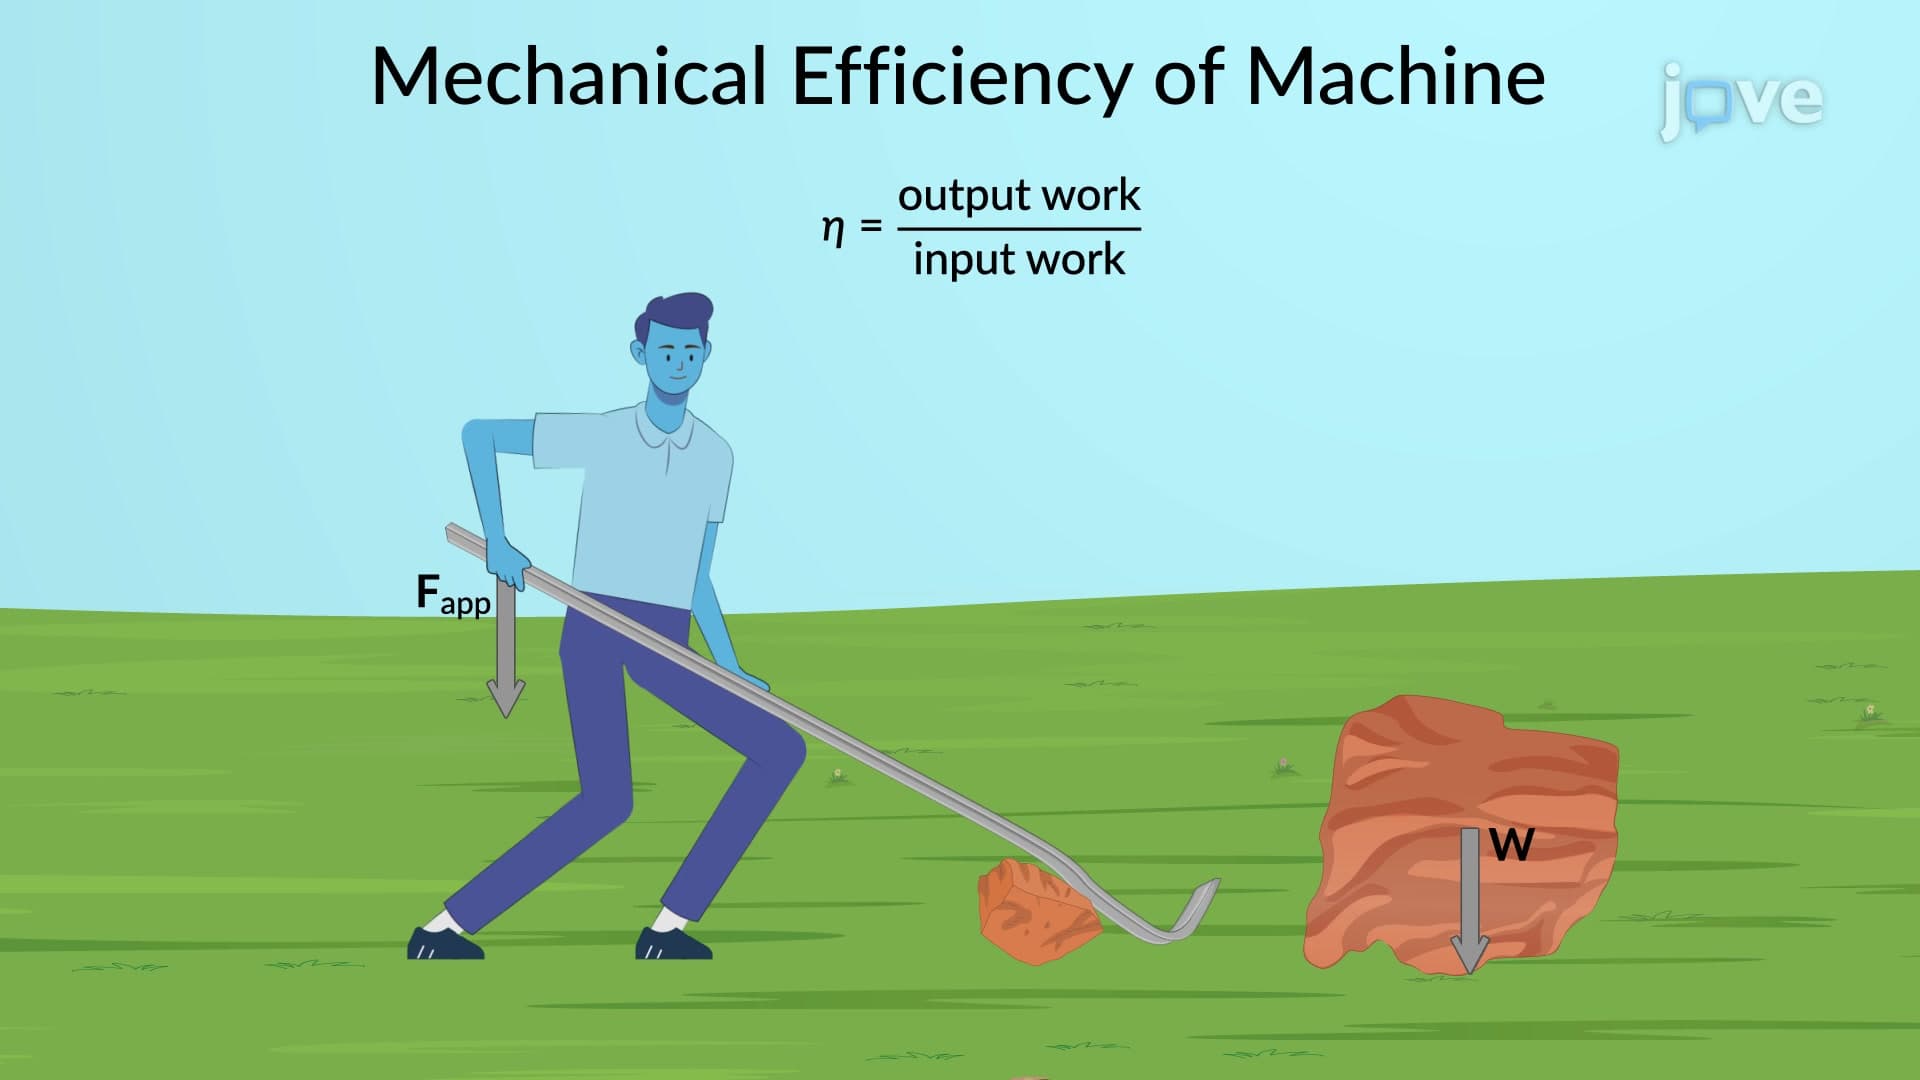
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
 01:22
Mechanical Systems
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...