Related Experiment Video
Updated: Jan 10, 2026
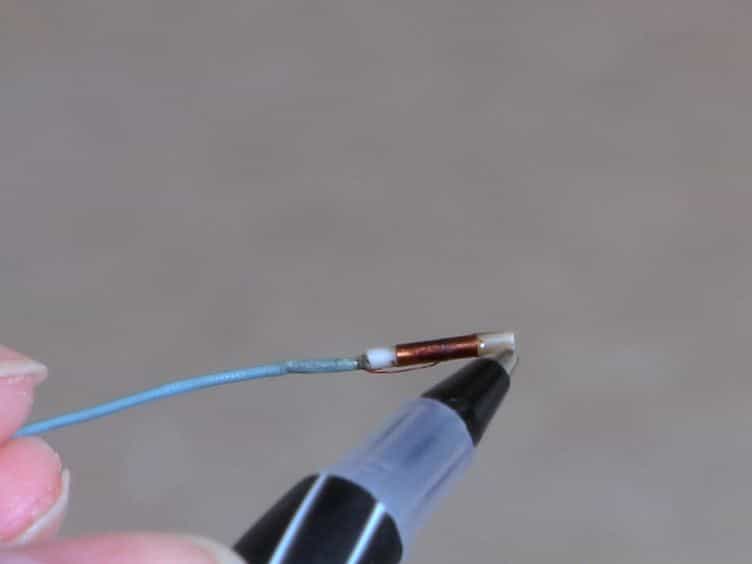

Magnetically-Assisted Remote Controlled Microcatheter Tip Deflection under Magnetic Resonance Imaging
Published on: April 4, 2013
Rapid Fabrication of Self-Propelled and Steerable Magnetic Microcatheters for Precision Medicine
Zhi Chen1, Boris Rivkin2, David Castellanos-Robles1,3
1CIC nanoGUNE, 20018, San Sebastián, Spain.

Abstract:
Minimally invasive therapies demand precise navigation through complex and delicate anatomical pathways, requiring medical tools that are small, flexible, and highly maneuverable. Here, a high-yield fabrication method for the production of magnetic tubular microrobots, tethered and untethered, with programmable magnetization, is presented. The method uses Joule heating through a template wire, enabling the fabrication of microrobots with tunable dimensions. Three device configurations are demonstrated: 1) a steerable guiding microcatheter with stiffness modulation; 2) an untethered tubular microrobot (TubeBot), exhibiting wave-crawling locomotion; and 3) a hybrid microcatheter robot that integrates distal-end wave-crawling propulsion with linear insertion to minimize tissue trauma. Validation in tortuous channels, soft phantoms replicating tissue compliance, 3D-printed organ models, ex vivo tissues, and live mice demonstrates the microrobots's ability to achieve precise navigation across different environments. The successful targeted delivery of sperm cells, embryos, and drug-mimicking compounds further highlights its potential for precision medicine, including applications in assisted reproduction and targeted drug delivery.
More Related Videos
 09:13
Remote Magnetic Navigation for Accurate, Real-time Catheter Positioning and Ablation in Cardiac Electrophysiology Procedures
Published on: April 21, 2013
 09:58
Computer Numerical Control Micromilling of a Microfluidic Acrylic Device with a Staggered Restriction for Magnetic Nanoparticle-Based Immunoassays
Published on: June 23, 2022