Related Experiment Video
Updated: Jan 6, 2026


Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023
From static to dynamic: how object rotation influences grasp decisions in ambiguous settings
Natalie J Maffitt1, Emma G Cairns1, Julia Wozna1
1Biosciences Institute, Newcastle University, Newcastle Upon Tyne, NE2 4HH, UK.

Abstract:
The hand grasp of an object is normally consistent, determined by the optimal, most efficient strategy learnt from previous experience. Yet in certain settings, despite object properties remaining constant and intention the same, the grasp chosen by an individual can vary with a lack of clear preference for a particular grasp configuration. This is referred to as motor ambiguity. Here, we compare the influence of preceding static versus dynamic visual information on participants' choice between two possible hand configurations when grasping an object at various orientations. We confirm previous findings that presentation of an object in an initial static orientation prior to the grasping in ambiguous orientation causes subjects to select a grasp that would be most congruent with the initial, determinate orientation. However, we unexpectedly found that when object rotation is observed between the initial and target positions, the bias is inversed, i.e. subjects choose the alternate grasp configurations. Furthermore, the inverse bias strength was found to be independent of the motion magnitude, and persists even when greater decision time is allowed. We discuss several possibilities across perceptual and decision making circuitry that might manifest this behavioural phenomenon.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:13
Angle of Twist: Problem Solving
 01:25
The Anchoring-and-Adjustment Heuristic
 01:11
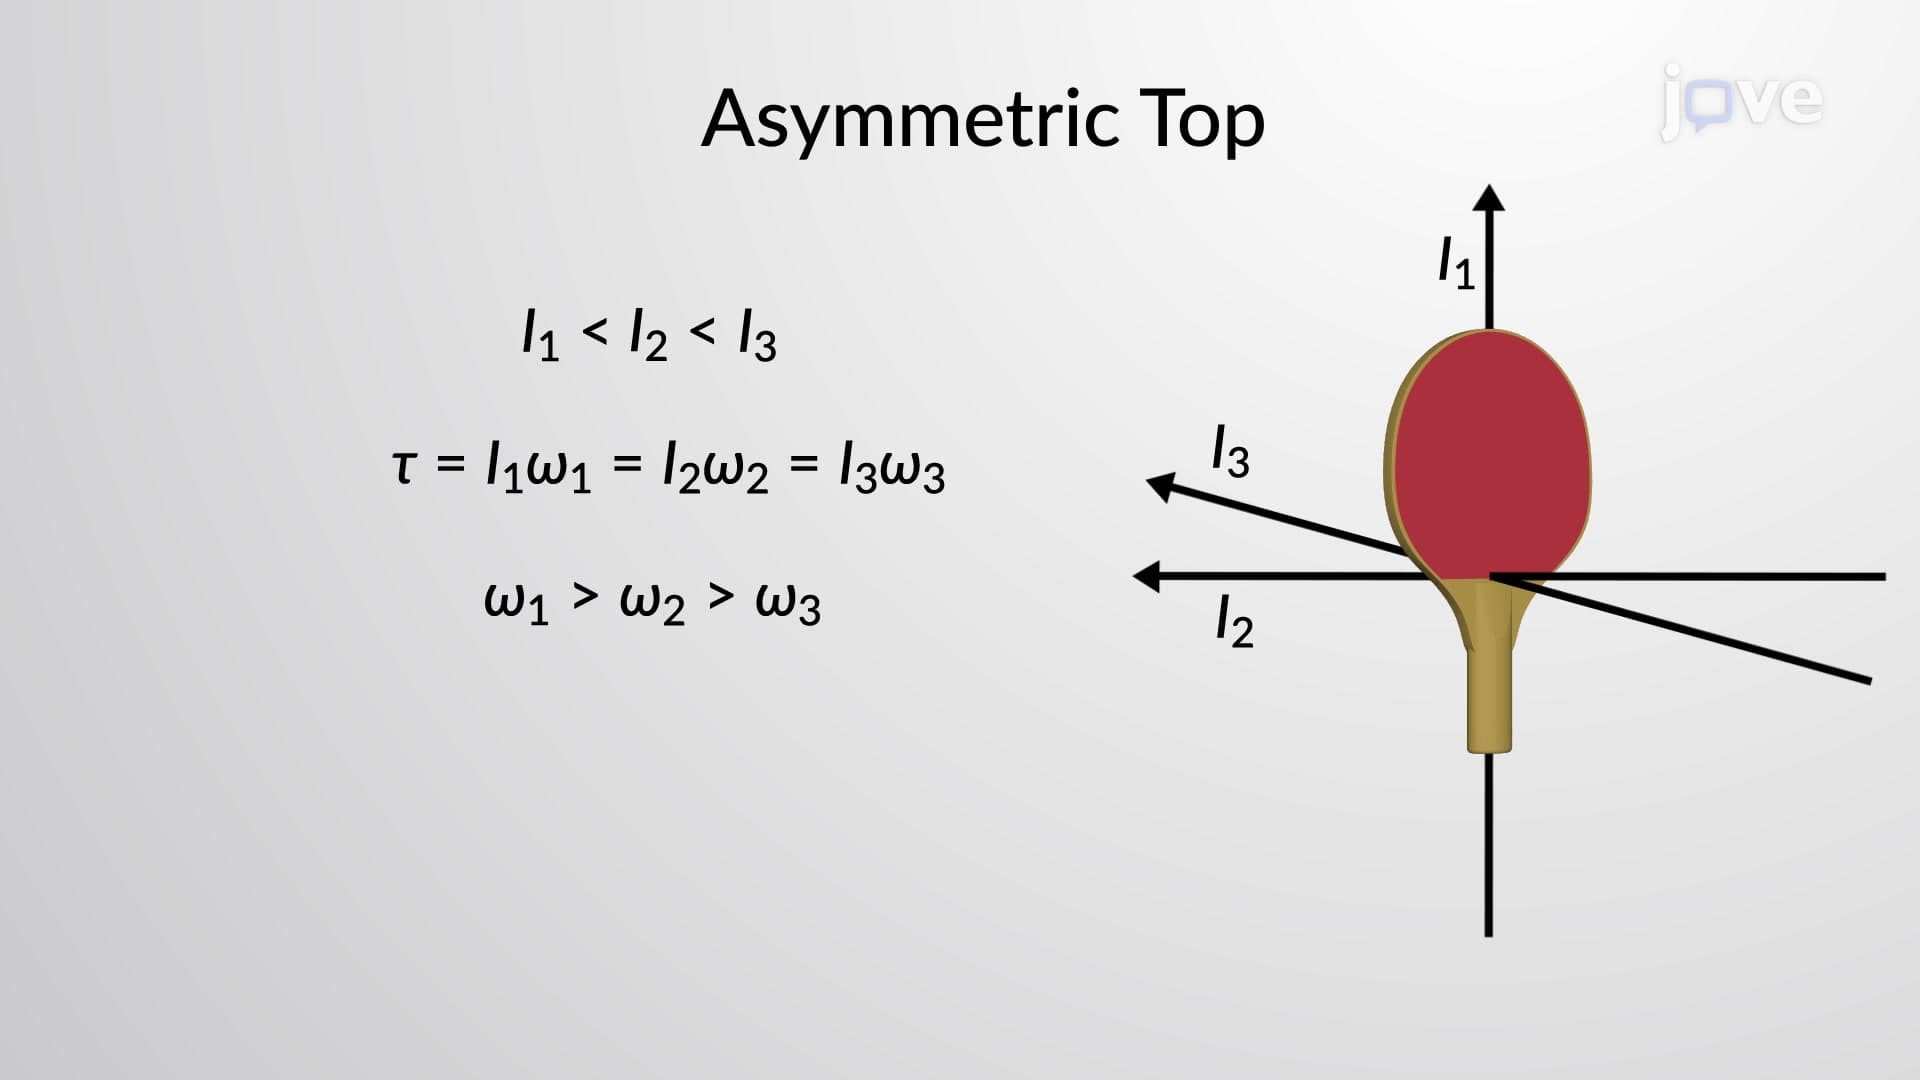
Rotation of Asymmetric Top
The relationship between the angular momentum of any rigid body and its angular velocity, both of which are vectors, involves the moment of inertia. The moment of inertia is a scalar quantity only for spherically symmetric...
 01:12
Hindsight Biases
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...