

Integrating GAN-based machine learning with nonlinear Kalman filtering for enhanced state estimation
Lior Tobaly1, Eyal Yaniv2, Zeev Zalevsky3
1School of Business Administration, Bar-Ilan University, Ramat-Gan, 52900, Israel. lior.tobaly@biu.ac.il.

Abstract:
This study introduces a novel approach for enhancing state estimation in non-linear dynamic systems by integrating Generative Adversarial Networks (GANs) with the Unscented Kalman Filter (UKF). While the UKF improves upon traditional Kalman Filters by using sigma points to estimate the mean and covariance in non-linear transformations, its effectiveness is limited by static parameters - specifically, the process noise covariance (Q), measurement noise covariance (R), and scaling factors (primary, secondary, and tertiary; α, κ, and β). We propose a dynamic framework in which a GAN predicts and updates these parameters in real-time, based on the UKF's recent performance, allowing the filter to better adapt to rapidly changing system dynamics. This method is validated on real-world aircraft navigation data containing time-stamped records of position, velocity, heading, and environmental variables. Results show that the GAN-enhanced UKF significantly reduces state estimation errors compared to conventional static models. The proposed framework is generalizable and can be applied to other domains such as robotics, autonomous vehicles, and smart cities, where accurate real-time state estimation under uncertainty is critical.
More Related Videos
 10:51
An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:27
State Space Representation
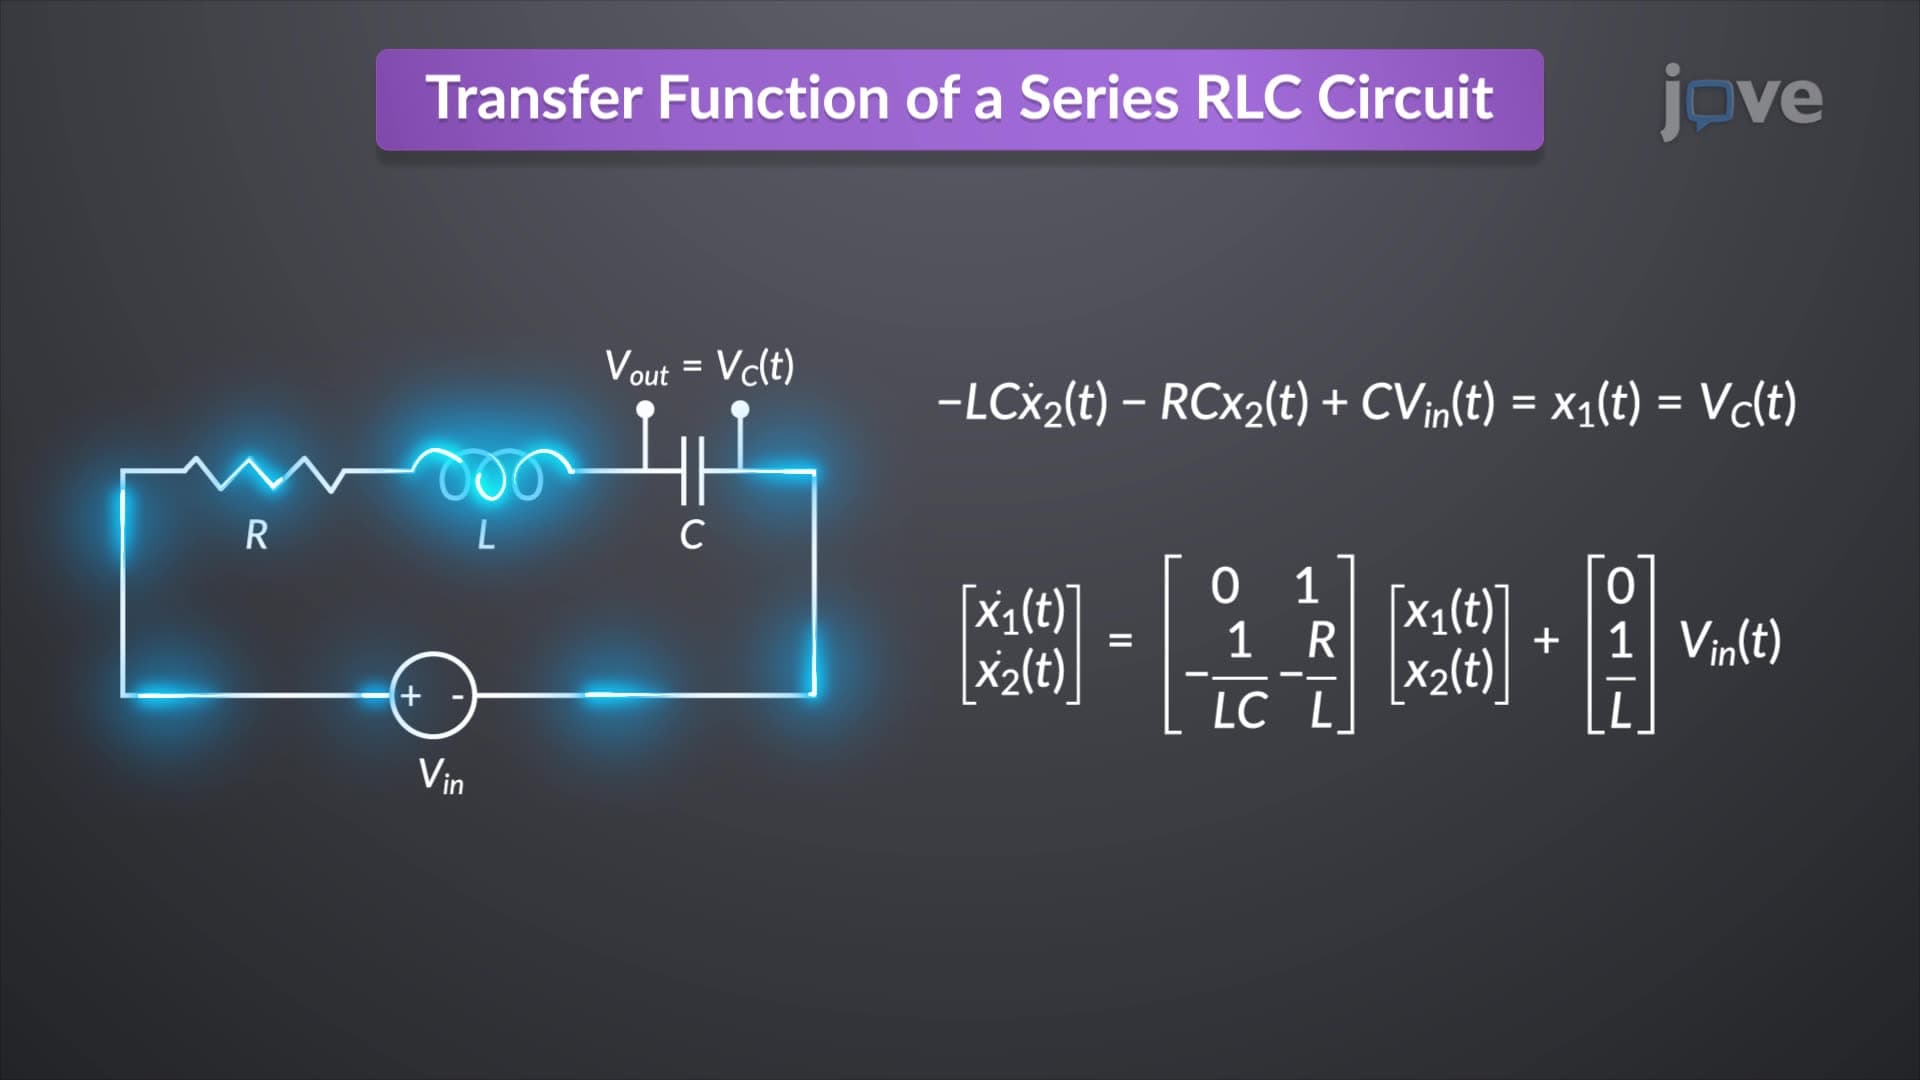
Consider an RLC circuit, a...
 01:23
Transfer Function to State Space
In an RLC...