Dynamical analysis and adaptive prescribed-performance backstepping control of two electrostatically coupled MEMS resonators with optimization
Related Experiment Video
Updated: Jan 9, 2026

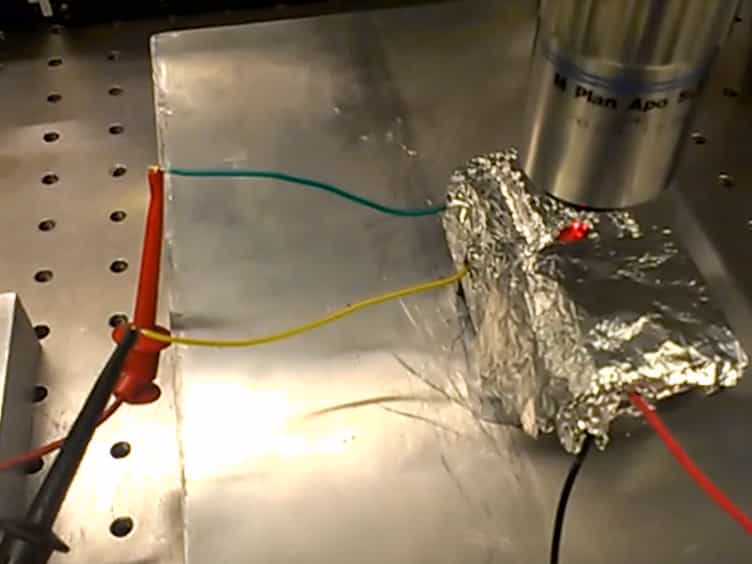
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
Yeqing Shan1, Guangying Lv1, Fengyun Li2
1College of Mathematics and Statistics, Nanjing University of Information Science and Technology, Nanjing 210044, China.

Abstract:
This paper investigates the dynamical analysis and adaptive prescribed-performance backstepping control for the coupled MEMS resonators with nonlinear dynamics. The dynamical model of such resonators is established considering the mutual interactions. Then, we examine and reveal the inherent chaotic behaviors that noticeably influence the system sensitivity, using time histories, phase diagrams, bifurcation diagrams, and Lyapunov exponents. In the subsequent controller design, we introduce a type-2 fuzzy wavelet neural network (T2FWNN) to estimate the uncertainties in the system. In backstepping, a speed function and prescribed performance functions are employed to reconstruct the error signals thereby achieving accelerated convergence and the high-precision control. Meanwhile, an accelerated tracking differentiator (ATD) with the speed function is design to address the intrinsic problem of 'complexity explosion' of traditional backstepping. Moreover, the particle swarm optimization (PSO) is integrated to tune the control parameters and to minimize the cost function. Besides, we prove that all signals of the closed-loop system are ultimately bounded through stability analysis. Finally, simulation results verify that all control targets such as chaos suppression, accelerated convergence, prescribed performance and optimization are all achieved. Compared with existing methods, the proposed control scheme exhibits superior performance in terms of both accuracy and convergence speed, achieving RMS control errors of 0.0016, 0.1126, 0.012, and 0.1126 respectively.
More Related Videos
 15:25
Design and Characterization Methodology for Efficient Wide Range Tunable MEMS Filters
Published on: February 4, 2018
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:17
Design Example: Underdamped Parallel RLC Circuit
Starting with a fixed...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:20
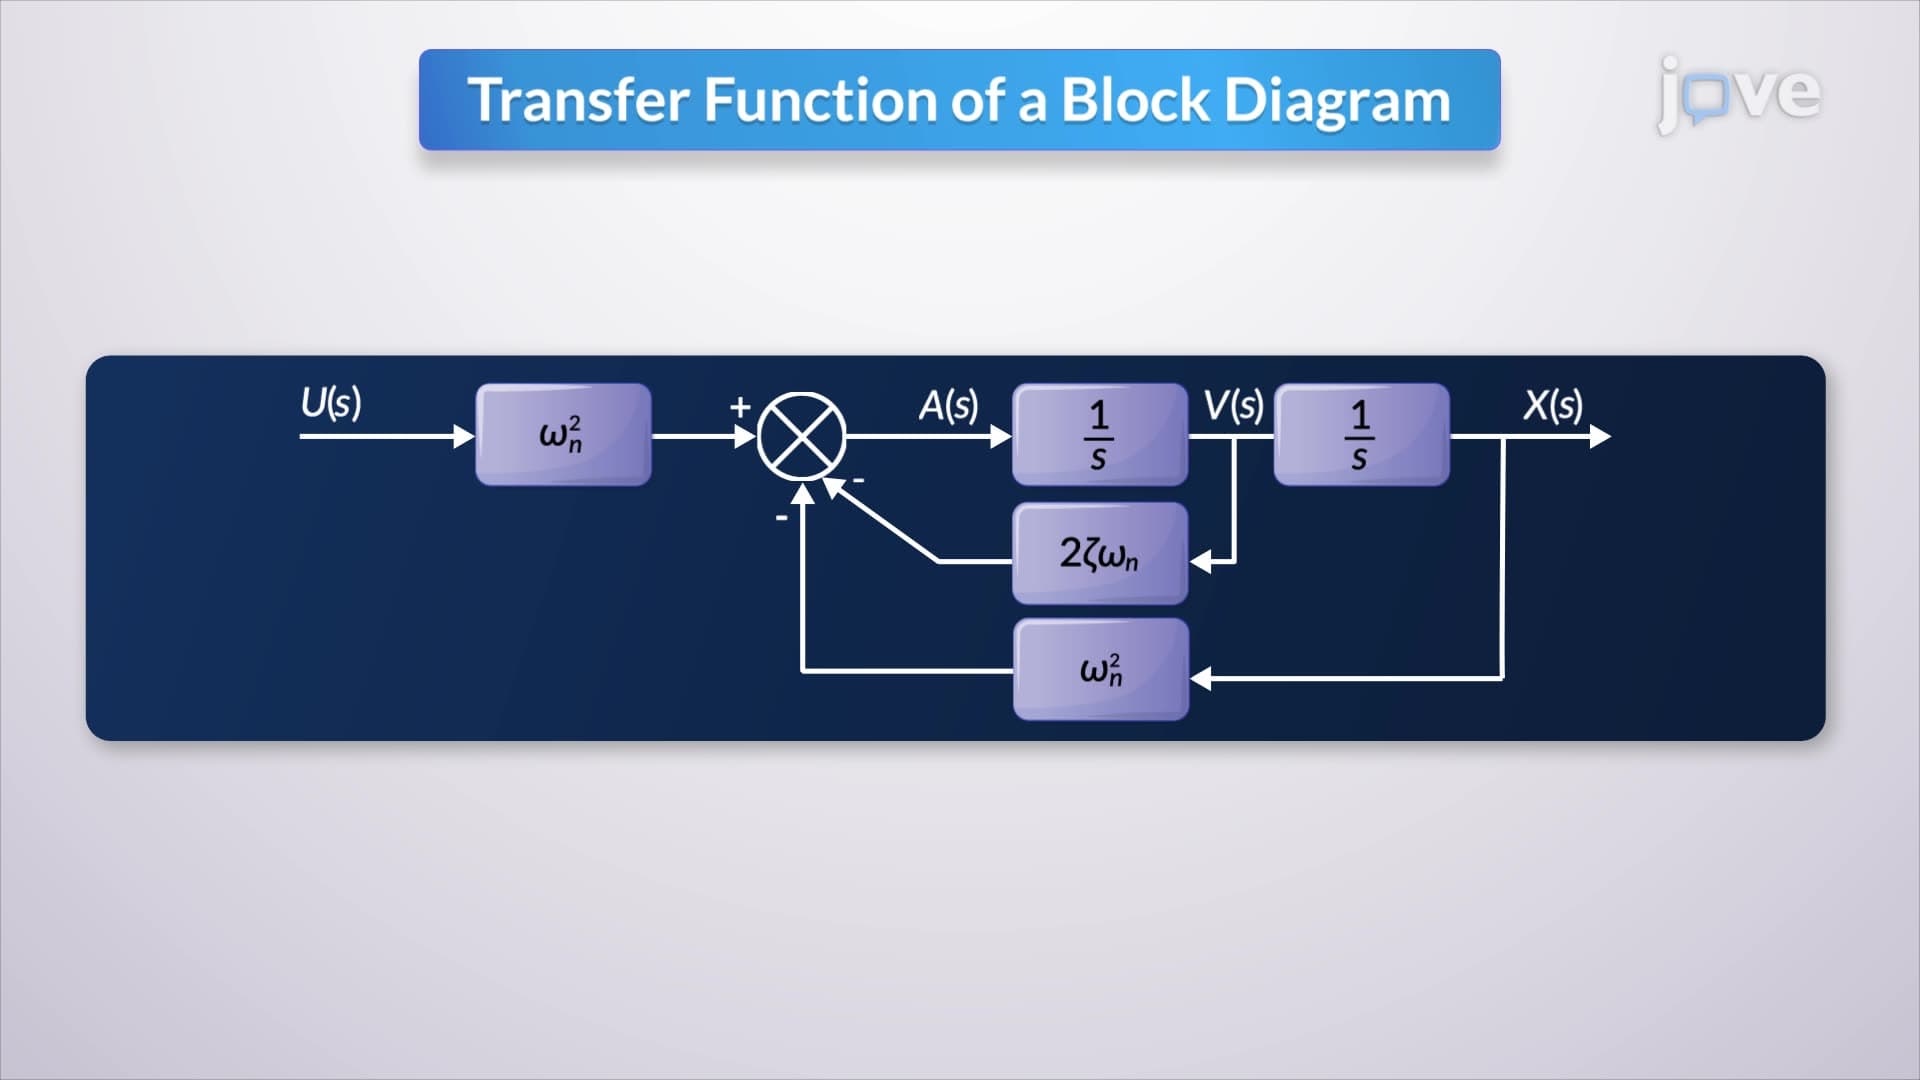
Relation between Mathematical Equations and Block Diagrams
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...