Related Experiment Video
Updated: Jan 9, 2026


Cardiac Muscle-cell Based Actuator and Self-stabilizing Biorobot - PART 1
Published on: July 11, 2017
Dynamic responses of a vibro-impact capsule robot self-propelling in the large intestine via multibody dynamics
Zepeng Wang1, Jiyuan Tian1, Yang Liu1
1Exeter Small-Scale Robotics Laboratory, Engineering Department, University of Exeter, Exeter, EX4 4QF UK.

Abstract:
In recent years, colonic capsule endoscopy has become available in clinical practice as an alternative modality to colonoscopy. However, it faces challenges such as prolonged examination time and the absence of clinician navigation. Leveraging their pioneering work in the field of vibro-impact self-propulsion technique for gastrointestinal endoscopy, Zhang et al. (IEEE Robot. Autom. Lett. 8:1842-1849, 2023) developed a novel, untethered, self-propelled, endoscopic capsule robot, with the aim of providing a new means of examining bowel cancer in real time. To evaluate and optimize the passage of this capsule robot self-propelling in the large intestine, this work adopts multibody dynamics analysis and experimental investigation to study the robot's dynamics and its interaction with the intestinal environment. Considering the complex anatomy of the large intestine, containing different sections, e.g., cecum, ascending, transverse, descending, and sigmoid colon, and variations of the haustra, e.g., with various radii, lengths, and heights, the robot was driven by the square-wave excitation of an inner mass interacting with the capsule body and tested on a real porcine colon. The robot's driving parameters, including the excitation frequency, amplitude, and duty cycle, and the dimensions of the haustra are the two main factors influencing the robot's progression in the intestine. By comparing with the experimental results, the proposed multibody dynamics model developed using MSC Adams can estimate the movement of the capsule robot and the intestinal resistance quantitatively. Extensive numerical and experimental studies suggest an excitation frequency of 60 Hz and a duty cycle of 0.4 as the optimal parameters for driving the robot, and the longer the haustral length is, the faster the robot passes through. These results ensure the validity of the proposed multibody dynamics platform, which can be used by robotic engineers for developing medical robots for intestinal examinations.
Supplementary Information:
The online version contains supplementary material available at 10.1007/s11044-025-10052-6.


Related Concept Videos
 01:22
Physiology of the Gastrointestinal System I: Ingestion and Propulsion
 01:13
Cell-matrix's Response to Mechanical Forces
Anchoring junctions mechanically attach a cell to the...
 01:26
Imaging Studies III: Gastrointestinal Motility Studies and Virtual Colonoscopy
Radionuclide Testing
Radionuclide testing is a sophisticated medical technique for assessing gastrointestinal motility. It focuses on gastric emptying and colonic transit time. Radioactive markers track the movement of food through the digestive system, providing insights into gastrointestinal disorders.
In gastric emptying studies, a meal's liquid and...
 01:13
Kinetic Energy for a Rigid Body
 01:11
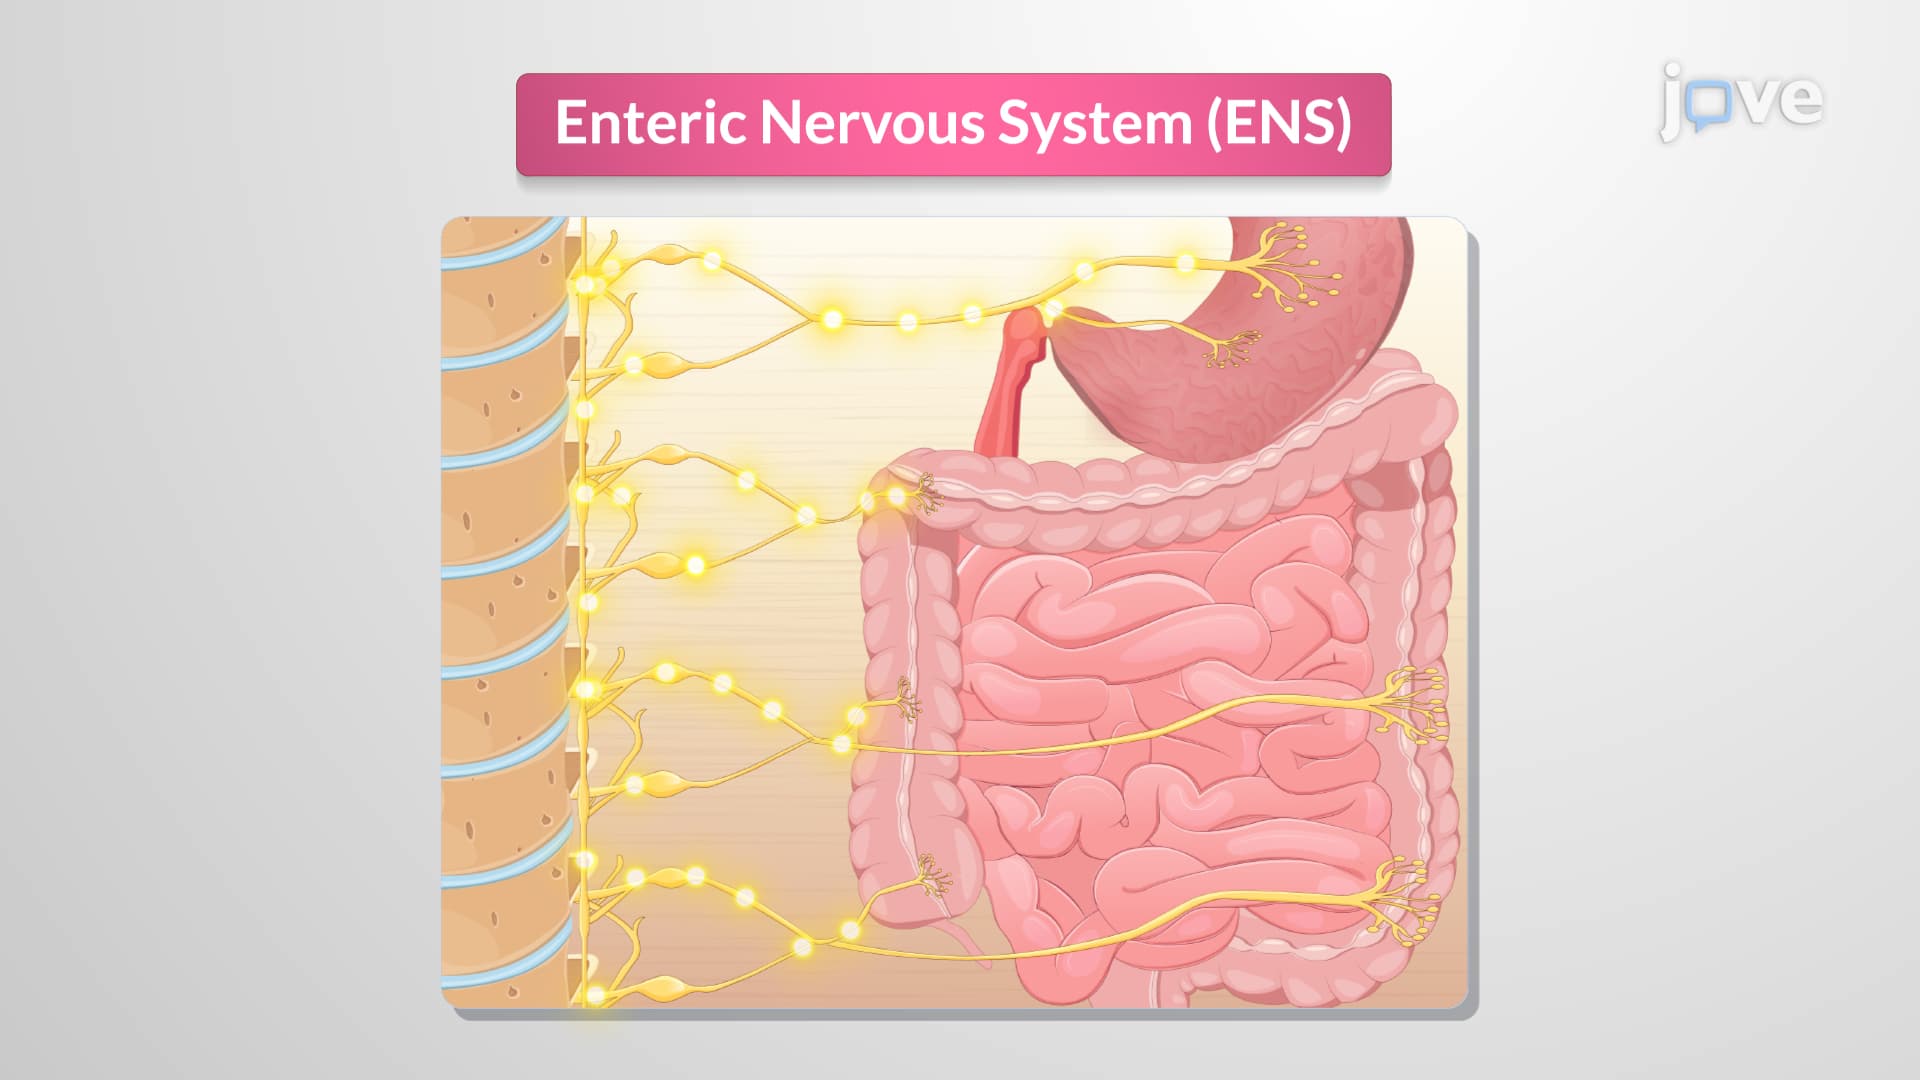
Enteric Nervous System: Regulation of GI Motor Activity
During periods of fasting, the ENS initiates the migrating myoelectric complex, a...
 01:30
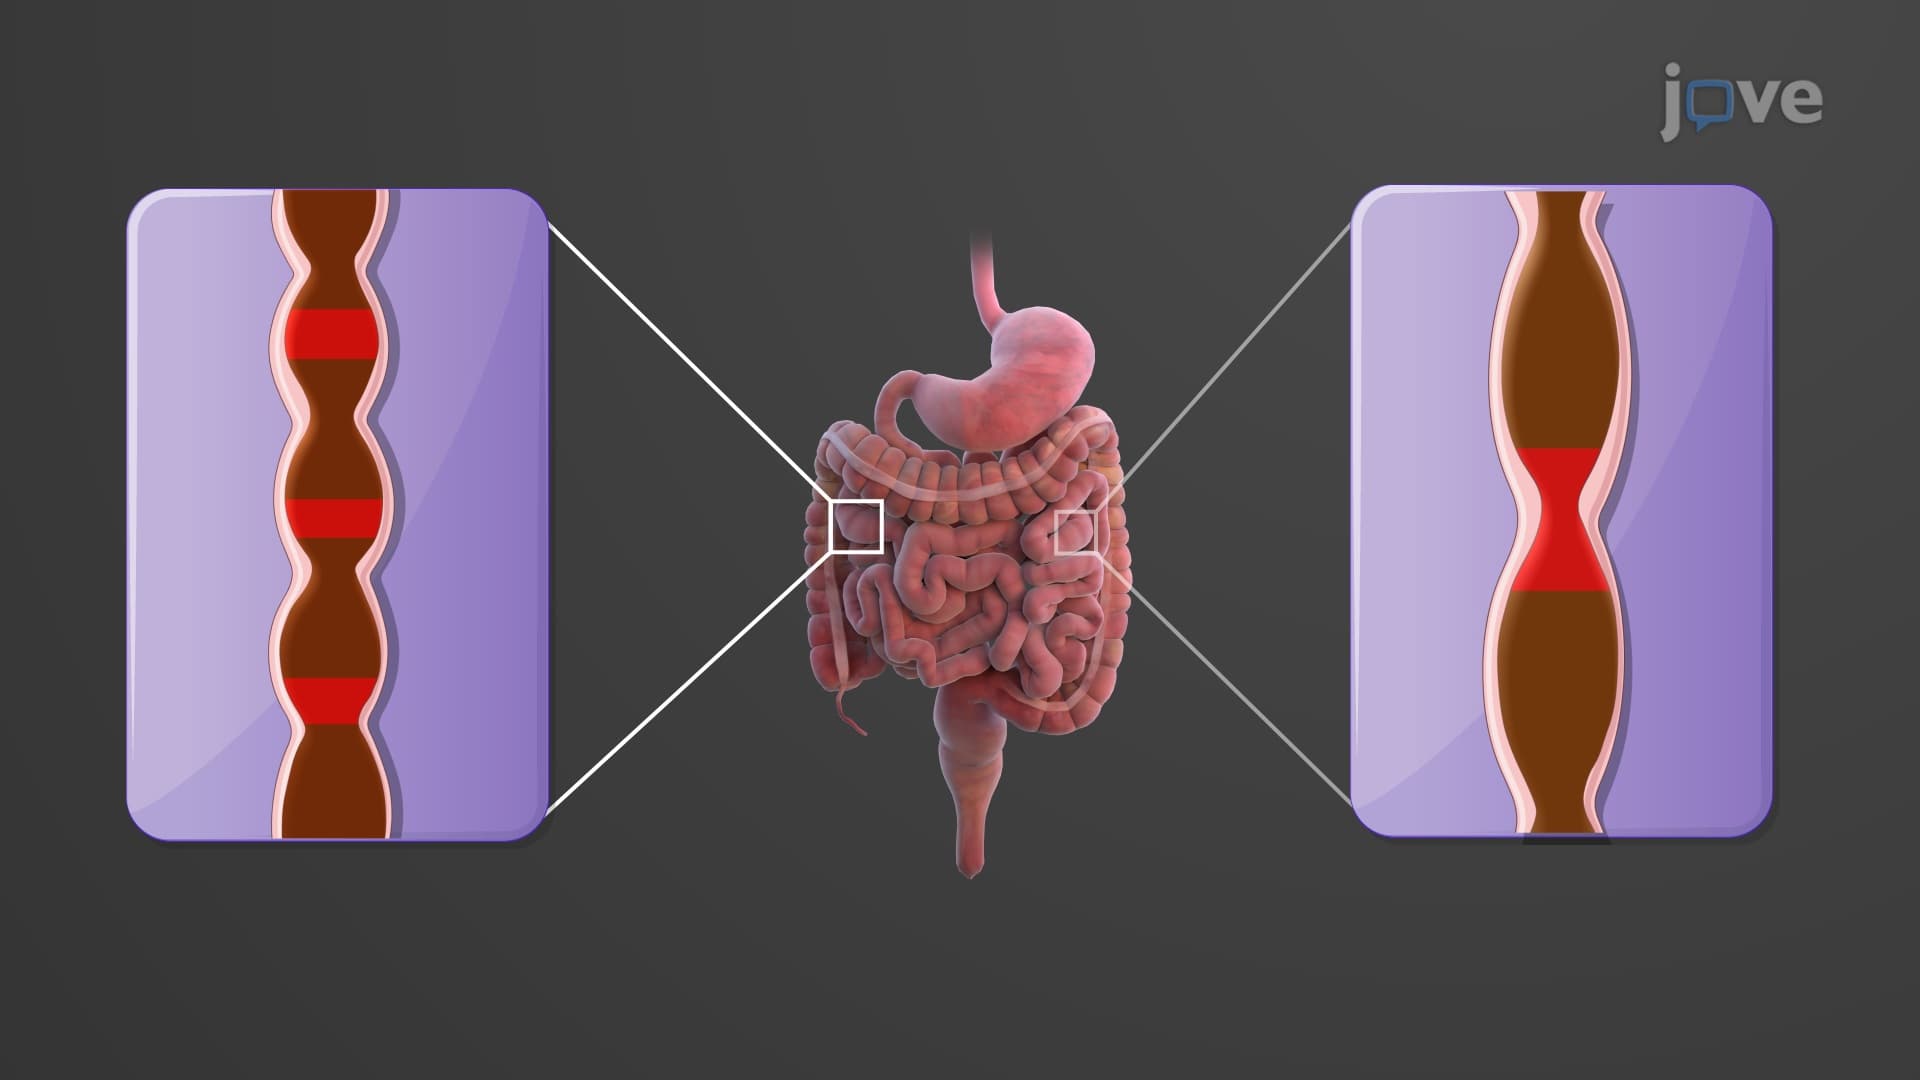
Mechanical and Chemical Digestion in the Small Intestine
Mechanical digestion in the small intestine involves movements such as segmentations and migrating motility complexes (MMCs), primarily controlled by the myenteric plexus. Segmentations are localized contractions occurring in areas of the intestine distended by chyme—a mixture of partially digested food. These contractions mix chyme with digestive juices, facilitating...