Related Experiment Video
Updated: Jan 9, 2026


Haptic/Graphic Rehabilitation: Integrating a Robot into a Virtual Environment Library and Applying it to Stroke Therapy
Published on: August 8, 2011
Nonlinear error augmentation applied to upper limb movements enhances motor learning

Abstract:
We investigated adaptation to a nonlinear, power-based error-augmentation feedback to assess the hypothesis that it can promote effective motor learning. Two groups of healthy adults (experimental and control groups) participated in a study involving a planar reaching task. Participants' hand was occluded from view. The hand held the puck of a graphics tablet, which tracked its movement, represented by a round cursor moving in a display placed in front of the participant. Canonical Familiarization, Baseline, Adaptation, and Washout phases characterize the experiment. In the control group, all four phases involved a 1:1 mapping between hand and cursor position, whereas, in the experimental group, real trajectories were distorted by a nonlinear function according to a power-based error-augmentation approach, during the Adaptation phase. The experimental group showed learning increase and average error reduction. The proposed approach extends the error augmentation techniques proposed so far, and may be useful for inducing motor learning in teleoperation, sports, and rehabilitation contexts.
More Related Videos
 04:49
Author Spotlight: Enhancing Post-Stroke Upper Limb Rehabilitation with Robotic Technologies for Improved Motor Recovery and Functional Outcomes
Published on: September 6, 2024
 05:28
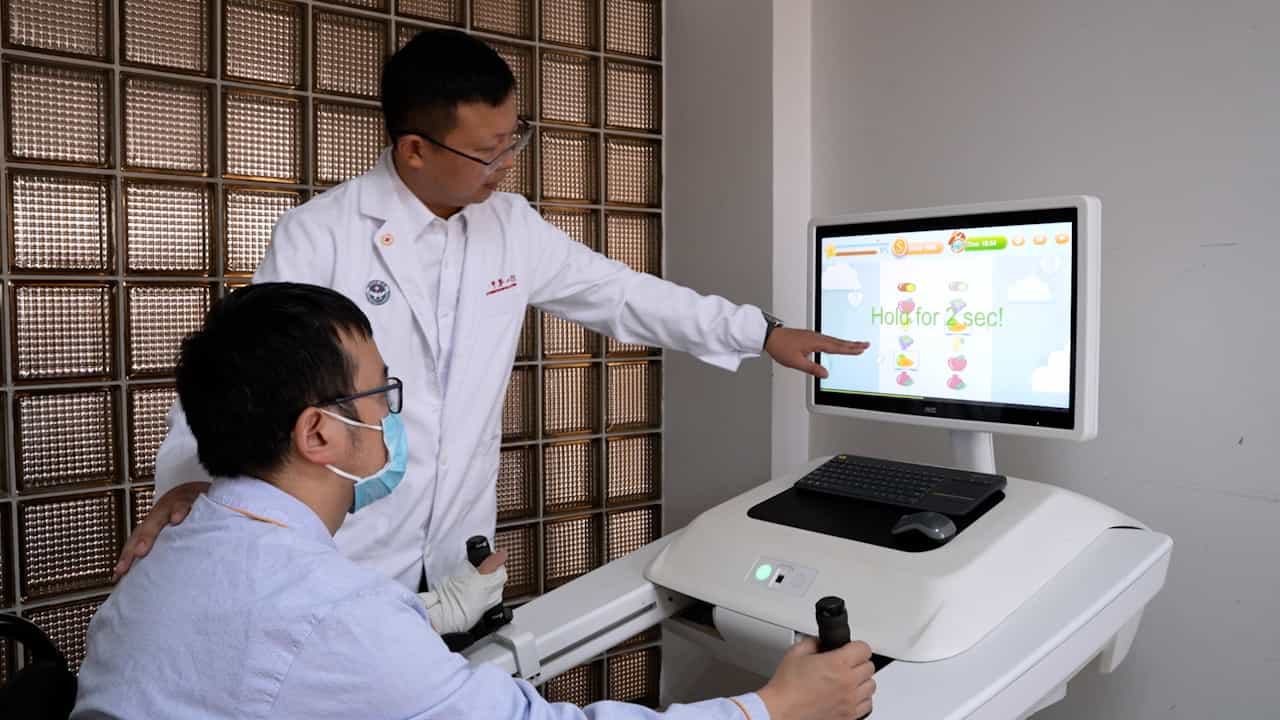
Author Spotlight: Enhancing Upper Limb Rehabilitation in Stroke Patients Through Advanced Robotic and Neuromodulation Technologies
Published on: October 11, 2024