Related Experiment Video
Updated: Jan 7, 2026
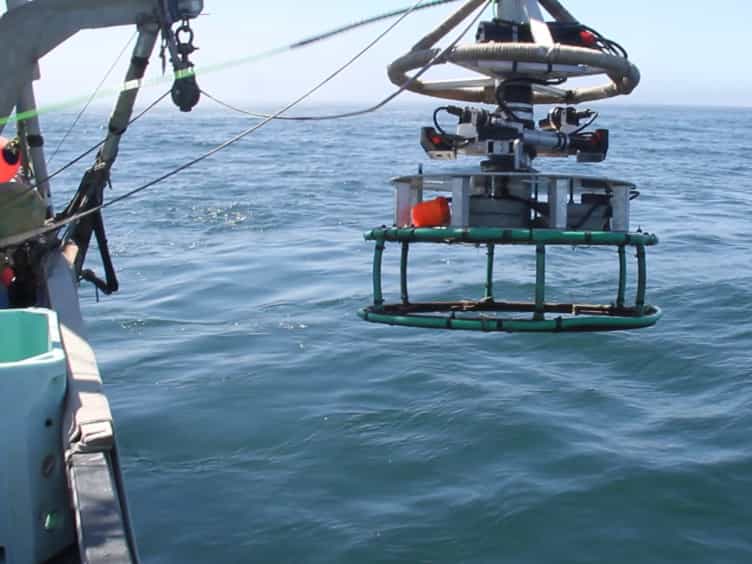
Development of New Methods for Quantifying Fish Density Using Underwater Stereo-video Tools
Published on: November 20, 2017
An open-source underwater robotics platform for aquatic research & exploration
Scott Mayberry1, Jinzhi Cai1, Ruochu Yang1
1Georgia Institute of Technology, Hong Kong University of Science and Technology, United States.

Abstract:
Underwater research is often constrained by the specialized expertise, high costs, and dedicated facilities required for traditional aquatic experiments, limiting participation from smaller research groups. In response, we introduce an open-source miniature underwater robot (MUR) platform that broadens access to aquatic research and exploration while simplifying experimental implementation. Built on a fully networked ROS ecosystem, our platform integrates advanced sensing, control, and versatile communication capabilities to support real-time data acquisition and sensor fusion. Its modular 5-degree-of-freedom propulsion system enables precise position, yaw, and roll control, with passive pitch stability through neutral buoyancy supporting steady station-keeping and dynamic trajectory tracking. Equipped with multiple cameras, the system facilitates advanced perception tasks essential for complex underwater operations. Moreover, WiFi, radio, and high-speed Ethernet tethering ensure communication in shallow water environments, enabling both autonomous operation and tethered deployments. This open, modular architecture reduces barriers to underwater research while promoting collaborative innovation and establishing a shared research infrastructure for marine science and robotics.
More Related Videos
Related Concept Videos
 01:11
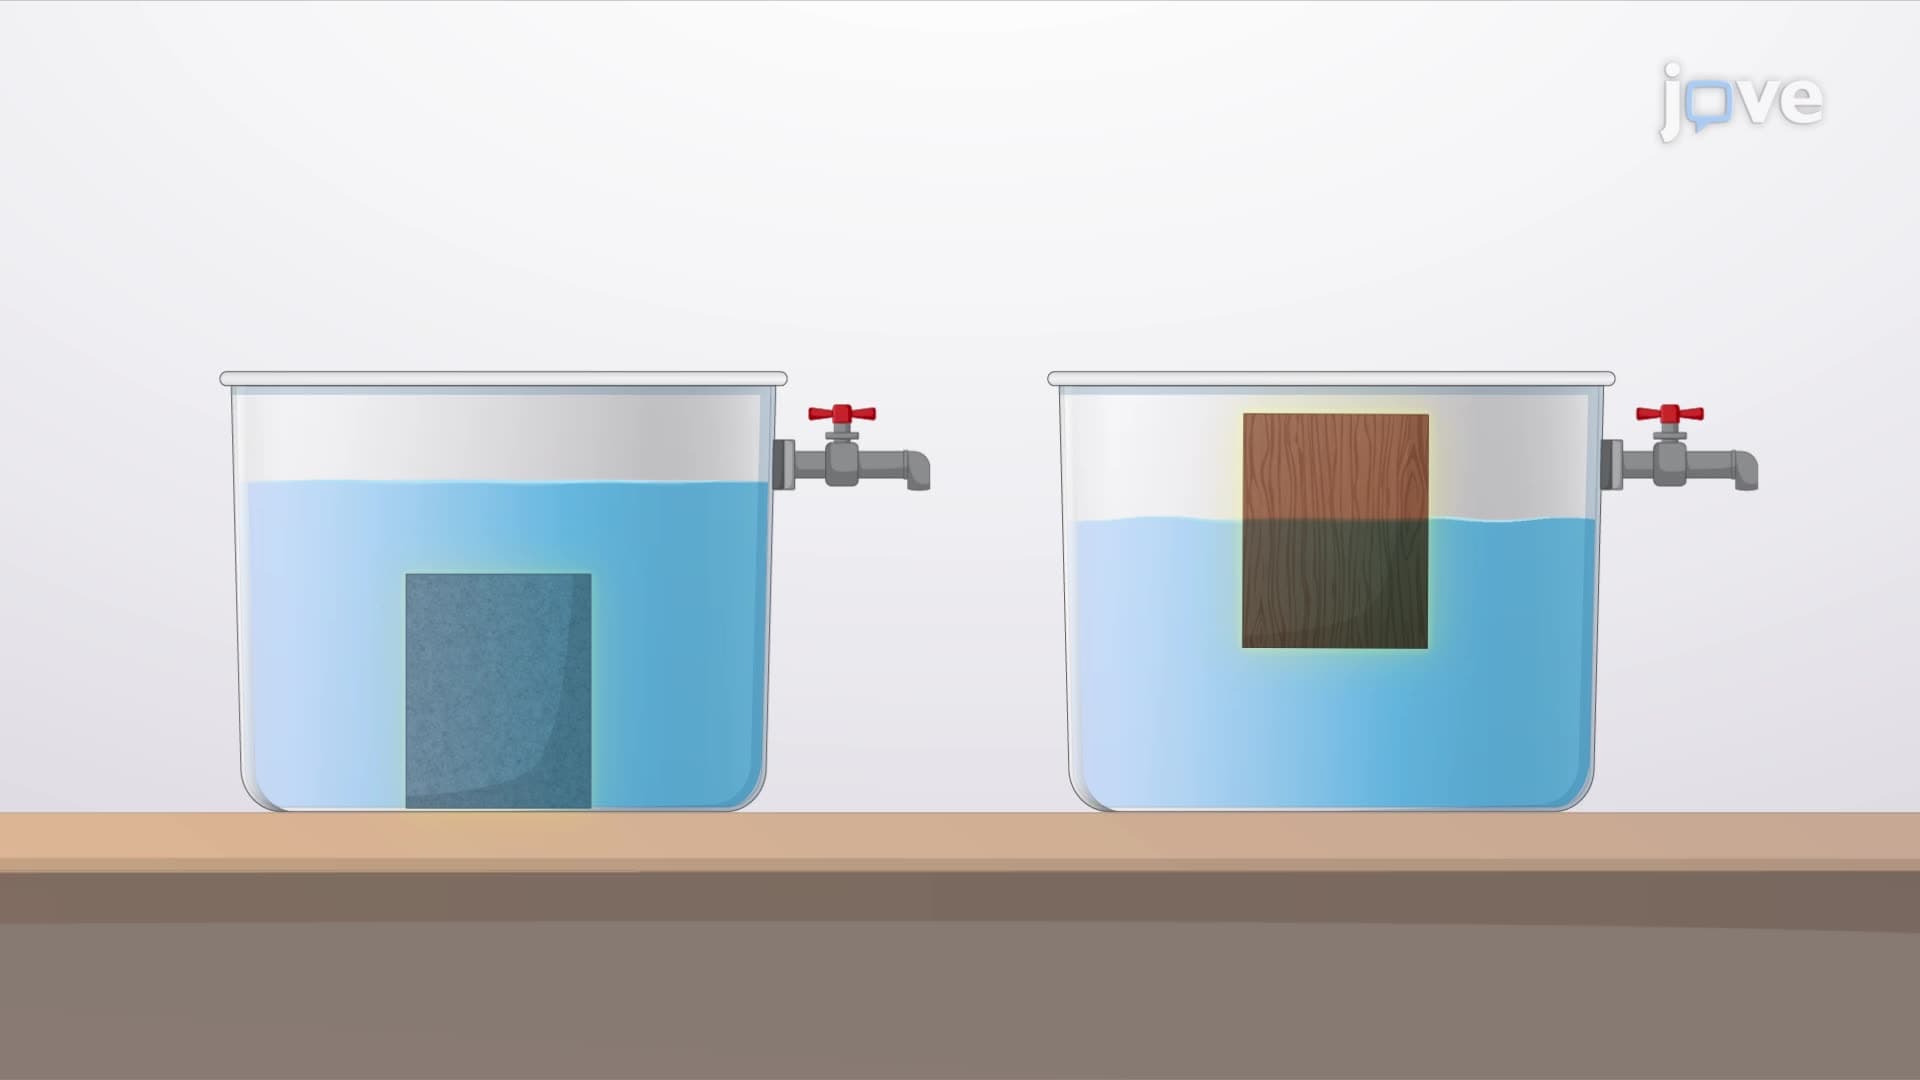
Buoyancy and Stability for Submerged and Floating Bodies
 01:12
Buoyancy
 01:14
Testing Water Quality
 02:32
Osmoregulation in Fishes