Related Experiment Video
Updated: Jan 9, 2026

Quantitatively Measuring In situ Flows using a Self-Contained Underwater Velocimetry Apparatus SCUVA
Published on: October 31, 2011
Numerical study on the load characteristics of deep submarine rescue vehicle under the internal solitary waves
Houyang Zhong1, Chenchen Liu1, Xizhong Wei2
1PLA Navy Submarine Academy, Qingdao, 266042, China.

Abstract:
In marine environments, strong nonlinear internal solitary waves (ISWs) frequently occur. Due to their significant energy, ISWs have a substantial impact on the deep submergence rescue vehicle (DSRV). This study uses computational fluid dynamics (CFD) methods to establish a numerical model for the stable propagation of ISWs and their interaction with a fixed DSRV, aiming to clarify the effects on the DSRV. Changes in depth lead to transitions in the flow field experienced by the structure. Initially, the flow is dominated by the upper fluid layer, then by both the upper and lower layers, and finally by the lower layer. Consequently, the load characteristics of the structure are complex and variable. Additionally, the drag and lift forces on the DSRV change significantly as it moves through ISWs. Changes in yaw angle result in an exponential increase in drag, according to the sine of the yaw angle. They also cause varying degrees of lift attenuation, complicating the maneuverability of the DSRV when encountering ISWs. Therefore, the effects of depth and yaw angle on the DSRV's performance should not be overlooked when encountering ISWs.
Related Concept Videos
 01:11
Buoyancy and Stability for Submerged and Floating Bodies
 01:30
Typical Model Studies
 01:16
Hydraulic Jump: Problem Solving
 01:22
Design Consideration
The factor of safety is another key...
 01:21
Design Example: Creating a Hydraulic Model of a Dam Spillway
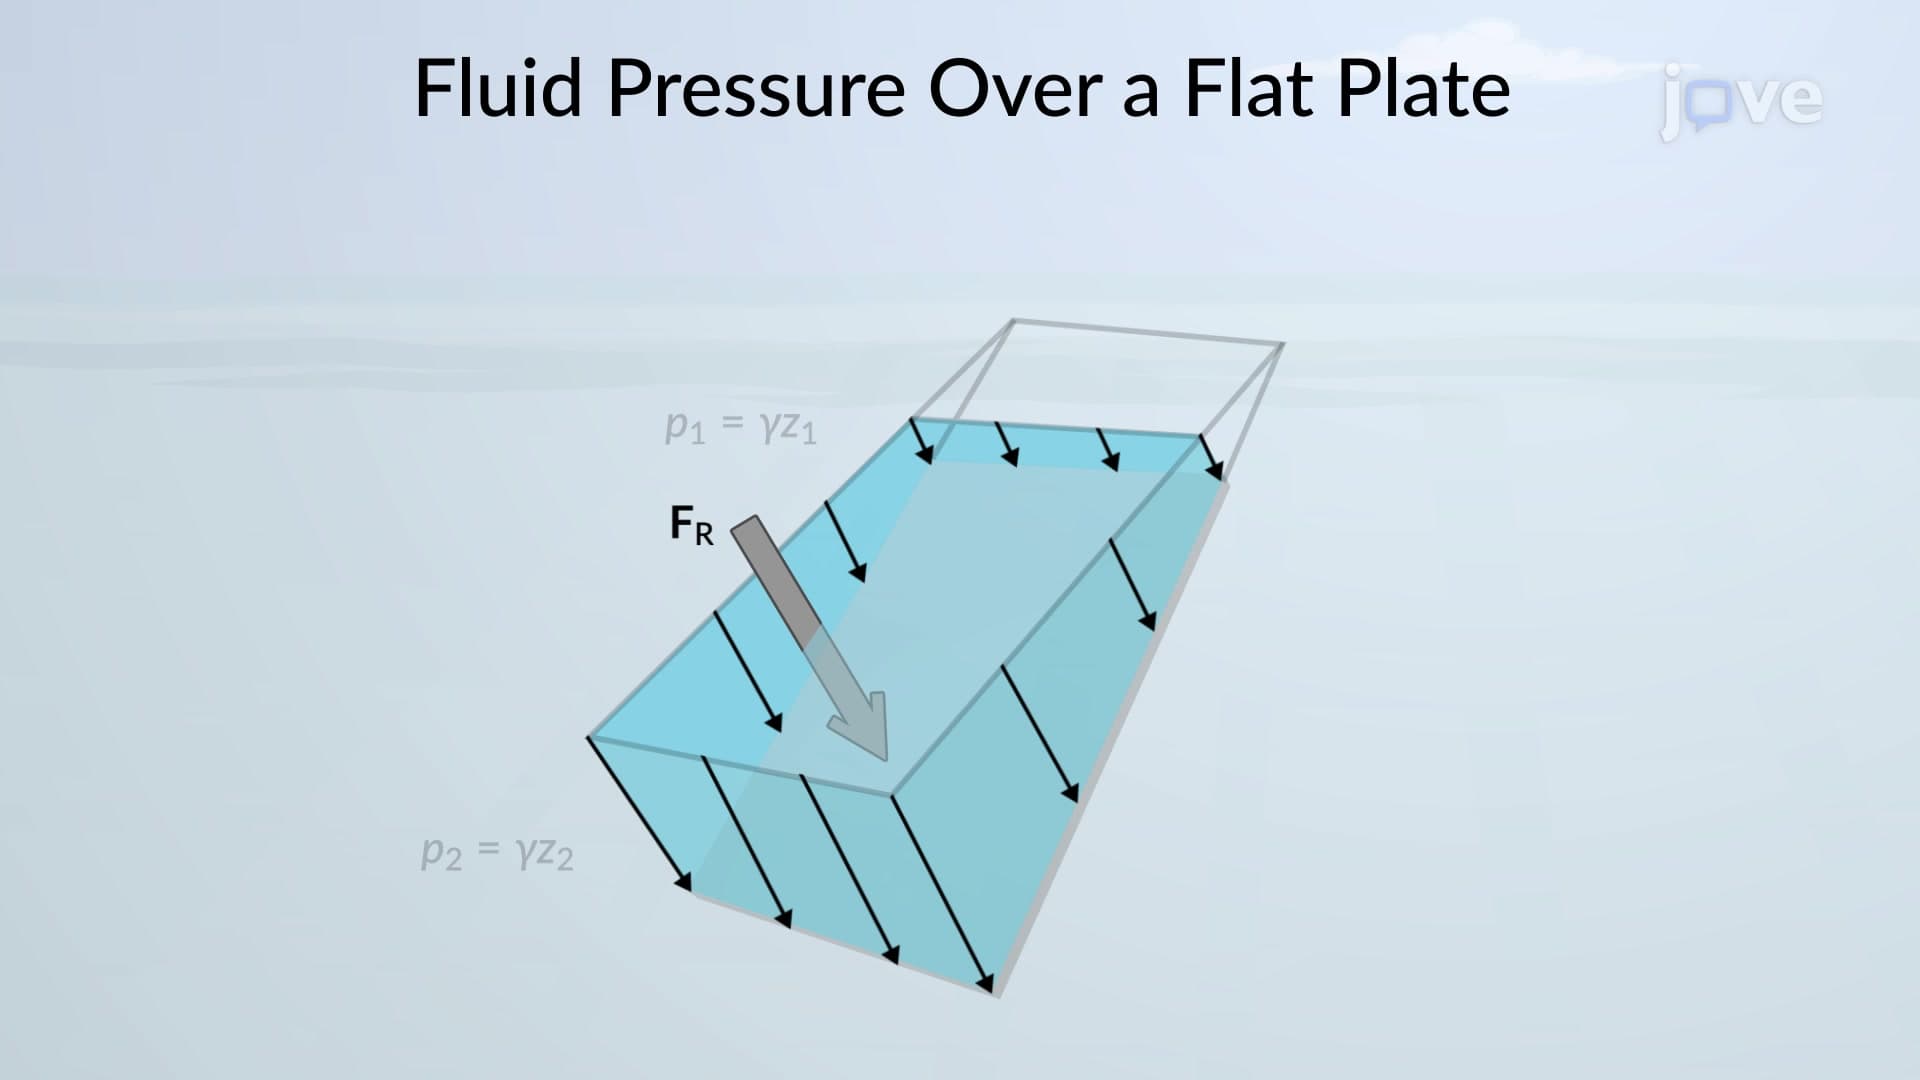 01:05
Fluid Pressure over Flat Plate of Constant Width
The resultant force...