Related Experiment Video
Updated: Jan 8, 2026
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
A framework for reconfigurable production line changeover task planning based on large language model
Jinliang Hou1, Li Yan2, Hua Qiang3
1Xi'an Technological University, Xi'an, China. houjinliang@st.xatu.edu.cn.

Abstract:
Addressing the issues of manual intervention, low efficiency, and high error rates in the changeover operations of reconfigurable production lines, this paper proposes an automatic changeover task planning framework for reconfigurable production lines based on Large Language Model(LLM). Utilizing this framework, the instructions input by the user can be interpreted, and the changeover robot can be controlled to automatically complete the changeover of the production line.The framework is primarily composed of five essential components: knowledge graph, high-level task planner, low-level task planner, changeover robot, and reconfigurable production line. The knowledge graph is utilized to depict the attributes and interrelationships of products, processes, tool & fixture tool & fixture resources, and programs of the reconfigurable production line.The semantic instructions input by the user are interpreted by the high-level task planner, which then decomposes the task into changeover subtasks, matches robot skills to each subtask, and generates a sequence of skills. With the low-level task planner, the sequence of skills is translated into executable code for the changeover robot, which controls the robot to complete the automatic changeover task. A low-code industrial software is designed to implement skill-based modular programming, and the four-layer control architecture including the physical, control, skill, and application layers has been implemented. The changeover robot was designed and fabricated. Through single-robot task planning experiment and actual production line changeover task planning experiment, the correctness of the proposed changeover task planning framework is demonstrated, automatic changeover of the production line can be realized.


Related Concept Videos
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
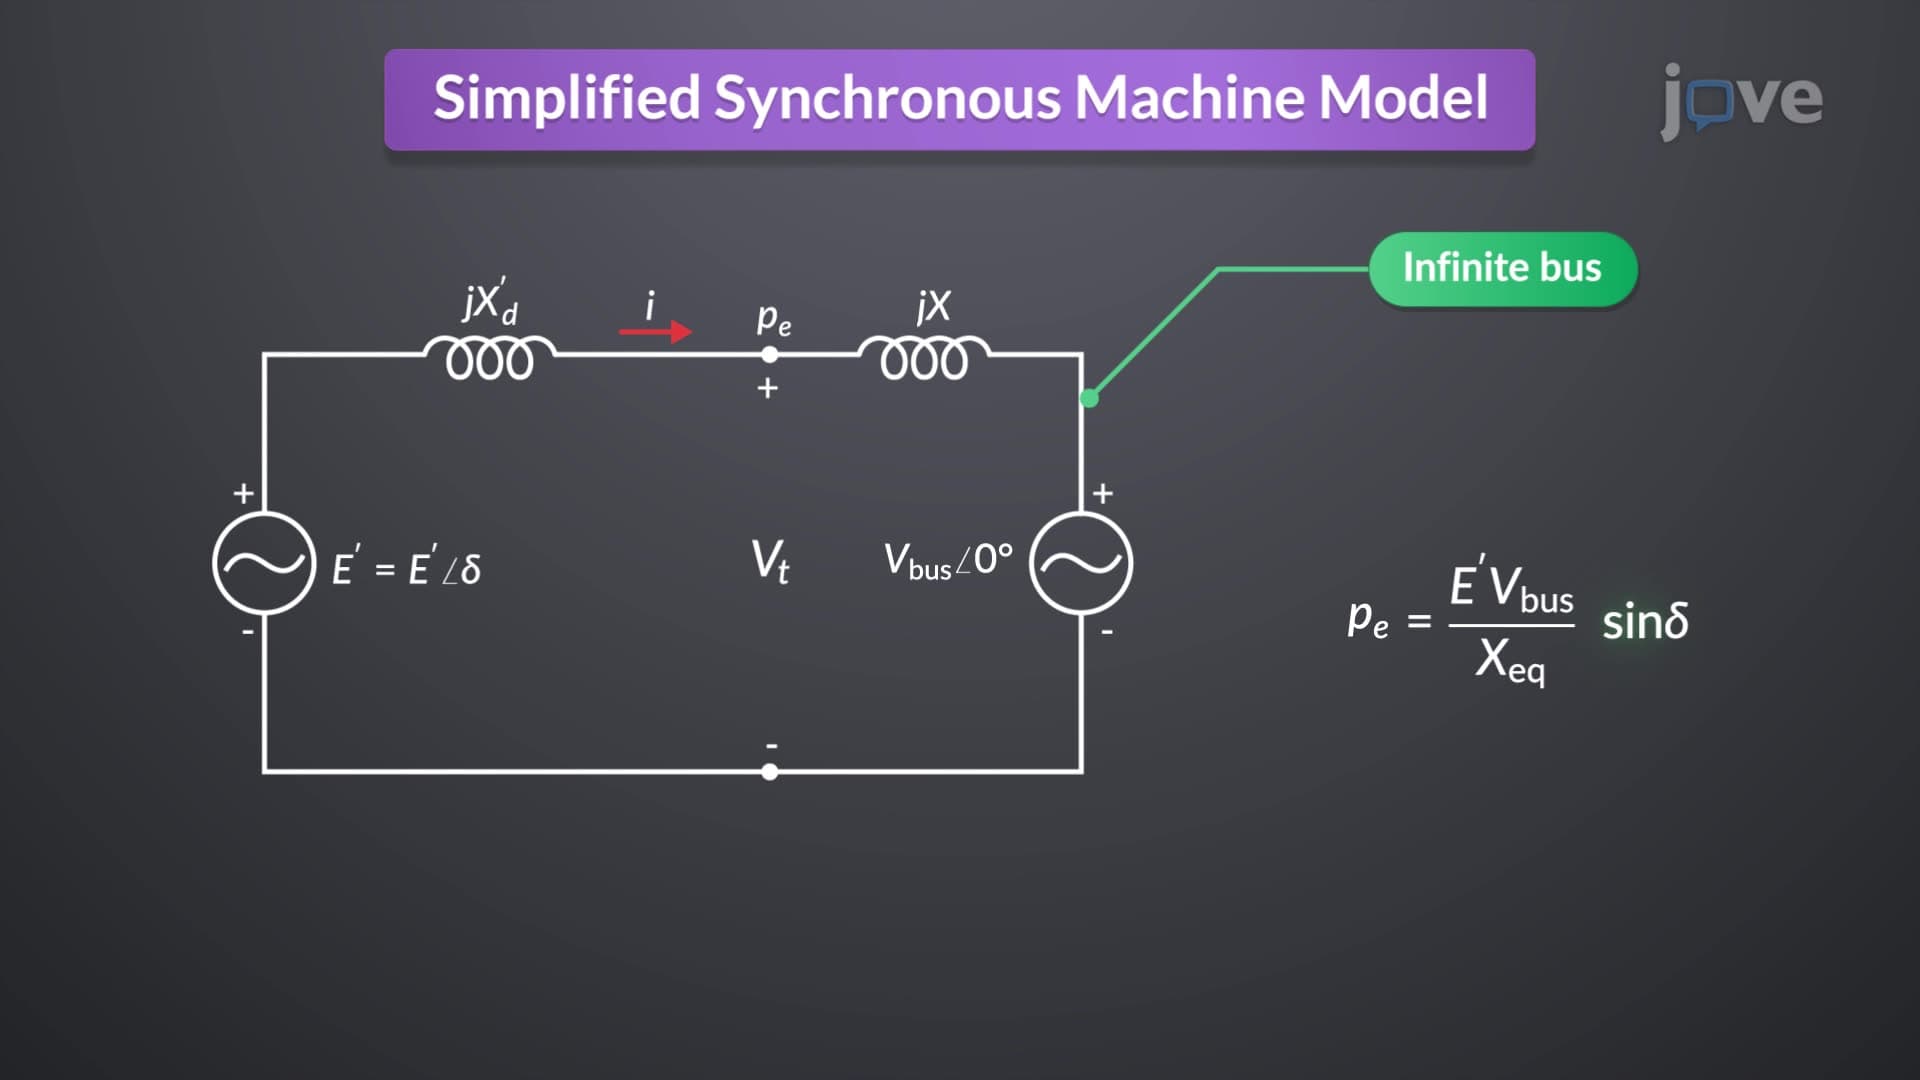 01:30
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
 01:16
Statically Indeterminate Problem Solving
 01:30
Machines: Problem Solving II
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...