Related Experiment Video
Updated: Jan 8, 2026

Easy and Accurate Mechano-profiling on Micropost Arrays
Published on: November 17, 2015
Mechanisms of anisotropic wet friction in bioinspired hexagonal pillar arrays
Meng Li1, Maomao Zhang1, Congfeng Wang1
1School of Mechanical Engineering, Anhui University of Technology, Ma'anshan, 243032, China.

Abstract:
Anisotropic friction under wet conditions is essential for biological attachment and emerging robotic applications, yet its governing mechanisms remain unclear. Inspired by the microstructure of tree frog toe pads, hexagonal micropillar arrays with varying geometric parameters were fabricated, and their wet friction behavior was systematically investigated. The results show that the pillar aspect ratio (γ) predominantly determines directional friction performance. A pronounced friction enhancement occurs within 0.25 < γ < 0.64, with the highest anisotropy at γ = 0.375, where side-sliding friction is 126 % higher than corner-sliding. This anisotropic enhancement arises from more efficient drainage and greater dry contact formation induced by surface warping and inter-channel constriction during pillar deformation. Interference imaging and theoretical modeling confirm that anisotropic friction originates from deformation-driven modulation of the lubrication film and dry contact area. These findings elucidate the structure-function relationship of hexagonal architectures and provide design principles for engineering bioinspired surfaces with controllable friction under wet conditions. STATEMENT OF SIGNIFICANCE: Directional friction under wet conditions is critical for biological and engineering systems that require controlled locomotion, attachment, or gripping in fluidic environments. Inspired by the hexagonal pillar arrays found on tree frog toe pads, this study elucidates the fundamental mechanisms by which aspect ratio and sliding direction govern anisotropic wet friction. By combining tribological experiments, optical interference analysis, and deformation modeling, we demonstrate that friction anisotropy arises from deformation-driven drainage - specifically, the coupled effects of inter-pillar channel contraction and top-surface warping. These insights establish a mechanistic framework linking microscale structural deformation to macroscale frictional performance, providing design principles for bioinspired surfaces with programmable friction. The findings have direct implications for soft robotics, medical tools, and wearable devices operating in wet or dynamic environments.
Related Concept Videos
 01:07
Frictional Force
 01:24
Wedges
Consider using a wedge to lift a heavy slab. Here, the wedge functions by converting the applied force into a much larger force directed almost perpendicular to the initial force. This...
 01:39
Mechanism of Filopodia Formation
Their main function is to guide migrating cells during normal tissue morphogenesis or cancer metastasis by recognizing and making initial contacts with the extracellular matrix. However, they can also act as stationary cell anchors or help to establish communication...
 01:58
Mechanical Protein Functions
 01:21
Characteristics of Dry Friction
Before the wheelbarrow starts moving, the static frictional force acts tangentially to the contact surface, opposing the force that is about to induce the motion. This frictional force prevents the...
 01:05
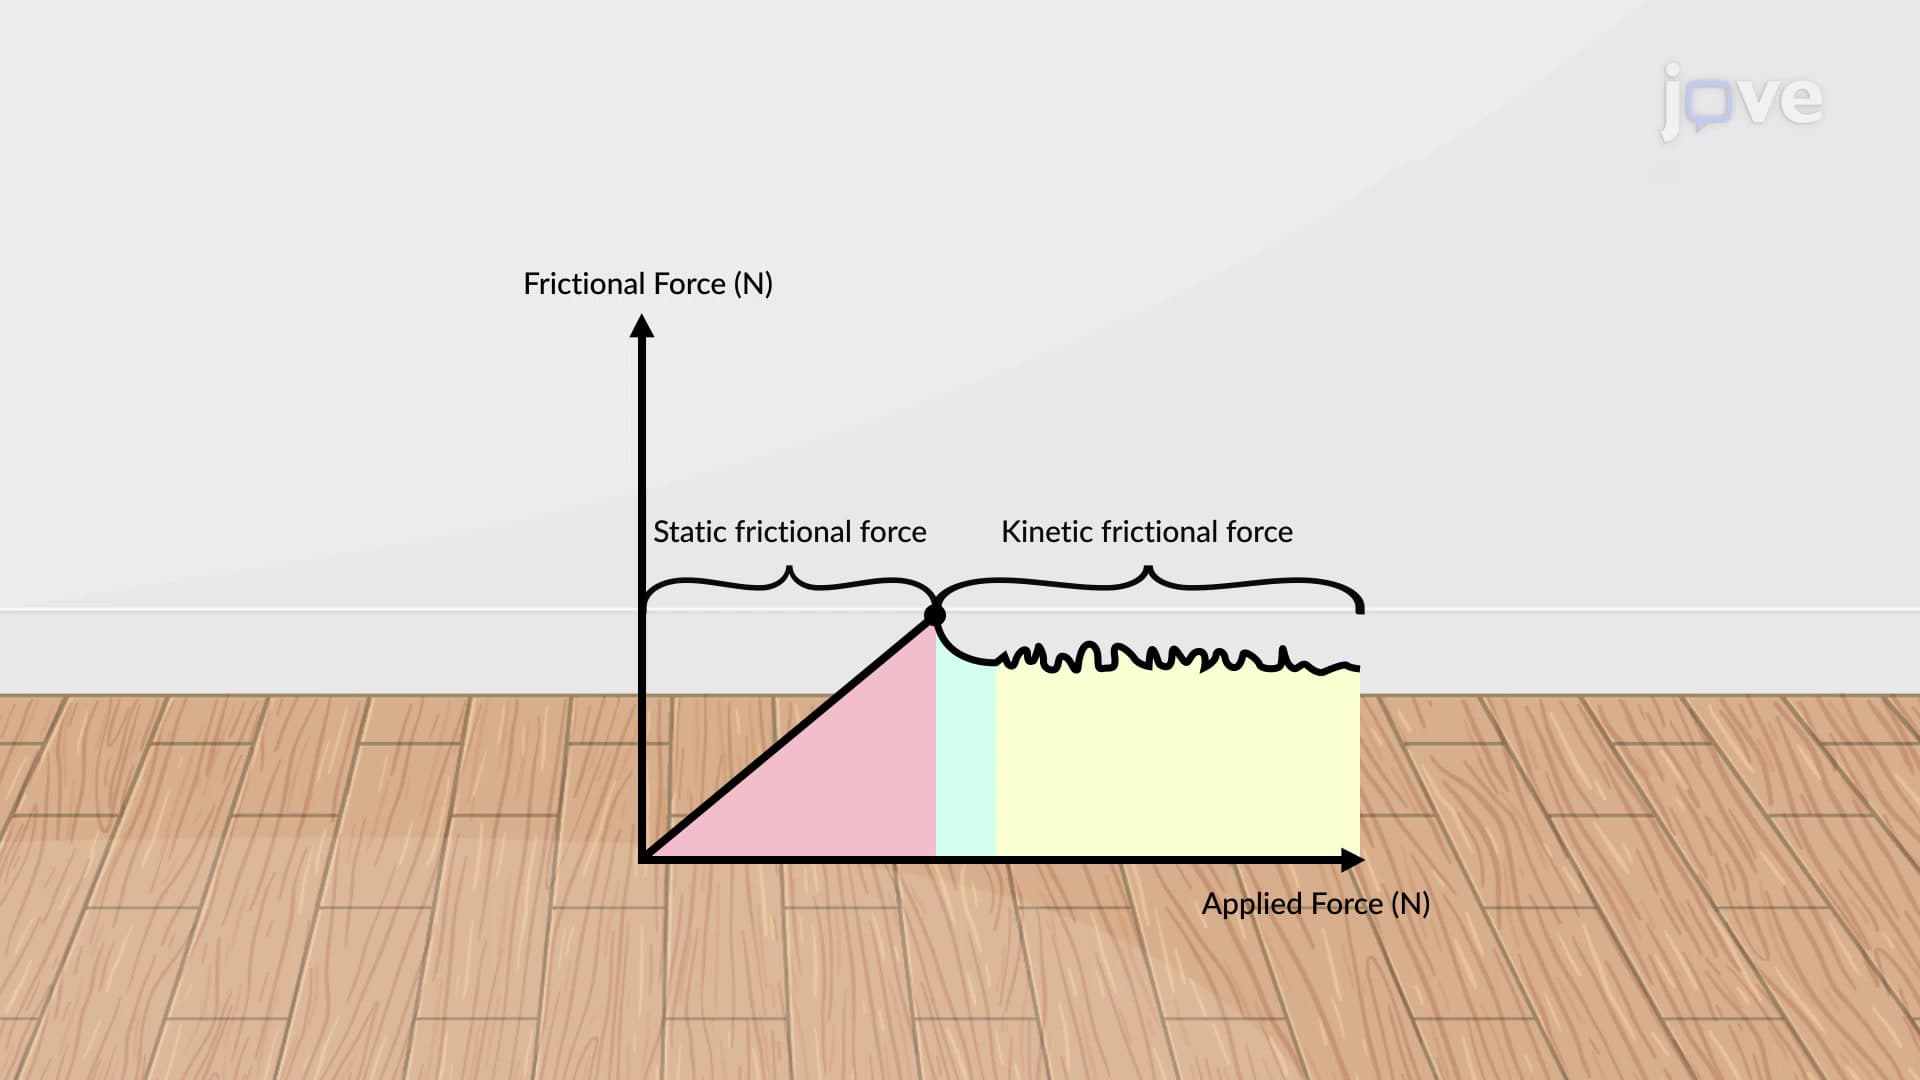
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...