Related Experiment Video
Updated: May 13, 2026

Technical Detail for Robot Assisted Pancreaticoduodenectomy
Published on: September 28, 2019
IDEAL-compliant implementation of the Dexter® surgical robot in cholecystectomy: a comprehensive framework and
Jonas Dohmen1,2, Julia Weber1,2, Jan Arensmeyer1,2
1Department of Surgery, University of Bonn, Bonn, Germany.

Objectives:
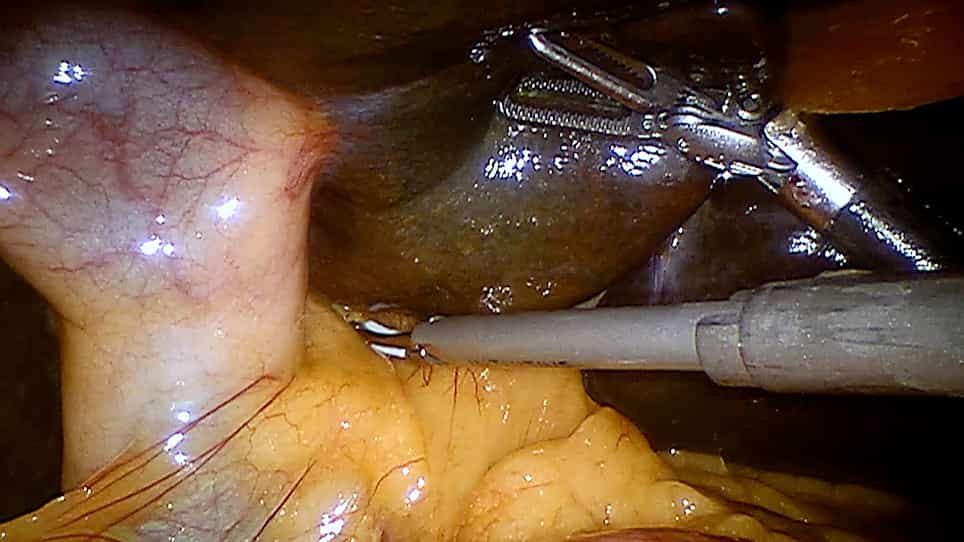
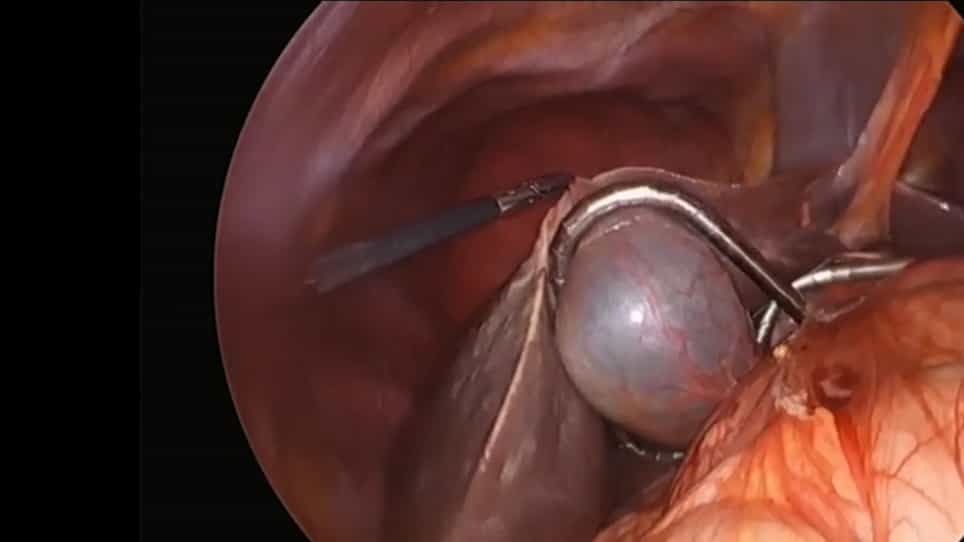
The integration of advanced technologies is transforming surgical practice, particularly through robotic systems. This study presents the early clinical implementation of the Dexter® surgical robot for cholecystectomy and evaluates clinical outcomes using the IDEAL framework.
Methods:
Twenty patients underwent elective robotic-assisted cholecystectomy using the Dexter® robot. A thorough implementation process, including rigorous surgeon and nurse training and standardized care protocols, was established. Data on operative metrics, complications, and patient outcomes were analyzed, and patient well-being was assessed via a postoperative phone survey.
Results:
Six surgeons and thirty nurses were trained, with surgeons completing a minimum of 20 h of simulation. Preoperative and operative times were significantly reduced through this process. Comparing the first 10 operations to the second, docking time decreased from 11.4 ± 4.1 min to 7.1 ± 2.1 min (p=0.0144) and operative time improved from 130.5 ± 25.7 min to 99.7 ± 21.8 min (p=0.0134). Mean intraoperative blood loss was minimal, averaging 19.5 ± 31.4 mL, and the average length of hospital stay was 3.1 ± 1.4 days. Postoperative pain levels were low, and patient satisfaction was high, as assessed by telephone survey.
Conclusions:
Our findings highlight the value of the IDEAL framework in guiding the systematic evaluation and implementation of new surgical technologies such as the Dexter® robot. A structured approach is essential to improve patient outcomes and safety in the coming digital transformation of surgery.