Related Experiment Video
Updated: Jan 7, 2026
Porcine As a Training Module for Head and Neck Microvascular Reconstruction
Published on: September 29, 2018
A swine model for surgical training in various types of robotic liver resection with surgical videos
Na Reum Kim1, Gi Hong Choi2, Dai Hoon Han1
1Department of Surgery, Division of Hepato-biliary and Pancreatic Surgery, Yonsei University College of Medicine, Ludlow Faculty Research Building, 50 Yonsei-ro, Seodaemun-gu, Seoul, Republic of Korea.

Background:
Robotic liver resection (RLR) presents technical challenges due to the lack of standardized procedures and limited opportunities for hands-on training. To overcome these limitations, we developed a swine model designed to facilitate stepwise education across various RLR techniques. This model was supplemented with surgical videos to provide detailed procedural guidance.
Methods:
A standardized single-day curriculum was implemented using a swine model to simulate key components of RLR. Training included non-anatomical and anatomical resections using the extrahepatic Glissonean approach, parenchymal transection guided by indocyanine green fluorescence or ischemic demarcation, and advanced procedures such as hilar dissection, biliary reconstruction, and portal vein anastomosis. All procedures were recorded and edited into instructional videos. Multiple workshops were conducted through the Korean Association of Liver Surgery.
Results:
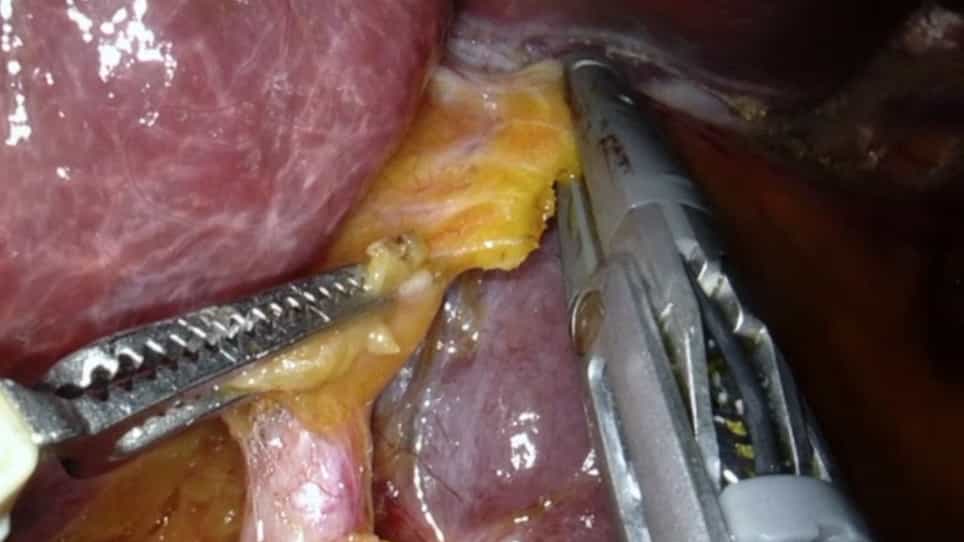
The swine model reliably reproduced key robotic liver surgery techniques, providing realistic tissue handling, stable operative exposure, and effective practice of parenchymal transection using both harmonic and bipolar energy devices. The accompanying educational videos highlighted key procedural steps and enhanced conceptual understanding. Survey responses from participating surgeons demonstrated improved technical confidence, better understanding of robotic liver anatomy and transection techniques, and increased clinical adoption of RLR.
Conclusions:
This swine-based educational model provides a practical, high-fidelity, and reproducible environment for structured RLR training. When integrated with instructional surgical videos, it offers a comprehensive educational tool that supports early-career surgeons in achieving proficiency in robotic liver surgery.