Related Experiment Video
Updated: Jan 7, 2026

Modeling and Experimental Analysis of the Single-Shaft Coaxial Motor-Pump Assembly in Electrohydrostatic Actuators
Published on: June 13, 2022
Jacobi-Ritz formulation for modal analysis of thick, anisotropic and non-uniform electric motor stator assemblies
Panagiotis Andreou1, Amal Z Hajjaj1, Mahdi Mohammadpour1
1School of Mechanical, Electrical and Manufacturing Engineering, Loughborough University, Wolfson Building, Ashby Rd, Loughborough, Leicestershire, LE11 3TU UK.

Abstract:
This study presents a novel and efficient modal analysis framework for thick cylindrical structures with complex geometry and material variability, subject to arbitrary boundary conditions. The methodology is applied to an electric motor (e-motor) stator assembly modelled as a thick cylindrical shell incorporating stator teeth, windings, and housing or cooling jacket effects. The model accommodates both continuous and piecewise variations in material properties and thickness. Based on First-Order Shear Deformation Shell Theory (FSDST), it accounts for shear deformation, rotary inertia, and trapezoidal stress distributions, enabling accurate prediction of axial, circumferential, torsional, and bending vibration modes. A segmentation approach is used along the axial direction, with artificial massless springs enforcing continuity and permitting general boundary conditions. Displacement fields are constructed using orthogonal Jacobi polynomials, and the eigenvalue problem is solved via the Rayleigh-Ritz method. Notably, the methodology allows accurate and efficient prediction of axisymmetric (breathing) modes in thick, non-uniform cylindrical shells - a capability rarely addressed in existing literature, despite its importance in Noise, Vibration, and Harshness (NVH) analysis. Validation against Finite Element Analysis (FEA) and Experimental Modal Analysis (EMA) on both generic cylindrical shells and a real Permanent Magnet Synchronous Machine (PMSM) stator shows excellent agreement, with natural frequency deviations typically below 5% and highly consistent mode shapes. The framework also achieves over 95% reduction in computational time compared to FEA, establishing it as a highly adaptable and practical tool for vibration analysis in electric motor design and NVH engineering applications.
More Related Videos

Related Concept Videos
 01:15
Thin-Walled Hollow Shafts
 01:12
General Case of Eccentric Axial Loading
Consider a member subjected to equal and opposite forces that are applied along a line that does not coincide with the member's neutral axis. In unsymmetrical...
 01:15
Torque Free Motion
 01:18
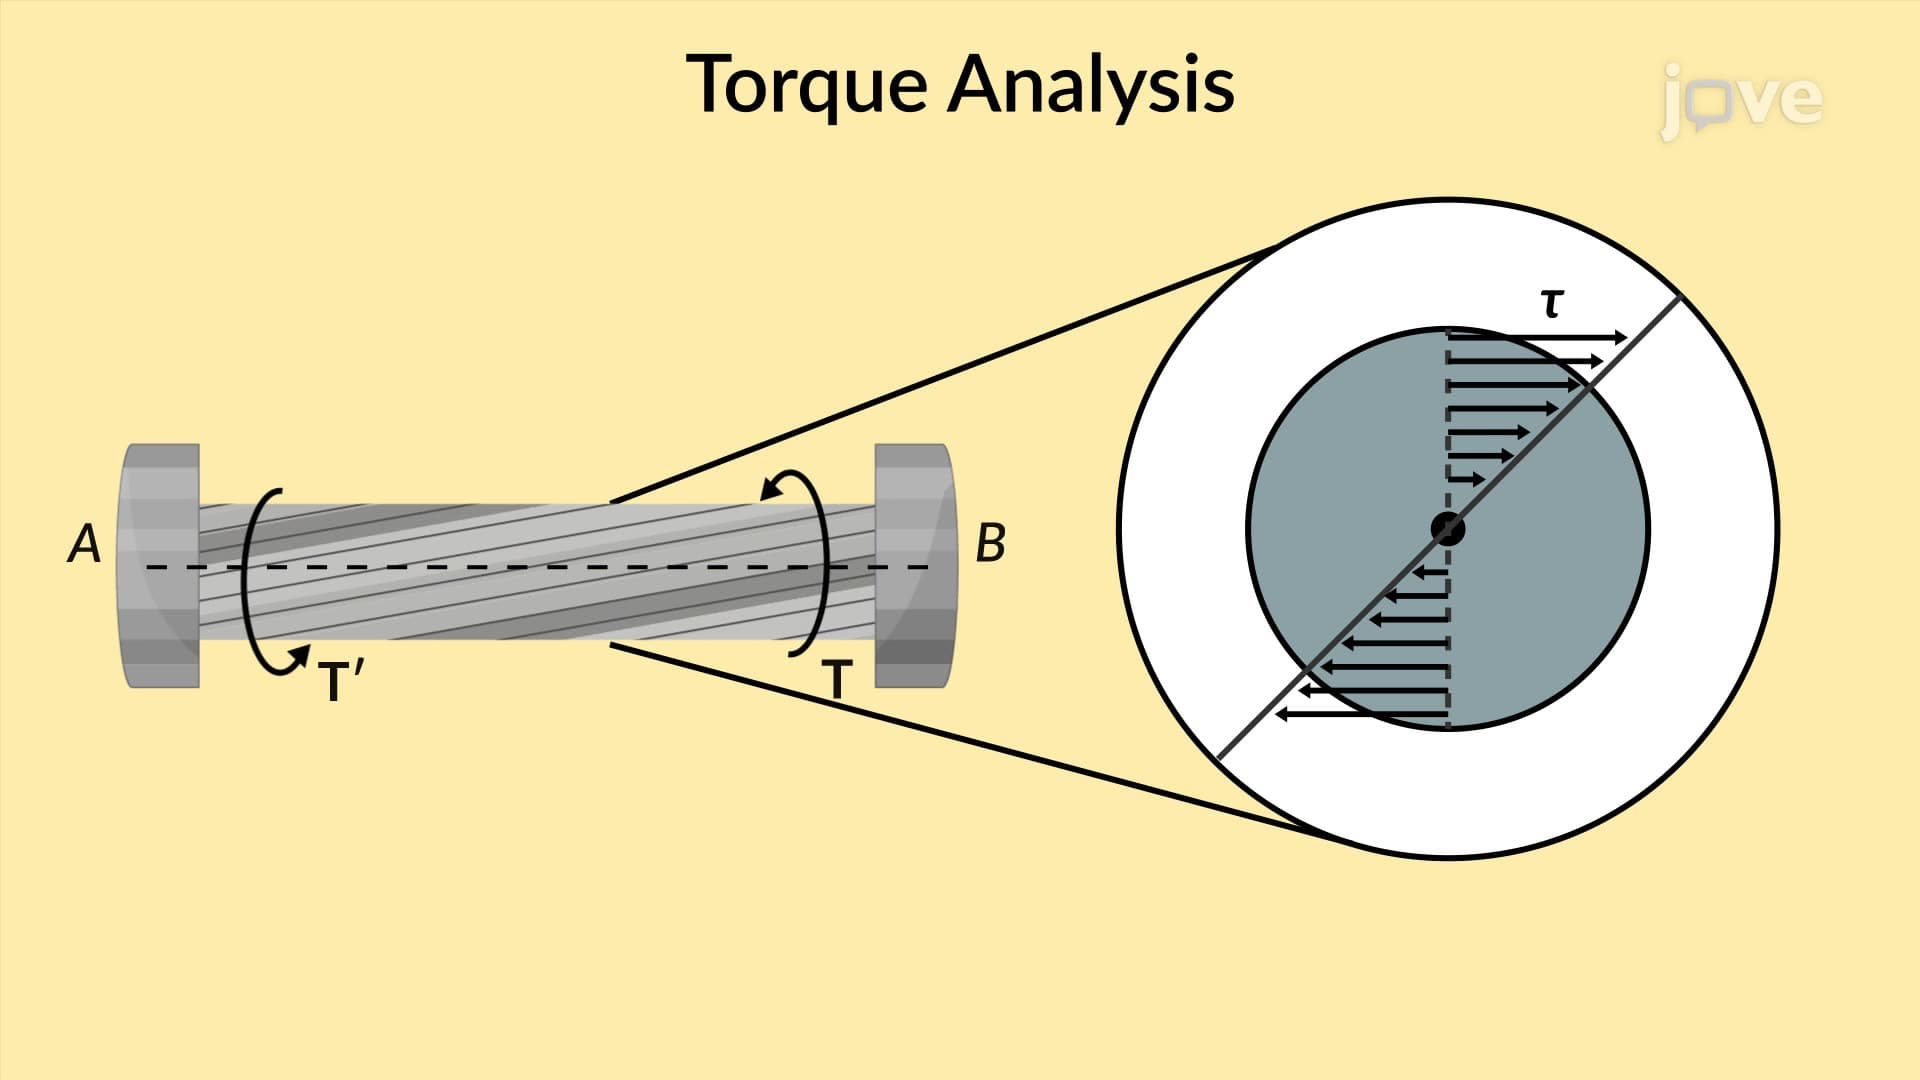
Stresses in a Shaft
Applying equilibrium conditions to the QR segment establishes that the internal shearing forces within the...
 01:19
Euler Equations of Motion
 01:13
Circular Shaft - Stresses in Linear Range