Related Experiment Video
Updated: Jan 7, 2026


Training Persons with Spinal Cord Injury to Ambulate Using a Powered Exoskeleton
Published on: June 16, 2016
Assistive Trajectory Planning for Lower Limb Exoskeletons: Strategies From Laboratory-Optimized Gait to

Abstract:
Lower limb assistive exoskeletons (LLEs) show great potential to reduce metabolic cost, improve walking performance, and correct abnormal gait patterns. Among their core control architectures, assistive trajectory planning is key to determining system responsiveness and effectiveness under varying locomotion conditions. Many trajectory planning methods were proposed in either laboratory or unstructured real-world environments. To clarify the scope and challenges of existing research, this review categorizes trajectory planning strategies into two major types based on application scenarios: (1) strategies for laboratory settings with controllable disturbances, which usually involve optimal control for gait under stable or controllable conditions; and (2) strategies for real-world environments characterized by varying terrain, individual differences, and gait fluctuations, which usually involve adaptive control for gait under diverse or unstructured conditions. Given the foundational role of gait phase detection in trajectory planning, this review also systematically examines mainstream algorithms for gait phase recognition and estimation. Finally, the paper analyzes the limitations of existing methods and discusses the potential of advanced algorithms, intelligent multimodal sensing systems, novel sensing technologies, and embedded deployment to enhance the performance of exoskeleton assistive trajectory planning.
More Related Videos
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
 06:00
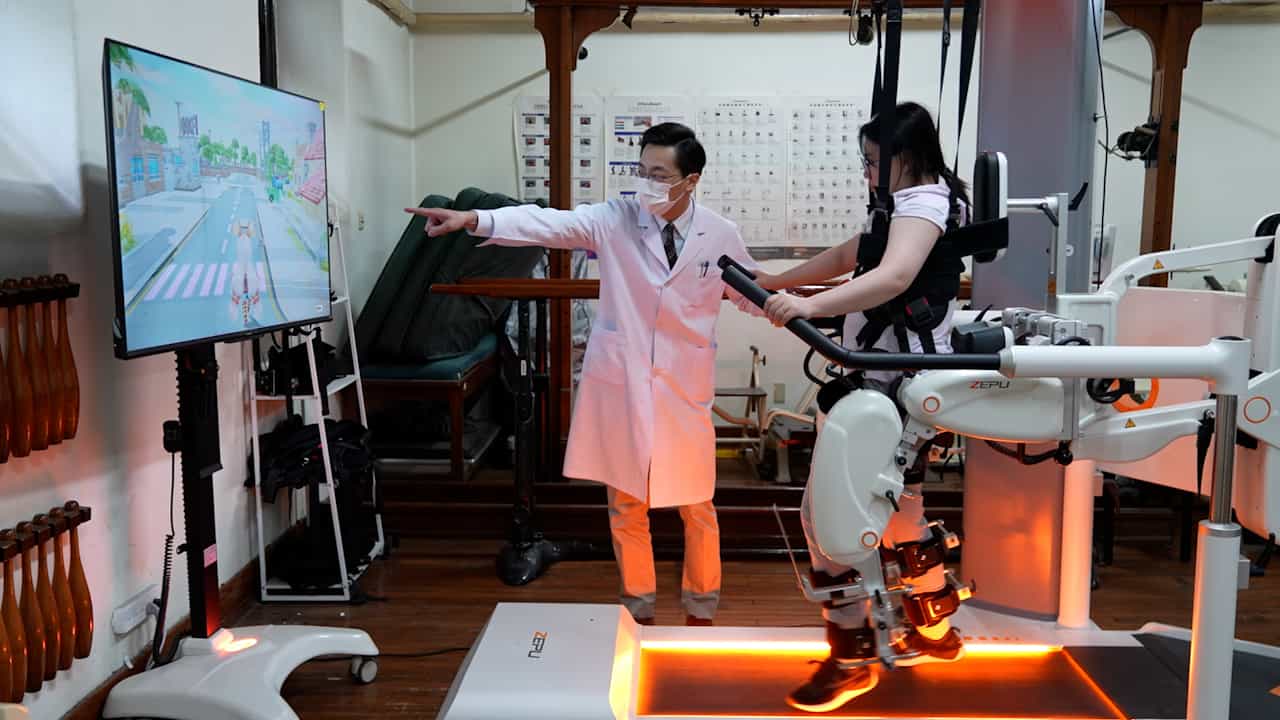
A Rehabilitation Program of Exoskeleton-assisted Body Weight-Supported Treadmill Training with Non-immersive Virtual Reality for Stroke Patients
Published on: May 16, 2025