Related Experiment Video
Updated: Jan 7, 2026


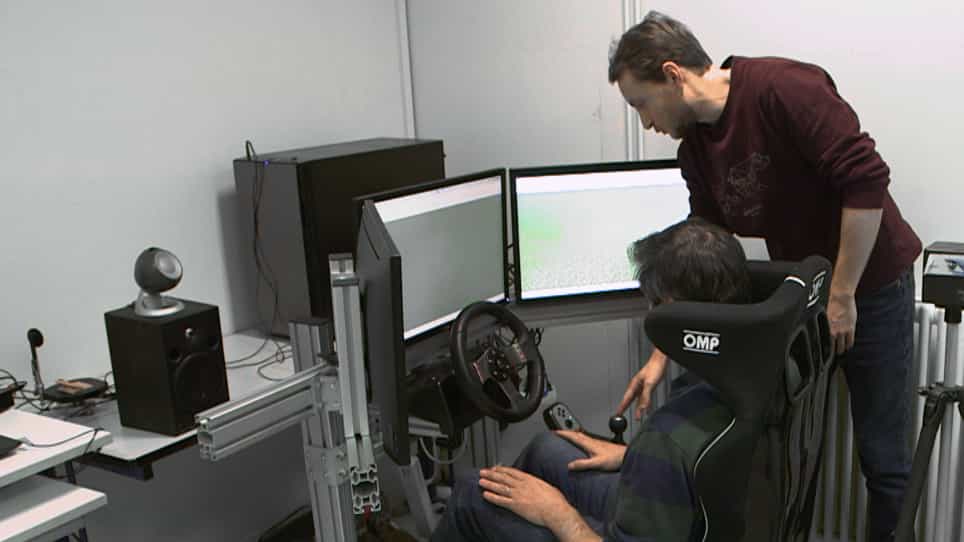
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Extraction of driving behavior primitives considering driver expectation and vehicle dynamics
Yuanyuan Ren1, Xiaotong Cui2, Xuelian Zheng1
1Transportation College, Jilin University, Changchun, Jilin, China.

Abstract:
Extracting meaningful driving behavior primitives is crucial for fine-grained behavior analysis. To develop primitives that more closely mirror the hierarchical nature of human driving, this paper introduces a novel framework and carries out on a 16 drivers' dataset. The proposed method operates in two synergistic stages. First, for behavior segmentation, a multi-type feature space is constructed to capture both the objective vehicle motion states and the subjective driver expectations on vehicle performance. This space is then input into a Bayesian Model-based Agglomerative Sequence Segmentation (BMASS) model to achieve precise segmentation. Segment durations and the positioning of segmentation points serve as key metrics to assess the quality of behavior segmentation. Next, for primitive clustering, a Variable Coupling-based Latent Dirichlet Allocation (VC-LDA) method is proposed. The core innovation of VC-LDA lies in a features-coupling-aware discretization process. By considering the non-linear coupling and temporal asynchrony among features in the multi-type space, this process yields driving states with enhanced physical interpretability, providing a high-quality foundation for LDA clustering. Experimental results demonstrate that the VC-LDA model significantly outperforms the GMM-LDA, achieving a much lower perplexity and exhibiting higher intra-class compactness in topic-word distributions. This framework offers an automated and efficient pathway to understand and model driver behavioral patterns, providing valuable insights for the development of ADAS and AVs.
More Related Videos
Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:15
Elastic Collisions: Case Study
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:27
Drive-Reduction Theory: Push Theory of Motivation