Related Experiment Video
Updated: Jul 15, 2026

Methods to Quantify Pharmacologically Induced Alterations in Motor Function in Human Incomplete SCI
Published on: April 18, 2011
Mechanical energetics of different sagittal gait patterns in children with bilateral spastic cerebral palsy
Kosar Barati1, Farzam Farahmand1, Saeed Behzadipour1
1Mechanical Engineering Department, Sharif University of Technology, Tehran, Iran.

Insights
Children with cerebral palsy (CP) show distinct gait inefficiencies related to their specific movement patterns. Understanding these biomechanical issues, like amplitude and phase problems, can guide targeted interventions for better walking efficiency.
Area of Science:
- Biomechanics
- Pediatric Rehabilitation
- Gait Analysis
Background:
- Children with cerebral palsy (CP) frequently display inefficient gait patterns.
- The precise relationship between specific sagittal gait patterns and gait inefficiency in CP is not fully understood.
Purpose of the Study:
- To investigate the mechanical energy characteristics of gait in children with bilateral spastic CP.
- To quantify gait inefficiencies, specifically Amplitude and Phase Problems, across different sagittal gait patterns in CP.
- To compare gait energy characteristics between children with CP and typically developing (TD) controls.
Main Methods:
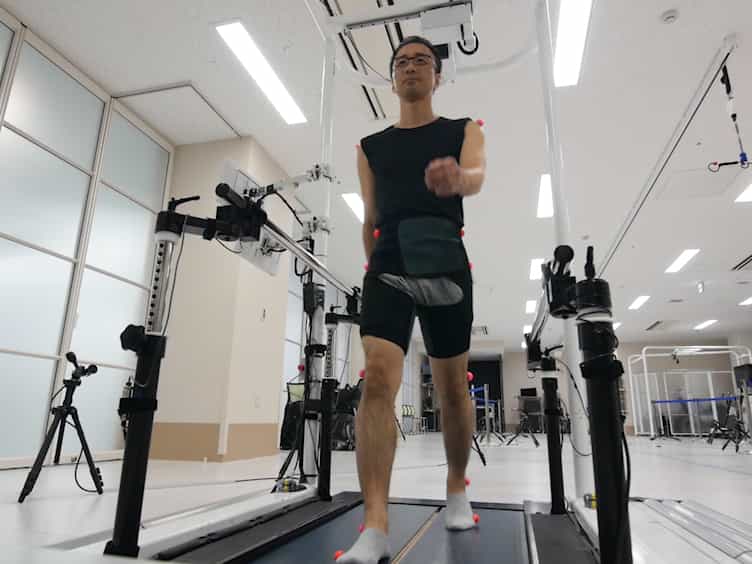
- Collected 3D gait data from 148 children with bilateral spastic CP and 19 TD controls using motion capture.
- Applied an extended inverted pendulum framework to analyze dimensionless kinetic (T) and potential (V) energy waveforms during single support.
- Quantified Amplitude and Phase Problems by assessing deviations from optimal energy exchange and calculating continuous relative phase.
Main Results:
- Amplitude-related inefficiency was most pronounced in the Crouch gait pattern.
- All CP subgroups exhibited impaired phase coordination, indicated by positive time lags and reduced continuous relative phase compared to TD.
- CP subgroups showed significantly greater total energy fluctuations, cost of transport, and energy recovery index, with specific energy dissipation patterns in Crouch and Jump patterns.
Conclusions:
- Gait inefficiencies in children with CP are specific to their sagittal gait patterns.
- Quantitative biomechanical data provide a foundation for developing targeted interventions to improve gait efficiency in children with CP.
- Understanding pattern-specific inefficiencies can lead to more effective rehabilitation strategies for CP gait disorders.
Abstract:
Children with cerebral palsy (CP) often exhibit inefficient gait; however, the relationship between their distinct sagittal gait patterns and this inefficiency remains unclear. This study examined the mechanical energy characteristics of gait in a large cohort of children with bilateral spastic CP, classified into four sagittal gait patterns: Crouch, Apparent Equinus, Jump, and True Equinus. Three-dimensional gait data from 148 children with bilateral spastic CP and 19 typically developing (TD) controls were collected using motion capture. An extended inverted pendulum framework was applied to assess deviations of dimensionless kinetic, T, and potential, V, energy waveforms from optimal energy exchange during single support, in order to quantify the Amplitude and Phase Problems. Results indicated that the amplitude-related inefficiency was most pronounced in the Crouch pattern, characterized by elevated V amplitude without proportional increases in T, and least in True Equinus, which showed elevated amplitudes in both V and T; nevertheless, both patterns exhibited significantly higher amplitude ratios than TD (p < 0.05). All CP subgroups had positive time lags, compared with a slightly negative lag in TD, and reduced continuous relative phase values (p < 0.05), indicating impaired phase coordination. These inefficiencies resulted in significantly greater total energy fluctuations, cost of transport, and energy recovery index across all CP subgroups (p < 0.05), with sustained energy injection in early stance and dissipation in late stance, particularly in Crouch and Jump patterns. These findings reveal gait-pattern-specific biomechanical inefficiencies in CP, offering a quantitative foundation for targeted interventions to improve gait efficiency.
Related Concept Videos
 01:14
Energy Diagrams - I
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:10
Energy Diagrams - II
The point in the energy diagram at which the system’s potential energy is the lowest is known as the local minima. The system tends to stay in this position indefinitely unless acted upon by a net force. The slope of the potential energy diagram at the local minima is zero, indicating that zero net force is acting on the system. The slope...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...