Related Experiment Video
Updated: Jan 13, 2026

Magnetic Tweezers for the Measurement of Twist and Torque
Published on: May 19, 2014
Enhanced trajectory tracking and robustness in magnetic levitation via takagi-sugeno fuzzy control: experimental
Yuvapriya T1, Vimala Kumari Jonnalagadda2, Vijaya Lakshmi Korupu3
1School of Electrical Engineering, Vellore Institute of Technology, Vellore, Tamil Nadu, 632014, India. yuvapriya.t@vit.ac.in.

Abstract:
Robust control of magnetic levitation (maglev) plant remains a significant challenge due to its inherent non-linearities and uncertainty to exogenous perturbations, though maglev technology has a wide range of usages, from high-speed trains to advanced robotics. To solve these problems and improve the maglev system's trajectory-tracking performance and robustness, this research proposes a control technique that involves synthesizing a T-S fuzzy controller using the parallel distributed compensation (PDC) method. The controller design is further augmented with a velocity-compensation technique to enable smooth and frictionless ball levitation in a maglev system. The gravitational bias acting on the maglev system is controlled by integrating the feed-forward controller ([Formula: see text]) with the PDC-TS fuzzy scheme. The Lyapunov function candidate and linear matrix inequalities (LMIs) are explored to determine the proposed TS fuzzy scheme's global asymptotic stability. Finally, the effectiveness of the control technique is experimentally evaluated for several test cases using hardware-in-loop (HIL) testing on the maglev system. The results corroborate that the T-S fuzzy control strategy offers robustness and trajectory tracking of the system with stable levitation over the traditional PIV scheme.
Related Concept Videos
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:13
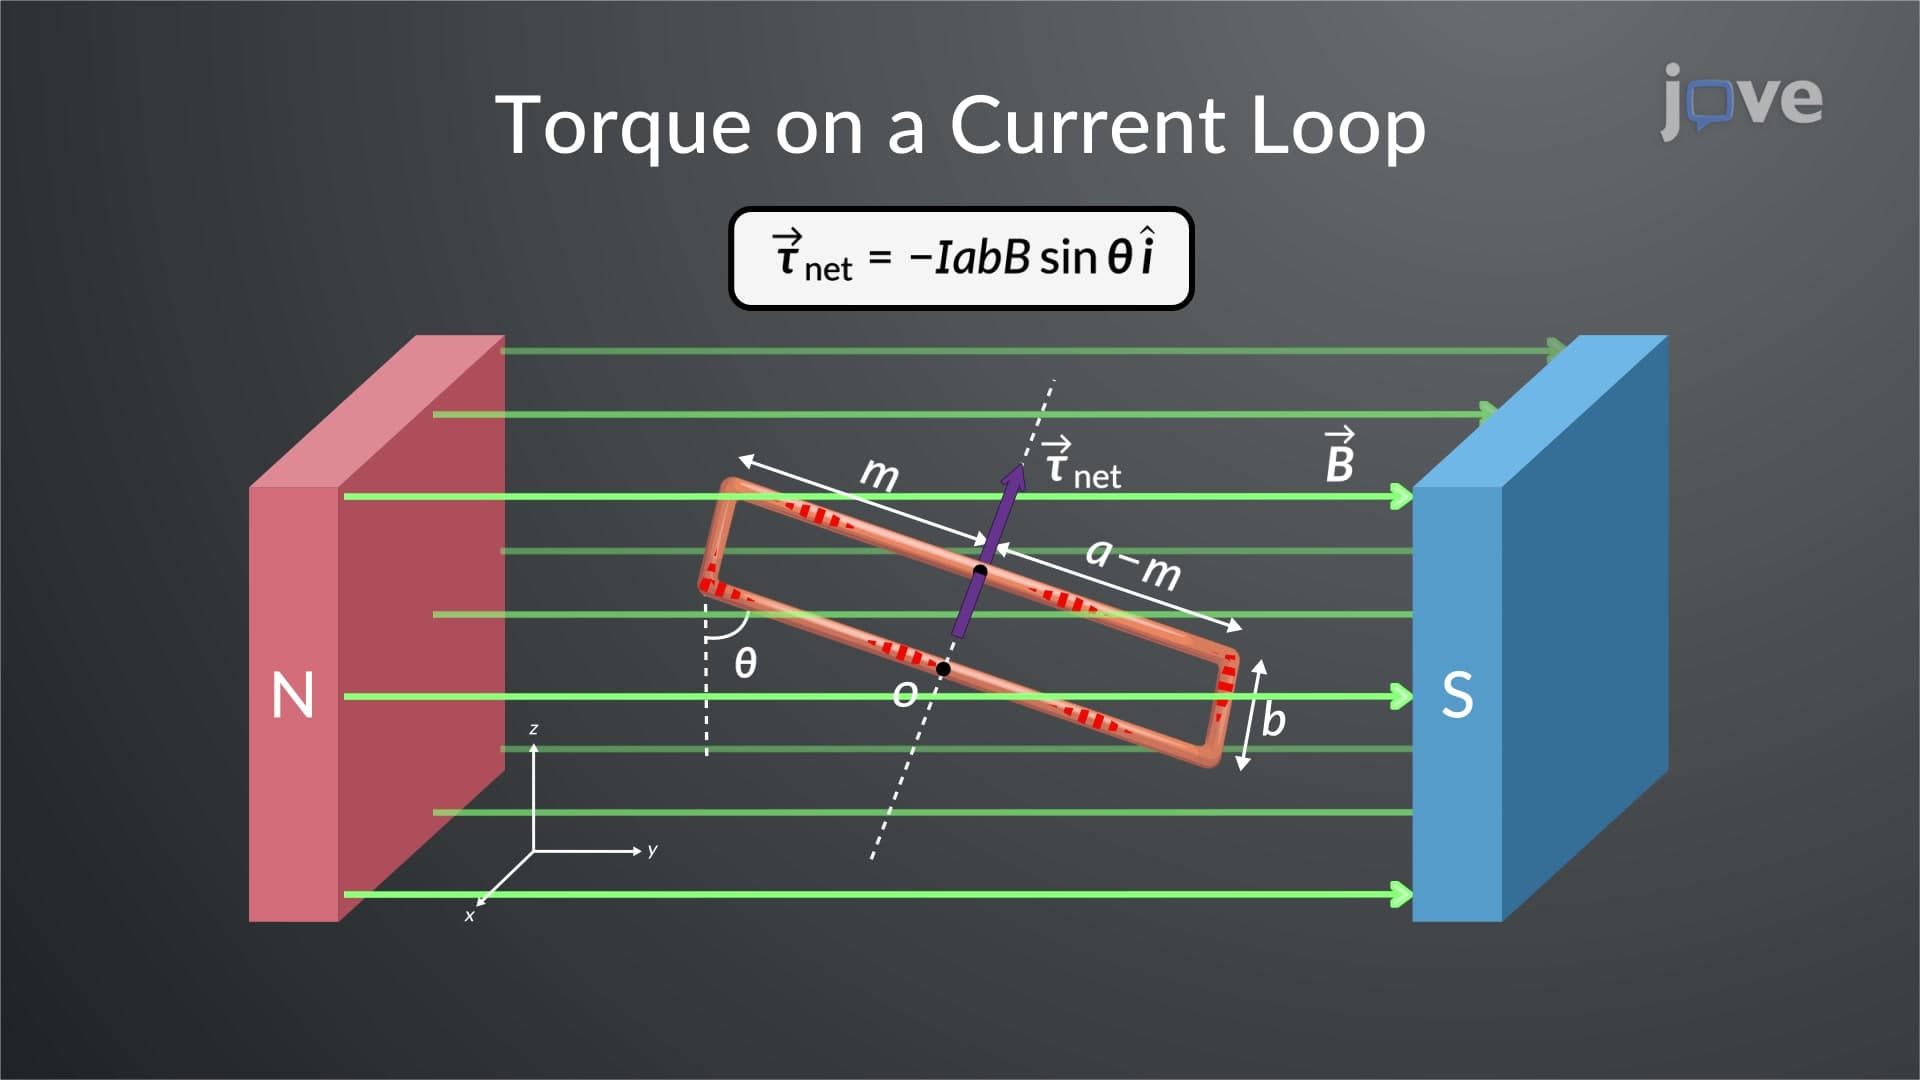
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:18
Magnetic Force
The magnetic force acting on a moving charge...
 01:15
Magnetic Vector Potential
Consider an ideal solenoid with n turns per unit length and radius R. If I is the current through the solenoid, the magnetic field inside the solenoid is expressed as the product of vacuum...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Orthogonal Trajectories