Geometric moment-based spectral descriptors for robust non-rigid 3D shape analysis
Related Experiment Video
Updated: Jan 21, 2026
Three-Dimensional Shape Modeling and Analysis of Brain Structures
Published on: November 14, 2019
Dan Zhang1,2,3, Na Liu4, Zhongke Wu5
1School of Computer Science, Qinghai Normal University, Xining, 810008, Qinghai, China.

Abstract:
Numerous 3D shape descriptors have been proposed in recent years, among which spectral descriptors have gained significant prominence. However, widely used spectral signatures, such as the Heat Kernel Signature (HKS), Scale-Invariant HKS (SIHKS), and Wave Kernel Signature (WKS), suffer from parameter dependence, where heuristic and sub-optimal scale selection limits their robustness and generalizability. To address this limitation, this paper introduces a novel class of descriptors termed Geometric Moments of Spectral Shape Descriptors (GMSDs). By integrating temporal and spatial domains, GMSDs leverage invariant moment theory to calculate six moment terms, creating a theoretical framework that significantly enhances performance in non-rigid 3D shape analysis. GMSDs not only inherit the desirable properties of standard spectral signatures, such as isometric invariance and robustness to noise and topological changes, but also effectively mitigate parameter sensitivity. Extensive experiments on the TOSCA, SCAPE, SHREC 2011, and SHREC 2015 benchmarks demonstrate that GMSDs achieve superior performance in both shape correspondence and retrieval tasks compared to state-of-the-art methods.

Related Concept Videos
 01:15
Geometric Mean
In cases of multiplicative data, the geometric mean is used for statistical analysis. First, the product of all the elements is taken. Then, if there are n elements in the...
 03:37
Molecular Shape and Polarity
 00:56
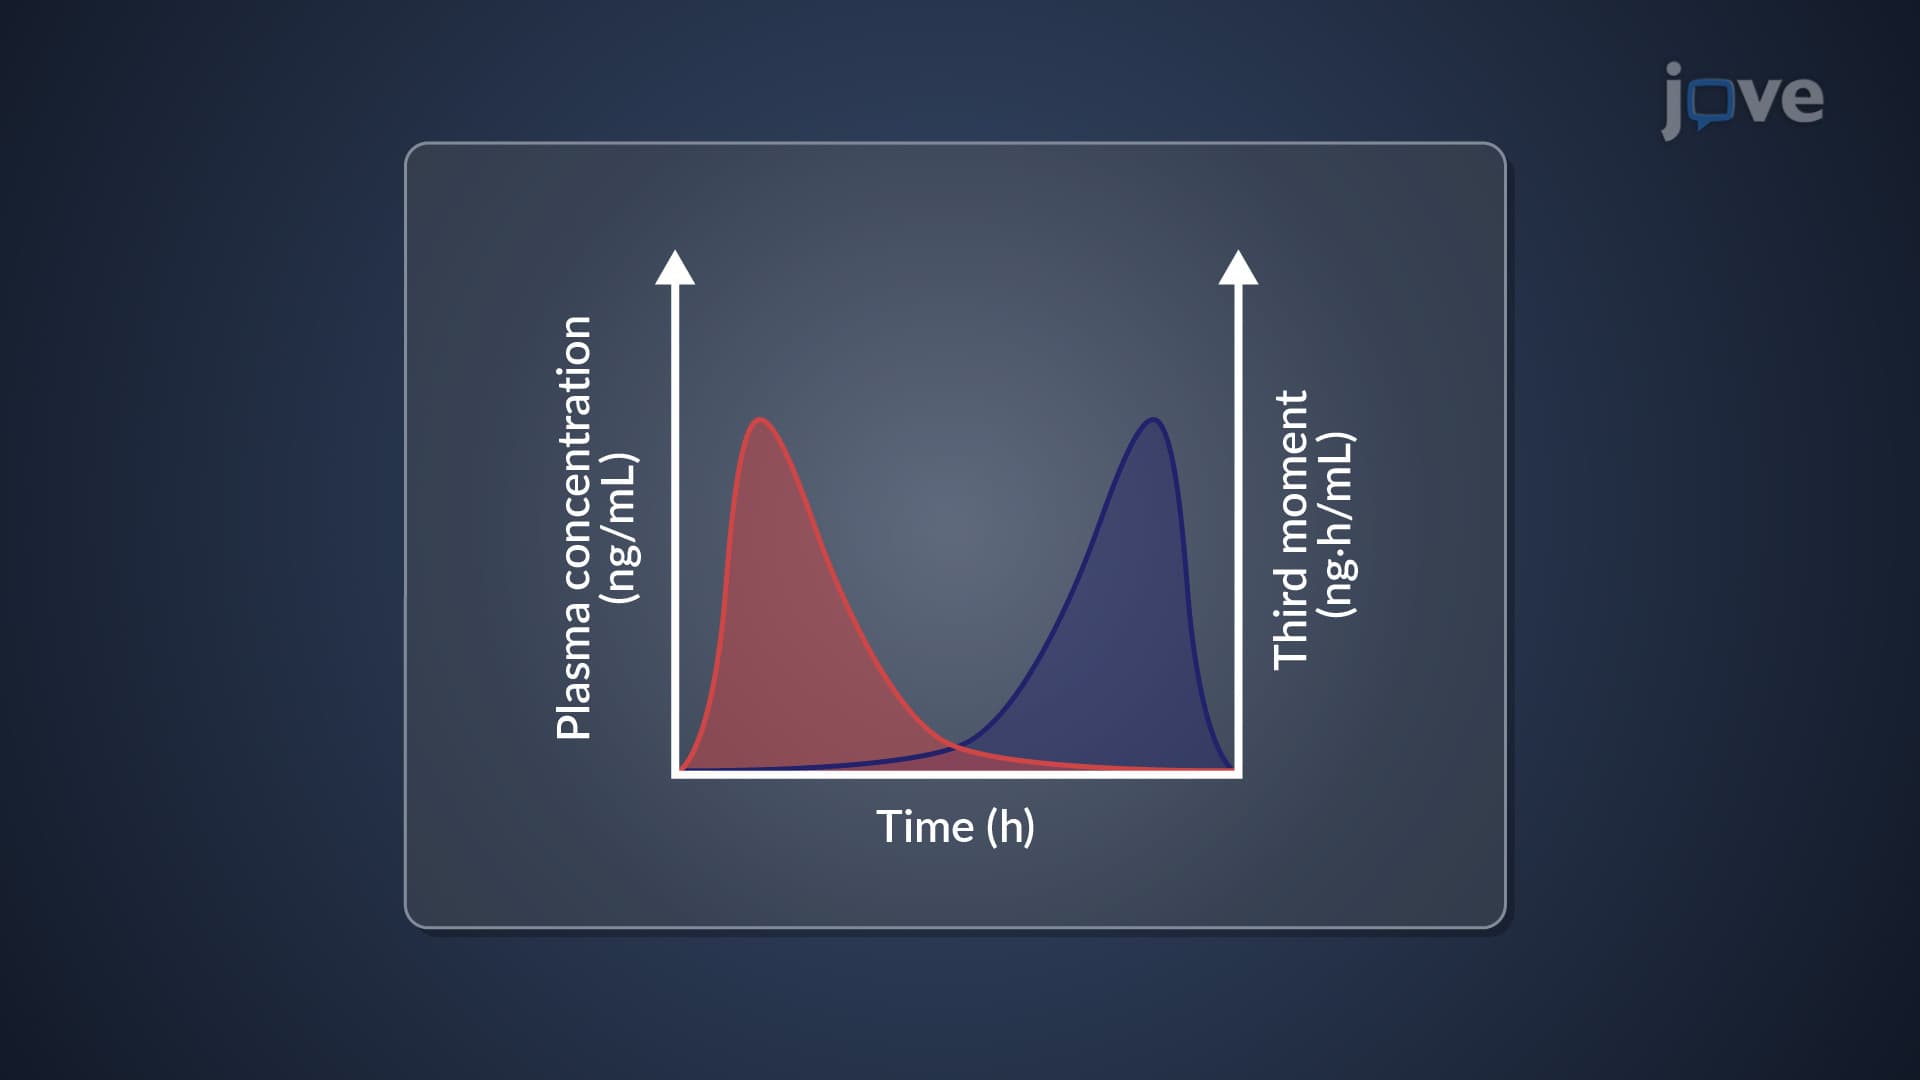
Noncompartmental Analysis: Statistical Moment Theory
 01:18
Molecular Shapes
Two regions of electron density in a diatomic...
 00:49
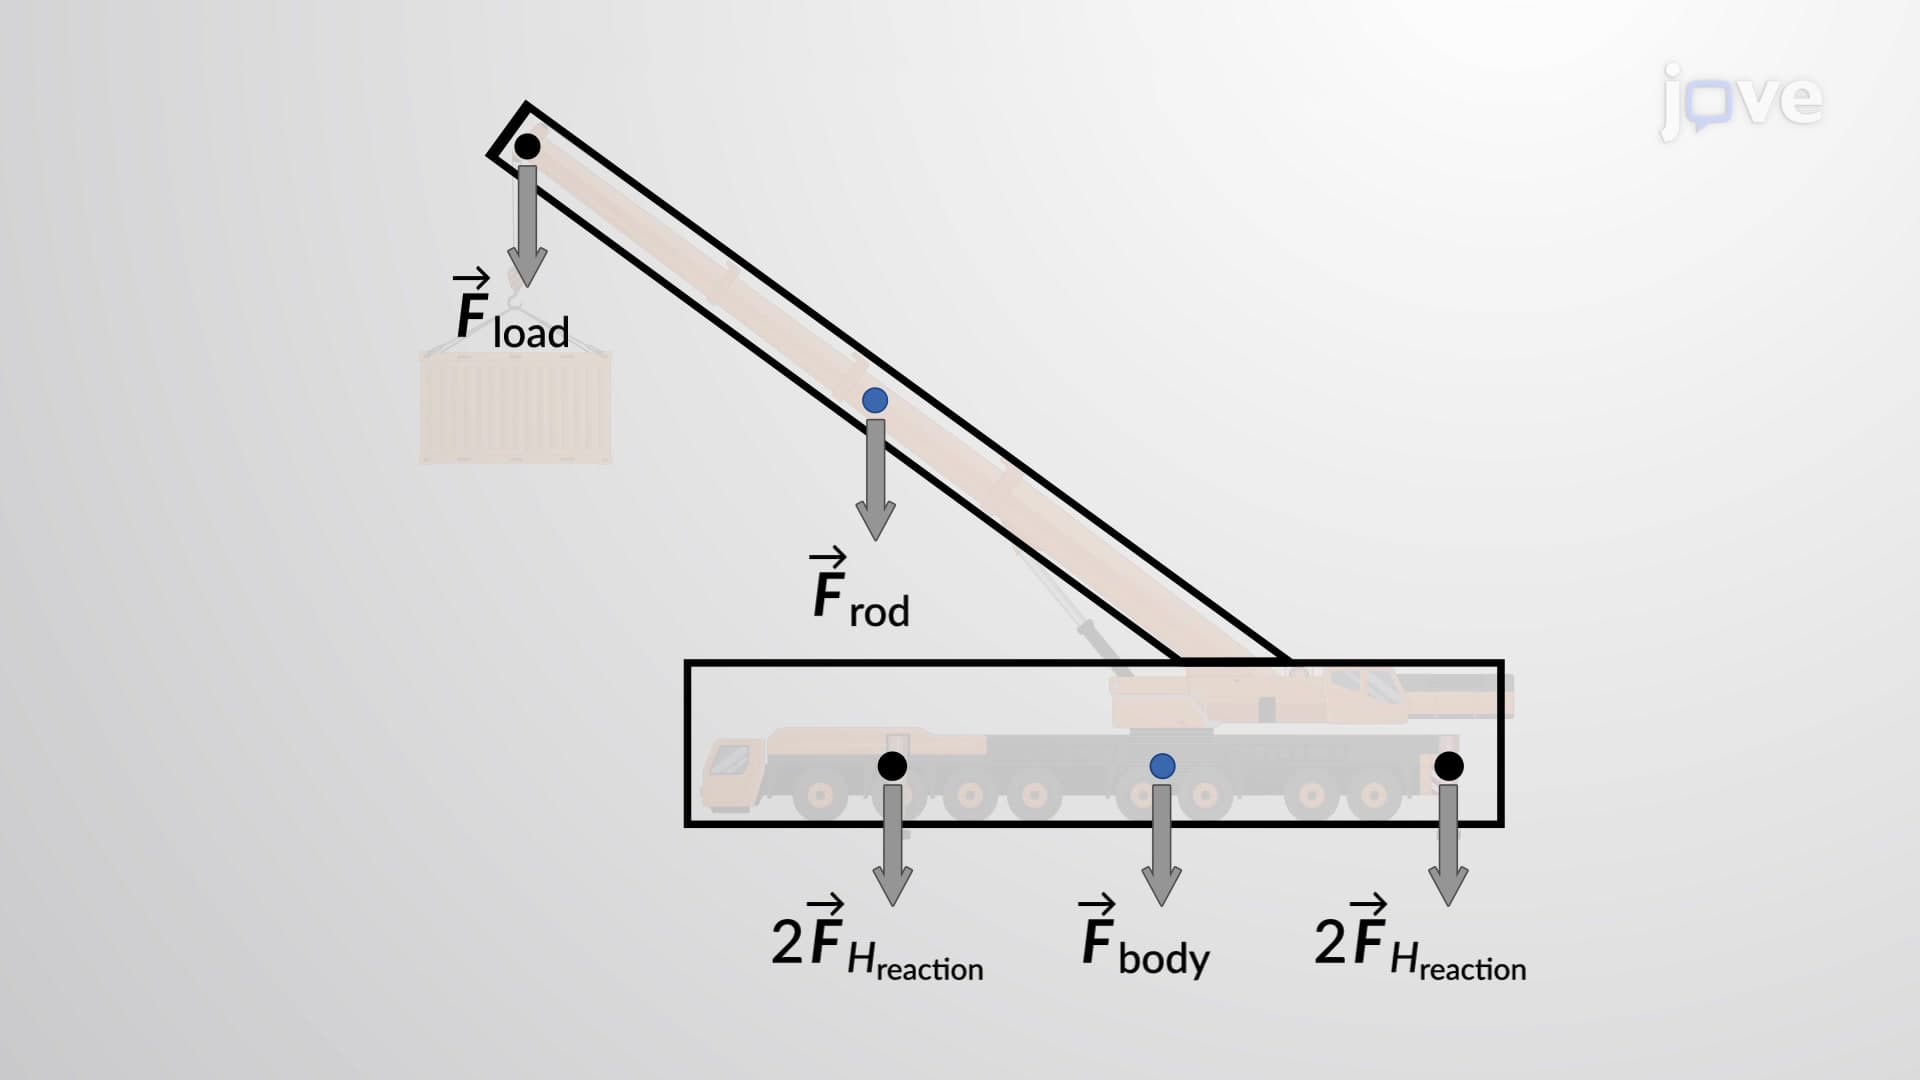
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?