Topology-Guided Semantic Face Center Estimation for Rotation-Invariant Face Detection


Abstract:
Face detection accuracy significantly decreases under rotational variations, including in-plane (RIP) and out-of-plane (ROP) rotations. ROP is particularly problematic due to its impact on landmark distortion, which leads to inaccurate face center localization. Meanwhile, many existing rotation-invariant models are primarily designed to handle RIP, they often fail under ROP because they lack the ability to capture semantic and topological relationships. Moreover, existing datasets frequently suffer from unreliable landmark annotations caused by imperfect ground truth labeling, the absence of precise center annotations, and imbalanced data across different rotation angles. To address these challenges, we propose a topology-guided semantic face center estimation method that leverages graph-based landmark relationships to preserve structural integrity under both RIP and ROP. Additionally, we construct a rotation-aware face dataset with accurate face center annotations and balanced rotational diversity to support training under extreme pose conditions. Next, we introduce a Hybrid-ViT model that fuses CNN spatial features with transformer-based global context and employ a center-guided module for robust landmark localization under extreme rotations. In order to evaluate center quality, we further design a hybrid metric that combines topological geometry with semantic perception for a more comprehensive evaluation of face center accuracy. Finally, experimental results demonstrate that our method outperforms state-of-the-art models in cross-dataset evaluations. Code: https://github.com/Catster111/TCE_RIFD.
More Related Videos
 08:17
A Semantic Priming Event-related Potential ERP Task to Study Lexico-semantic and Visuo-semantic Processing in Autism Spectrum Disorder
Published on: April 12, 2018
 05:38
Interaction between Phonological and Semantic Processes in Visual Word Recognition using Electrophysiology
Published on: June 29, 2021
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 02:33
Lattice Centering and Coordination Number
Types of Unit Cells
Imagine taking a large number of identical...
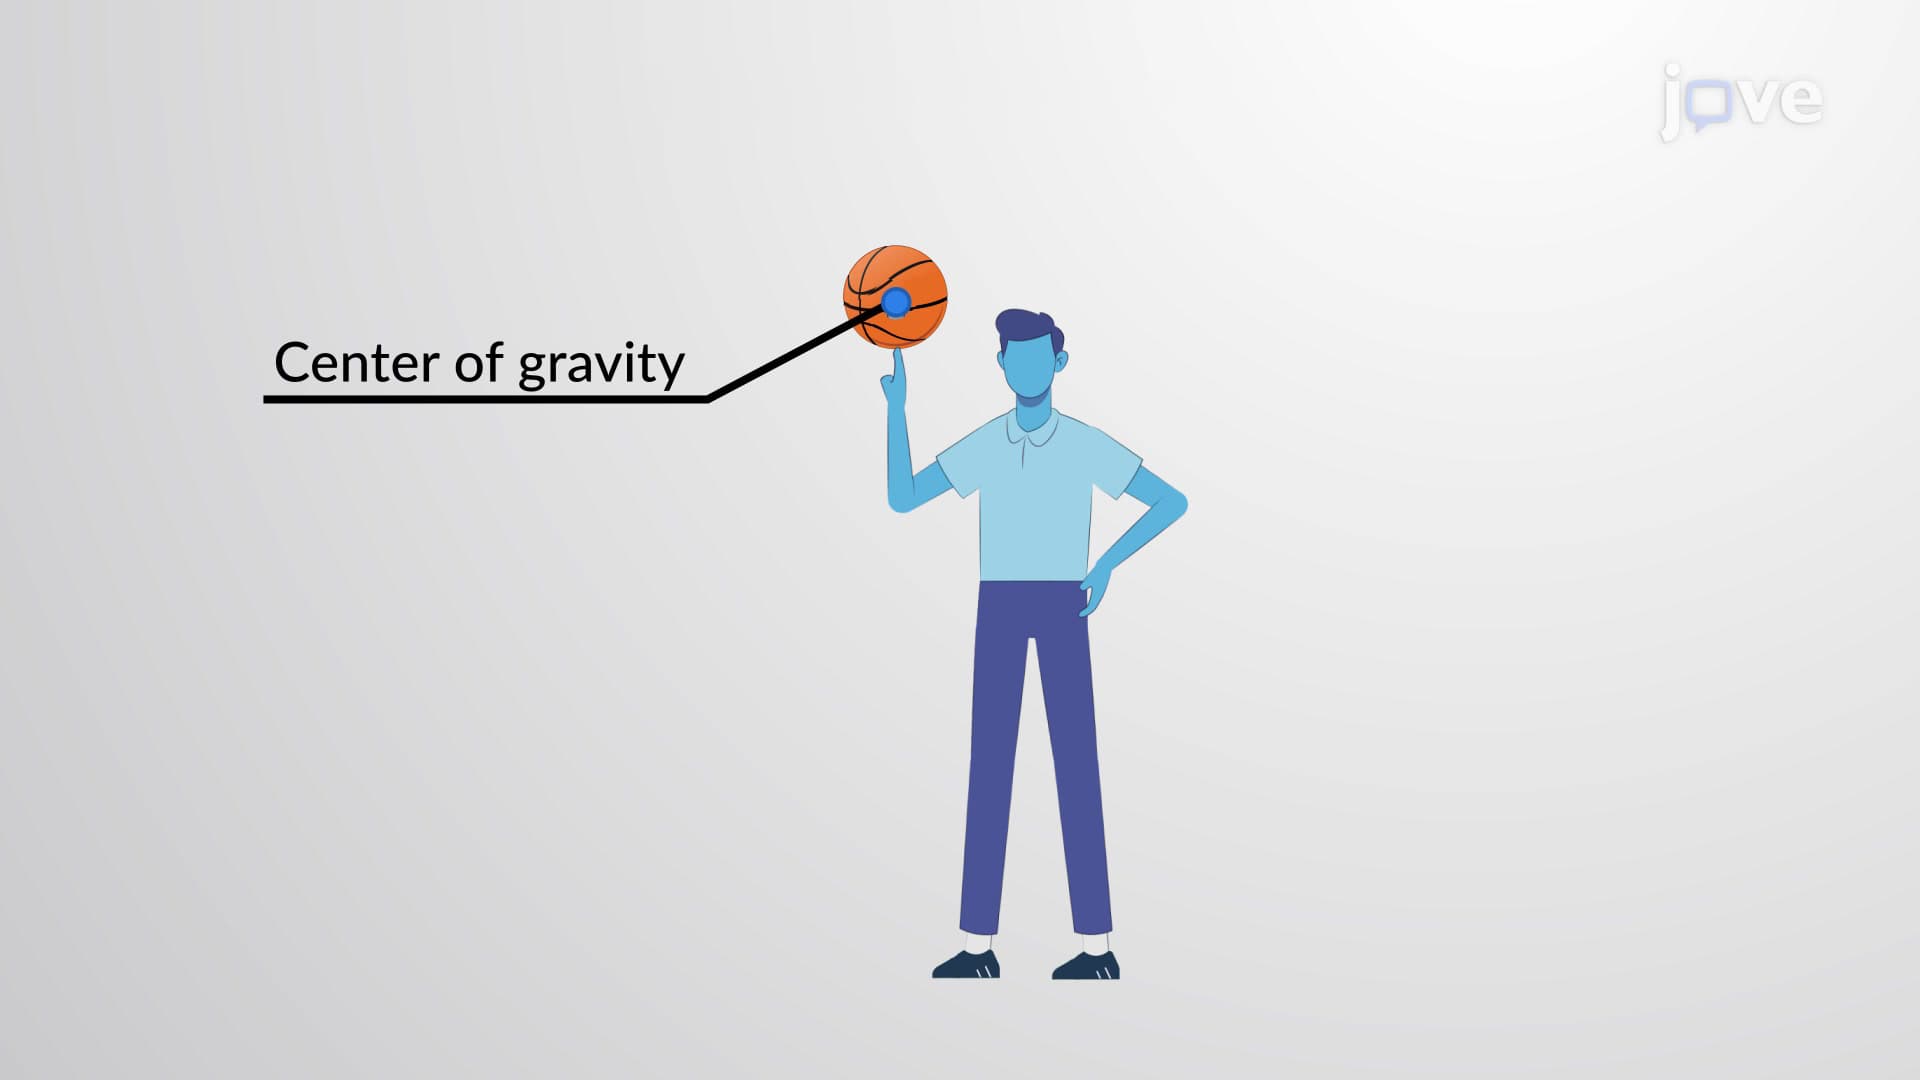 00:58
Center of Gravity
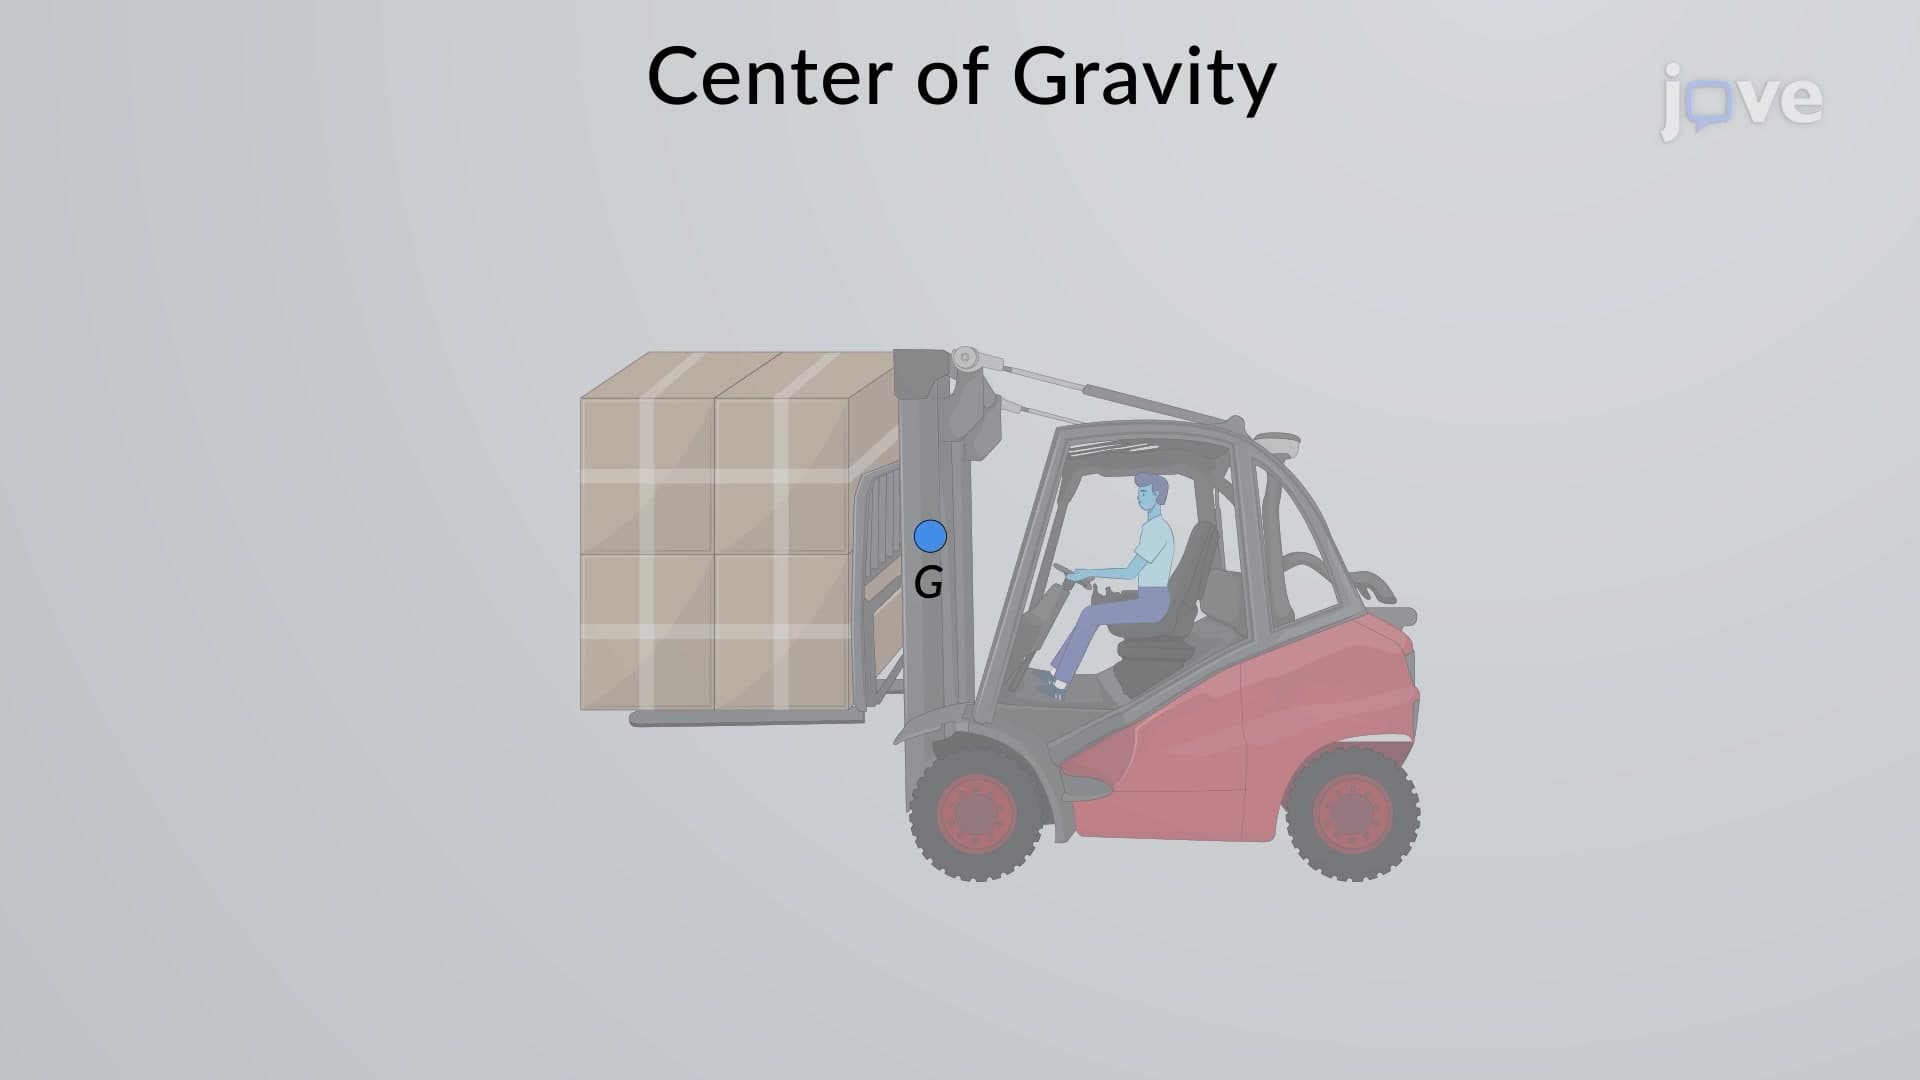 01:15
Center of Gravity
To determine its location, the principle of moments can be utilized by dividing the object into...
 00:59
Center of Mass
The knowledge of the center of mass can also help us to describe and predict the motion of objects. For example, when a ball is thrown...
 01:06
What are Estimates?
The estimate for the mean of a sample is denoted by ͞x, whereas the mean of the population is designated as μ. Further, parameters such...