Related Experiment Video
Updated: Jan 29, 2026
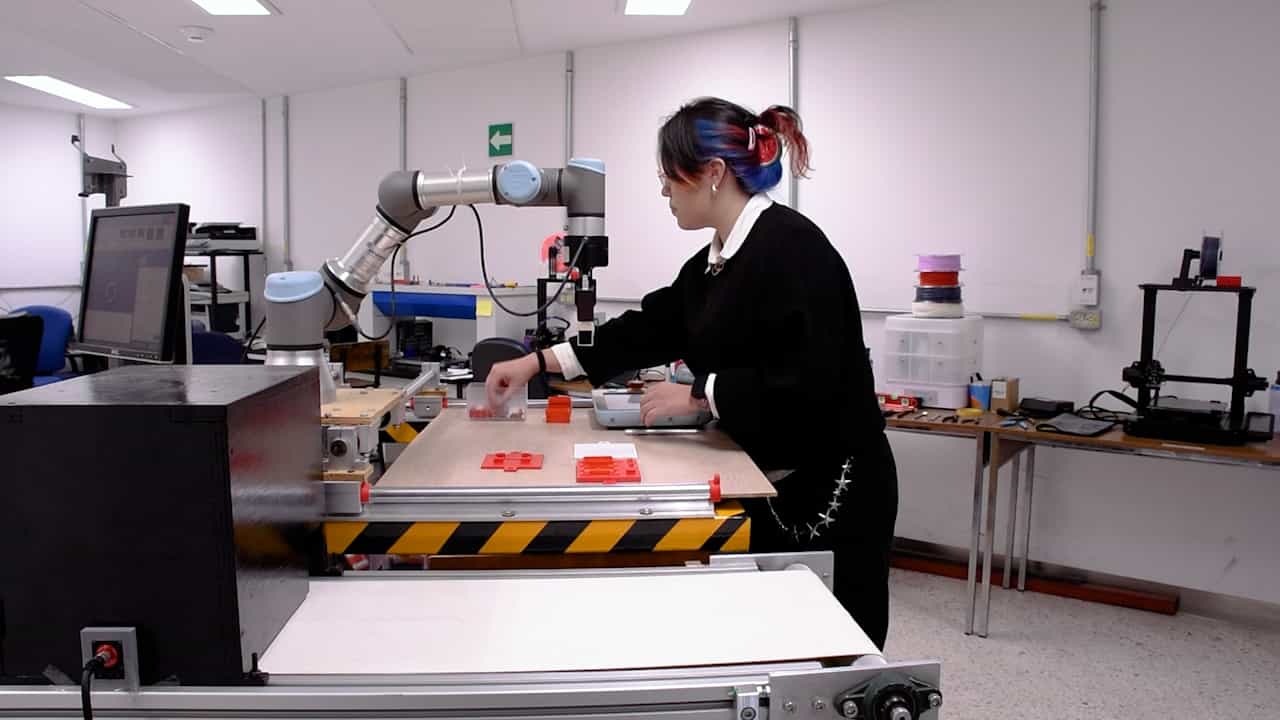
Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Achieving Robotic Data Efficiency Through Machine-Centric FDCT Vision Processing
1Computer Science Department, Bar-Ilan University, Ramat-Gan 5290002, Israel.

Abstract:
To enhance a robot's capacity to perceive and interpret its environment, an advanced vision system tailored specifically for machine perception was developed, moving away from human-oriented visual processing. This system improves robotic functionality by incorporating algorithms optimized for how computerized devices process visual information. Central to this paper's approach is an improved Fast Discrete Cosine Transform (FDCT) algorithm, customized for robotic systems, which enhances object and obstacle detection in machine vision. By prioritizing higher frequencies and eliminating less critical lower frequencies, the algorithm sharpens focus on essential details. Instead of adapting the data stream for human vision, the FDCT and quantization tables were adjusted to suit machine vision requirements, achieving a file size reduction to about one-third of the original while preserving highly relevant data for robotic processing. This innovative approach significantly improves robots' ability to navigate complex environments, perform tasks such as object recognition, motion detection, and obstacle avoidance with greater accuracy and efficiency.
Related Concept Videos
 01:14
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...
 01:24
Vision
 01:17
Design of Columns under a Centric Load
Euler's formula is applicable under the assumption that the column is a perfect, straight, homogenous prism, and it is operating...
 01:24
Color Vision
 01:19
Machines
A free-body diagram of the...
 01:30
Machines: Problem Solving II