Related Experiment Video
Updated: Jan 30, 2026
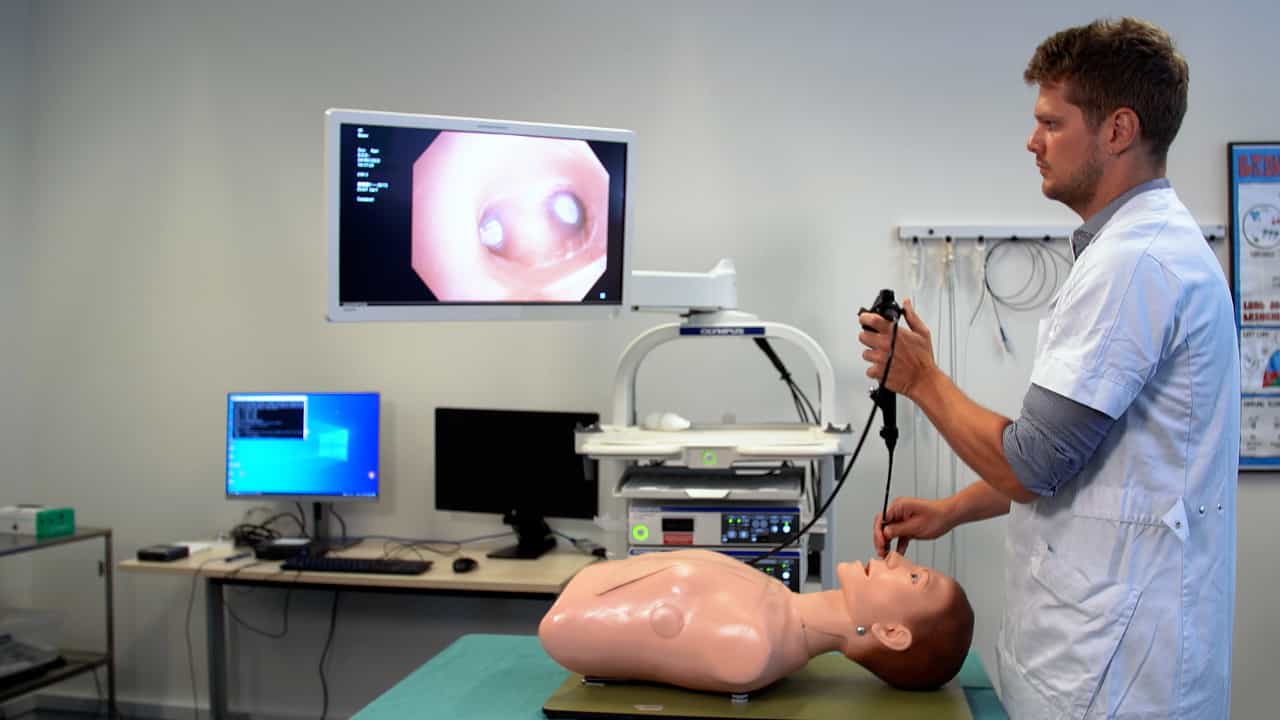

Author Spotlight: Learning Systematic Bronchoscopy in a Simulation-Base Setting
Published on: June 23, 2023
An automatic congenital radio-ulnar synostosis deformity evaluation method (CRUS-DE): integrating TLT-SAM and GPMM-R
Lu Liu1,2, Ying Cui3, Tianfeng Zhou4,5
1Department of Hand Surgery, Beijing Jishuitan Hospital, Capital Medical University, Beijing, China.

Abstract:
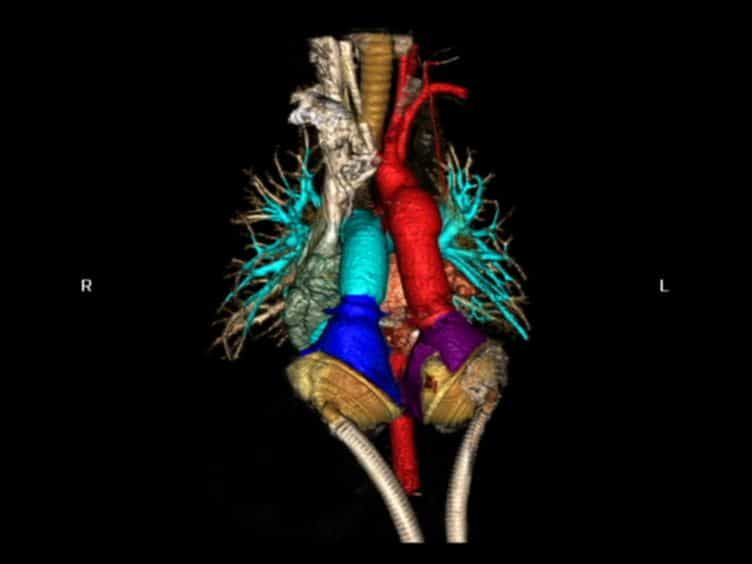
Congenital Radio-Ulnar Synostosis (CRUS) causes difficulty in forearm rotation, which is treated using osteotomy. Effective preoperative planning of osteotomy requires automatic and objective quantification of deformity angles. In this paper, an automatic Congenital Radio-Ulnar Synostosis deformity evaluation method (CRUS-DE) is proposed. Initially, a method using threshold-layer tracking (TLT) and the segment anything model (SAM) is designed to recognize and segment the forearm from CT images. Subsequently, the Gaussian Process Morphable Model, in conjunction with refinement based on anatomical characteristics is developed to accurately identify forearm landmarks. Finally, the model automatically estimates deformity angles for quantitative assessment of CRUS. The forearm landmarks and deformity angles were successfully obtained from CT images based on CRUS-DE with average errors ranging from 0.98 to 1.55 mm and from 0.7° to 2.4°, respectively. No significant differences existed between the automatic method and manual method. The CRUS-DE, as an explainable method, presented excellent performance in the quantification of deformity angles. This method can be used in preoperative planning and postoperative evaluation of osteotomy for forearm deformities.
Related Concept Videos
 01:28
Automatic Processing and Automatic Social Behavior
 01:28
Methods of Classification and Identification
 01:19
Plastic Deformations
 01:14
Plastic Deformations
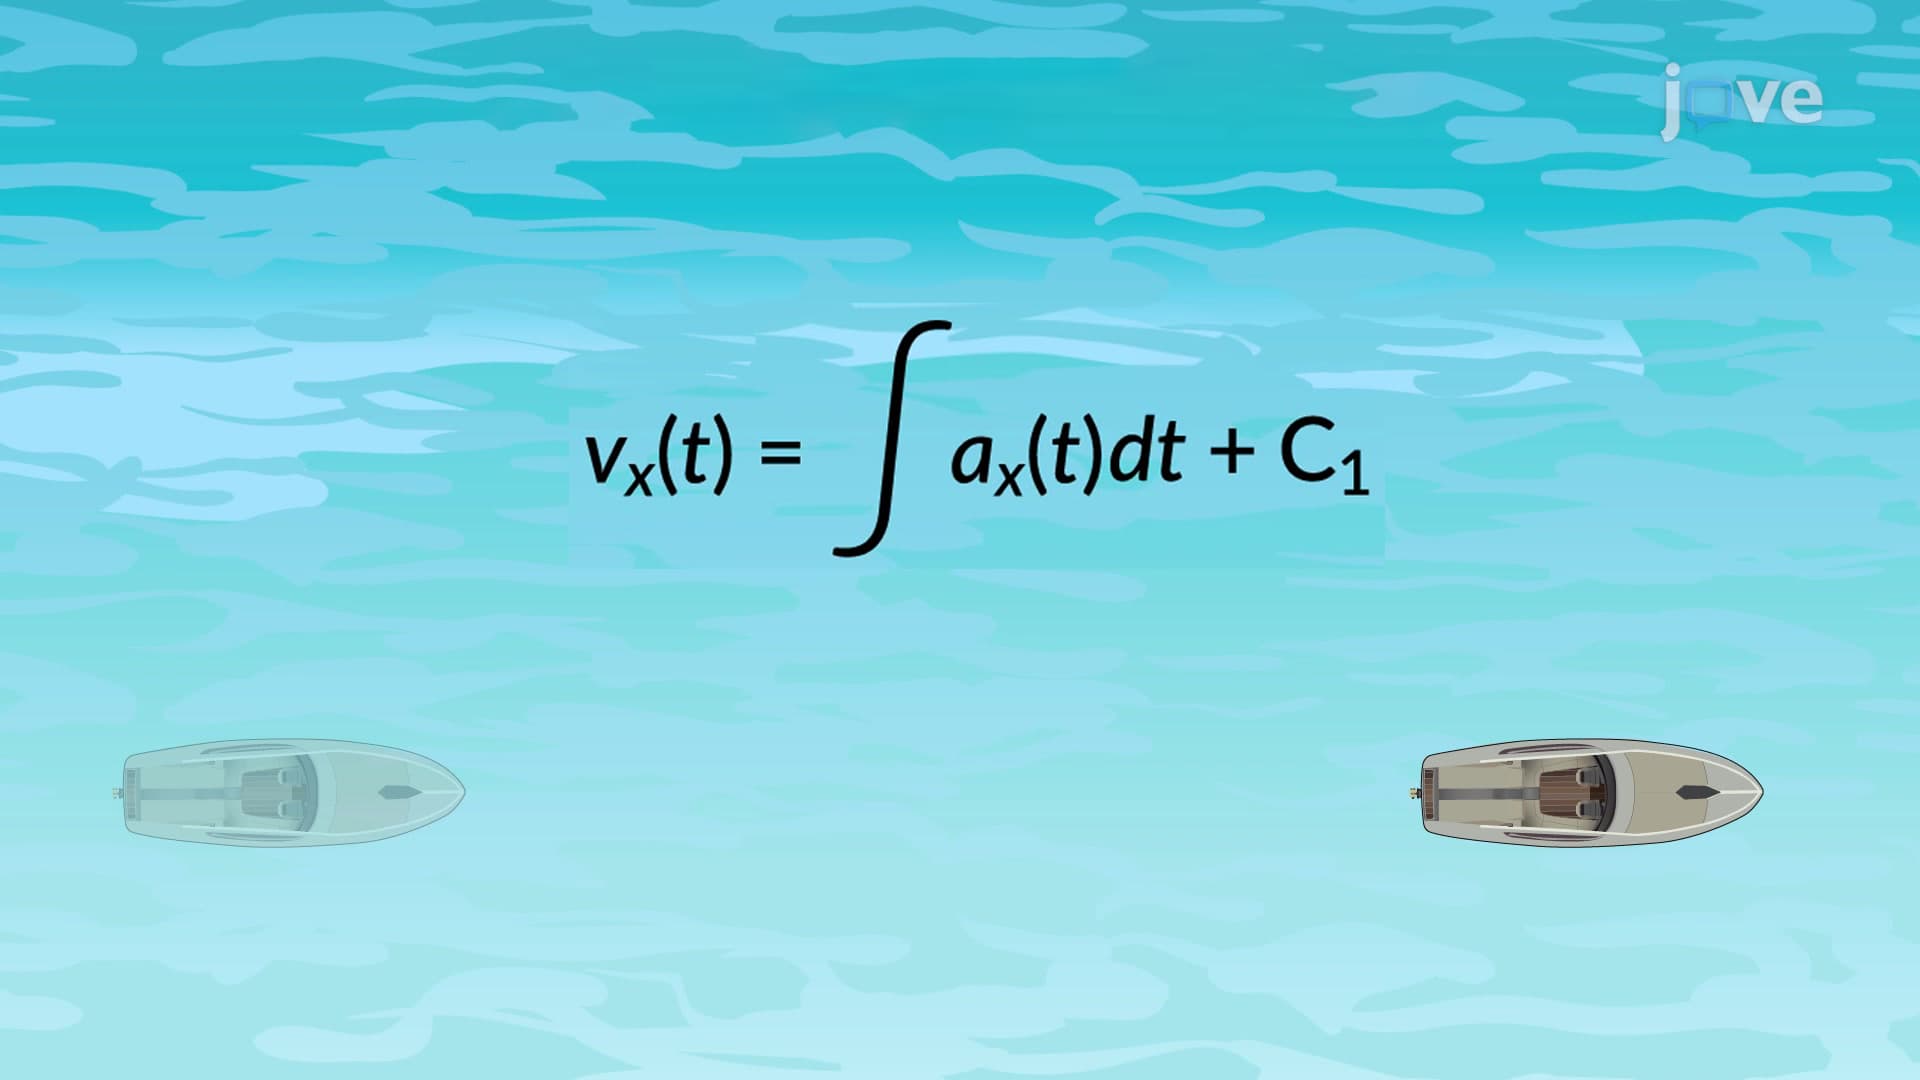 01:13
Velocity and Position by Integral Method
Consider an example to calculate the velocity and position from the acceleration function. A motorboat is traveling at a constant velocity of 5.0 m/s when it starts to decelerate to arrive at the dock. Its acceleration is...
 01:12
Temperature Dependent Deformation