Related Experiment Video
Updated: Feb 1, 2026

Dynamic Navigation for Dental Implant Placement
Published on: September 13, 2022
Comparison of the accuracy of Robotic arm and Dynamic Navigation in the placement of mandibular dental implants: An
Bander N Al-Meshary1, Mohammed Y Al-Jarsha2, Kurt B Naudi3
1Postgraduate student, MSc Oral & Maxillofacial Surgery, Glasgow University Dental Hospital & School, 378 Sauchiehall street, G2 3JZ, United Kingdom.

Objective:
To compare the spatial accuracy between Robotic Computer-Assisted implant Surgery (R-CAIS) and Dynamic Computer-Assisted Implant Surgery (D-CAIS) for placement of dental implants.
Methods:
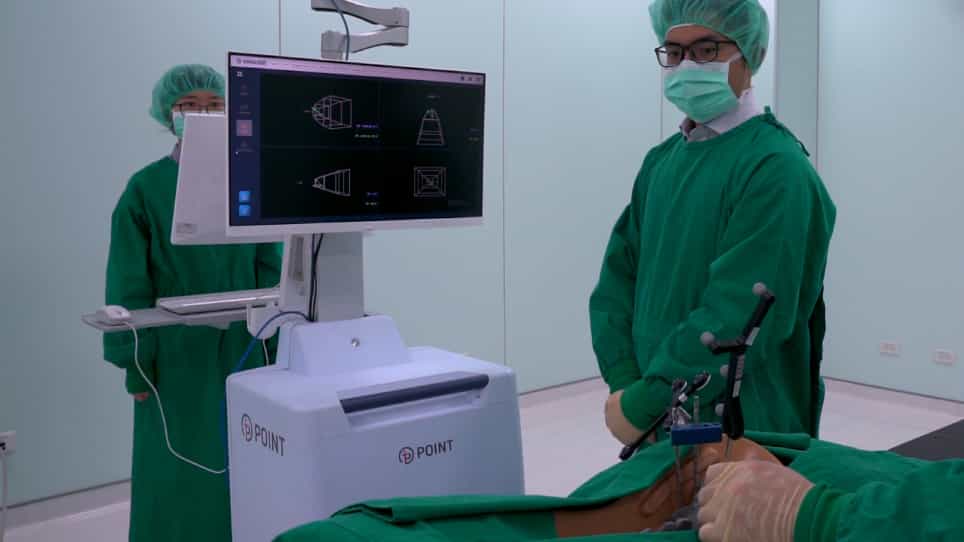
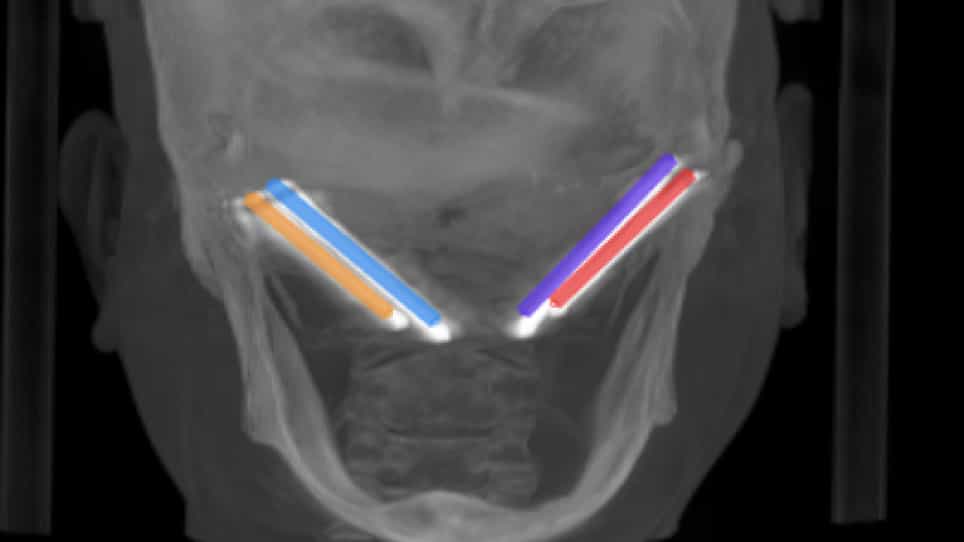
The study was carried out on twelve polyurethane mandibular models which were randomly divided into two groups (n = 6): D-CAIS (group 1) and R-CAIS (group 2). In group 1 the placement of two mandibular implants was carried out manually guided by dynamic navigation. In group 2, the placement of the two mandibular implants was achieved using a robotic arm. The postoperative Cone Beam Computed Tomography (CBCT) scans were superimposed on the predication planning to calculate the errors of the placement of the implants at entry point and at the apex as well as any angulation deviation. The statistical significance of the placement errors was assessed using Student t-tests and Mann-Whitney U tests (p < 0.05) for parametric and non-parametric measurements, respectively.
Results:
D-CAIS group cases showed significantly lower entry and apex deviations (0.99 ± 0.33 mm; 0.77 ± 0.34 mm) compared to the R-CAIS group (1.82 ± 0.50 mm; 1.30 ± 0.51 mm). Angular deviation was comparable between the two groups (3.97 ± 2.40° vs 4.33 ± 1.83°; p = 0.51). The standard deviations of the linear placement errors (entry and apex) were smaller in the D-CAIS group, whereas the standard deviation of the angular deviation was smaller in the R-CAIS group. Although the angular deviation differed slightly between the two approaches, the results showed no statistically significant difference. The measured implant placement errors of the two approaches were clinically acceptable (< 2 mm; < 5°). The measured errors are likely to be secondary to the registration process which was more complex with the application of the robotic arm for the placement of the implants.
Conclusion:
D-CAIS demonstrated higher accuracy in mandibular implant placement, particularly in terms of linear deviations, while R-CAIS showed greater consistency in angular measurements despite no significant difference between groups. Overall, the observed deviations were small and are of limited clinical significance. These findings reflect system-level performance in a controlled laboratory setting, further clinical studies are required to validate these results.
Clinical Significance:
The study investigated the challenges and opportunities of the clinical application of dynamic navigation and robotic arm for the placement of dental implants. It informs the reader with the related technical details and the digital workflow for each of these two innovative techniques.
Related Concept Videos
 02:57
The Sense of Self: Reflected Self-Appraisal and Social Comparison
 02:07
Improving Translational Accuracy
02:07Improving Translational Accuracy
 03:37
Uncertainty in Measurement: Accuracy and Precision
 01:31
Muscles that Move the Arm
The pectoralis major has two origins. Its clavicular head originates on the medial half of the clavicle. In contrast, the sternocostal head originates on the costal cartilages of ribs 1-6, the sternum, and the aponeurosis of the external oblique of the...
 01:52
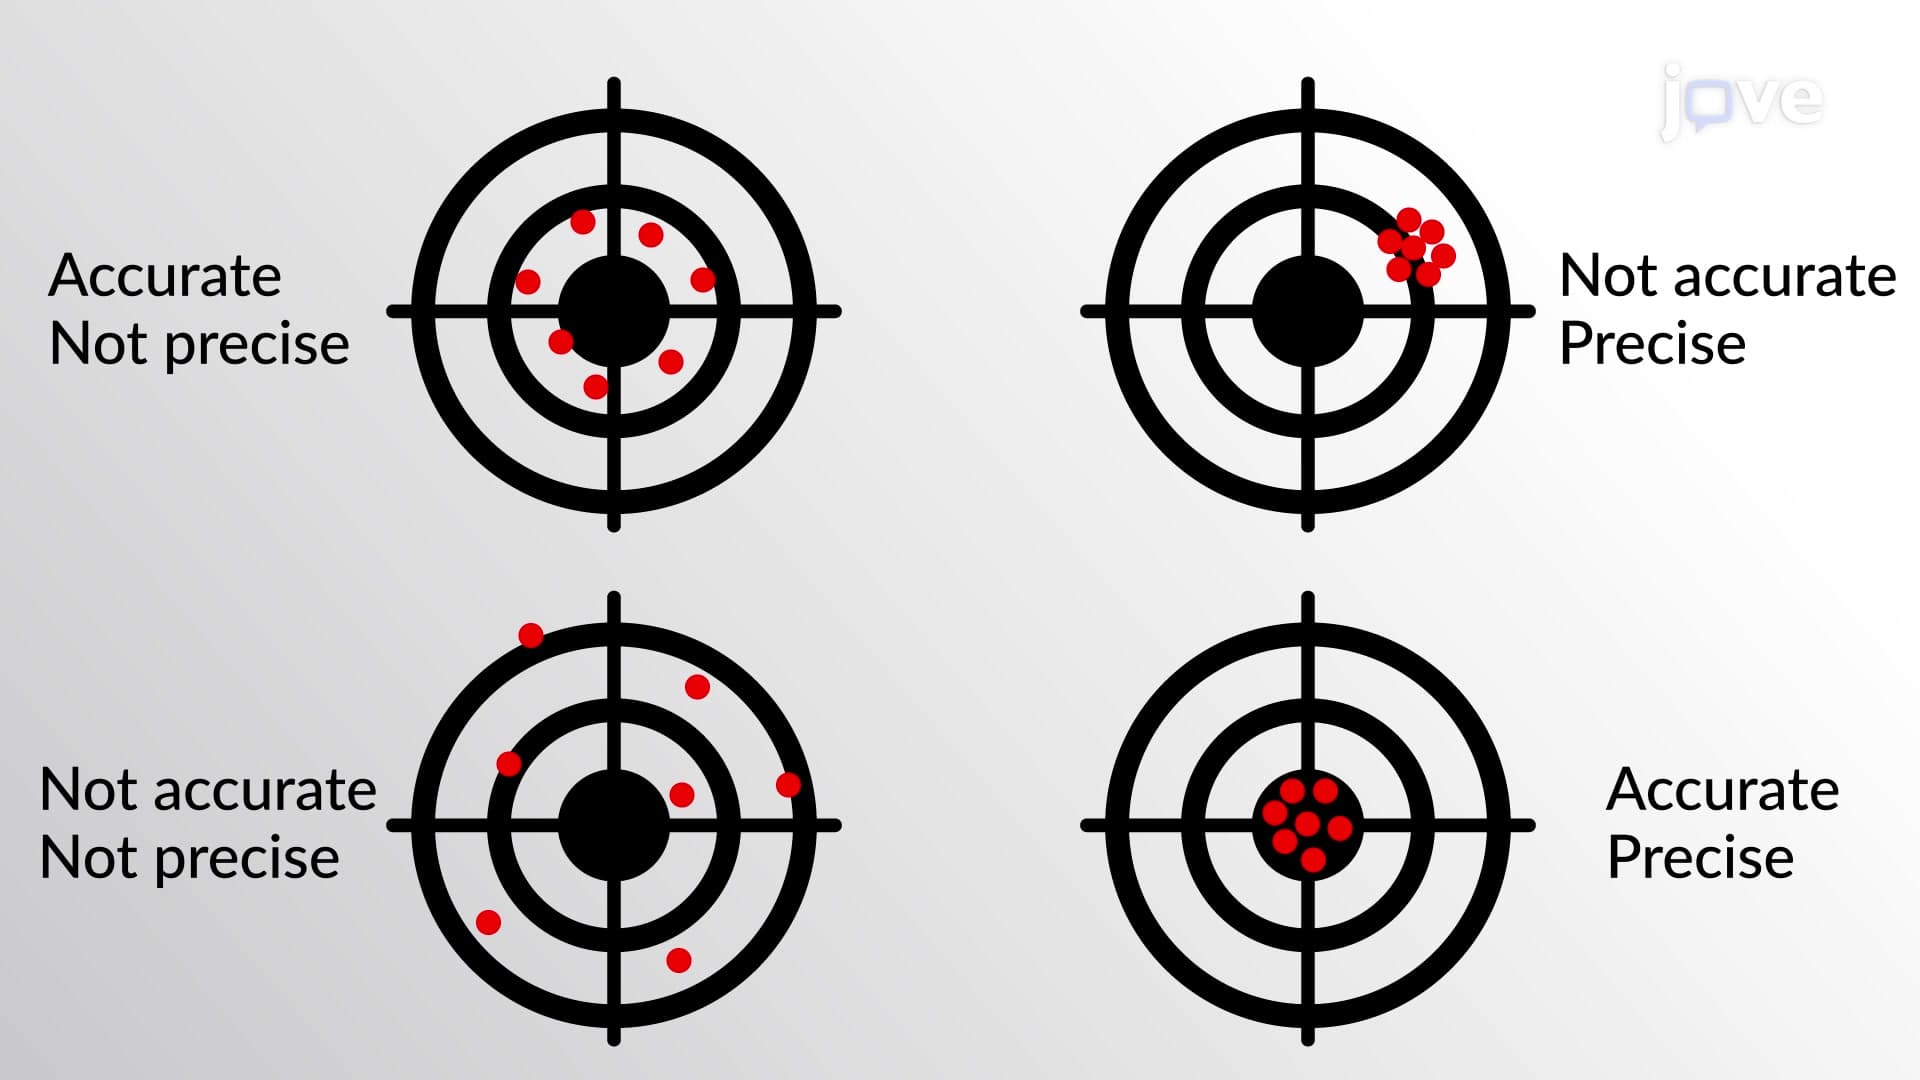
Accuracy and Precision