Related Experiment Video
Updated: Feb 5, 2026
Robot-assisted Partial Splenectomy
Published on: January 2, 2026
Feasibility and accuracy of a partial point cloud registration method for transoral robot-assisted surgery of zygoma
Hangyu Liu1, Bimeng Jie1, Chunheng Lu2
1Department of Oral and Maxillofacial Surgery, Peking University School and Hospital of Stomatology, Beijing, 100081, China; National Center for Stomatology, China; National Clinical Research Center for Oral Diseases, China; National Engineering Research Center of Oral Biomaterials and Digital Medical Devices, China.

Objectives:
To propose a novel registration method based on partial point cloud registration for transoral robot-assisted zygoma fracture surgery and validate its accuracy via a phantom study.
Methods:
This study comprised two validation phases. 1) Feasibility of partial zygomatic surface point cloud registration. Forty sets of normal CT data were selected from an established normative database. After segmentation and 3D reconstruction of zygoma, point clouds from different exposure ranges on the zygomatic bone surface (Group A: Full Zygomatic Bone Outer Surface; Group B: Area Below Infraorbital Margin; and Group C: Area Below Infraorbital Foramen.) were extracted and registered to the intact zygoma using the Iterative Closest Point (ICP) algorithm. The Fiducial Registration Error (FRE) was computed for each group. 2) Accuracy of partial point cloud registration: 10 pre-operative CT scans of zygomatic fractures were selected. Registration using fiducial markers served as the control (Group A). Using a self-developed and previously validated binocular vision camera and probe, point clouds of different exposure range (Group B1, B2, and B3) on the zygomatic bone surface were collected and registered using ICP algorithm. The accuracy of partial point cloud registration for different zygomatic bone surface areas was comparatively evaluated using both FRE and Target Registration Error (TRE).
Results:
Feasibility of partial zygomatic surface point cloud registration: The FRE for Group A, B, and C was 0.16 ± 0.16 mm, 0.18 ± 0.14 mm and 0.22 ± 0.13 mm (P > 0.05). Accuracy of partial point cloud registration: The TRE for Group A, B1, B2, and B3 was 0.47 ± 0.17 mm, 0.70 ± 0.17 mm, 0.70 ± 0.17 mm, 0.86 ± 0.24 mm. (P < 0.001) CONCLUSION: The proposed method, based on partial point cloud registration, demonstrated both accuracy and feasibility, offering a foundation for future advancements in transoral robot-assisted surgery of zygoma fracture.
Clinical Significance:
For transoral robotic-assisted zygoma reduction, the most crucial part is to enable the robot to accurately localize bone fragments following limited surgical exposure. The innovative registration approach based on partial point cloud registration has been proven to possess both accuracy and feasibility, which lays a solid foundation for the future development of transoral robot-assisted surgical techniques in the treatment of zygomatic fractures.
Related Concept Videos
 02:07
Improving Translational Accuracy
02:07Improving Translational Accuracy
 03:37
Uncertainty in Measurement: Accuracy and Precision
 01:52
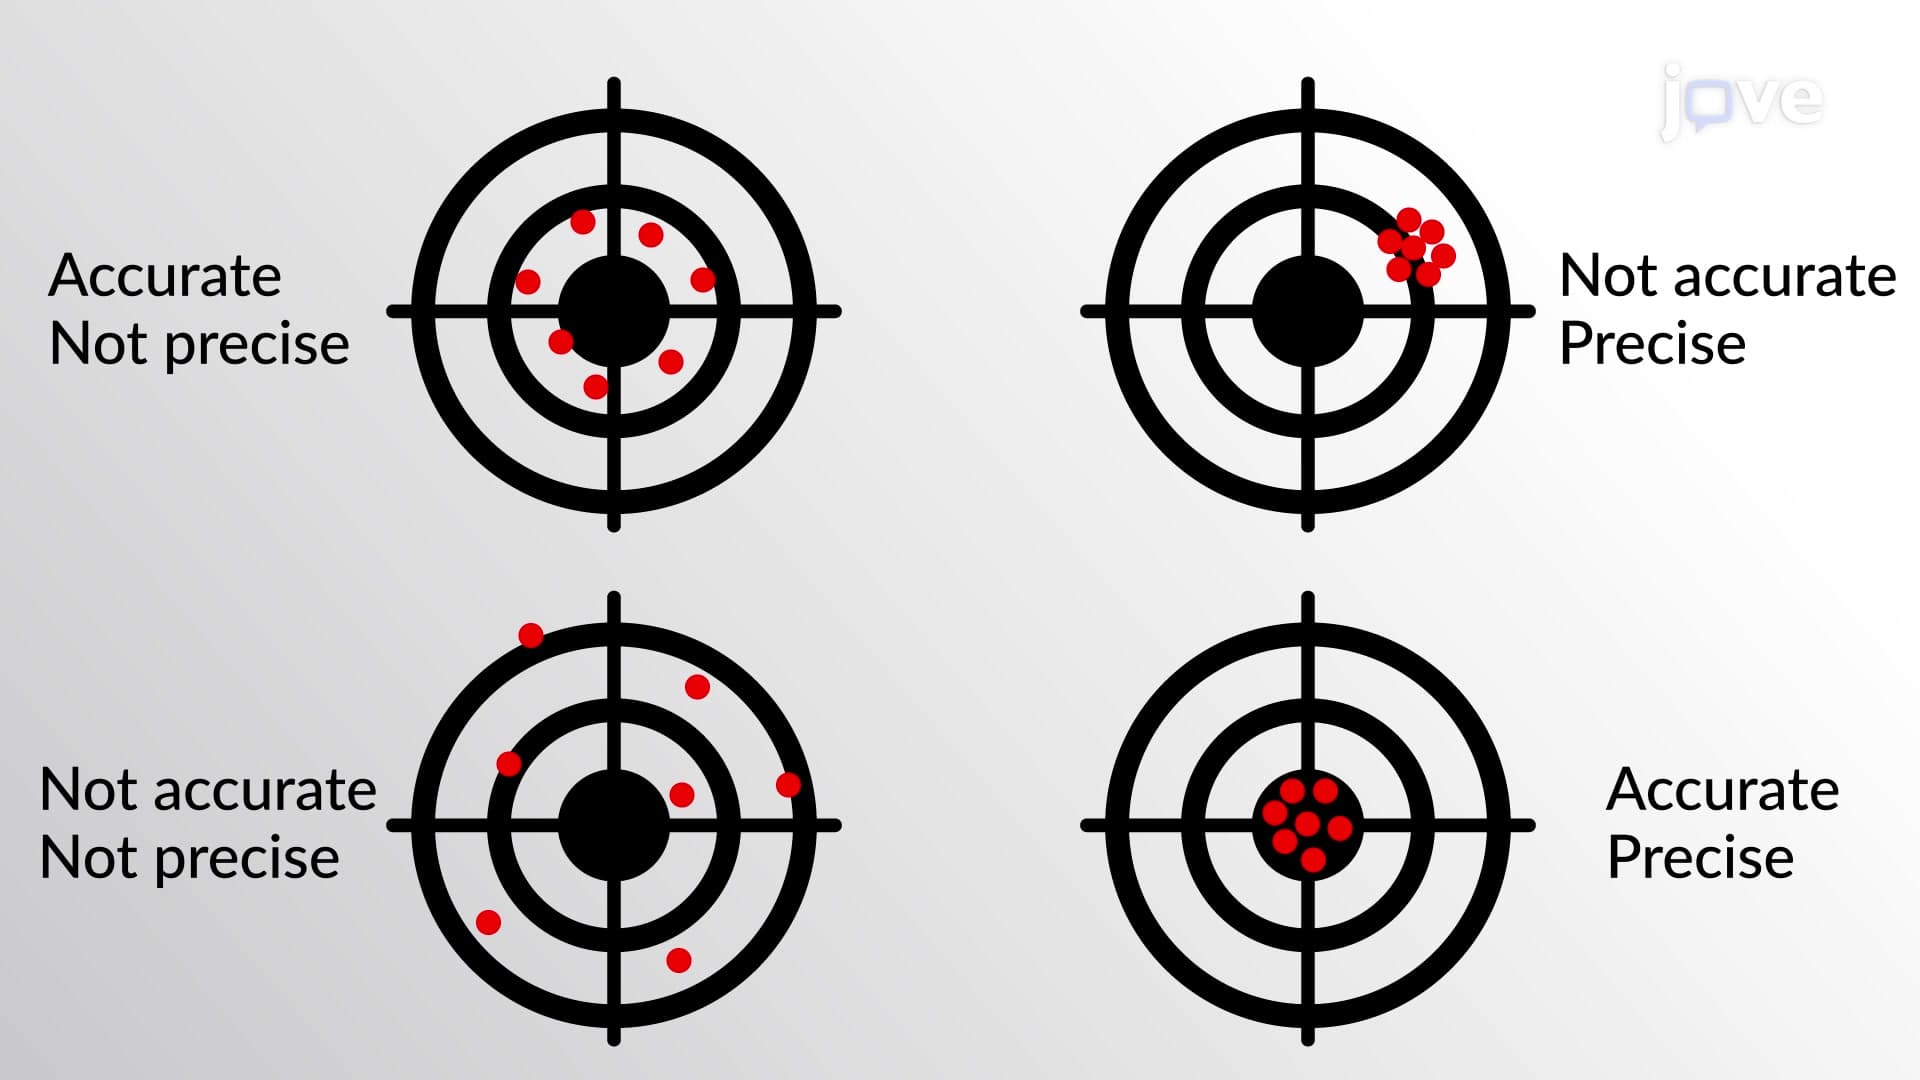
Accuracy and Precision
 01:28
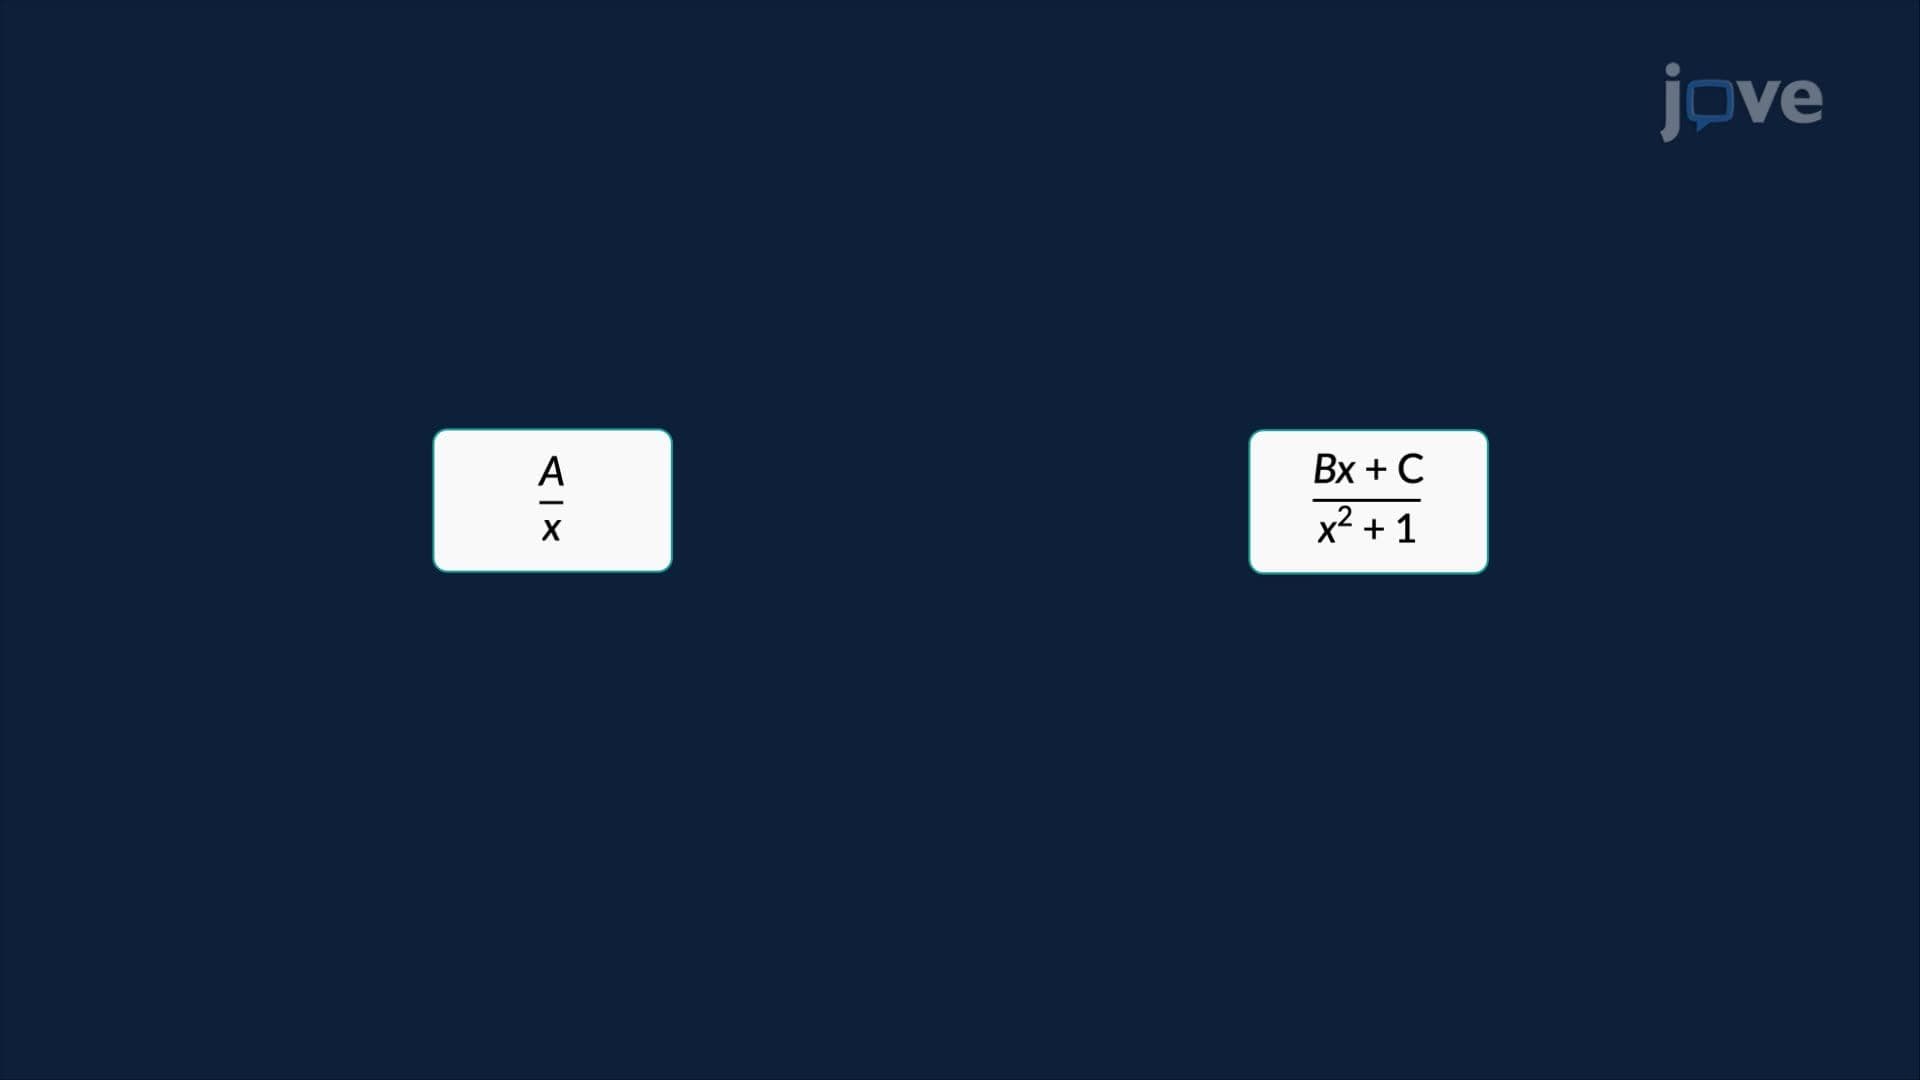
Partial Fractions
 01:28
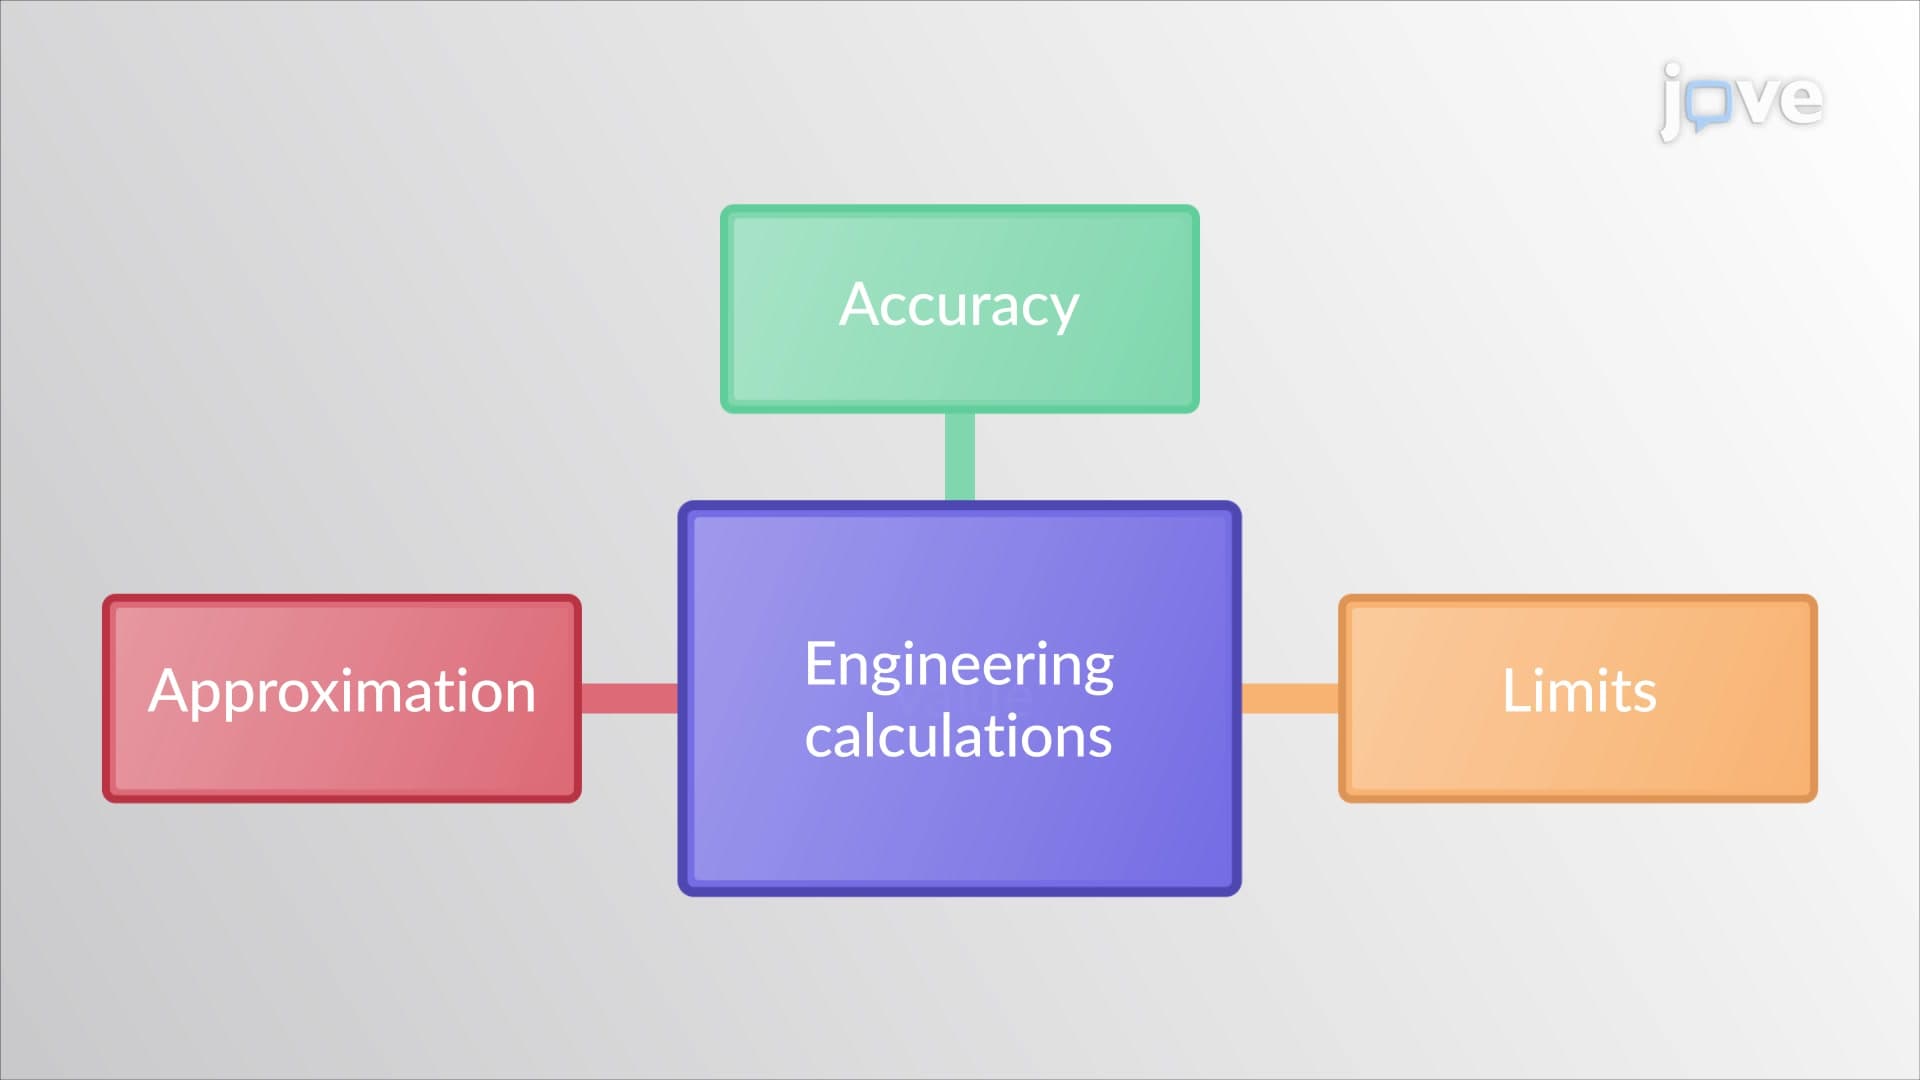
Accuracy, limits, and approximation
Accuracy is defined as the closeness of the measured value to the true or actual value. In engineering mechanics, repeated measurements are taken during theoretical or experimental analyses to ensure that the result is precise and accurate.
The accuracy of any solution is based on the...