Related Experiment Video
Updated: Feb 13, 2026

Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
Springtail-inspired compliant hinge enables terrain-adaptable takeoff in insect-scale robots
Jacob Harrison1,2, Baekgyeom Kim3,4, Hungtang Ko5
1School of Chemical and Biomolecular Engineering, Georgia Institute of Technology, Atlanta, GA 30318, USA.

Abstract:
Springtails execute millisecond-scale escape jumps with a single appendage, the furca, on soil, snow, leaf litter, and water. Across 15 taxonomic families (n=552 individuals), relative furca length is bimodal. High-speed video and confocal imaging show that in some long-furca springtails, the resilin-rich manubrium-dens joint behaves as a compliant hinge. It bends during push-off to prolong contact, suppress pitch, and bias takeoff forward, whereas rigid joints drive backward launches with rapid body rotation. We translate this mechanism to a 20-mm, 84-mg jumping robot with an elastic robo-furca hinge. This flexible hinge reduces body rotation by ~ 90% on flat ground compared to rigid-hinge designs, while maintaining takeoff speed on gravel, springboards, leaves, and pine needles, enabling passive, terrain-adaptable launches for power-limited insect-scale robots without onboard sensing or active control.

Related Concept Videos
 01:47
Osmoregulation in Insects
 01:30
Mechanism of Breathing I: Inspiration
The respiratory system, an essential network for breathing, comprises the conducting and respiratory zones, each playing a crucial role in the overall process of respiration. Let us explore the detailed mechanism of inspiration, or inhalation, which is the first phase of the respiratory cycle.
Pathway of Air during Inspiration
During inspiration, air enters our body through the nose or mouth and moves through the conducting zone,...
 02:41
pH Scale
 01:26
Scaling
 01:15
Natural Selection and Adaptation
Beyond physical adaptations,...
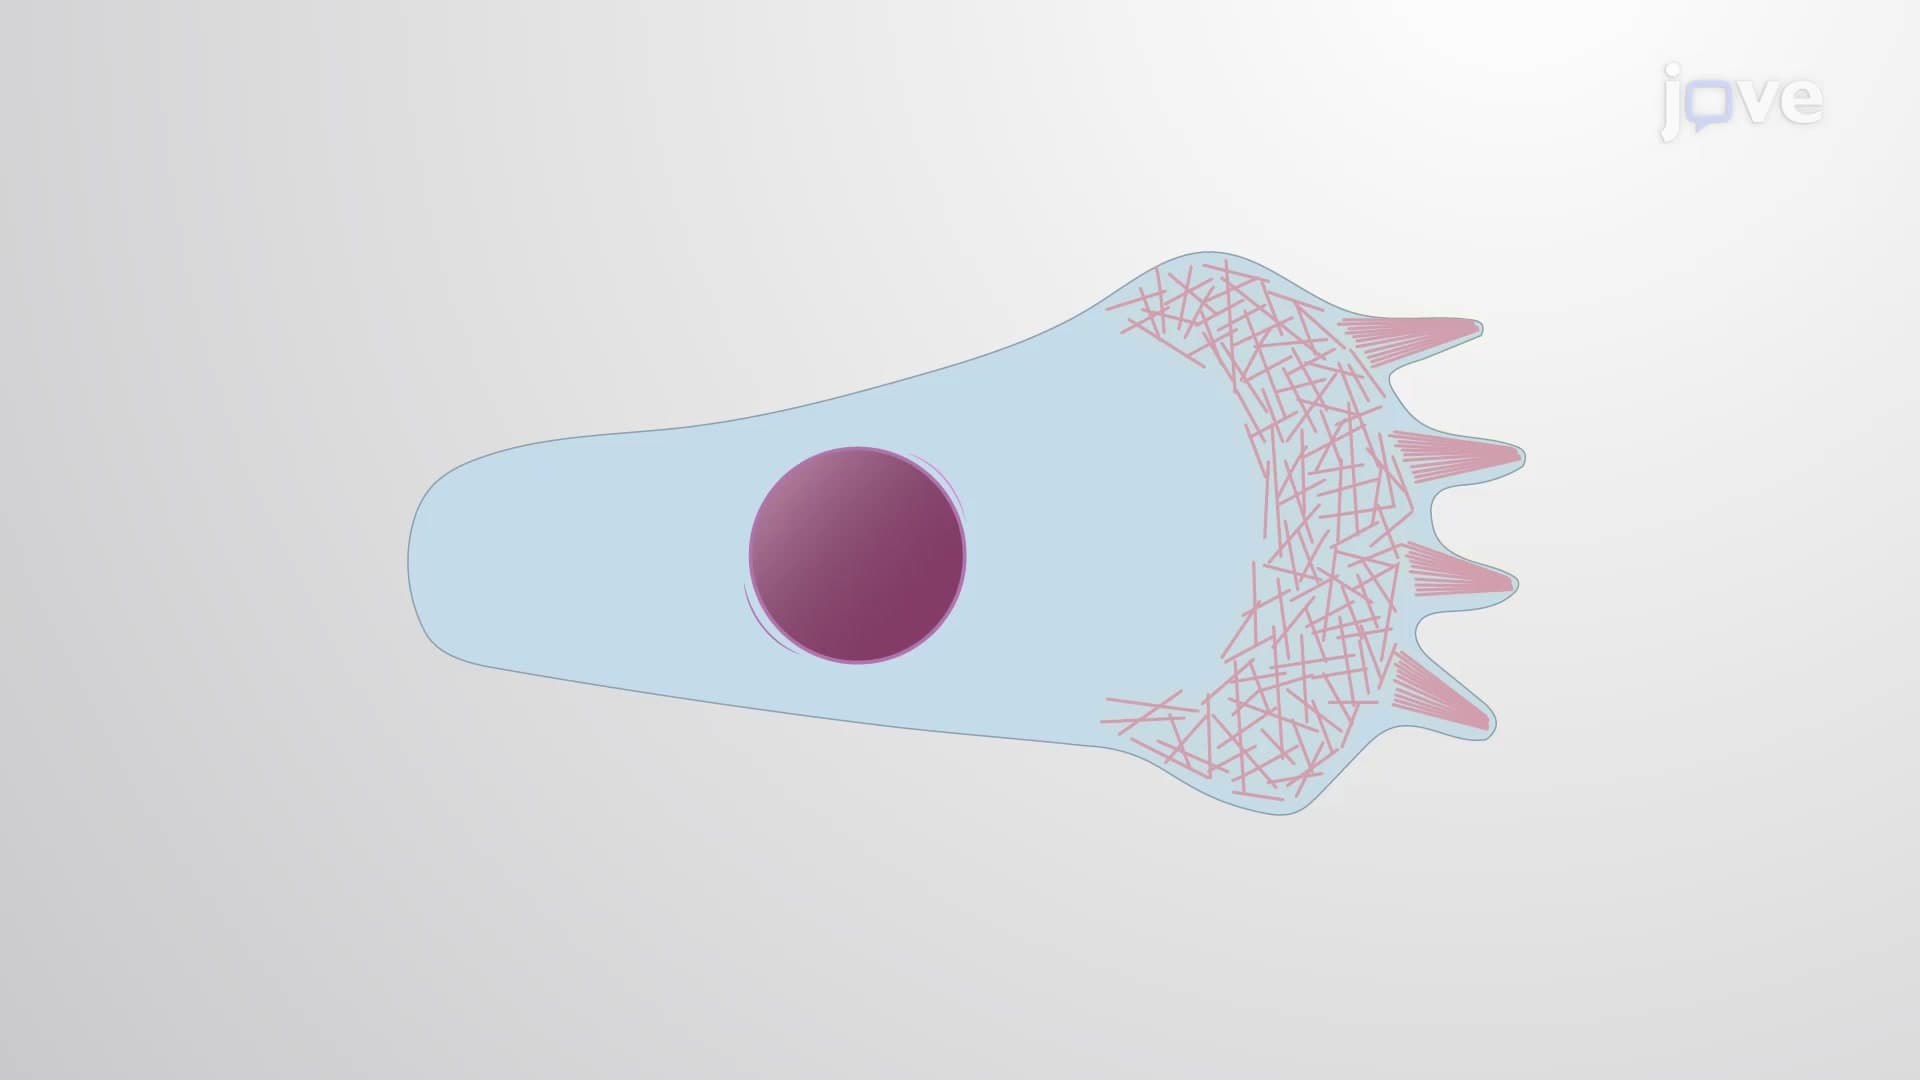 01:12
Adaptability of Cytoskeletal Filaments