Related Experiment Video
Updated: Feb 19, 2026
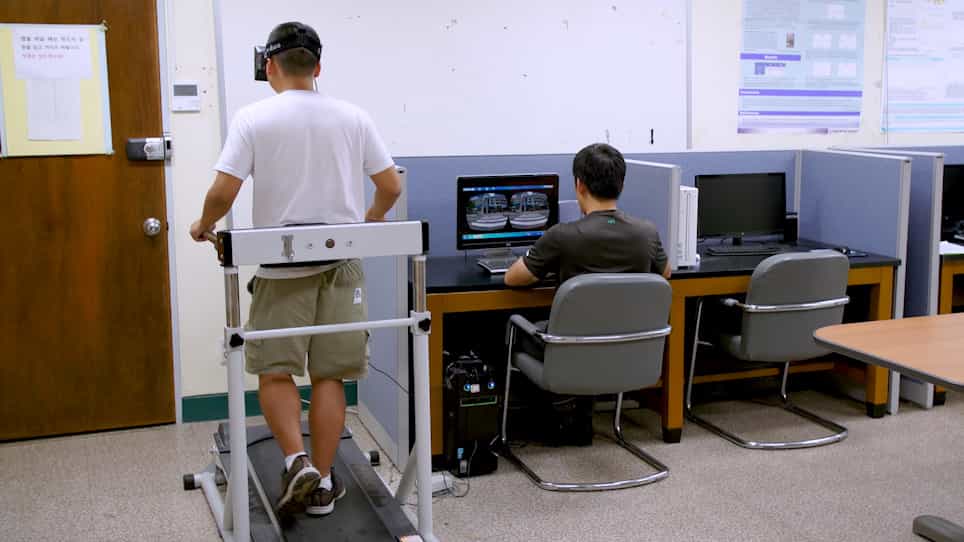

Using a Virtual Reality Walking Simulator to Investigate Pedestrian Behavior
Published on: June 9, 2020
Decision-Making of automated vehicles under diverse risky pedestrian crossing behaviors
1Jiangsu Key Laboratory of Urban ITS, Southeast University, Nanjing 211189, China; Jiangsu Province Collaborative Innovation Center of Modern Urban Traffic Technologies, Nanjing 211189, China; School of Transportation, Southeast University, Nanjing 211189, China.

Abstract:
Uncontrolled midblocks are frequently associated with elevated traffic conflict rates but often lack effective mitigation measures. Risky pedestrian crossing behaviors, such as jaywalking, distracted walking, and dart-outs from occluded areas, combined with heterogeneous driving styles, further complicate automated vehicle (AV) decision-making. However, most existing studies focus on simplified scenarios and rarely consider complex settings. This gap limits the realism and applicability of current AV decision-making research in urban environments. To address these challenges, a high-fidelity multi-agent simulation platform replicates the dynamic interactions among AVs, human-driven vehicles, and pedestrians with diverse risky crossing behaviors. A general visibility modeling method using polar-sector analysis simulates perceptual limitations caused by occlusions for multiple agents. On this basis, a deep reinforcement learning (DRL)-based decision-making framework is developed to integrate risk assessment with safety filtering. The framework dynamically incorporates environmental risk into the behavior policy of AVs and, during execution, employs a safety filter to correct or replace unsafe actions. Experimental results show that the proposed approach substantially improves safety margins and control smoothness in complex scenarios with occluded or distracted pedestrians. Compared to rule-based and risk-unaware DRL baselines, the learned policy exhibits stronger anticipatory behavior and achieves a better balance between safety and traffic efficiency. These findings highlight the promise of risk-aware DRL for managing highly uncertain and interactive urban driving environments. The approach provides new insights for the safe deployment of AVs in real-world traffic.

Related Concept Videos
 01:14
Decision Making: Traditional Method
First, a specific claim about the population parameter is decided based on the research question and is stated in a simple form. Further, an opposing statement to this claim is also stated. These statements can act as null and alternative hypotheses, out of which a null hypothesis would be a...
 01:20
Decision Making
Automatic decision-making is fast, intuitive, and relies on gut feelings...
 01:09
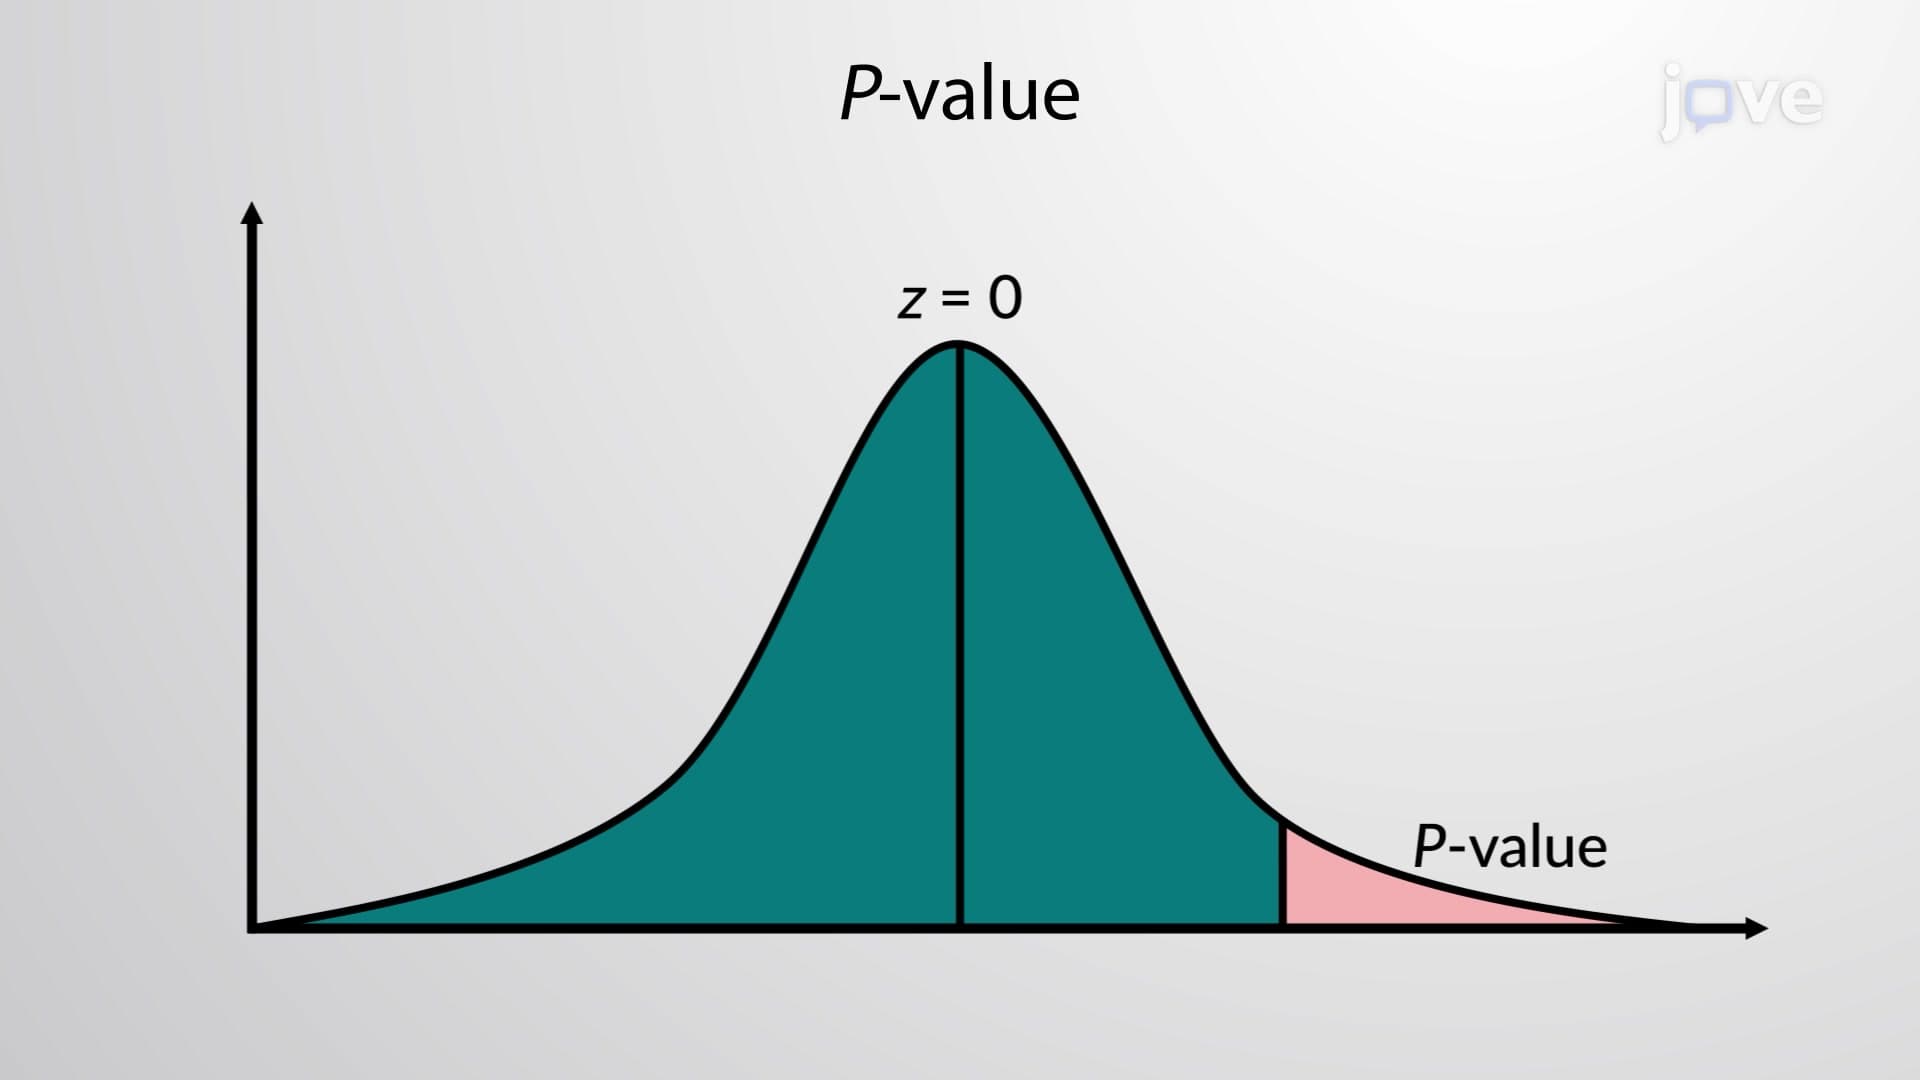
Decision Making: P-value Method
First, a specific claim about the population parameter is proposed. The claim is based on the research question and is stated in a simple form. Further, an opposing statement to the claim is also stated. These statements can act as null and alternative hypotheses: a null hypothesis would be a neutral statement while the alternative hypothesis can...
 01:42
Schemas
 01:25
The Anchoring-and-Adjustment Heuristic
 01:37
Reason and Intuition